
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
mm-Wave Sensing for In-Cabin and Exterior Detection: Use Cases, Limits, and Integration Tips
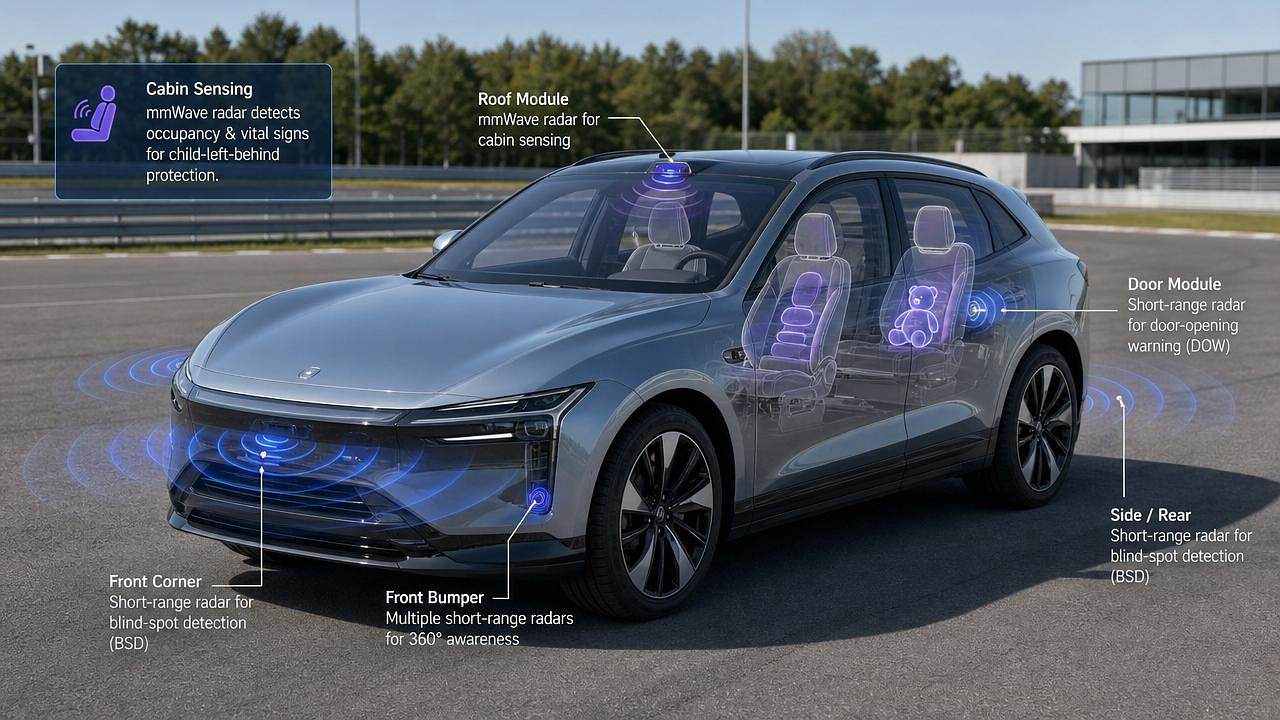
Where mm-wave sensing creates real value in modern vehicles
mm-wave sensing now sits closer to core vehicle decisions than many teams expected a few years ago.
Its role is no longer limited to simple presence detection or isolated convenience features.
In practical automotive programs, it affects safety logic, HMI behavior, exterior perception, and system redundancy.
That matters especially in EV platforms, where efficiency, packaging, and sensor fusion all compete for the same space.
For AEVS, this topic fits naturally within the wider link between smart optical perception, body electronics, and exterior intelligence.
The same vehicle that uses matrix LED logic, lightweight wheels, and sensor-driven switching also needs reliable environmental awareness.
In that context, mm-wave sensing becomes a practical engineering tool, not a headline feature by itself.
Actual deployment starts with scenario differences
The first mistake is treating in-cabin and exterior detection as the same sensing problem.
They may share a radar technology family, but the design targets are very different.
Inside the cabin, mm-wave sensing often focuses on micro-motion, occupancy, child presence, or gesture-related events.
Outside the vehicle, the same technology usually supports blind-spot monitoring, door opening alerts, and near-field object detection.
The signal environment changes as well.
Cabin glass, seat frames, trim materials, and passenger movement create one pattern of reflections.
Bumpers, road spray, metallic body geometry, curbs, and adjacent traffic create another.
Because of that, mm-wave sensing decisions should begin with use conditions, not only with nominal range claims.
Inside the cabin, sensitivity matters more than headline range
In-cabin mm-wave sensing is valuable when cameras face privacy concerns or poor lighting conditions.
It also helps when designers want low-visibility integration behind trim or roof modules.
A common use case is occupant detection after parking.
Here, the system must capture very small breathing movements, not just obvious body motion.
That pushes mm-wave sensing toward stronger signal processing, careful antenna placement, and low false-negative tolerance.
Another cabin case involves adaptive restraint logic.
The requirement is less about long reach and more about reliable occupancy classification across seats and postures.
In vehicles with panoramic roofs, premium NVH targets, and dense electronic packaging, integration gets more delicate.
Roof modules, sunroof motors, and overhead consoles can all shape mm-wave sensing performance in ways early prototypes may miss.
That is why cabin validation should include trim-closed testing rather than bench-only confirmation.
Exterior detection depends more on environment stability
Exterior mm-wave sensing usually faces tougher exposure and more variable object behavior.
A blind-spot function on a dry highway behaves differently from the same function in urban rain.
Door opening warning adds another challenge because bicycles, scooters, and pedestrians approach with different trajectories.
Short-range bumper radar can also support parking and curb awareness, but body styling changes the picture.
On sleek NEV platforms, aerodynamic surfaces and closed front designs may help efficiency while complicating sensor mounting windows.
Paint stack, emblem materials, bumper thickness, and bracket angle all influence mm-wave sensing quality.
In practice, exterior use cases need more than detection distance.
They require stable performance across weather, contamination, low-speed clutter, and body manufacturing variation.
Different scenarios change the engineering priorities
A quick comparison helps explain why one mm-wave sensing setup rarely fits every function well.
Where mm-wave sensing still has clear limits
mm-wave sensing is powerful, but it does not solve every perception problem cleanly.
One limit is object interpretation.
Radar can detect movement and position well, yet semantic understanding often remains weaker than camera-based systems.
Another limit is multipath complexity.
In cabins with metallic details or in exterior zones near complex body contours, reflections can distort confidence levels.
Low-cost integration can create another hidden limit.
A sensor that looks strong in a datasheet may underperform once hidden behind unsuitable plastic, coatings, or packaging structures.
There is also a system-level limit.
If vehicle software cannot handle edge cases, better mm-wave sensing hardware alone will not produce dependable behavior.
That is why AEVS often frames sensing choices within wider exterior and body-network architecture, not as isolated components.
Integration works better when paired with adjacent vehicle systems
The strongest mm-wave sensing results usually come from coordination, not from sensor substitution.
For exterior functions, radar logic often works best when aligned with lighting, switch control, and warning strategies.
A door opening alert, for example, should connect cleanly with mirror indicators, cabin chimes, and body controller timing.
For in-cabin functions, mm-wave sensing should be checked against seat sensors, HVAC airflow patterns, and roof electronics.
This is especially relevant in premium EV cabins, where electrochromic roof systems and compact overhead packaging affect sensor positioning.
On the exterior side, tire noise targets, wheel airflow design, and lighting architecture may seem unrelated.
Yet they influence sensor contamination, thermal behavior, and warning experience more than many programs assume.
Practical integration checks before release
- Confirm material transparency through final bumper, trim, or roof stack-up samples.
- Test mm-wave sensing after styling freeze, not only during mule development.
- Review EMC and cross-sensor interference in dense electronic architectures.
- Validate warning thresholds in real traffic, not only scripted proving-ground runs.
- Check serviceability when sensors sit behind painted or bonded exterior parts.
Misjudgments that often delay performance validation
A repeated misjudgment is assuming similar use cases need the same radar tuning.
Blind-spot monitoring and door opening warning may share hardware, but their timing priorities differ.
Another common oversight is focusing on purchase cost while ignoring calibration and validation workload.
With mm-wave sensing, integration effort often determines real program cost more than sensor price alone.
Programs also underestimate seasonal change.
Road spray, ice film, cabin load variation, and aftermarket body repairs can all shift performance margins.
In regulated markets, compliance interpretation matters too.
ECE and DOT related functions may not dictate every radar choice directly, but they shape warning behavior and validation evidence.
A better way to choose mm-wave sensing for the next platform
A useful starting point is to map each intended function to its real operating environment.
That means separating cabin micro-motion tasks from exterior tracking tasks before hardware decisions are frozen.
Then compare three layers together: sensing performance, packaging reality, and software response logic.
If one layer is weak, the full mm-wave sensing concept becomes fragile.
For vehicle programs balancing exterior aesthetics, lightweight structures, and smart perception, this approach is more durable.
It matches the broader AEVS view that body electronics, optical systems, aerodynamic packaging, and safety perception must be judged together.
The next step is straightforward.
List the target scenarios, define the non-negotiable detection conditions, and test mm-wave sensing in final-material assemblies early.
That usually reveals whether the concept is truly scalable, serviceable, and ready for wider platform adoption.