
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
Tags
- smart optical perception
- electric sunroof systems
- aluminum alloy wheels
- high-performance tires
- LED headlight assemblies
- auto sensor switches
- dynamic driving perception
- blind-spot monitoring
- electric sunroof
- alloy wheels
- performance tires
- headlight assemblies
- automotive sensor systems
- vehicle exterior design
How Automotive Sensor Systems Improve ADAS Performance and Vehicle Safety
How Automotive Sensor Systems Improve ADAS Performance and Vehicle Safety
Automotive sensor systems sit at the center of modern ADAS. They do not simply detect obstacles or trigger warnings; they shape how a vehicle interprets motion, distance, light, weather, and driver intent in real time. That distinction matters. When ADAS performs well, it is usually because the sensing layer is accurate, stable, and intelligently integrated. When it performs poorly, the weakness often starts there too.
For anyone tracking intelligent mobility, especially in the NEV era, sensors are no longer a narrow electronics topic. They now influence vehicle exterior design, lighting architecture, body network logic, aerodynamic packaging, safety redundancy, and even aftermarket service complexity. This is one reason platforms such as AEVS pay close attention to the intersection of smart optical perception, exterior systems, and dynamic driving perception. In practice, ADAS capability is rarely the result of one isolated module. It is built through coordination across headlights, sensor switches, wheel and tire behavior, and the broader vehicle intelligence stack.
ADAS depends on perception quality, not just software ambition
There is a tendency in public discussion to focus on algorithms, compute platforms, or headline features such as lane centering and automated parking. Those are visible outputs. The less visible truth is that ADAS can only make decisions from the data it receives. If the sensor layer has blind spots, contamination, weak calibration, or poor environmental tolerance, the software is working with incomplete reality.
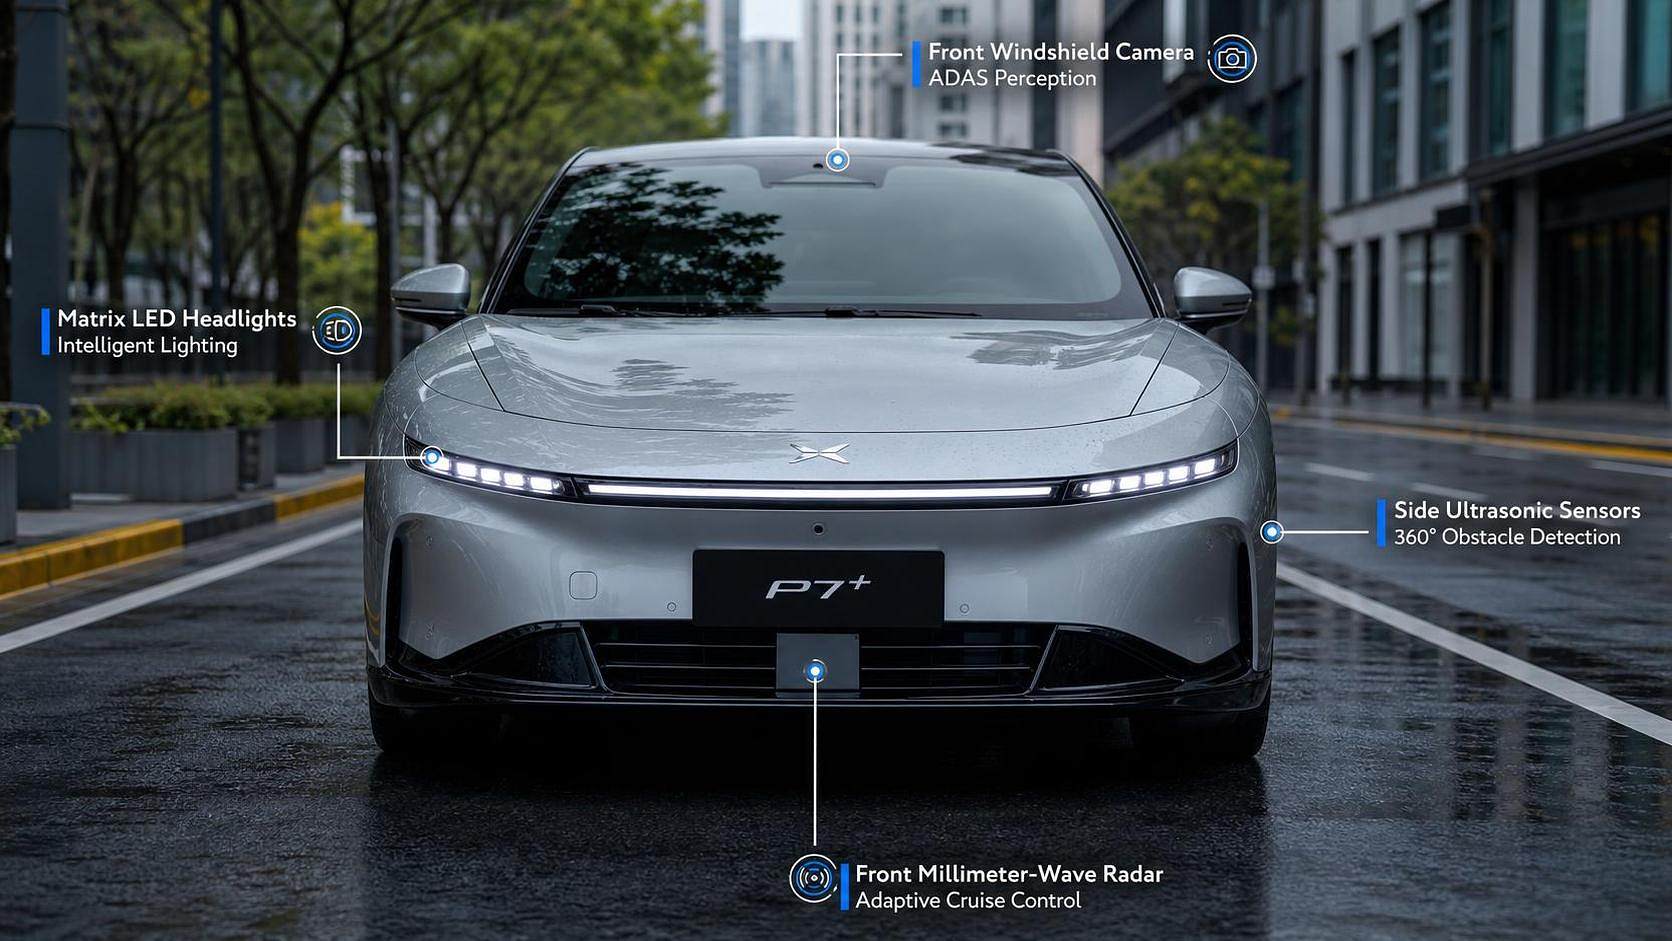
This is why automotive sensor systems are so critical to safety performance. Radar, cameras, ultrasonic sensors, photoelectric rain and light sensors, and related body-network sensing devices each contribute a different kind of environmental understanding. A forward camera may identify lane markings and classify objects. Millimeter-wave radar can estimate relative speed and distance in conditions where pure vision may struggle. Light sensors support automatic headlamp behavior, which affects driver visibility and the quality of camera-based perception at night. Rain sensing can trigger wiper response early enough to protect both the driver’s view and the camera’s usable image.
In other words, better sensing does not just add features. It reduces uncertainty.
Why one sensor is never enough
No single sensing technology performs best in every condition. Cameras are rich in visual detail but are sensitive to glare, darkness, fog, lens contamination, and contrast limitations. Radar is more resilient in poor weather and can measure velocity directly, but it does not describe the scene with the same semantic richness as vision. Ultrasonic sensors are useful at close range but are not a substitute for medium- or long-range detection.
That is why sensor fusion has become foundational to ADAS design. A practical system combines different sensor outputs and checks them against each other. If a camera sees a lane boundary but radar detects an unexpected lateral object movement, the controller can weigh both inputs before issuing a warning or intervention. This layered perception improves reliability, especially in edge cases that often matter most for safety.
For researchers and suppliers, the more useful question is not whether a vehicle has many sensors. It is whether those sensors are placed, calibrated, and fused in a way that reflects real driving conditions. A crowded sensor list can still underperform if thermal management, field of view, vibration resistance, or cleaning strategy were treated as secondary issues.
The direct link between sensing and core safety functions
Most drivers encounter ADAS through specific functions rather than through sensor architecture. Yet the connection is straightforward once you map it feature by feature.
Blind-spot monitoring relies heavily on side and rear sensing stability. If radar performance is inconsistent because of packaging interference, poor bumper material compatibility, or signal obstruction, warnings may come too late or not at all. Lane departure support depends on camera clarity and clean lane recognition logic, but it also depends on how well lighting and windshield conditions are managed. Automatic emergency braking needs rapid object detection and path prediction, which generally requires both distance confidence and classification confidence. Adaptive lighting and smart headlamp activation are another overlooked example: they are often treated as comfort features, but they directly support safety by improving visibility without dazzling other road users.
This is where AEVS’s focus on LED headlight assemblies and auto sensor switches becomes highly relevant. Headlights are no longer passive components, and sensor switches are no longer simple convenience triggers. Together they form part of the vehicle’s perception loop. A photoelectric sensor that accurately interprets ambient conditions can activate lighting at the right moment. A more advanced matrix LED system can then distribute light with precision, helping both the human driver and, in some architectures, the camera system operating within the same environment.
Exterior design now affects ADAS more than many teams expect
ADAS performance is not decided by electronics engineers alone. Exterior packaging has become a serious engineering constraint. Sensor location influences detection range, object occlusion, contamination risk, thermal exposure, and service accessibility. A radar hidden behind a bumper sounds elegant until bumper thickness, paint composition, or mounting angle starts affecting signal behavior. A camera integrated near the windshield may offer a strong forward view, but glare control, washer coverage, and heating strategy become part of system reliability.
That broader system view aligns with how AEVS frames vehicle exteriors: not as isolated styling surfaces, but as active contributors to aerodynamics, perception, and energy efficiency. In NEVs especially, teams are balancing drag reduction, lightweighting, thermal loads, and safety electronics in the same design envelope. Even wheel and tire choices can influence ADAS consistency indirectly, because road noise, vibration behavior, wet grip, and stopping response all affect how control systems perform when a warning becomes a braking event.
This does not mean every exterior component is part of ADAS. It means ADAS cannot be evaluated in isolation from the rest of the vehicle.
What usually limits real-world performance
The biggest gap between demo performance and daily performance often comes from ordinary conditions rather than dramatic failure. Dirt on a lens. Road spray. Low winter sun. Heavy rain. Reflections from wet asphalt. Tire wear changing vehicle response. Minor alignment drift after repair. None of these issues are exotic, but together they shape whether an ADAS feature feels trustworthy.
Several risks deserve closer attention:
- Sensor contamination, especially for forward-facing cameras and parking sensors.
- Misalignment after windshield replacement, bumper repair, or collision work.
- Software tuning that performs well in ideal road markings but struggles in mixed or degraded infrastructure.
- Weak coordination between lighting, wiper logic, and perception systems during low-visibility driving.
- Regional differences in traffic rules, lane marking quality, and homologation requirements such as ECE or DOT-related considerations.
None of these can be solved by adding more sensors alone. They require system-level validation and a strong understanding of use conditions. That is also why technical intelligence work matters. AEVS’s Strategic Intelligence Center, with its attention to compliance, optical systems, airflow behavior, and material shifts, reflects a reality many buyers and researchers discover late: performance is shaped as much by integration discipline as by component specification.
The NEV context changes the discussion
New energy vehicles add another layer. Their packaging priorities are different, their torque characteristics are different, and customer expectations for intelligent features are usually higher. A heavier curb weight and strong instant torque place more emphasis on tire behavior and braking coordination. Quieter cabins make warning logic and false alerts more noticeable. Energy efficiency targets also push teams to rethink drag, cooling, and electrical loads, which can affect where sensor modules and lighting systems are placed.
That is why it makes sense that AEVS tracks not only smart optical perception but also aluminum alloy wheels, high-performance tires, and electric sunroof systems. At first glance these may seem separate from ADAS. In reality, they belong to the same vehicle ecosystem where safety, range, comfort, and exterior intelligence increasingly overlap. A matrix LED headlamp, for example, is part optics, part thermal engineering, part control logic, and part regulatory compliance.
How to evaluate sensor systems more intelligently
For information research, a useful evaluation framework is less about chasing the newest acronym and more about asking practical questions:
- What sensing technologies are being used for each ADAS function, and why?
- How are those sensors packaged within the vehicle exterior?
- What happens in rain, glare, snow, road spray, or night driving?
- What calibration or service procedures are required after maintenance?
- Which local standards, roadway conditions, or market regulations may affect deployment?
- How well does the system coordinate with lighting, wipers, body controls, tires, and braking behavior?
These questions tend to reveal more than broad claims about smart driving capability. They also help separate mature engineering from feature inflation.
Automotive sensor systems improve ADAS performance because they give the vehicle a more reliable understanding of its surroundings and its own operating state. They improve vehicle safety when that understanding remains stable across weather, speed, road quality, and everyday wear. The hard part is not adding another sensor. It is turning sensing, lighting, exterior architecture, and control logic into one coherent safety system.
Anyone following this space should watch sensor integration as closely as sensor innovation. The future of ADAS will be shaped not only by better chips and smarter software, but by how well the entire exterior and perception stack is engineered around real roads, real maintenance, and real safety demands. Before drawing conclusions on any platform or component path, it is usually worth checking the specific sensing configuration, validation scope, and compliance requirements for the target market.