
Industry Portal
Related News
- 00
0000-00
Which ISO Standards Govern Vehicle Lightweighting Materials and Validation Testing? - 00
0000-00
Wheel Lightweighting in Europe: How EV Regulations Are Reshaping Wheel Sourcing - 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials
Dynamic Driving Perception Explained: Core Functions, Benefits, and Limits
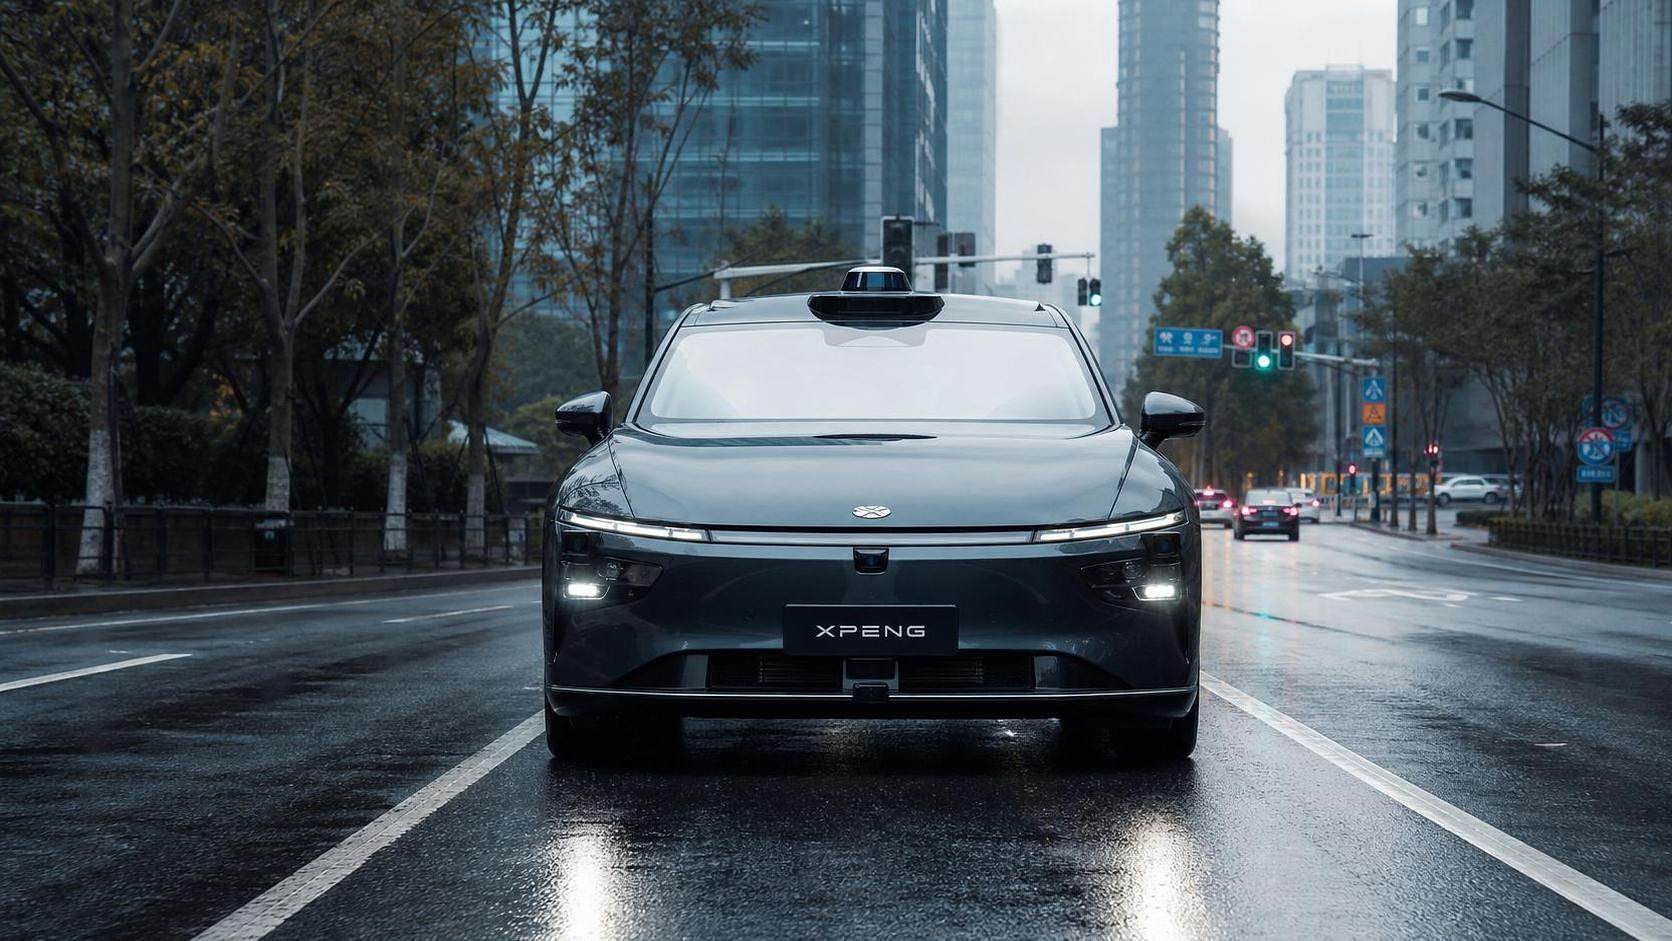
Dynamic Driving Perception Explained: Core Functions, Benefits, and Limits
Dynamic driving perception is becoming a practical benchmark for modern vehicles. It describes how a car senses the road, interprets motion, and supports safer decisions in real time. For NEVs and smart mobility platforms, it is no longer just a sensor feature. It is a system-level capability that links optics, control logic, tires, lighting, and body electronics into one driving experience.
From a technical review angle, dynamic driving perception matters because it can be measured, compared, and tuned. That makes it useful for platform validation, supplier selection, and performance audits. It also connects directly to exterior and vision systems, where design and engineering increasingly overlap.
What dynamic driving perception really covers
At the simplest level, dynamic driving perception is the vehicle’s ability to recognize changing conditions while moving. This includes lane edges, nearby vehicles, road texture, lighting shifts, weather effects, and sudden obstacles. In practice, the system combines cameras, radar, ultrasonic sensing, signal fusion, and actuator response.
The key point is not isolated sensing. It is whether the vehicle can create a stable perception loop under vibration, glare, rain, dust, and speed variation. A strong dynamic driving perception stack should reduce uncertainty, not just collect more data.
For technical evaluation, that means asking a few direct questions: How fast does the system detect change? How well does it filter noise? How consistent is its response across road types? Those answers matter more than marketing labels.
Core functions that shape performance
The first function is environmental sensing. Cameras and radar identify objects, boundaries, and motion patterns. In low light, smart headlights become part of the perception chain because they improve scene visibility and help the vehicle interpret the road ahead.
The second function is signal fusion. Raw sensor output is often incomplete or noisy. The system must combine optical and radar data with vehicle dynamics signals such as yaw rate, speed, wheel slip, and steering angle. That fusion is what turns data into useful driving awareness.
The third function is action coordination. Perception only has value when the vehicle reacts correctly. Braking, steering assist, headlight control, wiper activation, and warning logic all depend on perception quality. If one layer reacts late, the whole experience feels less reliable.
This is also where exterior systems matter more than many teams expect. Tire grip, wheel inertia, aerodynamic drag, and lighting geometry can all change how cleanly dynamic driving perception performs.
Why it matters for NEVs and smart mobility
NEVs place extra pressure on perception systems. Instant torque, heavier battery packs, and quiet cabins make small control errors more noticeable. A vehicle may feel smooth in a lab test, yet still expose weak perception under wet roads, high-speed lane changes, or rough pavement.
That is why dynamic driving perception has become linked to customer trust. Drivers expect a vehicle to read the environment early and respond naturally. A good system should feel calm, not intrusive. It should support the driver without creating false alarms or abrupt corrections.
For OEMs and Tier 1 suppliers, the business value is clear. Better perception can support safer ADAS tuning, higher comfort scores, and stronger product differentiation. It also gives technical teams a measurable way to compare platforms across regions and compliance standards such as ECE and DOT.
Benefits that show up in real use
One major benefit is improved situational awareness. The vehicle can detect hazards earlier, especially in complex traffic or poor visibility. That often translates into more stable lane keeping, better emergency response, and fewer awkward interventions.
Another benefit is comfort. When perception is accurate, assist systems behave more smoothly. The driver feels less fatigue because the car handles small corrections more consistently. In EVs, this comfort benefit is especially noticeable because power delivery is so immediate.
A third benefit is energy and system efficiency. Well-tuned perception can reduce unnecessary braking, avoid overreaction, and support smarter lighting or wiping decisions. That may sound minor, but at fleet scale it affects efficiency, component wear, and service intervals.
Where the limits still are
Dynamic driving perception is powerful, but it is not perfect. Heavy rain, snow, glare, fog, mud, and sensor contamination can reduce accuracy quickly. Even advanced fusion systems struggle when multiple cues become unreliable at the same time.
Mechanical factors also matter. Tire condition, wheel balance, suspension behavior, and body vibration can all distort sensing and interpretation. In other words, perception quality is not only a software problem. It is a vehicle-level integration problem.
There are also policy and validation limits. A system that works well in one market may need recalibration for another, due to road markings, lighting rules, or traffic patterns. This is why technical evaluation should include region-specific testing, not only controlled track runs.
How technical reviewers should evaluate it
- Check detection latency under changing speed, lighting, and weather.
- Compare false positives and missed detections across road surfaces.
- Review fusion stability when one sensor is partially degraded.
- Test interaction with tires, suspension, headlights, and body electronics.
- Validate behavior under compliance cases and regional driving patterns.
These checks help separate a polished demo from a dependable product. They also reveal whether dynamic driving perception is truly integrated or just layered on top of disconnected components.
What matters next
The next stage is not simply adding more sensors. It is improving how perception works with the rest of the vehicle. Better optical design, lighter wheels, quieter tires, smarter headlights, and cleaner signal logic all strengthen the same outcome.
For technical teams, the practical takeaway is simple. Measure dynamic driving perception as a system, not a feature. Look at response quality, edge-case behavior, and component interaction. That approach gives a clearer view of real-world value.
If the goal is safer, smoother, and more efficient driving, dynamic driving perception should be assessed alongside the vehicle’s exterior and vision architecture. That is where the strongest gains usually appear, and where the hidden limits are easiest to spot.