
Industry Portal
Related News
- 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions - 00
0000-00
Private Label Tire Export: Evaluating Suppliers, Compliance, and Landed Cost - 00
0000-00
DOT-Compliant Truck Lighting: A Practical Guide to FMVSS 108 Requirements
What optical matrix algorithms change in night driving
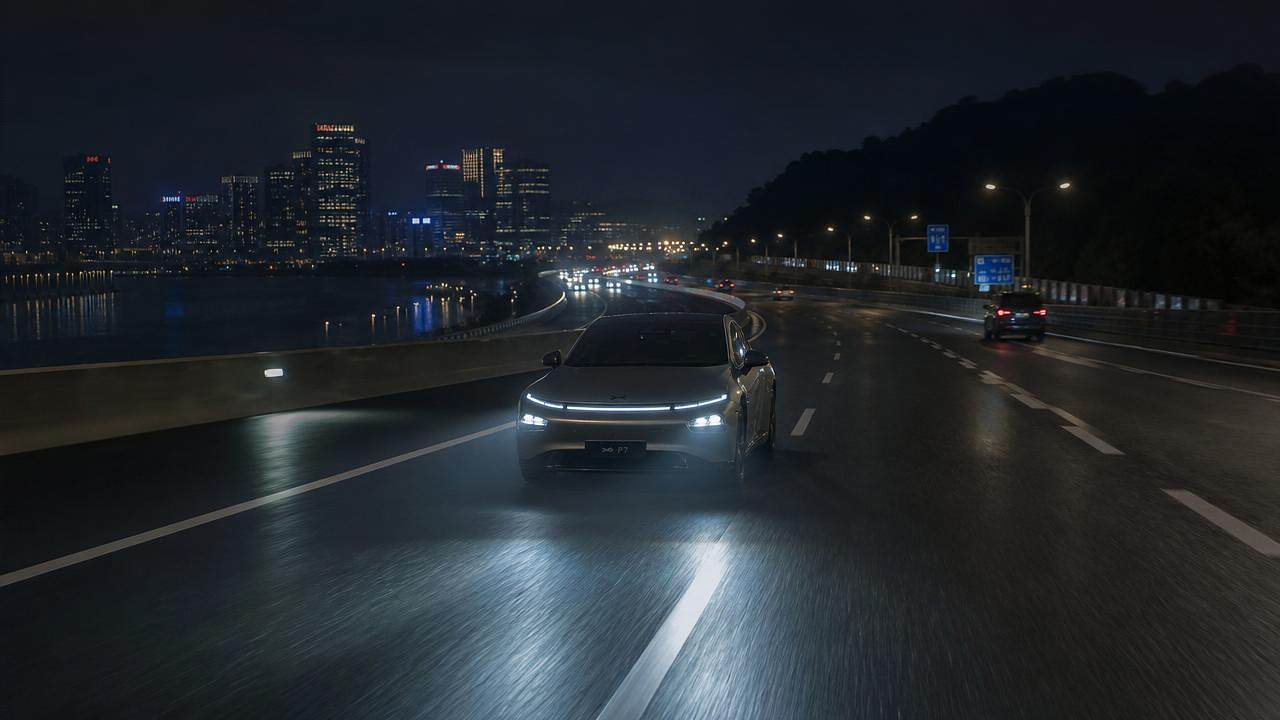
Night driving is no longer changed only by brighter lamps. It is changed by optical matrix algorithms that decide where light should go, where it should not go, and how fast the beam should react to a moving road scene.
For information researchers, the key point is simple: these algorithms transform headlights from fixed hardware into adaptive vision systems. They improve visibility, reduce glare, support driver confidence, and increasingly connect lighting with sensing, compliance, and intelligent vehicle design.
What people really want to know about optical matrix algorithms in night driving
When someone searches for optical matrix algorithms in night driving, they usually do not want a purely academic definition. They want to know what actually changes on the road, why it matters, and whether the technology delivers measurable safety and usability benefits.
The most relevant answer is that optical matrix algorithms make night driving more selective, contextual, and dynamic. Instead of illuminating everything with one uniform beam, the system shapes light around traffic, road edges, weather effects, speed, steering input, and navigation context.
This means drivers can keep more useful forward illumination without constantly dazzling oncoming vehicles. It also means headlights increasingly act as a real-time decision layer within the vehicle’s broader exterior and perception architecture.
From static headlamps to adaptive light control
Traditional low beam and high beam systems work as fixed modes. Even with automatic high beam, the logic is comparatively simple: detect another vehicle and switch between two preset distributions. That model improves convenience, but it does not fully optimize what the driver sees.
Optical matrix algorithms change that by controlling many individual light elements, sometimes dozens, hundreds, or even more, depending on the headlamp architecture. Each element can be dimmed, activated, or suppressed according to a calculated lighting pattern.
The result is adaptive driving beam behavior. A car can maintain strong illumination in dark road areas while creating shaded zones around detected vehicles. Instead of an all-on or all-off high beam, the system delivers a shaped beam with selective masking.
This is the real shift in night driving: the headlamp becomes computational. Optical performance is no longer determined only by lens design, reflector geometry, or LED power. It is increasingly determined by algorithm quality, update speed, and scene interpretation accuracy.
What changes for the driver on real roads
For drivers, the most immediate change is better forward visibility without the usual penalty of excessive glare. On a dark highway, a matrix system can preserve long-range illumination in open zones while reducing light intensity around oncoming traffic.
That creates a practical improvement in visual comfort. Drivers can see lane boundaries, roadside hazards, curves, and distant objects sooner, while other road users experience less discomfort. In many cases, the benefit is not dramatic brightness but smarter distribution.
Another important change is reduced workload. Drivers do not need to keep manually switching beams as often, especially on mixed roads where opposing traffic appears intermittently. The algorithm handles transitions with much finer control than a human toggle action.
Night driving also becomes more stable in complex scenarios such as multilane roads, urban-rural transitions, or roads with reflective signs. The system can adapt the beam pattern to avoid overwhelming the driver with backscatter or excessive foreground brightness.
In advanced implementations, the driver also gains contextual support. Some systems widen light in low-speed corners, extend reach at higher speeds, or coordinate with navigation data to pre-shape light for an upcoming curve or intersection.
How anti-glare masking actually works
Anti-glare masking is one of the most discussed functions because it best explains the value of optical matrix algorithms. The system identifies the position of other road users and creates darker zones within the broader beam to prevent direct dazzling.
That sounds straightforward, but in practice it requires several coordinated steps. The vehicle must detect relevant objects, estimate their position and motion, translate that into optical coordinates, and command the light modules with minimal latency.
The algorithm must also avoid over-masking. If the shadow region is too large, useful road illumination is sacrificed. If it is too small or too slow, glare leakage can occur. Good optical matrix algorithms therefore balance safety, visibility, and comfort at the same time.
This balance depends on sensor fusion and calibration quality. A camera may detect headlights and taillights, but the lighting controller must still map those detections accurately into the projected beam field. Even small errors can affect real-world performance.
For researchers, this is where differentiation happens. Many systems claim adaptive anti-glare capability, but not all perform equally in crowded traffic, on uneven roads, or during rapid relative motion such as overtaking and merging.
Why the algorithm matters as much as the headlamp hardware
It is easy to focus on headlamp hardware such as LED count, micro-mirror devices, or pixel resolution. Those matter, but they do not tell the whole story. High-resolution hardware without strong optical matrix algorithms may underperform in actual traffic conditions.
The algorithm decides segmentation strategy, transition smoothness, brightness prioritization, and scene response logic. It determines whether the beam changes feel precise and natural or late and distracting. In other words, software quality defines usable intelligence.
This is especially important in premium and next-generation NEV platforms, where headlamps are expected to support both aesthetics and function. A visually advanced lamp signature may attract attention, but the algorithm is what turns it into a high-value safety system.
Thermal limits and energy efficiency also depend on control logic. The system may need to manage luminous output intelligently under different ambient conditions, vehicle speeds, or electrical loads. Better algorithms can preserve effectiveness while avoiding unnecessary power use.
For manufacturers and suppliers, this means competitive advantage is moving beyond optics packaging into integrated optical-software performance. Evaluation should therefore include beam behavior, reaction consistency, and edge-case handling, not just specification sheets.
Where night driving benefits are strongest
Optical matrix algorithms are most valuable in scenarios where conventional headlighting forces a compromise between visibility and glare control. High-speed rural roads are a classic example because drivers need longer sight distance but face intermittent opposing traffic.
They are also highly useful on roads with mixed traffic density. In such environments, the ability to preserve light between vehicles or around road geometry creates a meaningful advantage over standard automatic high beam systems.
Curved roads present another strong use case. When combined with steering angle, yaw rate, speed data, and sometimes map input, the beam can shift toward the path of travel. This improves preview visibility and helps the driver read the road earlier.
Bad weather is more complicated. Matrix systems cannot eliminate all visibility loss in rain, fog, or snow, but well-designed algorithms can reduce some self-defeating light distribution patterns, especially excessive foreground intensity or sign reflection overload.
Urban settings can also benefit, though differently. Here the goal may be less about maximum distance and more about refined shaping around pedestrians, cyclists, intersections, parked vehicles, and reflective surfaces that can create visual clutter.
What limits performance in the real world
Although the technology is impressive, it is not magic. Performance depends on sensor quality, calibration accuracy, computing speed, weather robustness, and regulatory operating boundaries. If any of these factors is weak, the night-driving benefit may be reduced.
Sensor occlusion is one example. Dirt, rain, snow, or lens contamination can affect object detection. If the system cannot reliably identify another road user, anti-glare masking performance may become conservative or inconsistent.
Road topology is another challenge. Hills, dips, barriers, and sharp elevation changes complicate beam placement. A system may technically detect a vehicle but still need highly refined prediction logic to avoid glare on irregular terrain.
There is also the question of driver perception. Very frequent beam adjustments can become noticeable if transitions are not smooth. Strong systems minimize visible flicker, abrupt changes, or distracting edge artifacts in the illuminated field.
Finally, regulations matter. Optical matrix algorithms operate within legal frameworks such as ECE or DOT requirements, and market differences can affect which functions are enabled, how they are tuned, and how quickly advanced capabilities scale globally.
How this technology fits into intelligent exterior systems
For AEVS-style industry analysis, optical matrix algorithms should not be viewed in isolation. They are part of a broader intelligent exterior ecosystem that includes sensors, body electronics, thermal management, styling, power efficiency, and compliance engineering.
Headlights now sit at the intersection of visibility, perception, and brand identity. The same lamp assembly may need to deliver signature design, aerodynamic packaging, efficient thermal behavior, anti-glare driving beam, and interaction-ready projection functions.
This convergence is especially relevant for NEVs. Electric platforms are highly sensitive to energy management, software-defined features, and premium user experience. A smart lighting system therefore contributes not only to safety, but also to perceived vehicle intelligence.
Auto sensor switches and perception hardware further reinforce this trend. As lighting systems rely more on camera and sensing input, the boundary between exterior lighting and environmental perception becomes less rigid than in legacy vehicle architectures.
That is why optical matrix algorithms are becoming strategic rather than merely functional. They influence product differentiation, regional homologation planning, supplier positioning, and the future direction of software-defined exterior systems.
What information researchers should compare when evaluating solutions
For readers researching suppliers, technologies, or industry direction, the most useful comparison point is not a generic claim such as adaptive lighting. It is the actual operating capability of the optical matrix algorithms under varied traffic and road conditions.
Start with beam resolution, but do not stop there. Ask how quickly the system updates, how precisely it masks moving vehicles, how it handles multilane traffic, and whether it balances foreground and distance illumination intelligently.
Look at sensor dependencies and fallback behavior. Does performance rely on one camera type only, or can the system integrate other vehicle data? What happens if detection confidence drops due to weather or contamination?
It is also worth examining calibration and manufacturing consistency. An excellent algorithm on paper can lose value if vehicle-to-vehicle optical alignment varies too much. Integration quality across the full lamp and control stack remains essential.
Researchers should also track regulatory adaptability. Suppliers that understand both ECE and DOT environments, and can evolve functions across markets, often hold a more durable strategic position than those optimized for a single regulatory case.
Finally, assess future expandability. The strongest platforms are not built only for today’s anti-glare beam control. They are designed to support higher pixel density, road guidance projection, vehicle-to-environment communication, and software upgrades over time.
The broader significance for night driving innovation
What optical matrix algorithms change in night driving is not just where the light lands. They change the role of the headlamp itself. Lighting becomes adaptive, situational, and increasingly integrated with perception and software intelligence.
That matters because night driving has always involved trade-offs between seeing farther and protecting others from glare. Optical matrix algorithms reduce that trade-off by making illumination selective rather than uniform.
For the automotive industry, this shift supports a larger move toward intelligent exteriors that do more than cover the vehicle body. They sense, calculate, respond, and communicate. Headlights are becoming one of the clearest examples of that transition.
For information researchers, the practical takeaway is equally clear: when evaluating modern lighting innovation, focus less on raw brightness and more on control intelligence. In the next phase of vehicle vision systems, algorithm quality is the real performance multiplier.
Conclusion
Optical matrix algorithms change night driving by turning headlights into responsive lighting systems that adapt to traffic, road geometry, and environmental conditions in real time. Their core value lies in improving visibility while reducing glare and driver workload.
The technology matters most when hardware, sensing, and control logic work together well. For anyone studying automotive vision trends, the key insight is that advanced night-driving performance now depends as much on software and system integration as on the lamp itself.
As vehicle exterior intelligence continues to evolve, optical matrix algorithms will play a central role in how cars illuminate the road, support safety, and express the next generation of smart mobility capability.