
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
Tags
TÜV Rheinland Updates Matrix LED Beam Algorithm White Paper
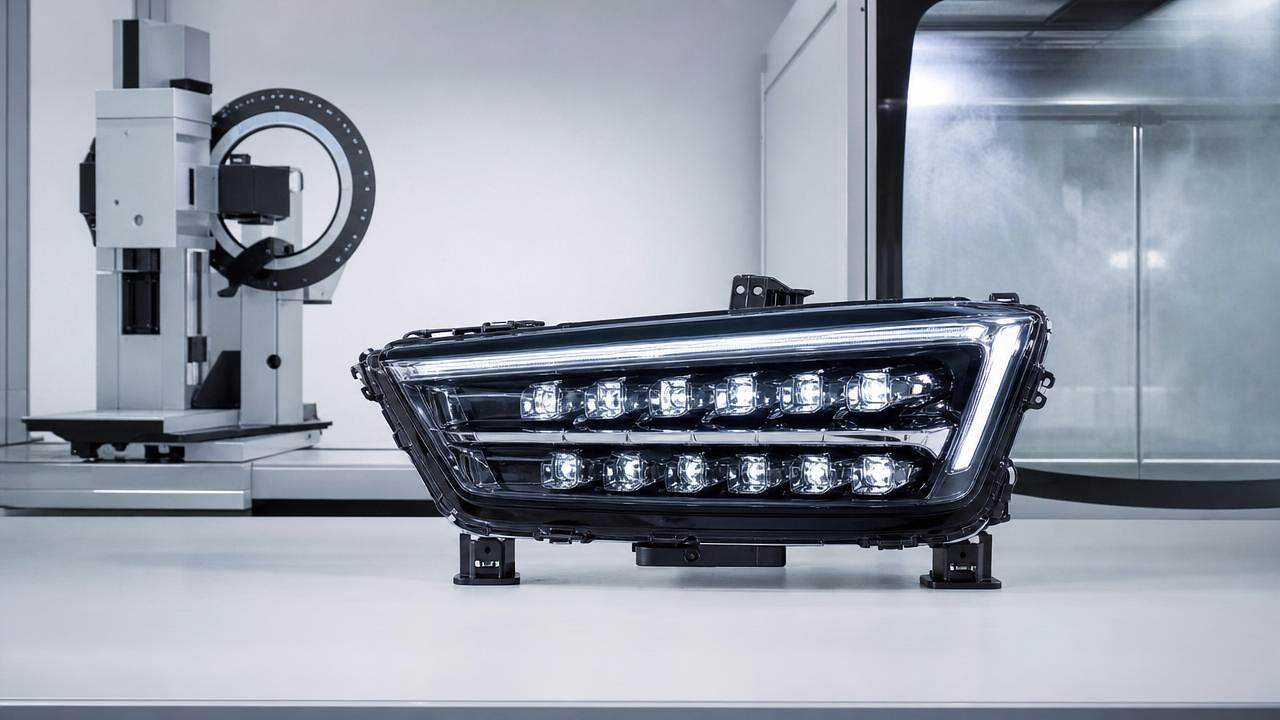
On May 18, 2026, TÜV Rheinland released the updated Matrix LED Adaptive Driving Beam Algorithm Guidelines V3.2, introducing four new mandatory technical specifications—including pixel-level projection angular tolerance (±0.15°) and dynamic masking response latency under rain/fog conditions (≤80 ms). This update directly impacts automotive lighting suppliers, ADAS system integrators, and Tier 1 OEM partners engaged in European vehicle certification and homologation processes.
Event Overview
On May 18, 2026, TÜV Rheinland published Version 3.2 of its Matrix LED Adaptive Driving Beam Algorithm Guidelines. The revision adds four hard technical requirements: (1) million-pixel projection angular tolerance of ±0.15°; (2) dynamic masking response latency ≤80 ms under simulated rain and fog conditions; (3) real-time beam segmentation continuity verification; and (4) minimum inter-beam transition smoothness threshold (CIEDE2000 ΔE ≤ 2.3). Concurrently, leading Chinese headlamp manufacturers reported an average algorithm calibration and on-vehicle validation cycle of eight weeks for compliance—down from eleven weeks in 2025.
Impact on Specific Industry Segments
Automotive Lighting Component Manufacturers
These firms are directly responsible for implementing the updated beam control algorithms into ECU firmware and optical hardware. The tightened angular tolerance and latency requirements increase validation complexity—especially for near-field projection accuracy and low-visibility scenario responsiveness. Impact manifests in extended internal test cycles, higher reliance on high-fidelity simulation tools, and increased dependency on TÜV’s pre-assessment services.
ADAS System Integrators
Integrators embedding matrix LED functionality into broader ADAS stacks must now align camera-based object detection latency, CAN FD timing budgets, and beam actuation logic with the new ≤80 ms masking response benchmark. This affects integration test planning, middleware timing validation protocols, and cross-supplier interface documentation (e.g., AUTOSAR-compliant signal definitions).
OEM Supplier Technical Liaison Teams
Teams managing technical alignment between Chinese Tier 2 suppliers and European OEMs face compressed feedback loops. The reduced 8-week validation window implies tighter coordination cadence across functional safety (ISO 26262 ASIL-B), photometric compliance (UNECE R149), and software update workflows (OTA readiness for beam algorithm patches).
What Relevant Enterprises or Practitioners Should Focus On and How to Respond
Monitor official TÜV implementation bulletins and regional interpretation notes
TÜV Rheinland has not yet published region-specific application notes for China-market homologation pathways under V3.2. Enterprises should track TÜV’s quarterly technical webinars and registered notifications—particularly regarding whether the ≤80 ms latency requirement applies to end-to-end system latency (camera-to-actuator) or only to the beam controller’s internal decision loop.
Prioritize validation resources on rain/fog masking edge cases and projection repeatability testing
Based on the new metrics, laboratories should allocate additional test runs using calibrated fog chambers (SAE J2711 Class B equivalent) and multi-axis goniophotometers capable of sub-0.1° angular resolution. Emphasis should shift from static photometric compliance to dynamic scene transition fidelity.
Distinguish between certification readiness signals and production deployment timelines
The 8-week validation cycle reflects current best practice among top-tier Chinese suppliers—not a guaranteed lead time across all vendors. Enterprises should treat this as a benchmark for supplier qualification, not a contractual SLA. Internal procurement and project planning should maintain buffer windows for first-time V3.2 submissions.
Pre-align internal firmware architecture with TÜV’s updated algorithm audit checklist
TÜV’s V3.2 release includes a revised software audit annex requiring traceable mapping between object classification confidence scores and corresponding beam mask coordinates. Teams should review existing algorithm logging structures and ensure timestamped, lossless capture of raw camera frames, inference outputs, and final beam coordinate sets for audit submission.
Editorial Perspective / Industry Observation
Observably, this update signals a shift from functional capability demonstration toward deterministic, real-time photometric behavior under adverse conditions. Analysis shows the ≤80 ms latency target is aligned with human visual reaction thresholds for glare avoidance—suggesting TÜV is tightening alignment between regulatory compliance and perceptual safety outcomes. From an industry perspective, the accelerated 8-week adaptation cycle in China reflects maturing local expertise in adaptive beam control, but does not yet indicate full parity in embedded AI validation infrastructure versus EU-based peers. Current evidence supports interpreting V3.2 less as an immediate compliance deadline and more as a forward-looking technical benchmark influencing next-generation platform development roadmaps—particularly for L2+ ADAS architectures integrating projection-based driver assistance (e.g., lane marking augmentation, hazard highlighting).
This update underscores a structural evolution: regulatory guidance is increasingly specifying performance *dynamics*, not just static output limits. For stakeholders, it reinforces that photometric compliance is no longer separable from real-time perception-action latency and environmental adaptability. The 8-week validation timeline highlights operational progress—but the underlying technical bar has risen meaningfully. It is more accurate to view this as an inflection point in adaptive lighting system maturity than as a standalone compliance milestone.
Source Attribution
Main source: TÜV Rheinland official press release and white paper version history (V3.2, dated May 18, 2026). Note: Regional implementation guidance for China GB standards and OEM-specific interpretation of the ≤80 ms latency clause remain pending and require ongoing monitoring.