
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
Matrix Projection in Headlamps: Where It Fits and What to Check Before Adoption
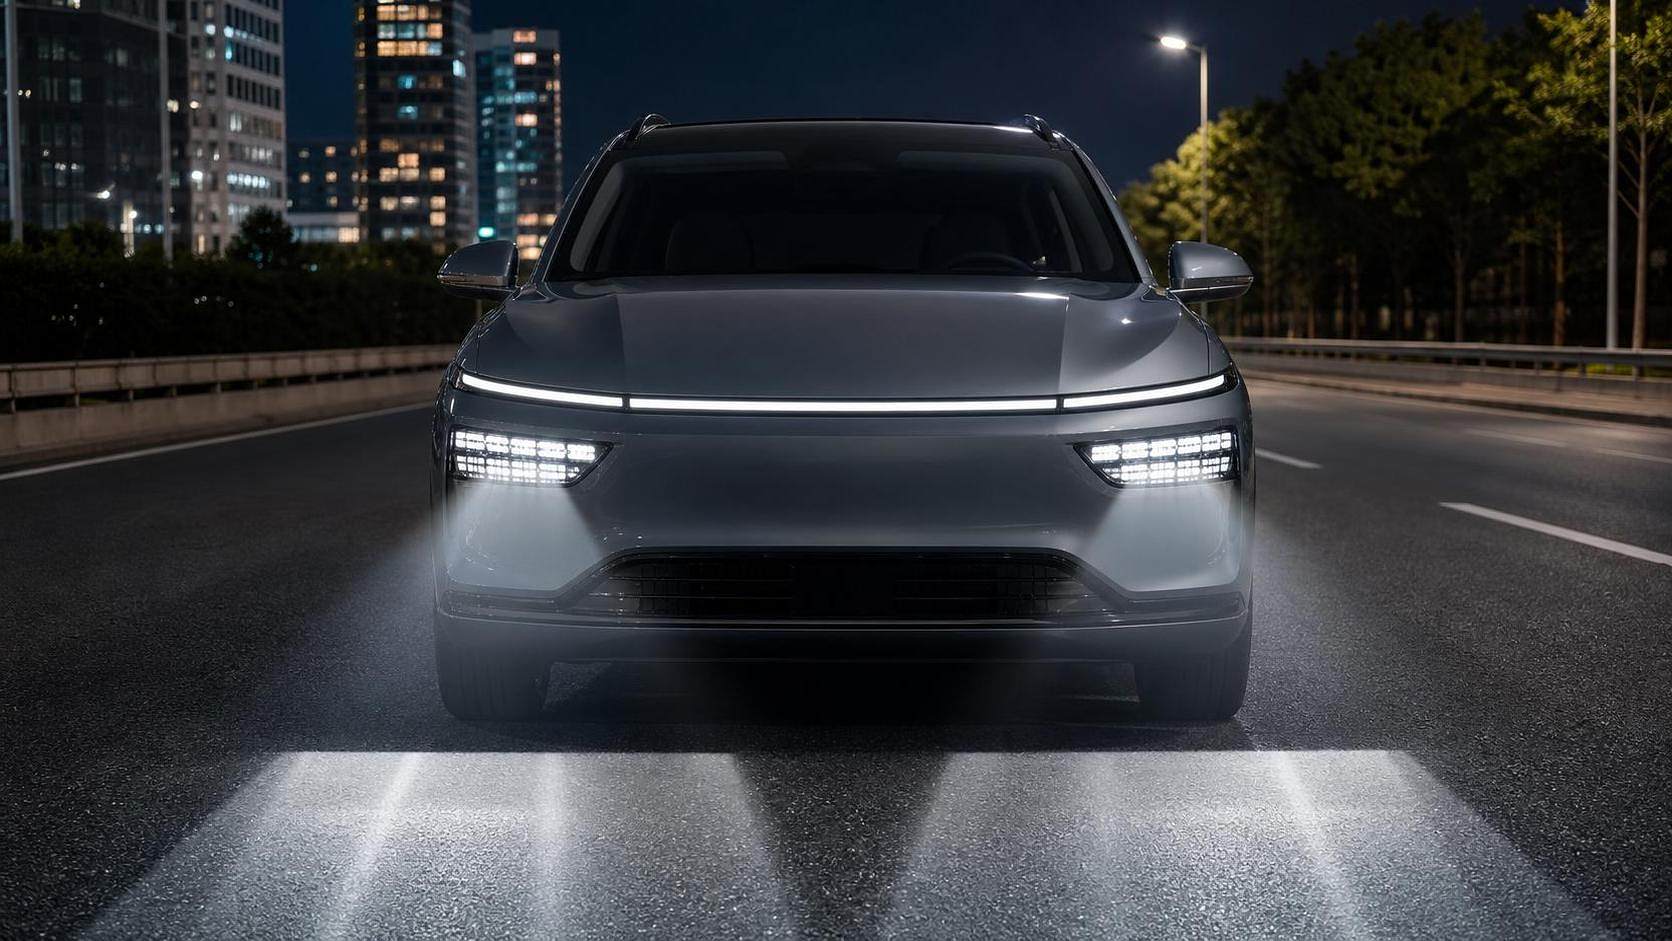
Matrix Projection in Headlamps: Where It Fits in Real Use
Matrix projection is moving headlamps beyond simple forward lighting. In many vehicle programs, the real question is not whether the technology looks advanced, but whether it fits the driving environment, the electrical architecture, and the compliance target. When those conditions align, matrix projection can improve visibility, reduce glare risk, and support a more refined driving experience.
That is why adoption decisions usually start with use context. Urban commuting, expressway travel, premium EV styling, and mixed-weather operation all place different demands on matrix projection in headlamps. A system that works well in one profile may feel oversized, fragile, or inefficient in another.
Why Different Driving Scenarios Change the Requirement
Matrix projection is most valuable when the headlamp must do more than illuminate a lane. In dense traffic, it has to segment light precisely and protect oncoming drivers from glare. On open roads, it may need to extend reach and improve contrast around lane edges, pedestrians, or roadside markers. In both cases, the value comes from adaptive control, not raw brightness alone.
For AEVS-style exterior intelligence analysis, this also connects with vehicle aesthetics and system integration. LED headlight assemblies are no longer isolated parts. They interact with sensors, thermal paths, body styling, and even energy management strategy. Matrix projection becomes attractive only when those layers are designed together.
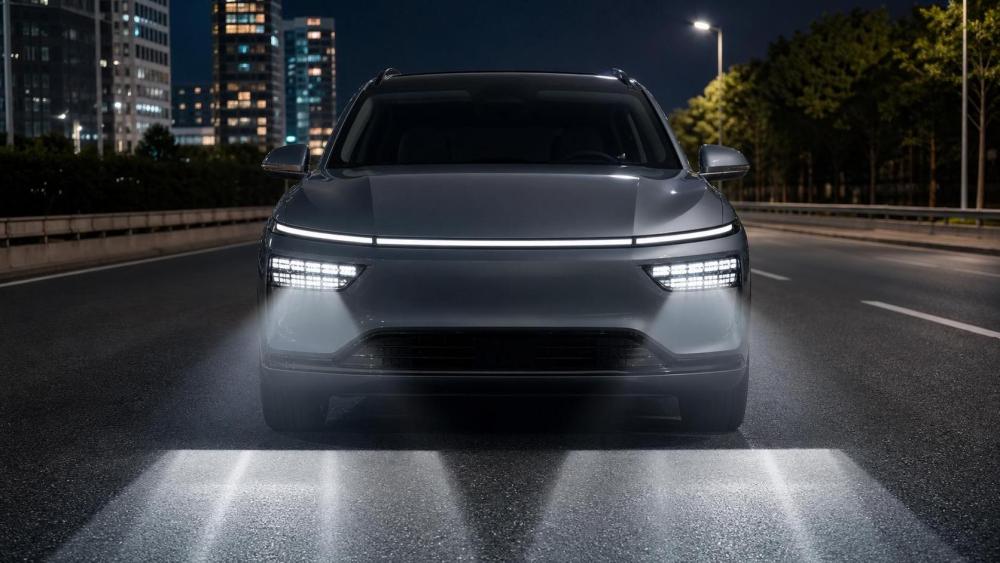
Urban traffic usually prioritizes glare control
In city driving, matrix projection is often judged by how smoothly it masks surrounding vehicles, cyclists, and pedestrians. The headlamp must switch patterns quickly without creating visible jumps or distracting flicker. If the optical segmentation is coarse, the system may look advanced on paper but feel inconsistent in real traffic.
This is where camera calibration and sensor latency matter. If the vehicle detects objects too late, the light distribution cannot react in time. A good urban setup needs stable perception, fast computation, and careful validation under rain, reflective road signs, and uneven street lighting.
Highway use favors reach and lane guidance
At higher speed, the priority shifts. Matrix projection should extend useful illumination farther ahead while keeping contrast strong near lane edges and merge points. Here, the question is less about masking and more about whether the beam pattern improves reaction time without wasting energy.
Thermal management becomes more visible in this scenario. Longer active periods mean the optical module, driver electronics, and housing must hold performance without color shift or degradation. In NEV platforms, this also affects overall energy efficiency and the vehicle’s lighting strategy across long-distance use.
What to Check Before Matrix Projection Adoption
Before adoption, the safest approach is to evaluate fit in layers. A matrix projection system can be impressive in demos and still fail in production if the architecture is not ready. The most common issues come from mismatched thermal limits, weak optical packaging, or software that is not tuned to local regulations.
A practical program usually checks these items together. Focusing only on luminous performance can hide problems in integration, cost, or legal acceptance. In AEVS terms, that is the difference between a promising optical concept and a viable LED headlight assembly strategy.
Compliance and regional use are not the same thing
One frequent mistake is to assume that one successful market test proves global readiness. Matrix projection often needs different approval logic across regions, especially when adaptive masking behavior or road projection functions vary. A system tuned for one compliance path may need calibration changes before it can be released elsewhere.
That is why regulatory review should happen early, not after styling freeze. The optical team, software team, and homologation path need to move together. Otherwise, the project can lose time even when the hardware itself is strong.
How matrix projection fits with vehicle architecture
Matrix projection is easiest to justify when the vehicle already supports a smart lighting stack. If the platform includes front cameras, ambient sensing, and a stable electrical supply, the headlamp can deliver more value with less compromise. If the architecture is basic, the technology may still work, but cost and complexity rise quickly.
This is especially relevant for NEV programs, where exterior design, energy use, and thermal packaging are tightly connected. The headlamp cannot be treated as a standalone feature. It must fit the front-end cooling layout, the styling language, and the software logic that governs the broader smart vehicle experience.
- If the vehicle targets premium positioning, matrix projection can strengthen perceived value.
- If the duty cycle is long, thermal stability becomes a primary gate.
- If regional deployment is broad, compliance planning should start early.
- If the electrical budget is tight, simpler adaptive lighting may be more balanced.
The key is not choosing the most advanced light pattern. It is choosing the setup that matches the vehicle’s real operating envelope.
Common misreads when evaluating matrix projection
A common misread is treating matrix projection as a styling upgrade only. It does influence brand perception, but its real role is operational: safer illumination, more adaptive visibility, and a more controlled light environment. If those gains are not measurable in the target use case, the added complexity may not pay back.
Another mistake is comparing systems only by pixel count or headline brightness. Those numbers matter, but they do not tell the full story. Optical efficiency, scene logic, thermal behavior, and serviceability often decide whether the headlamp remains stable over time.
A final blind spot is maintenance planning. Advanced lighting systems can be sensitive to lens contamination, calibration drift, and software updates. If the support model is weak, the field result may fall far short of the lab result.
A practical way to move forward
The best next step is to define the driving scenes that matter most, then test matrix projection against those scenes rather than against a generic benchmark. Urban masking, highway reach, weather robustness, and regional compliance should be scored separately. That produces a clearer decision than a single pass-fail result.
For teams tracking exterior and vision trends through AEVS-style intelligence, matrix projection is most interesting when it supports a broader system story: safer perception, smarter control, and cleaner integration with the vehicle’s front-end architecture. When those conditions are present, it can become a meaningful headlamp upgrade instead of just another feature line.
Before adoption, confirm scene priorities, thermal headroom, compliance scope, and software maturity. If those four points hold together, matrix projection is far more likely to deliver durable value in next-generation headlamps.