
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
How optical matrix algorithms improve beam accuracy
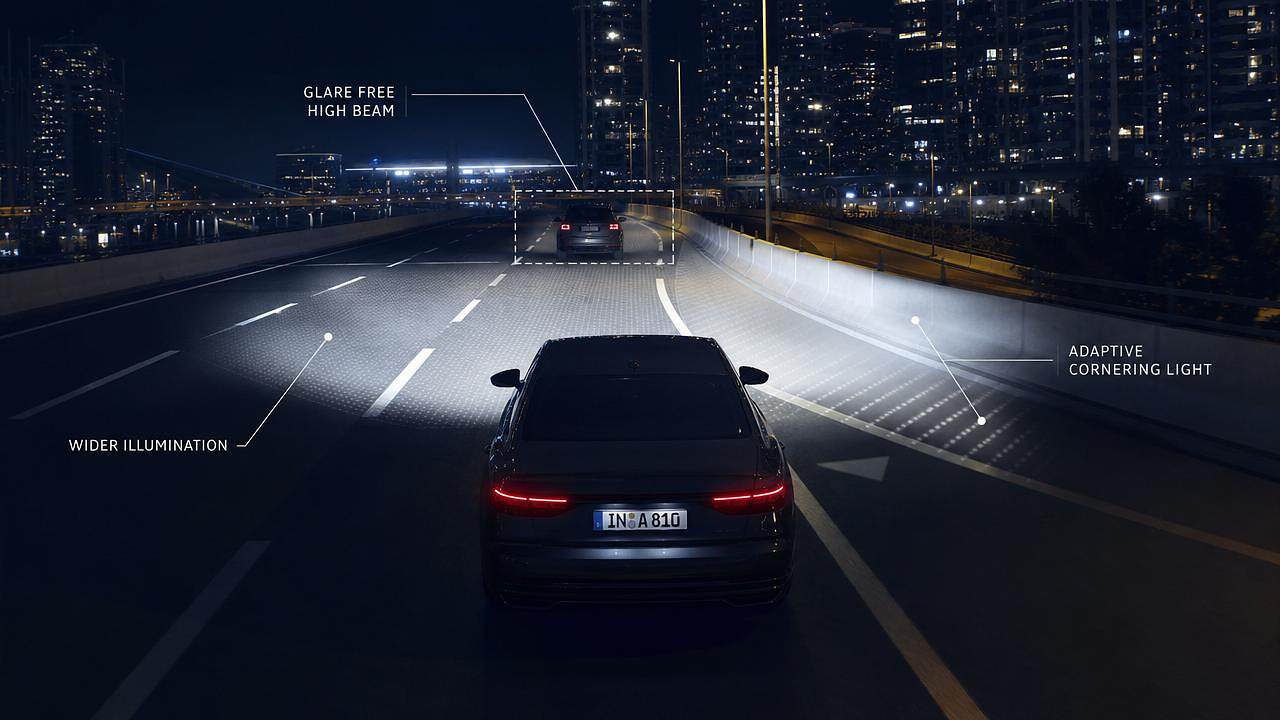
For technical evaluators assessing next-generation vehicle lighting and perception systems, the key question is not whether optical matrix algorithms matter, but how much measurable beam accuracy they can deliver under real driving conditions. In advanced matrix LED headlight assemblies, these algorithms directly influence illumination precision, glare suppression, adaptive range, and system stability across varying speeds, weather, traffic, and road geometry.
The overall judgment is clear: optical matrix algorithms improve beam accuracy when they can convert sensor inputs, optical models, and regulatory constraints into fast, reliable light distribution decisions. Their value is greatest when evaluators look beyond headline features and examine resolution control, latency, calibration robustness, thermal drift compensation, and compliance performance. For automotive exterior and vision systems, algorithm quality is often the difference between impressive lab output and dependable on-road beam behavior.
What technical evaluators are really trying to verify
When users search for information on optical matrix algorithms, their core intent is usually practical rather than academic. They want to understand how these algorithms improve beam placement, edge definition, dark-zone masking, and adaptive coverage in ways that can be tested and compared.
For technical evaluators, the concern is rarely the algorithm in isolation. It is whether the full system can maintain beam accuracy across component tolerances, vibration, temperature variation, dirty lenses, road curvature, and moving traffic scenarios without creating glare or unstable transitions.
This means the evaluation focus should center on decision quality under dynamic conditions. A high-resolution light source alone does not guarantee accurate illumination. The algorithm must decide which pixels, segments, or matrix zones to activate, dim, or suppress at the right time and with the right intensity.
In practical procurement or validation work, the most useful content is not abstract discussion about intelligence. Evaluators need performance criteria, failure modes, integration dependencies, and methods for determining whether an optical matrix solution is mature enough for premium vehicle programs.
How optical matrix algorithms actually improve beam accuracy
At a system level, optical matrix algorithms improve beam accuracy by translating scene information into controlled light distribution. They determine where light should go, where it should be reduced, and how the beam should adapt as the environment changes from one moment to the next.
In a matrix LED headlight, the algorithm controls multiple light-emitting elements independently or in grouped zones. That allows the beam to be shaped with far greater precision than a static low-beam or high-beam architecture. Accuracy improves because illumination is no longer fixed.
The first major gain comes from spatial selectivity. Instead of flooding the road with uniform light, the system can direct illumination to lanes, shoulders, signs, or curve entry points while shielding oncoming drivers and preceding vehicles from excessive exposure.
The second gain comes from dynamic responsiveness. Algorithms can update beam distribution based on steering angle, vehicle speed, yaw rate, pitch movement, ambient light, and camera-detected traffic. Beam placement becomes a continuous control process rather than a fixed optical compromise.
The third gain comes from compensation capability. Real-world beam accuracy is affected by load changes, suspension motion, lens contamination, manufacturing deviation, and thermal behavior. Advanced algorithms can partially compensate for these disturbances through feedback and predictive control logic.
For evaluators, this is the core point: optical matrix algorithms improve beam accuracy not simply by adding complexity, but by reducing the mismatch between the intended illumination pattern and the actual driving context.
Which algorithm functions have the greatest impact on real-world precision
Not every algorithm function contributes equally to beam accuracy. Some features are attractive in product brochures but have limited value unless the core control stack is already robust. Technical evaluation should prioritize the functions that most directly affect precision and repeatability.
One critical function is object-level glare masking. The system must identify vehicles, estimate their position accurately, predict relative motion, and carve out dark zones without over-masking useful road illumination. Poor masking logic either causes glare risk or reduces driver visibility.
Another high-value function is predictive curve lighting. By combining steering input, navigation data, and road-shape inference, the algorithm can place light earlier into the driver’s future path. This improves useful beam reach in corners and reduces the delay seen in reactive-only systems.
Pixel or segment intensity modulation is also essential. Accuracy is not just about switching zones on and off. Smooth dimming control improves beam edge quality, transition comfort, and object contrast. It also reduces visible flicker or abrupt cut lines during adaptive changes.
Road-surface and environment classification has a major effect as well. Wet pavement, snow, fog, urban reflective clutter, and highway conditions all change how light should be distributed. Better classification logic allows more context-appropriate beam tuning and avoids over-illumination.
Calibration management is often underestimated. Even the best beam-shaping logic will underperform if emitter mapping, projector alignment, camera registration, and leveling references drift over time. Algorithms that monitor and correct calibration offset deliver more stable beam accuracy over vehicle life.
Why sensor fusion matters as much as optical computation
Beam accuracy depends on the quality of input data. Optical matrix algorithms can only make precise decisions if the surrounding perception stack supplies timely and trustworthy information. In modern automotive exterior systems, this usually means combining multiple sensing sources rather than relying on one alone.
Front cameras are central because they detect headlamps, taillamps, lane structure, roadside objects, and ambient conditions. However, camera-only systems can struggle with glare, low contrast, snow cover, and certain weather effects. Sensor fusion improves confidence and continuity.
Vehicle-state inputs are equally important. Steering angle, speed, suspension height, acceleration, yaw rate, and braking behavior all influence where the beam should be placed. Without these signals, adaptive beam control becomes less precise during transient maneuvers.
Photoelectric sensing, radar-assisted environment awareness, and map-based road prediction can further enhance algorithm performance. For example, navigation-linked preview can improve curve illumination before the camera has complete visibility of the road path.
For technical evaluators, the lesson is straightforward. If a supplier emphasizes advanced optical matrix algorithms but cannot demonstrate stable sensor fusion and signal integrity, claimed beam accuracy gains should be treated cautiously.
How to evaluate beam accuracy beyond nominal lumen and resolution claims
Many system presentations focus on emitter count, matrix resolution, or maximum luminous output. These metrics are relevant, but they do not by themselves prove superior beam accuracy. Evaluators should look at how effectively the algorithm uses available optical hardware.
A useful starting point is beam placement error under scenario variation. How closely does the illuminated region align with lane boundaries, curve apex areas, pedestrian zones, and traffic masking targets? Repeatability across speed and road conditions matters more than a single ideal test.
Transition behavior is another core metric. When the system detects an oncoming vehicle, how quickly and smoothly does it create the dark zone? If reaction is late, glare risk rises. If suppression is overly broad or unstable, useful forward visibility is lost.
Evaluators should also measure edge fidelity and contrast preservation. A precise beam is not only correctly aimed; it must preserve visibility where needed while maintaining clean exclusion around protected objects. This is where algorithm quality often separates premium systems from basic adaptive lighting.
Latency across the full chain is crucial. Sensor capture, perception processing, beam decision logic, driver electronics, and optical response all contribute to total update delay. A high-resolution matrix with poor latency can underperform a lower-resolution system with faster control.
Thermal robustness should be included in any serious validation plan. As LED junction temperatures rise, luminous output and optical behavior can shift. Strong optical matrix algorithms account for thermal effects and maintain acceptable beam accuracy even under sustained night driving loads.
Common failure modes that reduce algorithm-driven beam precision
Understanding failure modes is often more valuable than reviewing best-case demonstrations. In technical evaluation, the goal is to identify where beam accuracy breaks down and whether those breakdowns are manageable within the target vehicle platform and regulatory envelope.
One common issue is over-reliance on ideal camera visibility. Dirt, spray, road salt, lens fogging, and low-contrast scenes can degrade object detection quality. If the algorithm lacks robust fallback logic, beam behavior may become conservative, inconsistent, or unsafe.
Another problem is insufficient synchronization between sensors and actuation. Even small timing offsets between vehicle-state data, perception output, and headlamp control can lead to misplaced masking zones or lagging curve illumination during high-speed maneuvers.
Mechanical and optical tolerances also matter. Module alignment shifts, vibration, and long-term settling can introduce systematic beam deviation. If algorithm calibration is static or too coarse, real-world precision degrades despite strong laboratory optical performance.
Thermal derating can create subtler errors. If certain matrix zones lose intensity disproportionately, the beam may no longer match the intended pattern. Evaluators should verify whether the control software adapts distribution logic when thermal conditions alter output characteristics.
Finally, regulatory optimization can sometimes conflict with functional usefulness. A system tuned mainly to pass compliance scenarios may appear accurate in certification setups but perform less effectively on complex roads. Balanced evaluation must include both homologation and realistic night-driving cases.
What good performance looks like in matrix LED automotive applications
In automotive exterior and vision systems, strong performance is visible in the consistency of useful illumination. A capable optical matrix algorithm should provide longer effective seeing distance without increasing discomfort glare for other road users.
In highway driving, good algorithms maintain stable high-beam coverage while carving narrow, well-controlled exclusion zones around distant traffic. The driver keeps most of the long-range visibility benefit instead of dropping back to a heavily compromised beam pattern.
In urban environments, quality algorithms reduce unnecessary foreground brightness and manage reflections from signs, wet roads, and dense traffic. Beam accuracy here is less about range and more about contrast, visual comfort, and avoiding wasted light distribution.
On curved roads, the system should illuminate the road trajectory early and smoothly. The best solutions do not simply swing light with steering input. They coordinate speed, yaw behavior, road prediction, and optical distribution so that the beam leads the driver’s visual demand.
For vehicles integrating smart optical perception and advanced driver assistance features, beam accuracy can also support sensor performance indirectly. Better targeted illumination may improve camera scene quality in low-light conditions, although this must be validated carefully at the system level.
How compliance and safety requirements shape algorithm design
For technical evaluators, compliance is not a secondary issue. Optical matrix algorithms must operate within strict regional lighting regulations while still delivering useful adaptive behavior. This is especially important for global programs spanning ECE, DOT, and other market requirements.
Regulatory constraints shape beam envelope, glare limits, switching logic, and the conditions under which adaptive functions can be enabled. An algorithm may be technically impressive but commercially weak if it cannot be efficiently adapted across homologation regimes.
Safety evaluation should include fail-safe behavior. If perception confidence drops, communications are interrupted, or a matrix driver fault occurs, the system must revert to a legal and predictable beam state. Graceful degradation is a major sign of engineering maturity.
Documentation quality also matters. Evaluators often need traceability from performance claims to software logic, calibration procedures, validation scenarios, and update management processes. In safety-critical exterior systems, opaque algorithm behavior creates unnecessary program risk.
A practical framework for technical evaluation and supplier comparison
To compare solutions effectively, evaluators should use a framework that links algorithm sophistication to measurable system outcomes. The first dimension is optical control precision: masking accuracy, edge sharpness, intensity modulation quality, and coverage adaptability.
The second dimension is dynamic performance: update rate, end-to-end latency, behavior at speed, and stability during combined steering, pitch, and traffic events. A solution that looks precise in static demos may fail this category under realistic vehicle motion.
The third dimension is robustness: tolerance to dirt, weather, thermal load, component drift, and sensor degradation. Since automotive lighting systems operate for years in harsh environments, robustness often matters more than peak capability.
The fourth dimension is integration readiness. Evaluators should review software architecture, calibration workflow, diagnostics, interface demands, and compatibility with the vehicle’s broader sensor and body electronics network. Integration complexity can erode the practical value of a strong algorithm.
The fifth dimension is regulatory and lifecycle fit. This includes homologation flexibility, update governance, serviceability, and long-term maintenance of beam accuracy across manufacturing variation and field aging. A premium lighting system must be supportable, not just impressive.
Conclusion
Optical matrix algorithms improve beam accuracy by making automotive lighting responsive, selective, and context-aware. Their real advantage lies in turning sensor input and optical capability into precise, adaptive illumination that better matches the road, traffic, and vehicle state in real time.
For technical evaluators, the most important takeaway is that beam accuracy should be judged as a system outcome, not a feature label. Resolution, lumen output, and marketing claims matter less than masking precision, latency, calibration stability, thermal robustness, and compliance behavior.
In matrix LED headlight assemblies and related smart exterior systems, strong optical matrix algorithms can materially improve safety, driver visibility, and product differentiation. But that value is realized only when the full stack—from sensing to actuation—performs reliably under real operating conditions.
When assessing next-generation solutions, the best decision comes from asking a practical question: does the algorithm consistently put the right light in the right place, at the right time, without creating glare or instability? If the answer is demonstrably yes, beam accuracy improvement is real.