
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
How Smart Headlight Activation Works and Which Driving Scenarios Benefit Most
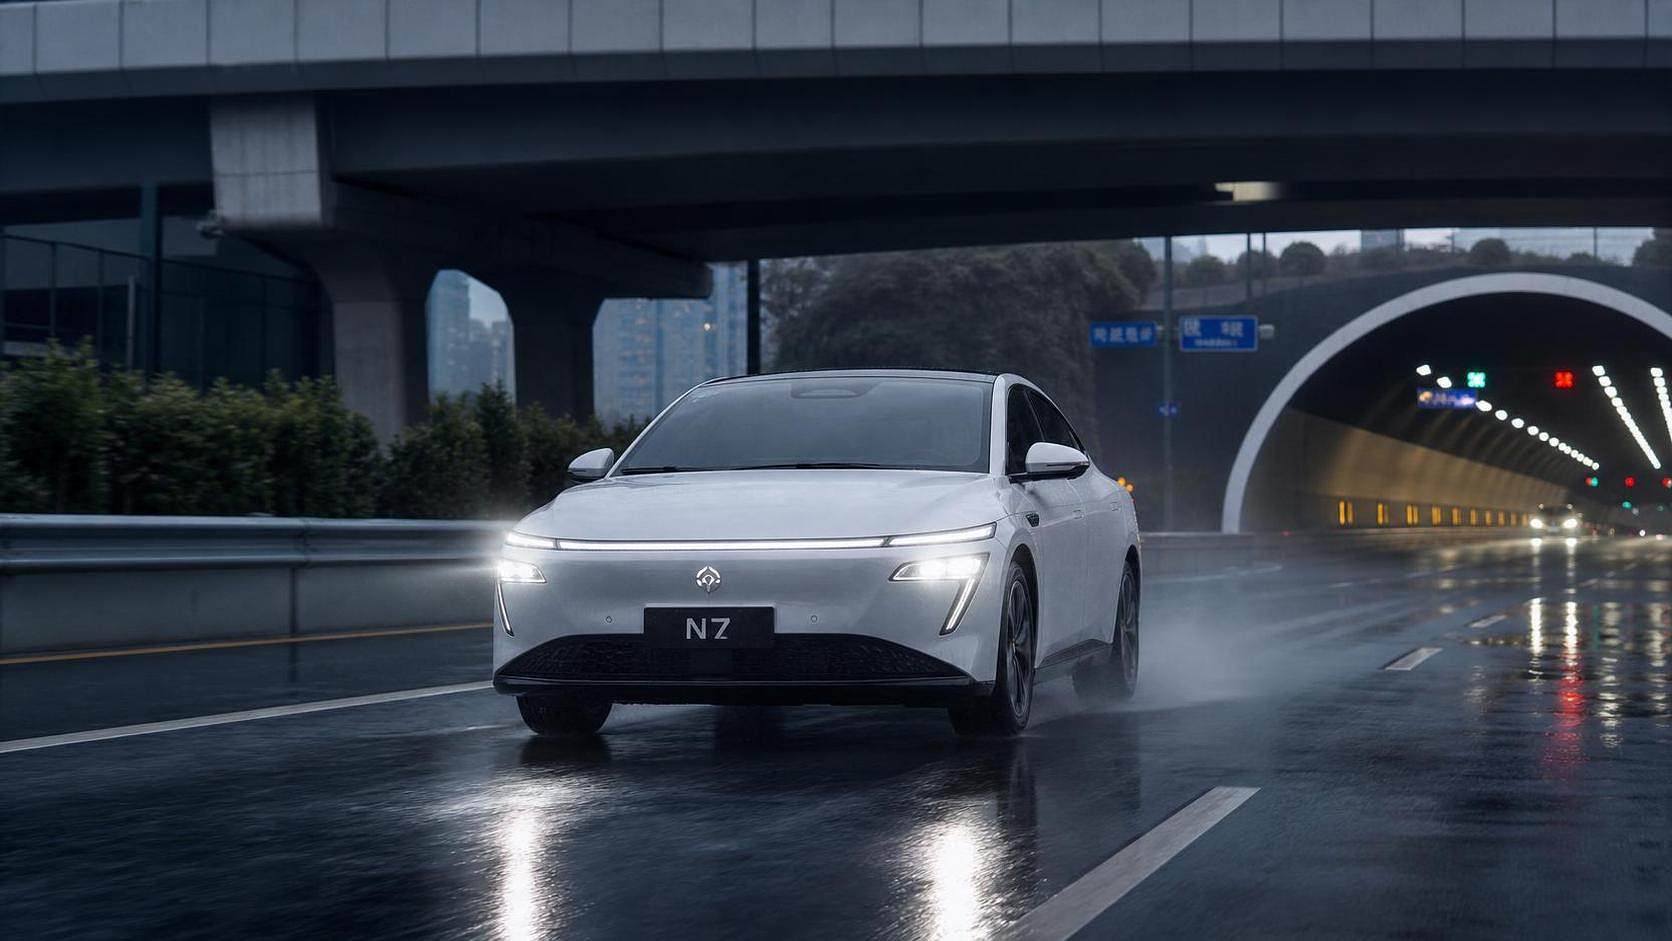
Smart headlight activation has moved well beyond a simple automatic on-off function. It now sits at the intersection of lighting safety, energy management, sensor fusion, and intelligent exterior design, especially as EV platforms demand more efficient use of every watt. In that context, understanding how the system works and where it creates the most value helps clarify why advanced lighting has become a strategic topic across the broader automotive exterior and vision ecosystem.
Why this function matters more now
A decade ago, automatic headlights were often treated as a comfort feature. Today, smart headlight activation supports road visibility, compliance, driver workload reduction, and the wider intelligence loop of the vehicle body network.
That shift is especially visible in new energy vehicles. Lighting systems now interact with range expectations, thermal limits, sensor packages, and software-defined functions rather than operating as isolated hardware.
From the perspective of AEVS, this makes headlights part of a larger exterior intelligence architecture. LED headlight assemblies, auto sensor switches, aerodynamic design, and road-contact systems increasingly influence each other in real driving conditions.
In practical terms, a headlight that activates at the right moment can improve recognition distance, reduce delayed driver reactions, and support smoother transitions between daylight and low-visibility environments.
What smart headlight activation actually means
At its core, smart headlight activation is an automated decision process. The system determines when headlights, daytime running lights, low beams, or adaptive lighting modes should change based on environmental and vehicle data.
The simplest versions rely mainly on ambient light sensors. More advanced versions combine sensor readings, camera input, wiper status, vehicle speed, steering angle, GPS context, and software rules.
This is why the term smart matters. The function is not just switching lamps on when it gets dark. It is interpreting driving context and triggering lighting responses earlier, more precisely, and with fewer false activations.
Typical inputs behind the decision
- Ambient light sensors measuring brightness changes outside the vehicle.
- Forward cameras detecting tunnels, glare, traffic, or lane surroundings.
- Rain sensors and wiper signals indicating weather-related visibility loss.
- Vehicle speed and steering data helping tune beam timing and direction.
- Body control modules applying logic, timing thresholds, and fail-safe responses.
In advanced vehicles, these inputs may also support adaptive beam shaping, anti-glare masking, or matrix lighting behavior. Smart headlight activation becomes the first step in a broader optical perception chain.
How the system works on the road
The operating logic usually follows a layered process. Sensors collect data continuously. Software filters short-term fluctuations. Then the control unit checks whether the conditions match a lighting threshold.
For example, driving under a bridge should not trigger the same response as entering a long tunnel. A robust system distinguishes temporary shadows from sustained low-light conditions.
The same principle applies in rain or fog. Brightness alone may not tell the full story, so the control strategy often considers wiper activity, camera visibility, and speed to decide whether low beams should activate.
Good calibration is critical. If activation happens too late, visibility benefits are lost. If it happens too early or too often, drivers may distrust the system and override it manually.
A simple process view
Driving scenarios where the value is highest
Not every driving environment creates the same need. The biggest advantage appears in situations where visibility changes quickly, or where delayed human response can compromise safety and comfort.
Tunnels, underpasses, and parking structures
These transitions happen fast and often catch drivers between full daylight and sudden darkness. Smart headlight activation helps maintain forward visibility without relying on a manual response after the environment has already changed.
Rain, spray, and fog-prone routes
Visibility loss in bad weather is not always linked to sunset. Road spray, reflective surfaces, and mist can reduce contrast well before ambient light falls. Systems linked to rain sensors and wipers are especially useful here.
Dawn, dusk, and winter low-sun conditions
These periods create inconsistent brightness and strong glare. A well-calibrated smart headlight activation strategy responds to reduced functional visibility, not just to a simple dark-versus-light threshold.
Rural and low-illumination roads
On roads with limited street lighting, earlier beam activation improves object detection and edge recognition. This matters even more when combined with matrix LED systems and camera-based road interpretation.
EV commuting and energy-aware driving
In EVs, headlight energy use is modest compared with traction demand, but system efficiency still matters. Smarter control avoids unnecessary operation while keeping safety margins intact, supporting better total energy discipline.
Why it matters for the wider exterior and vision system
Smart headlight activation should not be viewed as a stand-alone lighting trick. It interacts with the broader vehicle exterior package, including sensor placement, thermal management, styling constraints, and software coordination.
This is where the AEVS perspective is useful. Exterior intelligence is increasingly defined by the relationship between optical systems, lightweight structures, and ground-contact dynamics rather than by isolated component upgrades.
For example, headlight thermal behavior affects LED stability. Aerodynamic packaging influences contamination risk on lenses and sensors. Tire spray management can alter camera clarity in wet conditions. These links shape real-world activation quality.
The result is a more integrated design question: not just whether the headlight turns on, but whether the whole exterior perception system performs consistently across varied environments and regulations.
What to evaluate before treating it as a premium feature
The label smart can hide major differences in performance. Some systems are little more than improved automatic switching. Others are deeply integrated with matrix lighting, traffic detection, and predictive control logic.
A useful assessment should focus on behavior, not marketing language.
- Check activation timing in tunnels, rain, and twilight rather than only in static demos.
- Review how the system handles false triggers from shadows, reflective signs, or urban glare.
- Understand sensor dependencies, including camera cleaning, rain sensing, and lens contamination risks.
- Compare regional compliance needs such as ECE and DOT-related lighting behavior.
- Look at software update pathways if the vehicle uses adaptive or matrix-based logic.
In business analysis, it also helps to separate commodity automation from high-value perception capability. That distinction affects sourcing strategy, technical benchmarking, and aftermarket positioning.
Where the technology is heading next
The next stage of smart headlight activation is likely to be more predictive than reactive. Instead of waiting for darkness or rain to cross a threshold, systems will increasingly combine map context, camera classification, and driving behavior.
That evolution aligns with larger trends in smart mobility. Lighting is becoming part of a perception stack that supports safety, styling differentiation, and software-based function upgrades over the vehicle lifecycle.
It also fits the direction highlighted by AEVS, where intelligent optics, vehicle aesthetics, and efficiency targets are stitched together rather than managed in separate silos.
For anyone tracking this field, the next useful step is to compare systems by scenario performance, sensor architecture, and integration depth. That approach reveals far more than a brochure description and creates a stronger basis for judging future lighting platforms.