
Industry Portal
Related News
- 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions - 00
0000-00
Private Label Tire Export: Evaluating Suppliers, Compliance, and Landed Cost - 00
0000-00
DOT-Compliant Truck Lighting: A Practical Guide to FMVSS 108 Requirements
How Smart Headlight Activation Improves Night Driving in Tunnels, Rain, and Urban Traffic
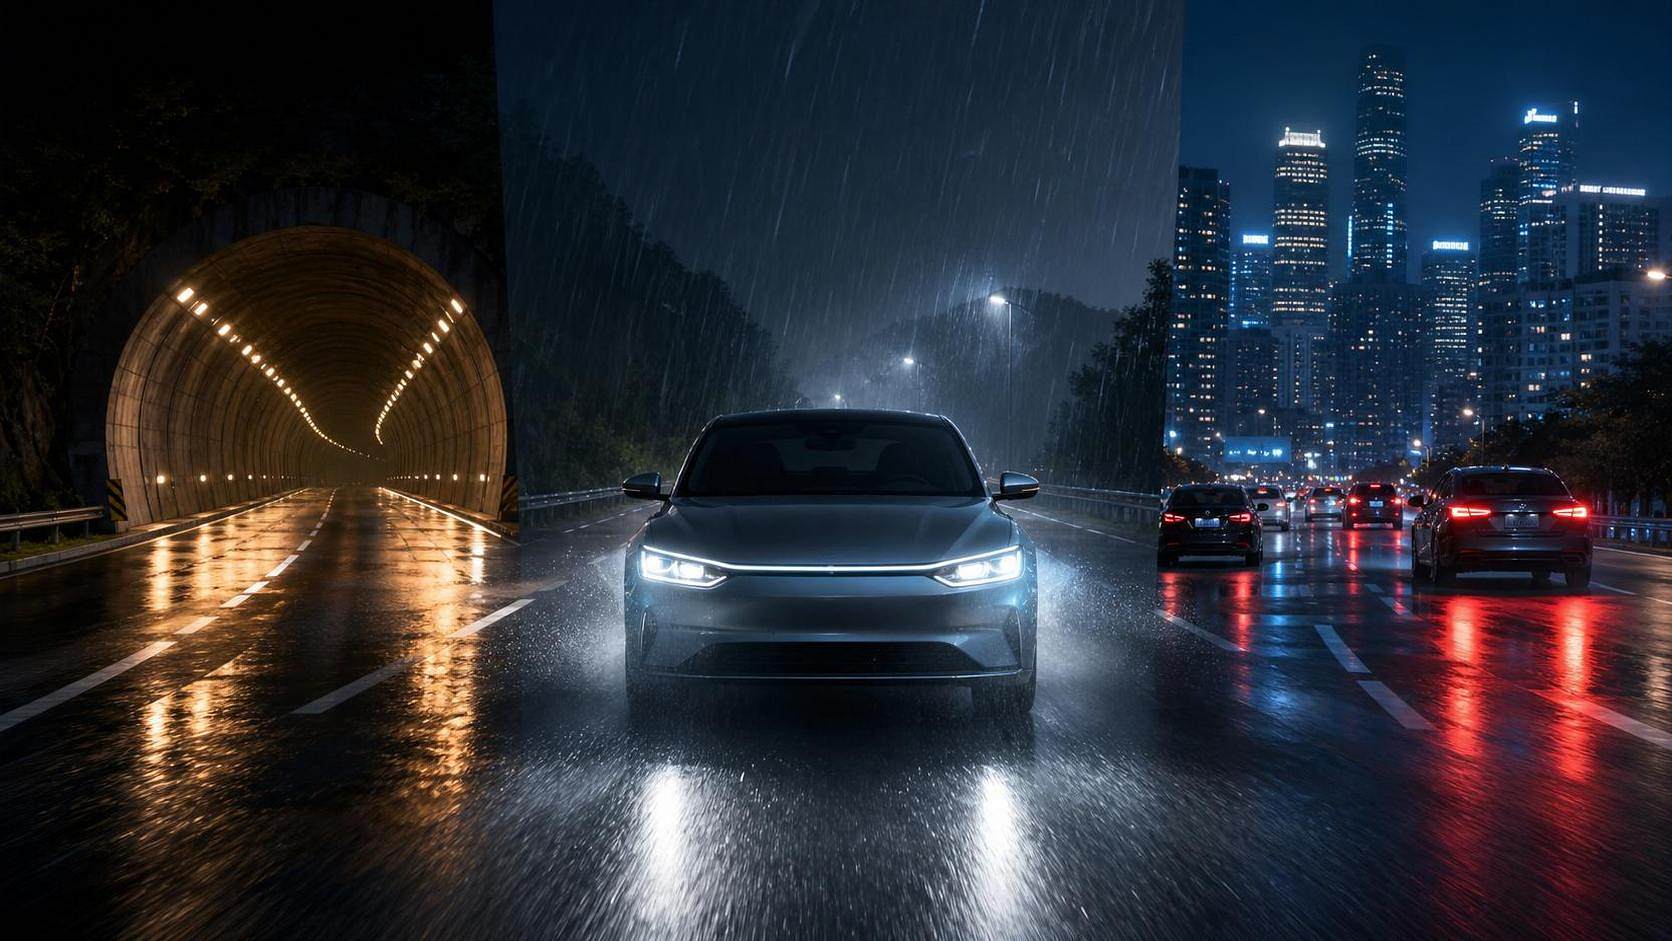
Night visibility changes fast, and the lighting response must keep up
Night driving rarely stays consistent for long. A dry open road can turn into a tunnel entrance, reflected rain spray, or dense urban glare within minutes.
That is where smart headlight activation becomes more than a comfort feature. It supports quicker visual adaptation when road brightness, contrast, and traffic density change suddenly.
In practical vehicle exterior and vision engineering, lighting cannot be judged alone. Sensor switches, LED headlight assemblies, windshield conditions, and even tire-road behavior affect what the driver can actually perceive.
This is also why AEVS treats smart optical perception as part of a wider driving quality system. The interaction between optics, sensing, compliance, and NEV efficiency matters most in real road situations.
The value of smart headlight activation is simple in principle but nuanced in use. It should respond early enough to help visibility, yet selectively enough to avoid unnecessary glare or distraction.
Why tunnel entries, rain corridors, and city traffic need different lighting logic
Different night environments create different visual problems. The challenge is not only darkness. It is the speed of transition, the direction of reflected light, and the amount of surrounding information.
A tunnel compresses the eye’s adaptation time. Heavy rain breaks contrast and multiplies reflections. Urban traffic adds signs, storefront lighting, wet asphalt glow, and constant encounters with other vehicles.
Because of that, smart headlight activation should not be evaluated by one parameter such as brightness alone. Response timing, masking accuracy, sensor reliability, and integration with auto wipers often matter more.
For EV platforms, another layer appears. Energy efficiency, thermal management of LED modules, and aerodynamic packaging of the front-end system can shape how advanced lighting performs over time.
Tunnel driving rewards early detection more than maximum brightness
Tunnel approaches are deceptively difficult. The issue is often not the tunnel interior itself, but the abrupt drop in ambient light at the portal.
A well-tuned smart headlight activation system detects the approach before the cabin reaches the darker zone. That earlier switch helps preserve depth perception and lane reading during the transition.
More advanced systems also account for tunnel length and traffic flow. A short underpass may need a different response from a long enclosed section with multiple curvature changes.
The common mistake is assuming every tunnel event needs the same high output. In reality, excessive or poorly aimed light inside reflective tunnel walls can flatten contrast instead of improving it.
The better judgment point is transition quality. Smart headlight activation should reduce visual shock, maintain lane-edge recognition, and avoid creating hot spots on signs or barriers.
What usually deserves attention before deployment
- Sensor sensitivity at tunnel mouths with mixed sunlight and shadow.
- Compliance with ECE or DOT beam behavior requirements.
- LED thermal stability during repeated switching cycles.
- Calibration consistency after windshield or front fascia replacement.
In heavy rain, visibility loss comes from reflection, spray, and delayed recognition
Rain creates a different task for smart headlight activation. The road may already be dark, yet the larger problem is scattered light and reduced object contrast.
Water on the road surface reflects headlamp output back toward the vehicle. Spray from nearby traffic diffuses the beam. Painted lane markings can either glow too strongly or disappear.
In this condition, smart headlight activation works best when linked with rain sensors and auto wipers. Coordinated logic allows the vehicle to recognize that the weather event, not sunset alone, has changed visual demand.
This is especially relevant for NEVs with quieter cabins. Lower cabin noise can make visual comfort more noticeable, so unstable lighting behavior feels more intrusive during rain driving.
A practical recommendation is to judge beam control by contrast recovery, not by apparent intensity. The goal is seeing lane boundaries, puddles, and vehicle outlines earlier, with less back-scatter.
Rain use cases often expose hidden system weaknesses
Photoelectric sensing can become less reliable when the windshield carries water film, dirt, or washer residue. If the sensing path is compromised, smart headlight activation may react late or oscillate.
Another overlooked factor is tire spray. High-performance tires with strong wet grip improve control, but they also change the amount of mist around the vehicle body at highway speed.
That means lighting, wiper logic, and road-contact behavior should be viewed as one perception chain, not separate features.
Urban night traffic needs selective control, not constant high output
City driving looks brighter, but it often demands the most precise smart headlight activation strategy. Streetlamps, LED billboards, bus lanes, cyclists, and wet intersections all compete for attention.
In these conditions, the main issue is not insufficient light. It is managing glare while preserving recognition of moving objects at the edges of the field of view.
Smart headlight activation becomes more effective when paired with adaptive LED matrices or anti-glare masking. That allows useful illumination without dazzling oncoming drivers or overexposing reflective signs.
The best urban systems also avoid nervous switching. If lamps change state too frequently in mixed lighting streets, confidence drops and the benefit of automation becomes less convincing.
A more balanced setup reads context. Traffic density, speed, intersection frequency, and surrounding luminance should shape the response window.
Different night scenes call for different judgment priorities
It helps to compare conditions directly rather than treating all night driving as one category. The table below shows where smart headlight activation should be judged differently.
This comparison also explains why a single brochure value says little. Smart headlight activation performs well only when its control logic matches the road environment it will face most often.
What often gets misjudged before real-world use
A frequent error is focusing on lamp specification while ignoring the sensing chain. If the photo sensor, windshield area, or control software is unstable, premium optics cannot deliver consistent results.
Another mistake is treating tunnel driving and rain driving as similar low-light events. One is mainly about transition speed. The other is mainly about contrast disruption and reflection.
Cost can also be judged too narrowly. Smart headlight activation should be reviewed with maintenance intervals, recalibration needs, replacement part compatibility, and regulatory requirements in mind.
For global platforms, regional standards matter. Beam behavior acceptable in one market may need different validation elsewhere under ECE or DOT frameworks.
In actual application planning, a system that is slightly less aggressive but more predictable often delivers better long-term driving quality.
Practical ways to match smart headlight activation to the vehicle and road context
A good starting point is to map the dominant night scenarios rather than average them together. A commuter EV in dense city traffic needs a different tuning priority from a long-range vehicle crossing tunnels and wet highways.
- Check whether sensor inputs include ambient light, rain status, and traffic context.
- Review beam behavior after windshield replacement or front-end repair.
- Compare activation timing in dry, wet, and mixed-light routes.
- Confirm that LED thermal performance remains stable during repeated night cycles.
- Assess compatibility with matrix lighting, auto wipers, and vehicle network controls.
From the broader AEVS perspective, this is where exterior intelligence becomes practical. Smart headlights, sensor switches, aerodynamic front architecture, and vehicle efficiency targets should reinforce each other rather than compete.
The next useful step is to define a scene-based evaluation standard. Separate tunnel transition tests, wet-road perception checks, and urban anti-glare validation will reveal more than a generic night drive review.
When smart headlight activation is judged that way, its role becomes clearer. It is not simply automatic lighting. It is a perception management tool that supports safer, calmer, and more efficient night driving.