
Industry Portal
Related News
- 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions - 00
0000-00
Private Label Tire Export: Evaluating Suppliers, Compliance, and Landed Cost - 00
0000-00
DOT-Compliant Truck Lighting: A Practical Guide to FMVSS 108 Requirements
Automotive Optical Systems Lighting Explained: Key Components, Functions, and Use Cases
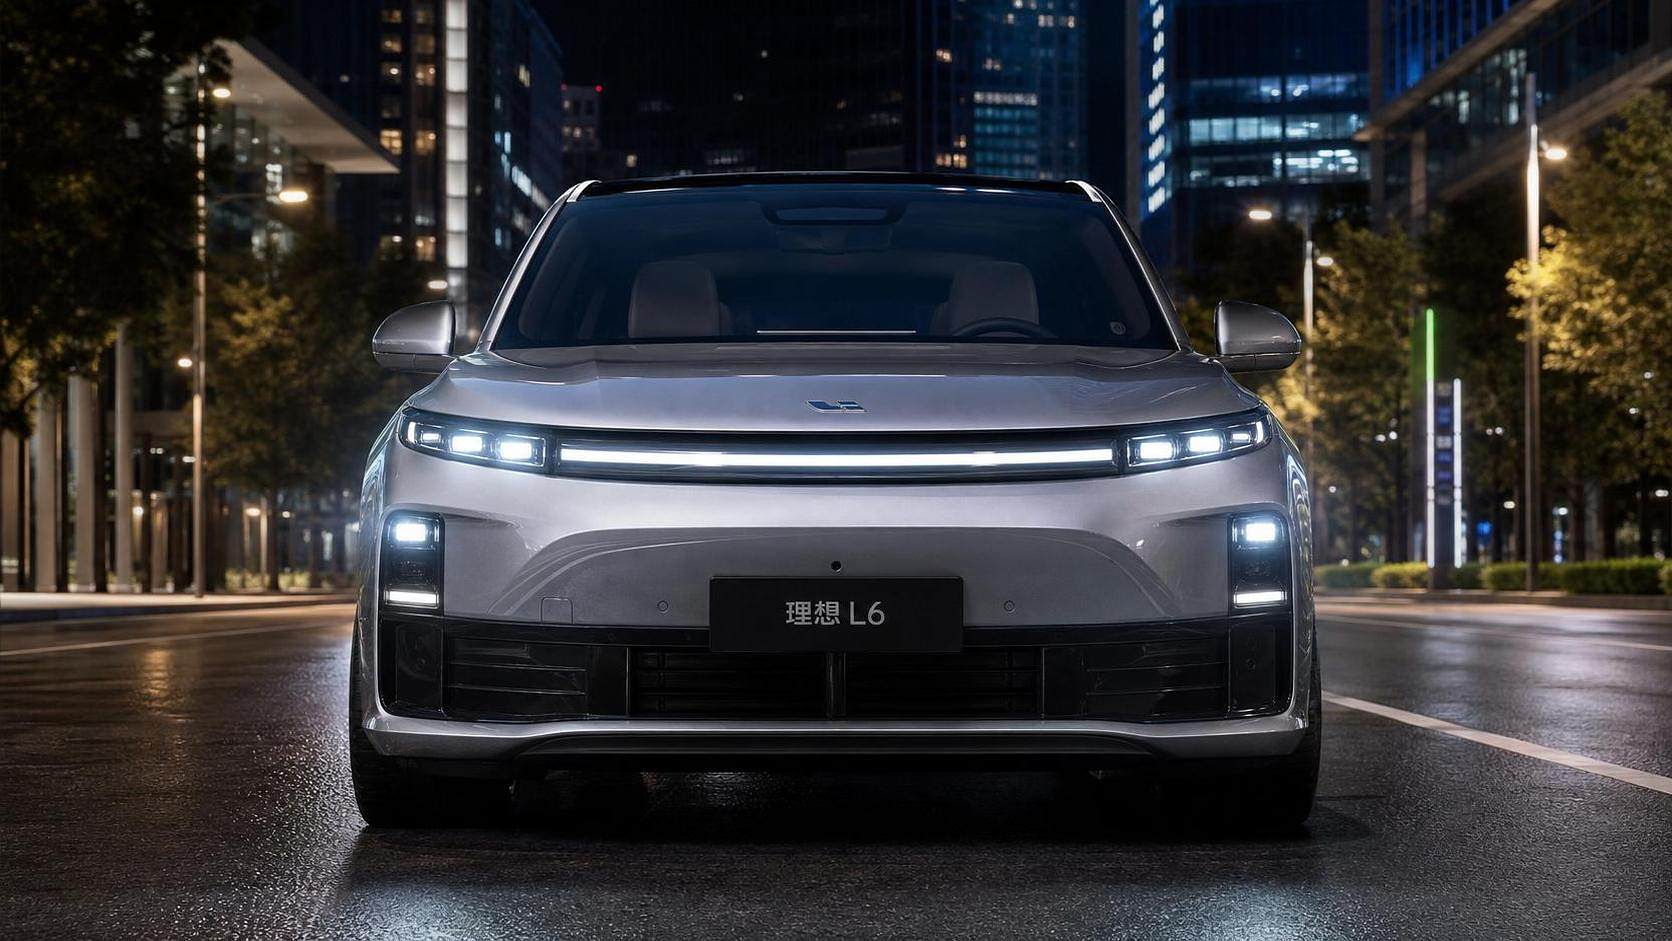
Why is automotive optical systems lighting getting so much attention?
Automotive optical systems lighting now sits at the center of vehicle safety, efficiency, and exterior design.
It no longer means only headlights that brighten the road.
In modern vehicles, it includes beam shaping, signaling logic, glare control, sensor-triggered activation, and even projection-based communication.
That shift matters even more in the NEV market, where energy use, thermal control, and aerodynamic packaging all affect vehicle range.
A useful way to read automotive optical systems lighting is to see it as part of a larger exterior intelligence stack.
This is also why platforms like AEVS track it alongside wheels, tires, sunroof systems, and sensor switches.
The connection is practical.
A headlamp’s optical performance depends on heat, electronics, body integration, regulations, and how the vehicle reads its surroundings.
So when people search for automotive optical systems lighting, they are usually asking a broader question.
How do vehicles see, signal, and protect more intelligently without wasting energy or compromising design?
What does automotive optical systems lighting actually include?
The term covers far more than bulbs and reflectors.
At the core are light sources, optical elements, control electronics, sensing interfaces, and thermal management structures.
Each part changes what the system can do on the road.
- Light sources: LED, laser-assisted modules, OLED, and emerging micro-LED solutions.
- Optical components: lenses, reflectors, projectors, light guides, diffusers, and matrix arrays.
- Control units: drivers, ECUs, beam algorithms, dimming logic, and adaptive lighting software.
- Sensing links: cameras, ambient light sensors, photoelectric triggers, and mm-wave-supported responses.
- Mechanical and thermal parts: housings, heat sinks, sealing materials, and ventilation paths.
LED headlight assemblies remain the most visible example.
Yet the real value comes from how these parts work together.
A matrix LED unit, for example, is only as useful as its glare-free masking, thermal stability, and software accuracy.
In practical research, the better question is not “Which lamp type is installed?”
It is “What optical function can the full system reliably deliver under real driving conditions?”
Which functions matter most in real driving use cases?
Most interest in automotive optical systems lighting comes from real road behavior, not from component names.
Drivers and engineers care about what the system improves at night, in rain, in traffic, and in mixed urban environments.
Several functions now define the category.
In actual applications, these functions often overlap.
A smart headlight may combine ambient sensing, matrix segmentation, and navigation-linked beam patterns in one housing.
That is why system-level evaluation matters more than checking a single feature box.
How do you compare LED, matrix, and sensor-linked solutions without oversimplifying?
A common mistake is to rank solutions by marketing language alone.
“Matrix” sounds more advanced than “LED,” but the real comparison depends on performance targets and integration depth.
Basic LED systems improve efficiency, styling freedom, and service life.
They suit many mainstream platforms where stable illumination and packaging flexibility are the main goals.
Matrix LED systems go further.
They divide light into controllable zones, allowing selective masking and more precise beam shaping.
This is especially valuable for premium vehicles, high-speed driving, and advanced driver assistance coordination.
Sensor-linked solutions should be seen as an enabling layer, not a separate lamp category.
They connect lighting behavior to weather, traffic, steering input, camera data, or body-control logic.
More often than not, the better judgment method is this:
- Check the required visibility range and glare limits.
- Confirm whether thermal load stays stable in compact EV packaging.
- Review ECE or DOT alignment early, not after design freeze.
- Test how lighting logic interacts with other exterior systems.
That last point is often underestimated.
At AEVS, exterior intelligence is not treated as isolated hardware.
Lighting performance can be affected by wheel airflow, front-end packaging, sensor placement, and body styling constraints.
Where do projects usually run into trouble?
The most common risks in automotive optical systems lighting are not always optical.
They often come from mismatch between design ambition and system discipline.
One issue is thermal underestimation.
High-output LED modules can lose consistency or lifetime if heat paths are poorly designed.
Another issue is algorithm dependence.
Adaptive and matrix functions rely on accurate sensing, robust software, and stable calibration.
If any of those layers drift, the optical advantage weakens quickly.
There is also a compliance risk.
A concept that looks strong in one market may need redesign for another because ECE and DOT requirements differ in beam rules and approval logic.
Then comes cost creep.
As functions stack up, the project can absorb extra sensors, control units, software validation, and sealing complexity.
A short checklist helps keep expectations realistic.
- Do not evaluate optics without heat management data.
- Do not assume projection functions are legally usable everywhere.
- Do not separate lighting logic from sensor-switch behavior.
- Do not treat styling goals as independent from serviceability and sealing.
In research terms, this is where deeper intelligence platforms become useful.
Tracking material cost shifts, aftermarket demand, and technical evolution together gives a more realistic picture than isolated product claims.
What should you look at next if you are evaluating automotive optical systems lighting?
Start with the function, not the label.
Ask what the system must achieve in visibility, signaling, interaction, and energy use.
Then connect that requirement to the surrounding exterior architecture.
For NEV-focused programs, this usually means reviewing packaging space, thermal limits, sensor links, and regulatory targets together.
It also helps to separate three evaluation layers.
- Core capability: illumination range, beam precision, anti-glare performance.
- Integration quality: ECU logic, sensor response, sealing, and heat stability.
- Program feasibility: compliance path, cost structure, validation time, and supply maturity.
That approach keeps the topic grounded.
Automotive optical systems lighting is best understood as a coordinated exterior technology, not just a lamp upgrade.
The strongest decisions usually come from comparing use cases, not chasing the most advanced term.
A sensible next step is to map the intended scenario, list the required functions, and verify which technical trade-offs are acceptable before comparing solutions.
From there, follow the signals that matter most: optical control quality, thermal behavior, compliance readiness, and how well the system fits the broader exterior intelligence strategy.