
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
Why optical matrix algorithms affect ADB performance
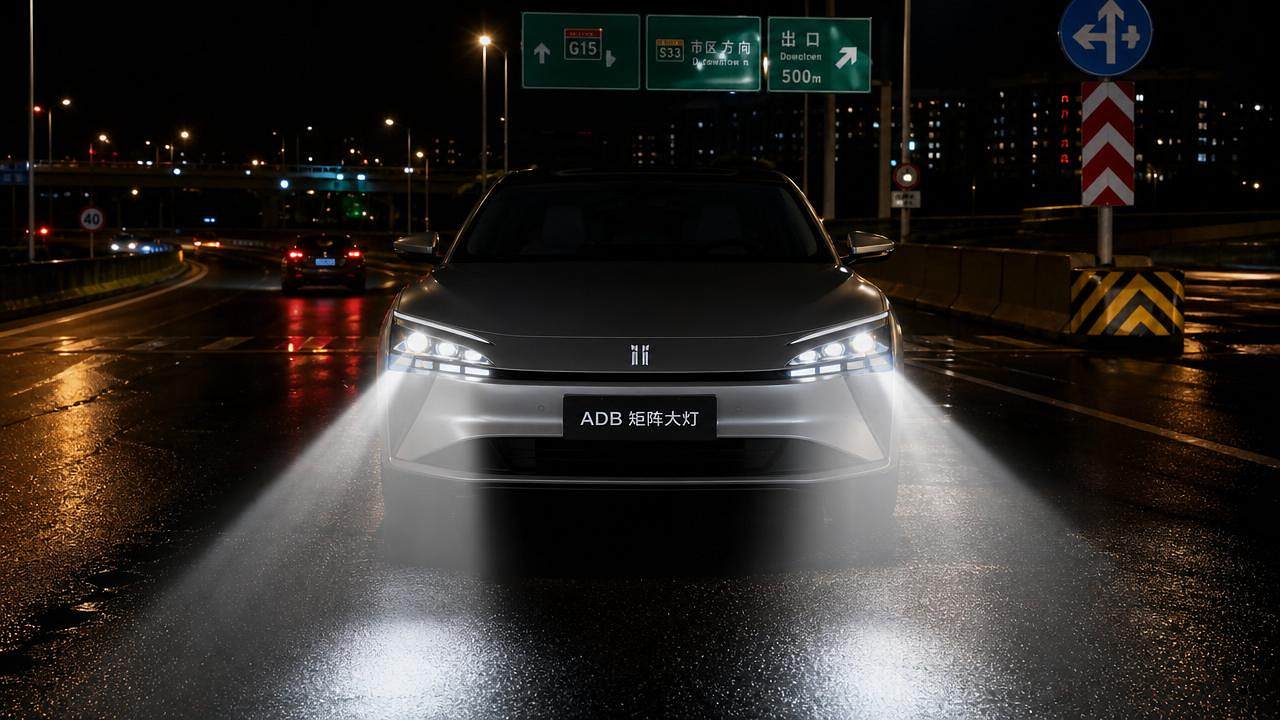
Why optical matrix algorithms matter in real ADB evaluation scenarios
For technical evaluators assessing Adaptive Driving Beam systems, optical matrix algorithms are not just software logic.
They directly determine beam accuracy, glare suppression, response timing, and regulatory consistency across dynamic road environments.
That is exactly why optical matrix algorithms affect ADB performance in measurable and commercially important ways.
Within the broader automotive exterior and vision ecosystem, algorithm quality also influences thermal loading, sensor coordination, driver confidence, and lighting energy efficiency.
For AEVS, this topic connects smart optical perception with compliance, safety, and the evolving aesthetics of intelligent vehicle front-end design.
When scenario differences change what “good” ADB performance really means
ADB systems do not operate in a fixed laboratory condition.
They face highways, urban intersections, rain reflections, crest hills, opposing traffic, roadside signs, and mixed-speed traffic patterns.
In each case, optical matrix algorithms decide how pixels switch, dim, mask, and reshape the beam.
A headlamp with strong hardware can still underperform if the control logic misjudges object position or delays beam segmentation.
This is why optical matrix algorithms affect ADB performance beyond brightness alone.
The best systems balance seeing farther while preventing discomfort glare.
That balance depends on scene interpretation, pixel mapping precision, and the algorithm’s ability to predict motion before conditions change.
Scenario 1: Highway driving demands long-range precision and stable masking
On highways, vehicles move faster and headlamp decisions must happen earlier.
Here, optical matrix algorithms affect ADB performance by controlling long-distance target detection and smooth anti-glare cutout transitions.
If masking zones are too wide, useful seeing distance drops.
If masking is too narrow, oncoming drivers may experience stray glare from beam leakage or delayed switching.
Core evaluation points on highways
- Detection range for vehicles in adjacent and opposite lanes
- Mask stability during lane changes and overtaking
- Latency between sensor input and pixel response
- Beam reach after glare-free segmentation
Highway ADB quality depends on predictive control, not only reactive switching.
That predictive layer is a major reason why optical matrix algorithms affect ADB performance so strongly.
Scenario 2: Urban streets require dense object handling and fine pixel control
Cities present more visual complexity than highways.
ADB must handle pedestrians, bicycles, traffic signs, parked vehicles, reflective glass, and frequent turning events.
In this environment, optical matrix algorithms affect ADB performance through classification accuracy and local beam shaping.
A system may detect an object correctly but still illuminate it poorly if pixel grouping is too coarse.
Urban comfort also matters.
Abrupt dimming or flickering masks can create distraction even when glare limits are technically met.
Core evaluation points in cities
- Object classification in cluttered scenes
- Fine-grained pixel addressing near signs and sidewalks
- Visual smoothness during repeated beam updates
- Suppression of false positives from reflections
Urban testing often reveals why optical matrix algorithms affect ADB performance more than raw lumen output suggests.
Scenario 3: Adverse weather exposes sensor fusion and thermal limits
Rain, fog, snow, and road spray degrade both sensing and beam usefulness.
Under these conditions, optical matrix algorithms affect ADB performance because they must reinterpret uncertain data and modify illumination strategy.
For example, excessive forward intensity in fog can increase backscatter and reduce visibility.
A stronger algorithm can shift beam distribution lower and wider while preserving target contrast.
Thermal behavior also matters in bad weather.
When LEDs heat up, luminous output changes, and compensation logic becomes essential to maintain intended beam geometry.
Core evaluation points in adverse conditions
- Robustness against noisy sensor input
- Adaptive beam strategy for visibility loss
- Thermal compensation for pixel consistency
- Reduced glare from wet-road reflections
How scene-specific ADB needs differ
The table shows why optical matrix algorithms affect ADB performance differently across operating conditions.
A system optimized only for one scenario may score poorly in another.
Practical adaptation guidance for comparing ADB architectures
When comparing matrix LED, pixelated LED, or higher-resolution projection architectures, evaluation should connect hardware and control logic together.
This is especially relevant for AEVS coverage of smart optical perception and intelligent exterior integration.
Recommended evaluation actions
- Measure end-to-end latency, not only sensor refresh rate.
- Test beam masking width at multiple target distances.
- Review thermal derating behavior after extended night operation.
- Check compliance margins under ECE or DOT relevant conditions.
- Validate performance on wet pavement, reflective signs, and curved roads.
- Compare visual smoothness, not just pass-fail glare results.
These steps help explain why optical matrix algorithms affect ADB performance in real deployment, not only in specification sheets.
Common misjudgments that distort ADB assessment
A frequent mistake is assuming more pixels automatically create better ADB behavior.
Without effective optical matrix algorithms, additional pixels may add complexity without improving practical beam control.
Another misjudgment is evaluating glare only in static tests.
Real glare events often appear during motion, cresting, steering input, or object crossing.
It is also risky to separate software from thermal design.
When LED temperature shifts, algorithm compensation may become the difference between stable output and degraded masking accuracy.
Finally, sensor quality alone does not guarantee success.
Optical matrix algorithms affect ADB performance because they translate perception into light distribution, which is the actual safety outcome.
What to do next for stronger ADB decision-making
To judge advanced headlamp systems accurately, build assessments around scenarios, not isolated specifications.
Focus on how optical matrix algorithms affect ADB performance across speed, weather, traffic density, and compliance boundaries.
Use cross-functional review between optics, electronics, sensing, thermal control, and vehicle exterior integration.
That approach reflects the AEVS view of intelligent exteriors: vision systems succeed when algorithms, hardware, and real mobility conditions are engineered together.
If the goal is safer, more efficient, and more expressive lighting, understanding why optical matrix algorithms affect ADB performance should be the starting point.