
Industry Portal
Related News
- 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems
Tags
Where Matrix Projection Still Falls Short in ADB Tuning
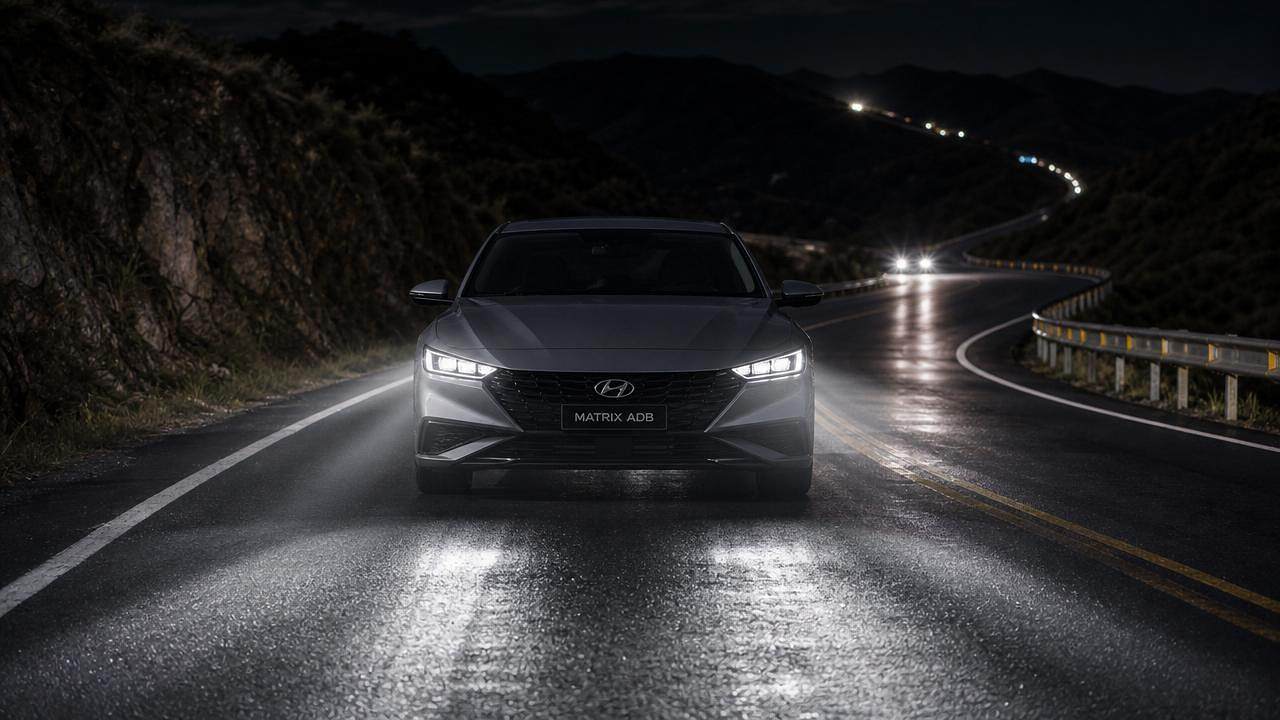
Where Matrix Projection Still Falls Short in ADB Tuning
Matrix projection has pushed ADB far beyond fixed low and high beams. It promises glare-free visibility, adaptive masking, and clearer night driving.
Yet matrix projection still falls short in daily tuning. Real roads, weather shifts, traffic diversity, and regulatory limits expose calibration gaps that lab validation may miss.
For the broader exterior and vision industry, this matters. Headlamp performance now affects safety, energy efficiency, brand perception, and the practical value of smart optical systems.
This article explains where matrix projection still struggles, and offers a structured way to evaluate ADB tuning with more realism and less assumption.
Why a structured review is still necessary
Many teams assume matrix projection accuracy scales directly with pixel count. In practice, optical quality, ECU logic, sensor confidence, and legal boundaries shape actual beam behavior.
A structured review helps separate marketing claims from usable performance. It also reveals whether ADB tuning remains stable across speeds, surfaces, climates, and mixed traffic environments.
This is especially relevant for EV platforms. Heavier curb weight, low-noise cabins, and higher customer sensitivity make lighting flaws easier to notice and harder to excuse.
Core points to examine in matrix projection tuning
- Check glare masking stability when vehicles approach on crests, dips, and banked roads, where vertical aim changes often cause matrix projection errors and delayed dark-zone placement.
- Verify beam edge precision at medium and long distance, because pixelated light blocks may look accurate nearby but blur or spill after lens and reflector interaction.
- Measure response latency from sensor detection to beam update, since fast overtakes, motorcycles, and crossing traffic can outpace matrix projection adjustment logic.
- Review performance in rain, fog, dust, and road spray, as low-contrast scenes reduce object recognition confidence and weaken reliable ADB tuning decisions.
- Assess lane guidance and symbol projection consistency, because decorative or guidance functions may distract if brightness, alignment, or contextual accuracy is poorly tuned.
- Compare left-right uniformity and hotspot distribution, since matrix projection often shows visible segmentation, brightness steps, or patchy illumination across wider beam patterns.
- Confirm calibration retention after vibration, thermal cycling, and load variation, because headlamp aim and optical alignment can drift under real vehicle operating conditions.
- Evaluate interactions with camera, radar, and ambient sensors, as conflicting signals may force conservative logic that limits the practical benefits of matrix projection.
- Test compliance margins against ECE and DOT requirements, since legal photometric limits often constrain the most aggressive ADB tuning strategies.
- Inspect energy and thermal management behavior, because projector heat, LED derating, and power-saving modes can reduce beam consistency during extended night driving.
Where matrix projection most often falls short
Glare control is not always as precise as expected
The main promise of matrix projection is precise anti-glare masking. However, glare still appears when road geometry changes faster than the system updates.
Hill crests are a common weakness. A beam that is safe on flat pavement may briefly shine into another driver’s eyes before masking catches up.
Beam precision degrades outside ideal optical conditions
Matrix projection depends on optics as much as electronics. Lens contamination, thermal expansion, and manufacturing tolerances can soften the intended beam boundaries.
That means the projected dark zone may be wider than needed, reducing visibility, or narrower than intended, increasing glare risk.
Scene interpretation remains imperfect
ADB tuning performs best when objects are easy to classify. It struggles more with bicycles, reflective signs, animal movement, unusual trailers, and partially hidden vehicles.
In these cases, matrix projection may behave too cautiously or too late. Both outcomes reduce trust in the system.
Thermal and power limits quietly reduce consistency
High-resolution lighting creates heat. As temperature rises, LED output may be reduced to protect hardware, changing brightness and beam balance during long nighttime use.
For EVs, power optimization strategies can add another constraint. Matrix projection may not always run at ideal output when efficiency targets dominate.
How these gaps appear in different driving environments
Urban traffic
Cities create dense visual noise. Streetlights, reflections, wet asphalt, and close traffic make object detection harder and increase unnecessary beam changes.
Here, matrix projection often becomes overactive. Frequent masking can create visible flicker and uneven illumination, which reduces driver comfort.
Highway driving
Highway speed exposes latency. At long range, even a small processing delay affects beam placement during overtaking, lane changes, and traffic merging.
Median barriers and truck height differences also challenge matrix projection. Misjudging these shapes can lead to either excessive masking or late glare suppression.
Rural and mountain roads
These roads highlight the limitations of prediction. Curves, elevation changes, and absent lane markings reduce confidence in road-scene interpretation.
A well-tuned system should preserve forward reach without blinding others. Matrix projection still struggles to balance both on complex terrain.
Rain, fog, and dirty surfaces
Bad weather compresses contrast and increases backscatter. Cameras lose clarity, while the projected beam can produce more reflected glare from droplets or spray.
When the outer lens is dirty, matrix projection precision drops further. This weak point is often underestimated in validation programs.
Commonly overlooked risks
One overlooked issue is calibration drift after suspension changes or wheel-tire updates. Vehicle stance shifts can alter aim enough to affect matrix projection accuracy.
Another is software conservatism. To avoid compliance issues, some ADB tuning maps disable useful projection behavior too early, especially near ambiguous light sources.
There is also a perception gap. A technically compliant beam may still look uncomfortable to road users if brightness transitions feel abrupt or artificial.
Finally, many reviews ignore maintenance effects. Aging LEDs, yellowing optics, and sensor contamination can gradually reduce matrix projection quality without obvious failure warnings.
Practical ways to improve ADB tuning evaluation
- Test on mixed routes, not only proving grounds. Include urban glare sources, highways, rural curves, gradients, wet surfaces, and varied traffic compositions.
- Record synchronized video, sensor logs, and beam patterns. This reveals whether matrix projection errors come from perception, decision logic, or optics.
- Set pass criteria for comfort, not just compliance. Evaluate transition smoothness, masking stability, and forward visibility under realistic driving loads.
- Run thermal endurance sessions at extended night duty cycles. Confirm that beam output and masking precision remain stable after heat buildup.
- Repeat validation after wheel, tire, suspension, and ride-height changes, because chassis variation can quietly undermine previously acceptable ADB tuning.
Summary and next-step focus
Matrix projection is a major step forward, but it is not a finished answer to perfect ADB tuning. Its limits appear in glare control, scene interpretation, beam precision, and durability.
The most reliable approach is disciplined review across optics, electronics, software, thermal behavior, and vehicle integration. Strong performance comes from system balance, not pixel count alone.
For organizations tracking automotive exterior and smart vision evolution, matrix projection should be judged by repeatable road outcomes. Better tuning starts with better test structure.
Use the points above as a working reference, then refine validation around actual driving environments, compliance boundaries, and long-term optical stability.