
Industry Portal
Related News
- 00
0000-00
Which ISO Standards Govern Vehicle Lightweighting Materials and Validation Testing? - 00
0000-00
Wheel Lightweighting in Europe: How EV Regulations Are Reshaping Wheel Sourcing - 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials
Optical Matrix Algorithms in ADB Systems: Key Parameters, Limits, and Validation Methods
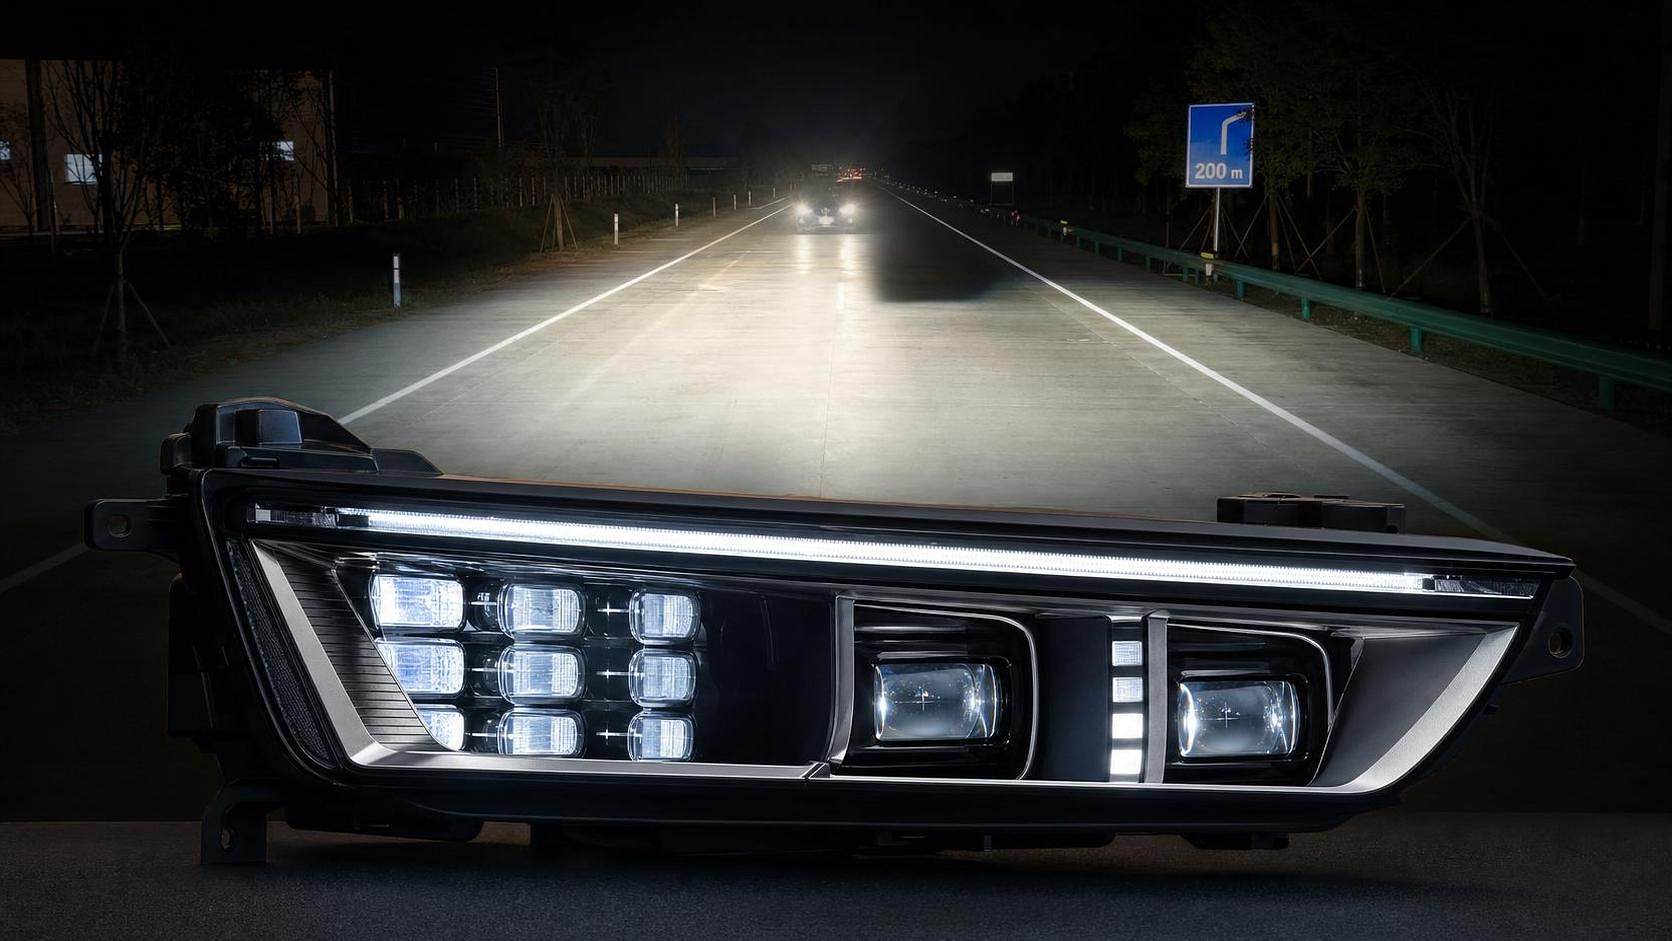
Optical Matrix Algorithms in ADB Systems: Key Parameters, Limits, and Validation Methods
As ADB technology moves from premium differentiation to regulatory necessity, optical matrix algorithms are now a core engineering topic.
They do not only shape beam patterns. They also influence compliance, driver comfort, thermal load, and platform cost.
For AEVS, this topic sits directly inside smart optical perception and exterior system intelligence.
In practical programs, the challenge is rarely one algorithm alone. It is the interaction between optics, electronics, software, and validation timing.
That is why understanding optical matrix algorithms early helps reduce late-stage surprises in ADB development.
Why optical matrix algorithms matter in ADB systems
Adaptive Driving Beam relies on selective light distribution. The system must illuminate useful areas while masking glare-sensitive zones.
This selective behavior depends on optical matrix algorithms that convert scene inputs into segment-level light commands.
The algorithm receives data from cameras, vehicle speed, steering angle, pitch signals, and ambient light conditions.
It then decides which pixels or LED segments brighten, dim, or switch off within milliseconds.
From a project perspective, this means algorithm quality directly affects homologation risk, customer perception, and software maturity.
Core parameters that define optical matrix algorithms
Not every parameter has equal impact. A few variables usually drive most ADB performance decisions.
1. Matrix resolution
Resolution describes the number of controllable light elements. Higher resolution allows finer glare masking and smoother transitions.
But higher resolution also increases processing demand, calibration effort, and potential failure points.
2. Angular precision
Angular precision links each light element to a physical road-space direction. Poor mapping creates masking errors and uneven beam edges.
This parameter is critical when optical matrix algorithms must protect oncoming traffic without reducing forward visibility too much.
3. Luminance control range
ADB is not just on and off. Good systems manage multiple intensity levels across the beam.
That allows gradual fade zones, better sign protection, and more natural driver perception at high speed.
4. Response latency
Latency includes sensing, decision logic, communication, and actuator response. In fast-closing traffic, delay becomes a safety issue.
Many teams underestimate this because optical matrix algorithms may look fast in simulation but slow down in integrated hardware.
5. Detection confidence thresholds
The algorithm must decide when an object is definitely a vehicle, a sign, or noise.
Thresholds that are too strict reduce responsiveness. Thresholds that are too loose create unstable beam behavior.
System limits that shape real-world performance
From recent program trends, the bigger signal is clear. Optical matrix algorithms are often limited more by system boundaries than by logic design.
Thermal constraints
High-density LED arrays generate heat. Thermal derating changes luminous output and can distort expected beam performance.
This means optical matrix algorithms must sometimes adapt to thermal states, not only road scenes.
Sensor quality and contamination
Rain, dirt, fog, and lens aging reduce input reliability. A perfect beam strategy fails if perception confidence collapses.
That is why fallback logic is as important as peak algorithm capability.
Compute and communication bandwidth
Real-time control depends on processor headroom, bus timing, and software scheduling.
When compute resources are shared across vehicle domains, optical matrix algorithms may lose determinism under load.
Regulatory boundaries
ECE and DOT frameworks do not evaluate innovation alone. They evaluate repeatable compliance under defined test conditions.
So the useful question is not whether optical matrix algorithms are advanced, but whether they stay compliant across edge cases.
How to validate optical matrix algorithms effectively
Validation should start earlier than many teams expect. Waiting for full vehicle integration usually creates avoidable schedule pressure.
Simulation-based validation
Use optical, environmental, and traffic simulations to assess beam logic before hardware maturity.
This stage is useful for sensitivity studies, threshold tuning, and corner-case exploration at low cost.
Hardware-in-the-loop testing
HIL testing exposes timing delays, interface mismatches, and degraded behavior that software models often hide.
For optical matrix algorithms, this is often where latency budgets become realistic rather than optimistic.
Photometric bench validation
Bench testing checks whether commanded light patterns match actual beam output with acceptable accuracy.
This step verifies segment mapping, cut-off behavior, uniformity, hotspot placement, and masking precision.
Road validation
Controlled road tests remain essential because human perception still matters in ADB acceptance.
Drivers notice flicker, unnatural transitions, and delayed masking faster than many metrics suggest.
Validation metrics that matter
- Masking accuracy against oncoming and preceding vehicles.
- Beam transition smoothness during steering and speed changes.
- Latency from target detection to beam update.
- Performance drift under thermal stress and voltage variation.
- Compliance repeatability across weather, road class, and sensor quality.
Common project risks behind optical matrix algorithms
In real business settings, several risks appear again and again.
- Requirements are written around ideal optics, not manufacturing variation.
- Validation plans focus on nominal weather and miss contamination scenarios.
- Software and optical teams optimize separately, causing beam-command mismatch.
- Regulatory interpretation is delayed until prototype freeze.
- Thermal behavior is treated as hardware only, not an algorithm condition.
The practical answer is cross-domain governance. Optical matrix algorithms need shared ownership across optics, electronics, software, and compliance.
A decision framework for development teams
A useful review framework keeps trade-offs visible before they become launch issues.
- Define target use cases first, including highway, urban glare, weather, and sign-rich routes.
- Set measurable limits for latency, masking width, fade smoothness, and thermal derating.
- Map every critical requirement to a validation method before design freeze.
- Review compliance assumptions early for ECE, DOT, and regional program variants.
- Plan fallback modes that remain safe when sensors or compute confidence degrades.
This approach supports faster decisions because it connects optical matrix algorithms to risk, cost, and timing in one view.
For intelligence platforms like AEVS, that connection is increasingly important as smart headlamps become part of wider exterior system strategy.
The stronger signal in the market is not only better illumination. It is better integration between optical intelligence and vehicle architecture.
When optical matrix algorithms are managed as a system capability, ADB programs gain better compliance resilience and better customer value.
The next practical step is simple: review current ADB requirements against actual validation coverage, then close the gaps before they become launch risks.