
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
How Smart Optical Perception Enables Low-Latency Detection in ADB Control Modules
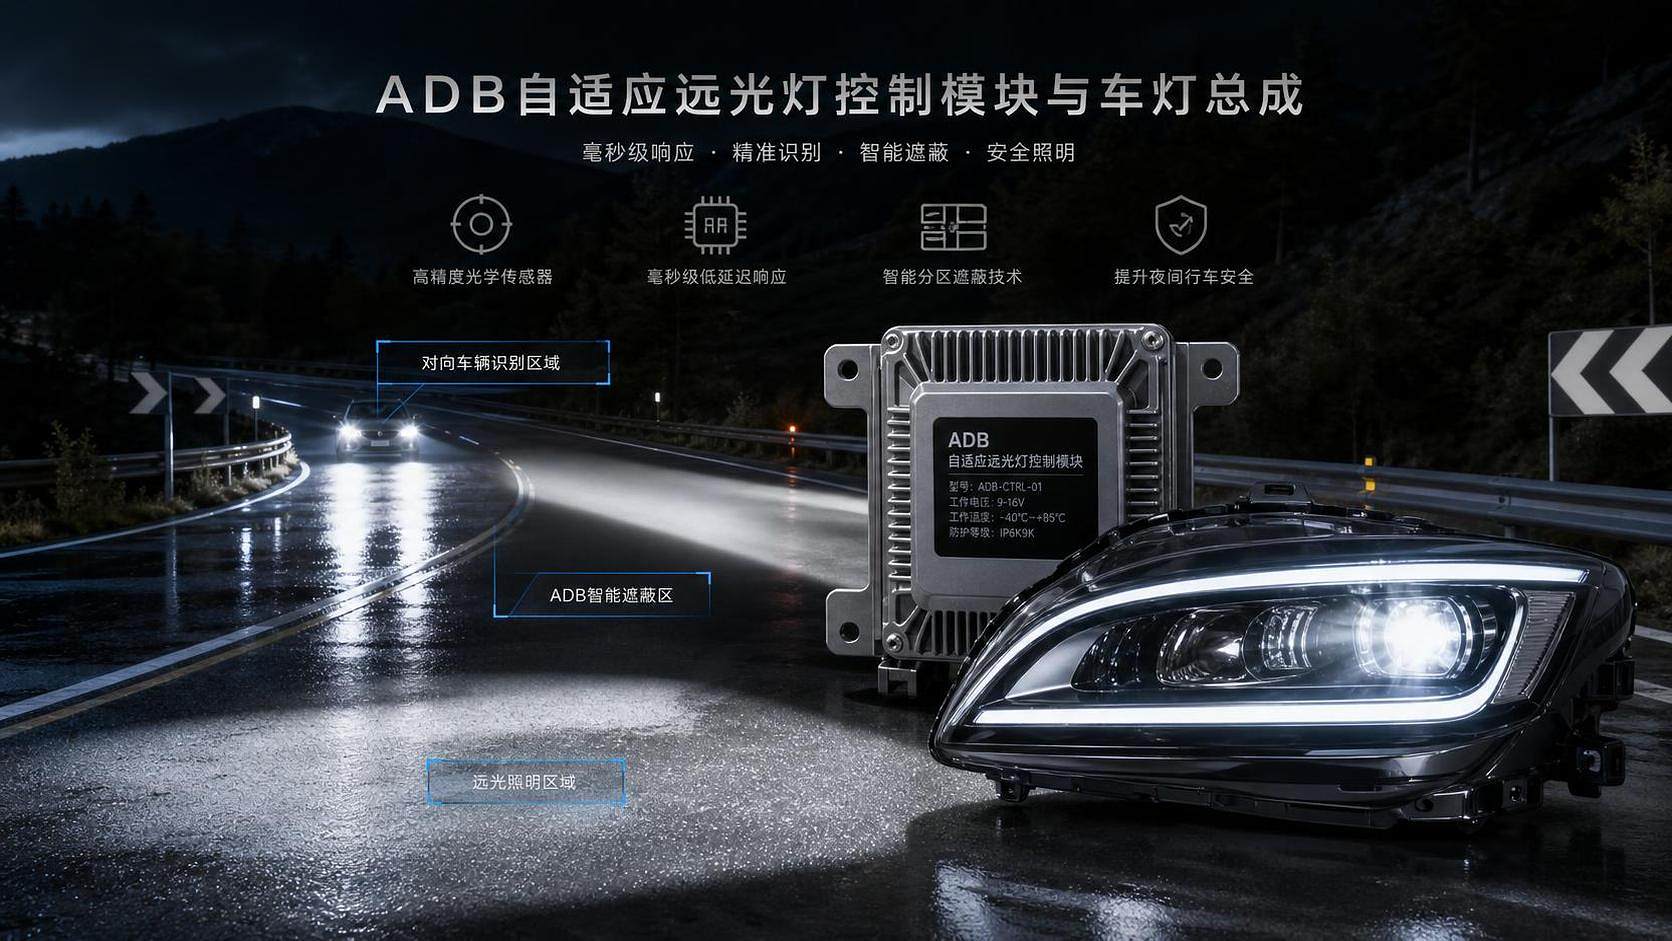
It usually starts with a complaint that is hard to reproduce in a controlled room but obvious on the road: the beam cutout reacts a fraction too late when another vehicle appears from a bend, or the masking zone hesitates when reflective signs, rain, and roadside objects arrive at once. In an ADB control module, that tiny delay is not a cosmetic issue. It changes where light lands, whether glare is suppressed in time, and whether the system behaves predictably enough for engineering approval.
If you are evaluating a next-generation module, the difficult part is that “fast enough” cannot be judged from processor specifications alone. Many teams first look at LED matrix resolution, camera frame rate, or the advertised intelligence of the perception stack. Then road testing reveals a less comfortable truth: low-latency behavior depends on the entire chain, from photons entering the sensor to the final actuation command reaching the headlamp driver. That is why smart optical perception low latency has become a useful phrase. It points attention away from isolated parts and toward timing discipline across sensing, interpretation, and beam control.
Where the delay usually hides
A common misunderstanding is to treat latency as a single number owned by one ECU. In practice, ADB response delay is accumulated. Exposure settings, sensor readout, image signal processing, object segmentation, classification confidence thresholds, bus transport, controller scheduling, and pixel mapping all add time. None of them may look alarming by themselves. Together, they can make the beam react after the scene has already changed.
This becomes more visible in mixed nighttime conditions. Dry highway testing may look clean because approaching headlights are bright, scene contrast is high, and motion patterns are predictable. Move into an urban edge road with wet asphalt, motorcycles, tree shadows, reflective signs, and intermittent street lighting, and the perception chain has to decide faster while also dealing with noisier inputs. The usual symptom is not complete failure. It is inconsistency: the mask is accurate in one pass, then slightly late in the next, even though the road seems similar.
When that happens, it helps to stop asking whether the module is “intelligent” and instead ask whether the optical perception path is temporally stable.
Latency is a sensing problem before it becomes a lighting problem
ADB engineers often inherit the lighting side of the problem and only later realize that the real bottleneck sits at the front end. Optical perception is not just camera hardware. It is the coordinated behavior of lens transmission, sensor dynamic range, exposure control, optical filtering, image preprocessing, and scene extraction logic. If these elements are not aligned for night driving edge cases, the control module receives information that is technically valid but too delayed, too noisy, or too uncertain to support precise anti-glare action.
That distinction matters during evaluation. A high-resolution scene input does not automatically create better beam behavior. In some conditions, more pixels and heavier interpretation pipelines increase compute load and push decisions later into the control cycle. The smarter design is often the one that extracts only the scene features the ADB function actually needs, then passes them through a deterministic path with minimal timing variation.
For this reason, many reviewers now examine smart optical perception as a real-time discipline rather than a visual quality discipline. The question is not simply whether the module can recognize vehicles, signs, lane edges, or ambient transitions. The question is whether it can recognize the right features quickly enough to drive a stable masking decision under lighting conditions that degrade contrast and increase ambiguity.
The first useful correction: stop equating frame rate with response speed
One of the most persistent evaluation mistakes is assuming that a higher camera frame rate means lower ADB latency. It may help, but only if the rest of the chain can consume those frames without buffering, waiting, or dropping confidence below the action threshold. A perception stack that samples rapidly but spends extra time denoising and reconciling unstable detections can still produce slower actuation than a leaner system with lower nominal frame rate.
Another issue is asynchronous behavior. The camera may update at one cadence, the perception software at another, and the lighting control scheduler at a third. If timestamps are not cleanly aligned, the module can act on a scene that is already old by the time the beam is updated. This is especially relevant when approaching vehicles appear from partial occlusion or when relative speed is high. In those cases, timestamp integrity matters almost as much as raw processing speed.
So when reviewing an architecture, it is worth asking a more grounded set of questions. Where is the scene timestamp created? Where can frames queue? Does the control module use the latest valid perception result or the latest fully classified result? Are confidence thresholds adaptive when glare risk is high? These are not glamorous questions, but they often expose whether a design is built for road timing or lab demos.
Practical ways to evaluate the perception path
When a module appears late or inconsistent, a useful approach is to break the chain into observable phases instead of debating the overall algorithm quality. Start from the moment a target light source enters the sensor field, then track when it becomes a candidate object, when it is accepted as relevant to glare control, when the beam map is recalculated, and when the matrix output changes. Even without publishing exact measurements, this phase-based review quickly reveals whether the major delay comes from sensing, decision logic, or actuation.
During this process, it is also important to separate absolute latency from jitter. An ADB system with moderate but stable delay can sometimes be calibrated more safely than one with lower average delay but unpredictable timing swings. Jitter creates driver-visible behavior such as beam flicker, mask hunting, or intermittent hesitation near threshold situations. In technical assessment, those are strong clues that the optical perception module is not feeding the controller with consistent timing or confidence.
Environmental variation should be treated as part of the test logic, not as noise around it. Road spray, retroreflective infrastructure, cresting hills, tunnel exits, and opposing traffic with nonstandard lamp signatures all stress the perception chain in different ways. If a module only looks good when contrast is clean, the evaluation has not yet reached the conditions that matter most.
Architecture choices that usually improve low-latency behavior
There is no single “best” architecture, but some design habits regularly produce better timing behavior. One is limiting perception outputs to function-relevant objects and regions rather than passing a broad semantic scene model into the ADB controller. Another is performing early rejection close to the sensor path so that the main controller is not overwhelmed by irrelevant candidates. A third is designing deterministic fallback logic for uncertain scenes instead of waiting for a perfect classification.
That last point deserves attention. In real nighttime driving, uncertain inputs are normal. If the system delays masking until it has high semantic confidence, the beam may remain too open for too long. A more robust strategy is to let optical cues trigger provisional beam shaping with bounded conservatism, then refine the mask as confidence improves. This is one of the places where smart optical perception low latency becomes more than a marketing phrase. Intelligent perception is not just about seeing more. It is about deciding when partial certainty is enough to act safely.
Sensor placement and optical path quality also matter more than many control discussions admit. Lens contamination sensitivity, flare resistance, optical alignment tolerance, and exposure control under point-source brightness all influence whether the perception stack starts with a trustworthy signal. If the signal quality collapses in realistic contamination or high-contrast scenes, no downstream acceleration fully recovers the lost time because the algorithm spends its budget repairing the image instead of interpreting it.
When comparing modules, use behavior-based criteria
It is tempting to compare modules by datasheet categories: sensor resolution, compute platform, number of controllable pixels, communication interface, and supported functions. Those items are relevant, but they do not necessarily predict on-road response. A behavior-based comparison is often more revealing.
For example, examine whether the beam mask expands and contracts smoothly when multiple opposing vehicles appear at different distances. Notice whether roadside reflective clutter causes unnecessary dimming. Watch how the module handles transitions where an oncoming car is first partially hidden, then suddenly exposed. Observe whether the system becomes conservative in rain to the point of reducing useful illumination, or whether it remains controlled without obvious late masking.
These observations are valuable because they reflect interaction between perception and actuation, not isolated subsystem strength. A module can look advanced on paper but still behave nervously if the timing path is fragile. Another module may have a less ambitious feature set yet prove easier to trust because its optical perception and ADB logic are tuned around consistent low-latency decisions.
Why sector intelligence still matters during technical review
Even a narrowly technical evaluation benefits from broader context. Exterior and vision systems do not evolve in isolation. Headlamp thermal behavior, sensor integration packaging, vehicle front-end styling constraints, and regional compliance expectations all influence which optical perception architecture is practical. A review process informed by the wider exterior and vision ecosystem is often better at identifying tradeoffs early, especially where optics, housing space, thermal limits, and control timing interact.
That is one reason industry observers focused on smart headlights, sensor switching logic, and vehicle exterior integration can be useful as reference points during assessment. Their value is not in making performance promises. It is in connecting adjacent topics that affect final behavior: optical matrix algorithms, packaging choices, thermal stability, and the way front-end components share physical and electronic constraints. For ADB modules, those links often explain why a theoretically fast system becomes less responsive once integrated into a real vehicle platform.
A more reliable path to judgment
If you are working through a difficult evaluation, the safer approach is not to chase the most complex perception stack. Start with timing visibility. Make sure the sensing chain, decision thresholds, synchronization strategy, and matrix actuation path can each be examined on their own terms. Then test under conditions that stress contrast, occlusion, and reflectivity rather than relying on ideal nighttime scenes.
In many reviews, the biggest improvement comes from changing the evaluation question itself. Instead of asking, “Can this module detect enough?” ask, “Can this module detect early enough, consistently enough, and with enough temporal discipline to support glare-free beam control?” That shift usually exposes whether the architecture was built around real driving response or around isolated feature capability.
For ADB control modules, low latency is not a finishing touch added after perception is complete. It begins in the optical path, continues through every processing handoff, and ends only when the beam changes on time. Once that is understood, technical assessment becomes less about headline specifications and more about whether the system can keep pace with the road in front of it.