
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
Dynamic Driving Perception in ADAS: What Data Fusion Solves on Urban Roads
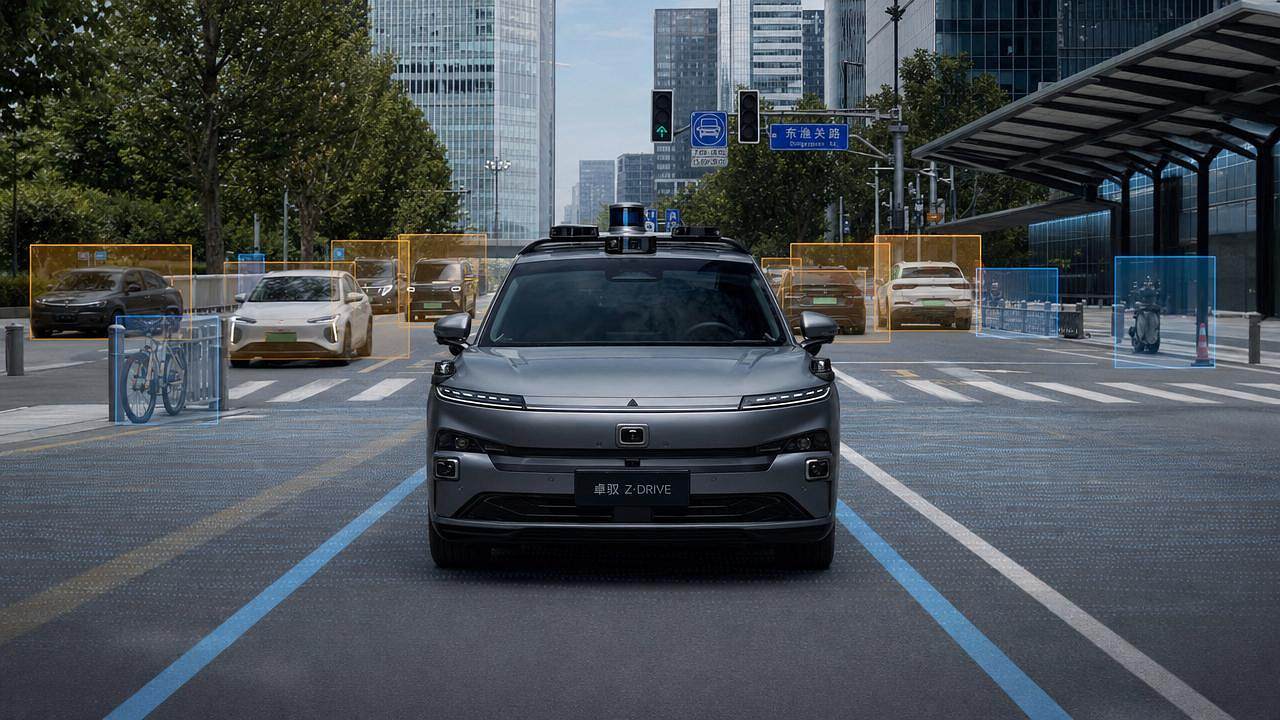
Why dynamic driving perception matters more on urban roads
Urban driving is where ADAS faces its hardest perception test.
Traffic density changes by the second. Pedestrians move unpredictably. Lane markings fade, split, or disappear under rain, glare, and construction dust.
That is why dynamic driving perception has become a central topic in advanced mobility research.
It is not only about seeing objects.
It is about understanding motion, intention, distance, and risk in real time.
For platforms such as AEVS, this issue also connects directly with exterior intelligence.
Smart headlights, sensor switches, wheel aerodynamics, and tire-road behavior all affect how reliably a vehicle senses and reacts.
So when people ask what data fusion solves in ADAS, the better question is broader.
How does dynamic driving perception stay trustworthy when the road is messy, fast, and inconsistent?
What does dynamic driving perception actually mean in ADAS?
In simple terms, dynamic driving perception is the vehicle’s ability to interpret a changing environment while it is moving.
Static recognition is not enough.
ADAS must estimate speed, trajectory, occlusion, road edge quality, and possible conflict points ahead.
A camera may identify a cyclist.
Radar may confirm closing speed.
Vehicle motion sensors may show the car is entering a tight turn on a wet surface.
Only together do these signals support a useful driving decision.
This is especially important in new energy vehicles, where quiet cabins, fast torque delivery, and heavier curb weights change response timing and braking expectations.
Dynamic driving perception therefore sits between sensing hardware and safe motion control.
It is one reason the industry increasingly treats optics, body electronics, ground contact, and control logic as one connected system.
Why can’t a single sensor handle urban uncertainty?
Because every sensor fails in a different way.
Cameras offer rich visual detail, but glare, fog, and low contrast can reduce confidence quickly.
Radar performs well in bad weather and detects velocity directly, yet it may struggle with fine object shape.
Lidar gives precise depth mapping, but cost, contamination, and integration complexity still matter.
Ultrasonic and body sensors add near-field awareness, but only within specific ranges.
On urban roads, those limitations overlap constantly.
A bus may block a pedestrian from one sensor but not another.
A reflective glass wall may confuse visual classification while radar still tracks motion.
This is the practical case for data fusion.
It does not make sensors perfect.
It reduces uncertainty by comparing signals, weighting confidence, and filtering contradictions before control actions are triggered.
A quick comparison helps clarify the point
This is where dynamic driving perception becomes more than object detection.
It becomes a confidence management problem.
What problems does data fusion solve in real city traffic?
The first problem is ambiguity.
Urban scenes are full of partial information, moving shadows, temporary barriers, and overlapping targets.
Data fusion helps decide whether a signal is noise, a hazard, or something in between.
The second problem is latency.
Different sensors update at different rates.
Fusion aligns time stamps and reduces gaps that can distort trajectory prediction.
The third problem is context.
A pedestrian near the curb is not always a crossing risk.
But if head orientation, walking direction, signal timing, and ego speed all align, the risk profile changes sharply.
The fourth problem is degraded conditions.
Rain on lenses, road spray, low sun angles, and nighttime glare all weaken isolated sensing.
A fused stack maintains better continuity.
In practice, stronger dynamic driving perception supports several urban functions:
- Safer cut-in and merge detection at intersections
- Earlier recognition of vulnerable road users
- More stable lane centering on poor road markings
- Fewer unnecessary alerts in crowded traffic
- Better braking decisions under changing grip conditions
That final point is often overlooked.
Tires, wheel behavior, and road friction matter because perception only creates value when the vehicle can execute safely.
How do exterior systems influence perception quality more than people expect?
This is where the AEVS perspective is useful.
Dynamic driving perception is not isolated inside a software stack.
It depends on the physical vehicle architecture surrounding the sensors.
LED headlight assemblies affect illumination range, glare control, and contrast recognition at night.
Smart optical systems can improve road edge visibility and reduce misread shadows.
Auto sensor switches matter because they automate wipers, lighting transitions, and localized sensing responses.
If rain is detected late, camera quality may already be compromised.
Wheel and tire systems also shape perception outcomes indirectly.
Low-drag wheel design changes brake airflow and contamination patterns around sensor zones.
High-performance tires influence stopping distance, yaw stability, and the confidence margin behind ADAS interventions.
Even electric sunroof systems can contribute through cabin NVH control and visibility comfort, though the effect is more indirect.
The broader lesson is clear.
Better dynamic driving perception depends on both algorithm quality and exterior-system integration.
What should be checked before judging a data fusion strategy?
A common mistake is focusing only on sensor count.
More devices do not guarantee better dynamic driving perception.
A stronger evaluation starts with a few practical questions.
In actual assessment, the strongest systems are rarely the ones with the most dramatic specifications.
They are usually the ones that remain predictable when conditions become ordinary but difficult.
Where do misunderstandings usually appear?
One misunderstanding is treating data fusion as a universal fix.
If poor calibration, dirty optics, or weak vehicle dynamics remain unresolved, fusion cannot fully recover performance.
Another is ignoring maintenance reality.
Urban durability involves vibration, thermal cycling, road salt, splash contamination, and sensor misalignment over time.
A third misunderstanding is assuming perception quality can be judged without looking at the full exterior package.
AEVS often emphasizes this cross-domain view for a reason.
Optical hardware, sensor placement, lighting design, airflow, wheel packaging, and tire behavior all contribute to how dynamic driving perception performs on the road.
There is also a cost misconception.
The real cost is not only hardware price.
It includes validation cycles, cleaning strategies, thermal design, software updates, and the burden of proving consistent behavior across scenarios.
So what is the practical takeaway for understanding dynamic driving perception?
The key takeaway is that dynamic driving perception is a system capability, not a single feature.
Data fusion solves a very specific urban problem.
It helps ADAS make reliable judgments when visibility, motion, and road conditions are incomplete or conflicting.
That value becomes clearer when perception is viewed alongside lighting, sensor switching, wheel airflow, and tire-road interaction.
For anyone tracking next-generation mobility, a useful next step is to compare systems by scenario, not by headline claims.
Check how they behave in glare, rain, occlusion, weak lane markings, and mixed traffic.
Then review whether the surrounding exterior architecture supports that performance consistently.
That is usually where the most credible progress in dynamic driving perception can be recognized.