
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
Dynamic Driving Perception in ADAS: Key Sensors, Data Fusion, and Failure Points
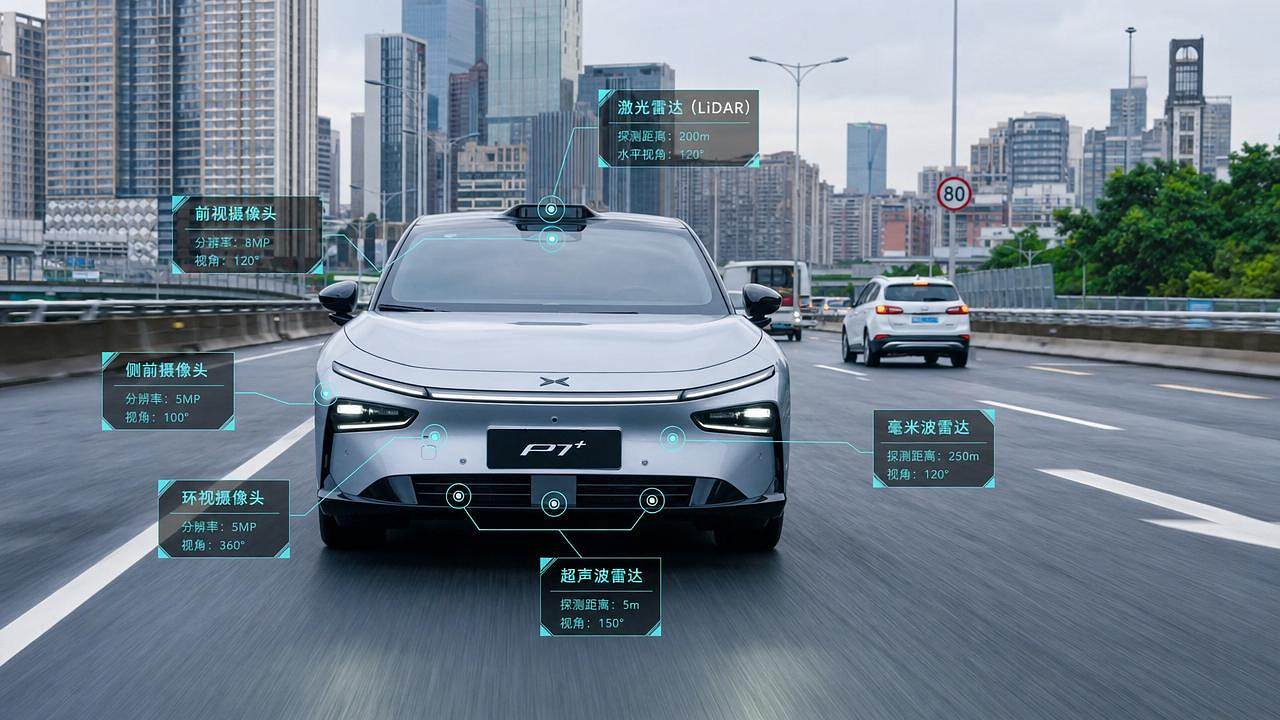
Dynamic driving perception sits at the center of advanced driver assistance systems because safe motion decisions depend on how accurately a vehicle understands distance, speed, road shape, object intent, and its own changing state. In real traffic, that understanding is rarely delivered by one sensor alone. It emerges from cameras, radar, LiDAR, ultrasonic units, inertial signals, wheel-speed data, lighting conditions, and tire-road interaction, all interpreted under tight time limits. That is why the topic matters not only for ADAS design, but also for evaluation, validation, and sourcing decisions across the intelligent vehicle chain.
For platforms shaped by electrification and software-defined architectures, dynamic driving perception has become even more sensitive. Heavier battery packs alter braking response, instant torque changes longitudinal behavior, and exterior components such as headlights, sensor covers, wheels, and tires directly influence what the perception stack can see and how confidently it can react. This broader systems view aligns closely with AEVS, where vehicle exterior engineering, optical perception, and driving quality are treated as interconnected rather than separate disciplines.
Why dynamic driving perception now carries more weight
ADAS is no longer judged by feature lists alone. Lane centering, forward collision warning, blind-spot monitoring, and automated emergency braking must perform consistently across sun glare, urban clutter, highway speed, and poor weather.
That consistency is difficult because perception quality changes from moment to moment. A clean sensor in mild daylight may classify a pedestrian correctly, while the same system can struggle when road spray, headlight bloom, or a dirty lens reduces signal quality.
The result is a market shift. More attention is moving toward sensor redundancy, fusion architecture, environmental robustness, and failure handling. These are practical concerns tied to compliance, liability, customer trust, and real vehicle behavior.
What the perception stack is really trying to solve
At a basic level, dynamic driving perception answers four questions at once: what is around the vehicle, where it is, how it is moving, and what may happen next.
Those questions sound simple, yet each depends on different data qualities. Detection needs visibility or reflectivity. Tracking needs temporal stability. Prediction needs context. Control support needs low latency and confidence scoring.
A strong ADAS stack therefore does more than detect objects. It estimates free space, road edges, lane semantics, relative velocity, surface conditions, and possible conflict trajectories. When any layer becomes uncertain, decision quality drops.
Sensor roles are complementary, not interchangeable
Cameras deliver texture, color, lane markings, traffic signs, and vulnerable road user cues. They are essential for semantic understanding, but they are vulnerable to glare, darkness, contamination, and reduced contrast.
Radar excels at measuring distance and relative speed in rain, fog, and darkness. It is strong for tracking moving targets, though object shape and classification detail are limited compared with vision.
LiDAR provides dense three-dimensional geometry and supports precise spatial modeling. Its strengths are especially useful in complex edge cases, but performance depends on cost targets, integration strategy, weather tolerance, and cleaning effectiveness.
Vehicle-state inputs are equally important. Steering angle, wheel speed, yaw rate, brake pressure, and IMU data stabilize the scene model. Without them, even good external sensing can drift during aggressive maneuvers.
How data fusion turns separate signals into driving confidence
Dynamic driving perception becomes useful only after fusion. Raw sensor outputs must be synchronized, aligned in space, weighted by confidence, and interpreted against a common scene model.
In practice, fusion can happen at several levels. Early fusion combines lower-level features. Mid-level fusion merges detections and tracks. Late fusion compares higher-level decisions from independent pipelines.
Each approach carries trade-offs. Early fusion may capture richer correlations, but it demands stronger calibration and computing discipline. Late fusion is often easier to manage, yet it can miss subtle cross-sensor cues.
The strongest implementations do not assume every sensor is always correct. They continuously estimate trustworthiness. If camera confidence falls during low sun, radar may carry more weight for target tracking. If radar reflections become ambiguous in dense traffic, vision or LiDAR may refine the scene.
Failure points usually begin outside the algorithm
When dynamic driving perception fails, the root cause is often physical before it becomes computational. A poorly placed sensor, a reflective cover, thermal stress, headlight flare, or road splash can degrade perception long before software makes a wrong decision.
Environmental and exterior-related weak spots
- Glare and bloom from low sun, wet pavement, or oncoming LED sources can reduce camera contrast and distort lane detection.
- Rain, fog, snow, and road spray weaken optical sensing and can introduce noisy radar reflections.
- Mud, salt, insect residue, and ice on lenses or radomes create gradual performance loss that may not trigger immediate fault flags.
- Thermal drift alters calibration stability, especially around tightly packaged front-end modules and smart headlight assemblies.
This is where vehicle exterior engineering matters more than many teams expect. Headlight optical behavior affects camera exposure. Wheel and tire spray characteristics influence contamination patterns. Front fascia materials affect radar transparency. Even aerodynamic flow can change how quickly a sensor surface gets dirty.
That systems linkage explains why AEVS pays attention not only to optics and sensing, but also to aluminum wheels, tires, and exterior architectures. Dynamic driving perception lives at the intersection of software intelligence and hardware reality.
Timing, calibration, and edge-case logic
Not every failure is visible. Some emerge through timing mismatches measured in milliseconds. If radar tracks are fresh but camera frames are delayed, the fused object path may appear stable while already being wrong.
Calibration drift is another quiet issue. Small mounting deviations, vibration, bumper replacement, or suspension changes can affect spatial alignment. In an EV with different load states, ride-height variation can also influence perception geometry.
Then there are classification edge cases. A plastic barrier, tire tread on the road, a motorcycle emerging from shadow, or a pedestrian partly hidden by an A-pillar can challenge even advanced fusion models.
Where evaluation should focus in practical programs
A useful review of dynamic driving perception goes beyond sensor specifications. It asks how the full stack behaves when data quality degrades, scenes become ambiguous, and vehicle dynamics shift.
- Check confidence management, not only nominal accuracy. Systems should explain when certainty drops and how fallback logic responds.
- Review contamination strategy, including lens cleaning, heating, diagnostics, and degradation detection thresholds.
- Assess synchronization between external sensors and vehicle-state signals under braking, cornering, and rough-road vibration.
- Test day, night, wet, and mixed-light conditions rather than relying on daytime benchmark performance.
- Compare perception quality with different tire compounds, wheel airflow patterns, and front-end packaging choices where relevant.
This wider lens is especially valuable in NEV programs. Lightweighting goals, aerodynamic drag reduction, thermal packaging, and premium lighting functions can all improve the vehicle while also changing the boundary conditions for perception.
Business value beyond the ADAS control unit
Dynamic driving perception has direct commercial implications. Better perception robustness can reduce false interventions, improve feature acceptance, support regulatory readiness, and lower validation rework late in the program.
It also creates a stronger basis for cross-functional decisions. Smart headlight thermal design, sensor switch performance, tire wet grip behavior, and wheel aerodynamics should not be reviewed as isolated procurement lines when they influence perception quality.
From that perspective, intelligence platforms such as AEVS become useful not because they promote one subsystem, but because they connect optical algorithms, exterior hardware, compliance trends, and material realities into a decision-ready picture.
A clear next step for better judgment
The most reliable way to judge dynamic driving perception is to build a structured review matrix that links sensor capability, fusion logic, exterior integration, environmental stress, and fallback behavior. That matrix should be grounded in real use cases, not brochure claims.
A practical starting point is to map likely failure points by scene: glare at intersections, heavy spray on highways, nighttime cut-ins, dirty winter roads, and partial sensor blockage. Then compare how different architectures detect degradation and preserve safe response.
As ADAS moves closer to broader autonomy, dynamic driving perception will remain a deciding factor in both safety credibility and product differentiation. The next evaluation step is not simply choosing more sensors. It is understanding how the entire vehicle helps those sensors perceive, agree, and fail safely.