
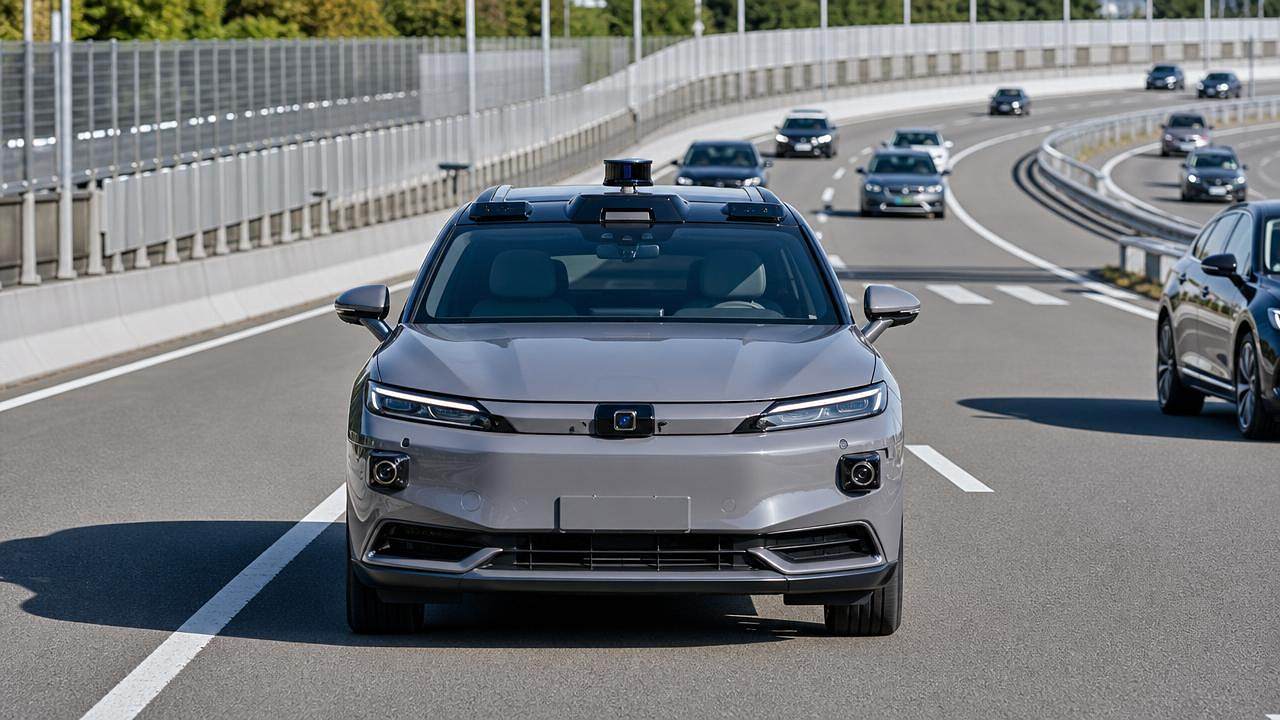
Dynamic Driving Perception for ADAS: Sensor Fusion Use Cases and Risks
Dynamic driving perception is now a program-level capability, not a feature-level experiment. ADAS success depends on how reliably sensors become decisions.
For engineering project leaders, the central question is not whether to add more sensors, but whether fusion improves safety, timing, and cost.
Camera, radar, lidar, ultrasonic sensing, lighting intelligence, and vehicle network data must work as one validated perception layer under changing road conditions.
This article focuses on practical use cases, integration trade-offs, hidden risks, and planning criteria that affect ADAS readiness from concept to production.
Why Dynamic Driving Perception Matters to ADAS Program Decisions
Dynamic driving perception describes the vehicle’s ability to understand moving scenarios continuously, including lanes, objects, intent, visibility, road friction, and driver context.
For ADAS programs, perception is valuable only when it remains dependable during rain, glare, occlusion, high speed, poor markings, and mixed traffic.
Project managers should treat perception as a system architecture issue. It affects sensor selection, ECU loading, network design, validation cost, and safety cases.
A stronger perception layer can support better lane keeping, adaptive cruise, collision avoidance, blind-spot monitoring, automatic lighting, and parking assistance.
However, more perception does not automatically mean better performance. Poorly integrated sensors can increase latency, conflicting detections, software complexity, and warranty exposure.
The real objective is balanced confidence. The ADAS system must know what it sees, what it does not see, and when uncertainty increases.
The Real Search Intent: Reducing ADAS Uncertainty Before Production
Most teams researching dynamic driving perception are not seeking definitions. They need evidence for architecture choices, risk planning, and supplier alignment.
Engineering leads want to know which fusion approach fits their safety goals, vehicle segment, cost target, launch timing, and regulatory expectations.
Program managers are also concerned about late design changes. Sensor packaging, lens contamination, wiring, software timing, and validation gaps often surface late.
The most useful evaluation is scenario-based. Teams should ask which real driving cases require fusion, and which can be solved with simpler sensing.
That framing prevents overspecification. It also makes trade-off discussions clearer between OEM teams, Tier 1 suppliers, optics specialists, and vehicle integration engineers.
Core Sensor Roles in a Fusion-Based Perception Stack
Cameras provide rich semantic information, including lane markings, traffic signs, vehicle classification, pedestrians, cyclists, and traffic light interpretation.
Their weakness is environmental dependence. Low sun, darkness, fog, dirt, snow, and heavy rain can reduce image quality or confuse recognition models.
Radar is strong for range and relative velocity. It performs well in poor weather and supports adaptive cruise, collision warning, and blind-spot detection.
Radar may struggle with object shape, elevation separation, and stationary clutter. Without complementary sensing, it can misinterpret roadside structures or metal reflections.
Lidar offers precise three-dimensional geometry and can strengthen object localization. It is useful for higher-level automation and complex urban scenarios.
Its challenges include cost, packaging, cleaning, thermal management, and performance degradation under certain weather or contamination conditions.
Ultrasonic sensors remain important for low-speed maneuvers. Parking, close obstacle detection, and short-range side monitoring still benefit from their low-cost robustness.
Vehicle network signals add context. Steering angle, yaw rate, wheel speed, brake status, wiper activation, lighting mode, and tire behavior improve interpretation.
Use Case 1: Forward Collision Warning and Automatic Emergency Braking
Forward collision warning and AEB are among the clearest cases where dynamic driving perception must be accurate, fast, and explainable.
Camera and radar fusion helps distinguish vehicles, pedestrians, cyclists, motorcycles, and roadside objects while estimating closing speed and collision probability.
The project challenge is threshold management. A late braking command increases safety risk, while false braking can harm trust and create secondary hazards.
Fusion must also handle cut-in vehicles, partial occlusion, parked vehicles near lanes, low sun, road spray, and heavy stop-and-go traffic.
Engineering leaders should validate both detection performance and timing. A highly accurate model is insufficient if system latency reduces available braking distance.
Use Case 2: Lane Keeping, Road Edge Detection, and Highway Assistance
Lane keeping seems camera-led, but real-world reliability often depends on additional context from map data, radar targets, and vehicle motion signals.
Dynamic driving perception becomes critical when lane markings are faded, temporarily covered, misaligned during roadwork, or confused by shadows and tar lines.
Fusion can help infer drivable space using preceding vehicles, guardrails, curbs, road edges, and trajectory history when markings become unreliable.
The risk is overconfidence. If the system estimates a lane where no valid lane exists, steering assistance can become uncomfortable or unsafe.
Program teams should define degradation behavior early. The vehicle must transition gracefully from assisted control to driver responsibility under uncertainty.
Use Case 3: Blind-Spot Monitoring and Lane Change Assistance
Blind-spot functions rely heavily on radar, but dynamic driving perception improves when radar is combined with cameras and vehicle trajectory prediction.
Relevant scenarios include fast motorcycles, merging vehicles, curved roads, multi-lane traffic, and objects hidden by body geometry or mirror limitations.
Sensor placement becomes a program issue. Rear bumper styling, wheel arch geometry, mud, snow, repair tolerances, and radar cover materials affect performance.
For project managers, the key question is whether the system only detects presence or also predicts closing risk and lane-change conflict.
False negatives are safety-critical, but excessive false positives reduce driver trust. Validation must include regional driving habits and lane discipline differences.
Use Case 4: Smart Lighting and Vision-Linked Exterior Systems
Smart headlights show how exterior systems and perception are increasingly connected. Matrix LED control depends on detecting vehicles, pedestrians, road curvature, and visibility.
Dynamic driving perception enables adaptive beam shaping, anti-glare masking, road guidance projection, and better illumination during turning or poor weather.
However, lighting decisions carry regulatory and safety implications. Incorrect object detection can glare oncoming drivers or leave hazards insufficiently illuminated.
Optical sensors, cameras, rain sensors, steering input, speed, and navigation data can work together to improve lighting response.
AEVS views this as a strategic exterior intelligence issue, where optical algorithms, thermal design, compliance, and perception validation must be integrated.
Use Case 5: Parking, Low-Speed Automation, and Near-Field Safety
Parking functions require a different perception balance. Near-field accuracy, short reaction time, low-speed control, and obstacle classification matter more than long-range prediction.
Ultrasonic sensors, surround cameras, short-range radar, and vehicle body signals can detect walls, pillars, curbs, children, pets, and shopping carts.
The most common risks are low obstacles, transparent surfaces, unusual curb shapes, tight spaces, sensor contamination, and poor lighting conditions.
For engineering leads, parking perception should be validated with real geometries, not only standardized targets in clean test environments.
Integration with exterior components is also important. Sensor covers, paint thickness, bumper repair, and mounting tolerances can change detection performance.
Choosing a Fusion Architecture: Early, Late, or Hybrid
Early fusion combines raw or low-level sensor data before object interpretation. It can improve richness but demands tight calibration and high computing capacity.
Late fusion combines independently processed object lists. It is often easier to integrate, but may lose information already discarded by each sensor pipeline.
Hybrid fusion mixes both approaches. Many production programs use hybrid strategies to balance performance, modularity, supplier boundaries, and validation practicality.
The best architecture depends on functional scope. A cost-sensitive Level 1 system may not need the same fusion depth as highway pilot features.
Project leaders should compare architectures using measurable criteria: detection confidence, latency, failure isolation, supplier responsibility, cybersecurity exposure, update strategy, and test effort.
Latency and Timing: The Hidden Constraint Behind Perception Quality
Dynamic driving perception is time-sensitive. A correct object classification may still be unsafe if delivered too late for braking or steering action.
Latency comes from sensor capture, synchronization, preprocessing, neural inference, fusion logic, communication buses, decision algorithms, and actuator response.
Teams should define timing budgets for each ADAS function. AEB, lane centering, blind-spot warnings, and parking assistance require different tolerances.
Timestamp accuracy and sensor synchronization are especially important. Misaligned camera and radar data can create false positions during high-speed movement.
Program managers should insist on end-to-end latency measurement, not only component-level claims from individual sensor or software suppliers.
Calibration, Packaging, and Exterior Integration Risks
Sensor fusion assumes sensors agree about geometry. Calibration errors can make the system believe an object is closer, farther, or offset laterally.
Exterior design can create unexpected perception risks. Lens angle, radar cover material, wheel spray, sunroof reflections, lighting glare, and body styling all matter.
Production tolerances also influence performance. A sensor calibrated perfectly in development may behave differently after assembly variation, repair, vibration, or minor collision.
Cleaning strategy deserves early attention. Cameras, lidar windows, radar covers, and ultrasonic surfaces can degrade from dust, ice, road salt, insects, or film.
AEVS encourages cross-functional design reviews between exterior architects, optical engineers, tire dynamics specialists, electronics teams, and ADAS validation leaders.
Validation Scope: What Must Be Tested Beyond the Happy Path
Validation is where perception ambitions often meet budget reality. Dynamic driving perception requires scenario coverage across weather, geography, traffic, and driver behavior.
Core scenarios include cut-ins, cut-outs, emergency braking ahead, vulnerable road users, night driving, tunnels, construction zones, wet roads, and complex intersections.
Edge cases deserve special attention because they expose fusion weaknesses. Examples include radar ghost targets, camera glare, lidar reflections, and conflicting sensor classifications.
A strong validation plan combines simulation, proving ground tests, fleet data, hardware-in-the-loop testing, software-in-the-loop testing, and production audits.
Project managers should track scenario maturity, not only kilometers driven. Ten thousand repetitive highway miles may reveal less than targeted urban edge cases.
Safety Risks and Failure Modes Project Leaders Should Monitor
The biggest safety risk is not sensor failure alone. It is an undetected mismatch between perceived environment and actual driving reality.
Common failure modes include object misclassification, missed detection, duplicated objects, wrong velocity estimation, incorrect lane assignment, and delayed threat prioritization.
Fusion systems can also create authority problems. When sensors disagree, decision logic must know which source to trust under which condition.
Degradation strategy is critical. The system should reduce functionality, alert the driver, or shift modes when confidence falls below defined thresholds.
Safety cases should document assumptions clearly. These include operational design domain, sensor availability, contamination tolerance, driver monitoring dependencies, and maintenance expectations.
Cost, Supplier Strategy, and Return on Integration Effort
Adding sensors increases bill of materials, wiring, compute demand, thermal load, software complexity, and validation cost. Benefits must justify the added burden.
For premium vehicles, advanced fusion may support brand differentiation, safety ratings, smart lighting, and future software-defined feature upgrades.
For mass-market models, the best return may come from robust camera-radar fusion, carefully packaged sensors, and disciplined scenario validation.
Supplier strategy matters. Fragmented sensor sourcing can reduce component cost but increase integration risk, interface disputes, and accountability gaps.
Project leaders should define ownership for calibration, fusion logic, diagnostics, over-the-air updates, cybersecurity, and post-repair service procedures.
A Practical Decision Framework for ADAS Planning
Start with use cases, not sensors. Define the ADAS functions, operating conditions, safety goals, customer value, and regional compliance needs.
Next, map each scenario to required perception capabilities. Identify range, resolution, classification, velocity accuracy, redundancy, and acceptable response time.
Then select sensor combinations that satisfy these needs with realistic cost, packaging, compute, and validation implications.
Assess failure behavior early. Teams should know how the system reacts to sensor blockage, degraded visibility, calibration drift, and conflicting detections.
Finally, build a validation roadmap tied to program milestones. Perception confidence should mature alongside hardware freezes, software releases, and production readiness.
Conclusion: Treat Perception as a Vehicle-Level Capability
Dynamic driving perception is becoming one of the defining capabilities of competitive ADAS programs, especially as vehicles combine exterior intelligence and automation.
The winning approach is not simply maximum sensing. It is the right fusion architecture, validated against real scenarios, with clear degradation logic.
For project managers and engineering leads, the priority is disciplined trade-off management across safety, latency, cost, packaging, compliance, and customer trust.
When perception is planned as a vehicle-level capability, ADAS programs gain stronger performance, fewer late surprises, and a clearer path to production confidence.