
Industry Portal
Related News
- 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems
Why thermal management models matter in drive motor safety
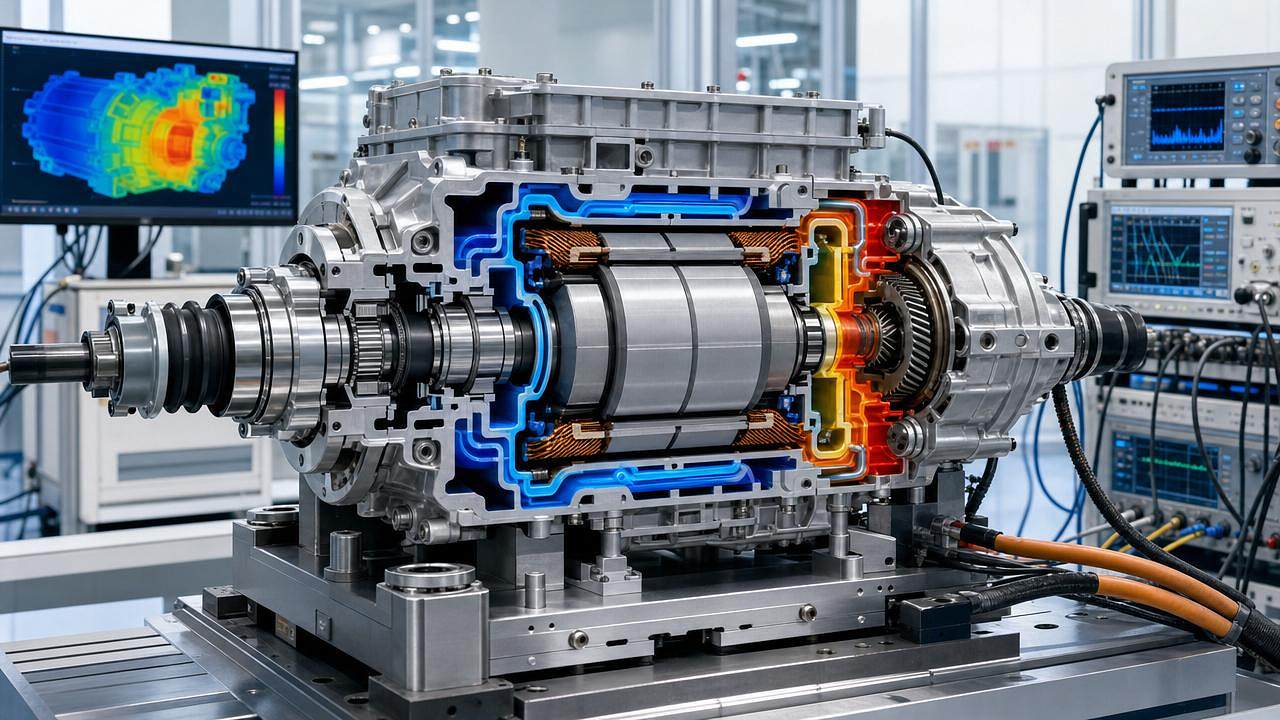
In drive motor safety, thermal management models are more than engineering tools—they are a critical line of defense for quality and safety teams. By showing heat distribution, overload risk, and failure patterns under real operating conditions, these models help prevent thermal runaway, protect reliability, and support safer, more compliant NEV performance.
Why checklist-based evaluation matters for drive motor safety
Drive motors operate at the intersection of torque demand, inverter switching, cooling limits, and packaging constraints. A small thermal error can trigger insulation aging, magnet demagnetization, bearing damage, or reduced system efficiency.
That is why thermal management models should be reviewed through a practical checklist. A structured approach helps connect simulation outputs with test data, control strategy, compliance targets, and field durability expectations.
For a platform focused on intelligent vehicle systems, this topic also links with broader exterior and perception trends. Efficient thermal behavior supports range, power consistency, lighting stability, and overall safety performance across modern NEV architectures.
Core checklist for thermal management models
- Define operating boundaries early, including peak torque, repeated acceleration, hill climb, fast charging interaction, ambient extremes, and stop-go duty cycles.
- Map heat sources precisely across windings, rotor, stator core, bearings, inverter interfaces, and cooling jackets instead of treating the motor as one lumped body.
- Validate assumptions with test benches, road loads, and transient measurements so thermal management models reflect real loss behavior and actual coolant performance.
- Track hotspot movement over time, because maximum temperature alone cannot reveal where insulation breakdown, adhesive failure, or magnet degradation begins.
- Include aging effects in materials, seals, thermal interface layers, and coolant flow paths to avoid optimistic predictions after long mileage exposure.
- Link models to control logic, including derating thresholds, warning triggers, limp-home modes, and sensor plausibility checks under noisy conditions.
- Compare multiple cooling strategies, such as water jacket design, oil spray, shaft cooling, and integrated e-axle packaging tradeoffs.
- Assess fault scenarios explicitly, including blocked channels, pump degradation, sensor drift, connector resistance increase, and high-humidity operation.
- Review coupling with adjacent systems, because battery heating, underbody airflow, wheel-end heat, and headlight power loads can alter thermal balance.
- Document calibration limits clearly so design, validation, and aftersales teams can interpret model outputs without overstating safety margins.
What thermal management models should reveal
Useful thermal management models do not stop at average temperature plots. They should reveal transient overload tolerance, thermal lag, local hotspots, and the time gap between sensor readings and actual material stress.
They should also support decision-making. That includes choosing copper fill ratio, insulation class, coolant routing, housing geometry, and safe derating thresholds before late-stage validation becomes expensive.
Key outputs worth checking
- Temperature distribution by component and by time step, not just steady-state snapshots.
- Sensitivity to ambient temperature, altitude, contamination, and coolant flow variation.
- Correlation between electrical losses, mechanical losses, and cooling response delay.
- Failure threshold proximity during aggressive drive cycles and regenerative braking events.
Application notes across different scenarios
High-performance urban EV platforms
Urban EVs face frequent launch events, regenerative transitions, and repeated low-speed thermal soak. In this case, thermal management models must capture short bursts and poor airflow conditions.
If the model only emphasizes highway cruising, it may miss winding hotspot accumulation during delivery-style driving or dense traffic in summer conditions.
Integrated e-axle systems
In compact e-axles, thermal interaction is stronger because the motor, gearbox, and power electronics share limited space. Heat rejection paths compete with NVH, sealing, and lightweight packaging goals.
Here, thermal management models should include enclosure conductivity, lubricant behavior, and cross-heating from nearby electronics to avoid misleading isolation assumptions.
Cold climate and high-humidity use
Low temperatures can reduce immediate thermal risk but create other problems. Viscosity changes, condensation, and sensor inaccuracy may distort actual thermal control performance.
A robust model should therefore simulate warm-up phases, moisture exposure, and intermittent load spikes instead of assuming a stable thermal baseline.
Heavy wheel and tire configurations
Vehicle exterior choices can influence motor thermal loads indirectly. Larger wheels, higher grip tires, and aerodynamic drag changes alter torque demand, regenerative behavior, and cooling airflow underbody patterns.
This is especially relevant for intelligence platforms such as AEVS, where wheel design, tire dynamics, and optical system power loads intersect with total vehicle efficiency and safety.
Commonly overlooked items and risk warnings
Ignoring sensor placement bias
A temperature sensor rarely sits at the true hotspot. If thermal management models are calibrated to convenient sensor locations only, risk margins may appear safer than they are.
Underestimating transient overload damage
Short overload events may not breach steady-state limits, yet they can accelerate varnish aging and magnet weakening. Damage often accumulates before visible faults appear.
Treating cooling hardware as constant
Pump wear, partial blockage, coolant contamination, and thermal interface degradation all change heat transfer over time. Static assumptions reduce the credibility of long-life safety predictions.
Separating thermal and control validation
A sound physical model still fails operationally if derating logic reacts too late, oscillates, or creates unstable driver response under repeated thermal events.
Practical execution advice
- Start with a reduced-order model for fast concept screening, then refine critical regions with detailed CFD or multi-physics simulation.
- Run paired validation using bench cycles and vehicle-level data so model confidence is built under both controlled and dynamic conditions.
- Set pass-fail gates for hotspot error, thermal response time, and derating trigger accuracy before design freeze.
- Review model updates after wheel, tire, aero, or software changes because thermal balance can shift across the whole vehicle system.
- Use the same thermal language across design, testing, and quality reviews to keep decisions traceable and safety-focused.
Conclusion and next-step guidance
The value of thermal management models in drive motor safety lies in prediction, not paperwork. Good models identify where heat starts, how it moves, when control action is needed, and which failures are most likely under real use.
A checklist-based review keeps this work grounded. It turns simulation into a decision tool for material choice, cooling design, software protection, and lifecycle reliability.
As NEV systems become more integrated, thermal decisions no longer belong to the motor alone. They affect range, safety, exterior packaging, optical electronics, and total driving quality.
The next step is simple: audit the current model against real operating boundaries, validate hotspots with measured data, and close any gap between predicted temperature and actual protection behavior.