
Industry Portal
Related News
- 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions - 00
0000-00
Private Label Tire Export: Evaluating Suppliers, Compliance, and Landed Cost - 00
0000-00
DOT-Compliant Truck Lighting: A Practical Guide to FMVSS 108 Requirements
Why thermal management models fail in real driving cycles
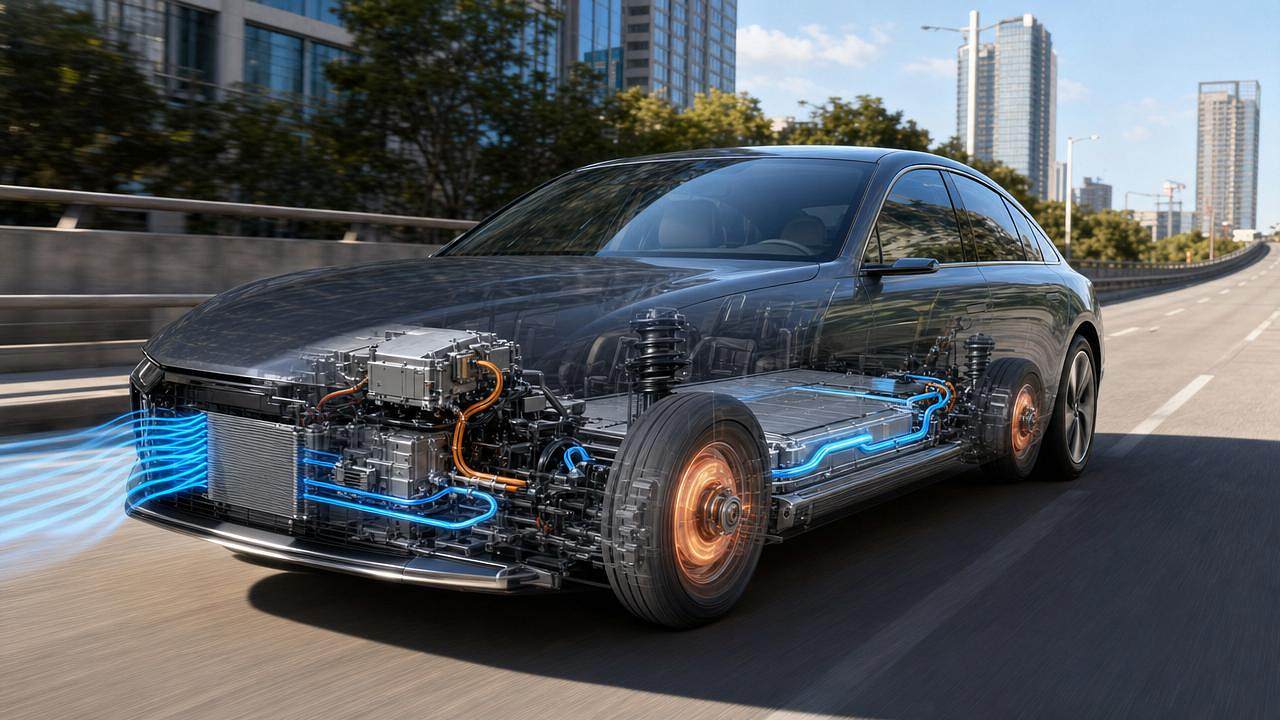
Why do thermal management models often perform well in simulation yet break down under real driving cycles? For technical evaluators in the automotive sector, this gap is more than a calibration issue—it directly affects component reliability, energy efficiency, and safety validation. This article examines the hidden assumptions, transient load mismatches, and multi-system interactions that cause thermal management models to fail when laboratory logic meets real-world vehicle dynamics.
What technical evaluators are really trying to determine
The core search intent behind “why thermal management models fail in real driving cycles” is not academic curiosity. Technical evaluators want to know why a model that appears validated still mispredicts temperatures, derating, or component stress on the road.
They are usually assessing whether a thermal model is decision-grade. In other words, can it support design release, safety margins, supplier comparison, compliance evidence, and durability forecasts under realistic vehicle use rather than idealized test sequences?
For this audience, the most important questions are practical. Which assumptions are breaking, which operating domains are underrepresented, how large the prediction error can become, and what evidence is sufficient to trust or reject the model.
That means an effective article should focus less on textbook heat transfer theory and more on model failure mechanisms, detection methods, validation gaps, and improvement paths across real automotive operating conditions.
Why thermal management models look accurate in simulation first
Most thermal management models are built around controlled boundary conditions. Ambient temperature, vehicle speed, solar load, airflow distribution, drive power, and component duty cycles are often simplified to make simulation tractable and repeatable.
Those simplifications are not inherently wrong. In early development, they are useful because they reduce dimensionality, accelerate iteration, and make parameter tuning easier across batteries, e-drive units, lighting systems, tires, brakes, and sensor-adjacent electronics.
The problem emerges when model confidence grows faster than model coverage. A model can fit bench data, wind tunnel runs, or a standard drive trace very well while still missing the thermal behavior caused by irregular traffic, driver behavior, road surface, weather, and control interactions.
In automotive programs, this is common because simulation environments reward stability and repeatability, while real driving cycles are defined by variability, abrupt transitions, and competing subsystem priorities.
The biggest reason models fail: transient loads are underestimated
Real driving is transient, but many thermal management models are still structured around quasi-steady assumptions. They may capture average loads reasonably well while failing during sharp accelerations, regenerative braking events, stop-and-go traffic, hill climbs, towing, or repeated high-power pulses.
Transient mismatch matters because temperature does not respond only to average power. It responds to timing, thermal inertia, localized heat concentration, material interfaces, and delayed control reactions across the system.
For example, a battery loop may appear sufficient over a standardized cycle, yet cell edge temperatures can overshoot in urban congestion after repeated acceleration bursts and low ram-air availability. The average pack temperature may look acceptable while local hotspots exceed durability thresholds.
Similarly, LED headlight assemblies can pass laboratory thermal checks under fixed electrical loads, but real on-road usage introduces ambient swings, contamination, reduced convective cooling, and variable activation of adaptive matrix functions that alter heat density in ways the original model did not represent.
Boundary conditions in the real world are rarely what the model assumes
Many failures start with boundary conditions that are technically reasonable but operationally incomplete. Vehicle speed is often treated as a clean proxy for cooling airflow, but actual underbody, wheelhouse, grille, and lamp-cavity flow fields are far more complex.
Crosswinds, drafting, splash, road debris accumulation, grille shutter logic, ride height variation, and component packaging changes all influence thermal paths. Even small geometric differences can alter convection coefficients enough to shift real temperatures beyond the simulated range.
This issue is especially relevant for exterior and vision-related components. Low-drag wheel designs, brake airflow, tire cavity heat buildup, and compact sensor housings all sit inside aerothermal environments that are highly sensitive to local turbulence and contamination.
As a result, thermal management models built from nominal airflow maps often become unreliable when transferred between prototypes, trims, regions, or supplier variants. The model may be internally consistent but externally fragile.
Control strategy interactions are often modeled too simply
A vehicle thermal system is not just physics; it is also software. Pumps, valves, fans, shutters, compressors, lighting controllers, battery protection logic, and torque management all interact dynamically. Many model failures occur because these controls are represented too ideally.
In simulation, actuators may respond instantly, sensors may be noise-free, and control thresholds may be deterministic. On the road, however, there are delays, hysteresis, sensor drift, arbitration conflicts, and fallback modes.
These details matter because thermal outcomes are shaped by decisions, not only by loads. A coolant loop that should switch early may switch late due to filtering logic. A fan request may be limited by acoustic constraints. Headlamp power may be reduced to protect thermal margins while interacting with visibility requirements.
When those controls are simplified, the model tends to underpredict thermal excursions and overpredict system stability. Technical evaluators should therefore treat a well-correlated physical model with suspicion if its embedded control logic is idealized.
Component-level accuracy does not guarantee vehicle-level accuracy
Another common mistake is assuming that accurate submodels automatically create an accurate system model. In practice, a well-tuned battery model, wheel thermal model, lamp thermal model, or HVAC model can still produce poor results once integrated.
This happens because coupling effects are nonlinear. Cabin cooling demand changes compressor usage, which affects electrical load, which alters battery temperature, which influences power availability, which changes drive behavior and airflow conditions across the vehicle.
Exterior systems add further complexity. Wheel design affects brake cooling and local air motion. Tire rolling resistance changes energy use and heat generation. Sensor covers and lamp enclosures influence local thermal soak. These interactions are easy to miss if teams validate in organizational silos.
For technical evaluators, this means one of the best risk indicators is not whether each subsystem passed its own validation, but whether the integrated model was tested during competing high-demand scenarios.
Real driving cycles expose spatial non-uniformity that simple models hide
Many thermal management models track bulk temperatures well enough but miss spatial gradients. Yet reliability failures often come from local extremes rather than system averages.
Battery packs develop cell-to-cell variation. Tires show shoulder-to-center differences depending on inflation, load, and road texture. Lighting modules can have hotspots near drivers, emitters, or optical coatings. Sensor housings may see sun-facing thermal asymmetry.
If the model architecture is too lumped, these gradients disappear mathematically. The simulation then reports safe average conditions even while local regions cross adhesive, polymer, coating, or semiconductor limits in the field.
This is one reason thermal management models sometimes seem “almost correct” but still fail validation. They capture the right trend while missing the actual failure location and trigger.
Environmental variability is broader than standard validation windows
Standard validation matrices cannot cover every climate, altitude, traffic condition, and driver behavior pattern. Yet thermal performance is highly sensitive to exactly those variables.
Humidity, solar angle, wet roads, dust loading, altitude-related air density changes, and seasonal tire behavior can all shift heat rejection and thermal absorption. For electric vehicles, auxiliary loads such as demisting, heated surfaces, and lighting functions further broaden the operating space.
Because of this, models validated against narrow environmental windows often fail when exported globally. A model calibrated in moderate European conditions may not hold in Gulf heat, Southeast Asian urban congestion, or North American mixed suburban-highway usage.
Technical evaluators should therefore distinguish between “validated within the test plan” and “robust across deployment conditions.” These are not the same claim, even if they are often presented as though they were.
Data quality problems quietly undermine model credibility
Sometimes the issue is not the thermal model structure itself but the data used to build and validate it. Sensor placement, sampling rate, thermal lag, wiring noise, and synchronization errors can distort both calibration and correlation results.
A temperature sensor mounted slightly away from the hotspot may systematically underreport severity. A low sampling rate can miss transient peaks. A vehicle-speed channel that is not time-aligned with thermal data can create false confidence in airflow-dependent predictions.
Bench and road data can also differ in instrumentation fidelity. Laboratory setups usually provide cleaner, denser signals than production-like vehicle tests. If the model is trained in one environment and judged in another, discrepancies may reflect data architecture as much as thermal physics.
For evaluators, a key question is whether the model was validated against the temperatures that matter physically or merely against the temperatures that were easiest to measure.
How to recognize when a thermal management model is not decision-ready
Several warning signs indicate that a model may be insufficient for technical evaluation. One is strong correlation on standard cycles paired with unexplained error during aggressive or interrupted driving. Another is accurate average temperature prediction with poor peak prediction.
A third warning sign is excessive dependence on tuning factors that lack physical transparency. If convection multipliers, correction coefficients, or generalized safety offsets dominate correlation, the model may be compensating for missing mechanisms rather than representing them.
Other red flags include narrow validation domains, poor transferability across trims, sensitivity to initial conditions, and limited representation of control logic edge cases. These issues do not always make the model unusable, but they do reduce its value for release-critical decisions.
In procurement or supplier assessment, technical evaluators should also watch for models that appear polished in presentation but lack traceable assumptions, uncertainty bounds, and failure-domain disclosure.
What a more reliable validation approach looks like
Improving thermal management models does not always require maximum complexity. It requires better alignment between model assumptions and the decisions the model is expected to support.
First, validation should include transient-rich real driving cycles, not only standard traces. This means combining urban stop-and-go, repeated accelerations, hill loads, hot soak recovery, mixed weather exposure, and subsystem overlap events.
Second, evaluators should require both temporal and spatial correlation metrics. Average error alone is insufficient. Peak error, time-to-peak, hotspot location accuracy, and control-response timing often matter more for reliability and safety assessment.
Third, multi-system interaction tests should be deliberate. Thermal loads should be evaluated when lighting, HVAC, battery conditioning, braking, and sensor functions compete for energy, airflow, or cooling capacity.
Fourth, uncertainty should be explicit. A useful model does not need to be perfect, but its confidence limits must be known. Decision-makers need to understand where the model is predictive, where it is indicative, and where it is not yet reliable.
Why this matters for exterior, vision, and adjacent vehicle systems
In the AEVS landscape, thermal modeling is not confined to batteries and power electronics. It directly affects smart headlights, sensor reliability, wheel and brake aerothermal behavior, tire performance, and the broader energy efficiency of vehicle exterior systems.
For LED headlight assemblies, thermal errors can reduce luminous stability, accelerate material aging, and disrupt optical performance. For wheel and brake airflow studies, poor thermal assumptions can distort drag, cooling, and durability conclusions.
For high-performance tires, temperature distribution influences grip, rolling resistance, wear, and noise. For sensor switches and perception hardware, thermal instability can degrade sensing accuracy or trigger protective logic at the wrong moment.
That is why technical evaluators in this sector should treat thermal management models as cross-functional risk tools, not isolated engineering artifacts. Their value lies in how well they represent operational reality across connected systems.
Conclusion: the model fails when reality contains more coupling and variability than the assumptions allow
Thermal management models fail in real driving cycles for a simple reason: the road introduces transient behavior, environmental variability, control imperfections, and subsystem coupling that many simulation frameworks still simplify too aggressively.
For technical evaluators, the right question is not whether the model correlates somewhere, but whether it remains trustworthy where decisions carry cost, safety, and durability consequences. That requires scrutiny of assumptions, validation scope, spatial accuracy, and control realism.
A credible model is not the one with the smoothest plots. It is the one that reveals where thermal risk actually emerges under realistic vehicle use. When evaluation is built around that principle, thermal management models become genuinely useful rather than merely persuasive.