
Industry Portal
Related News
- 00
0000-00
Wheel Lightweighting in Europe: How EV Regulations Are Reshaping Wheel Sourcing - 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development
What Drives Smart Optical Perception Cost in Vehicles? Sensors, Compute, and Integration
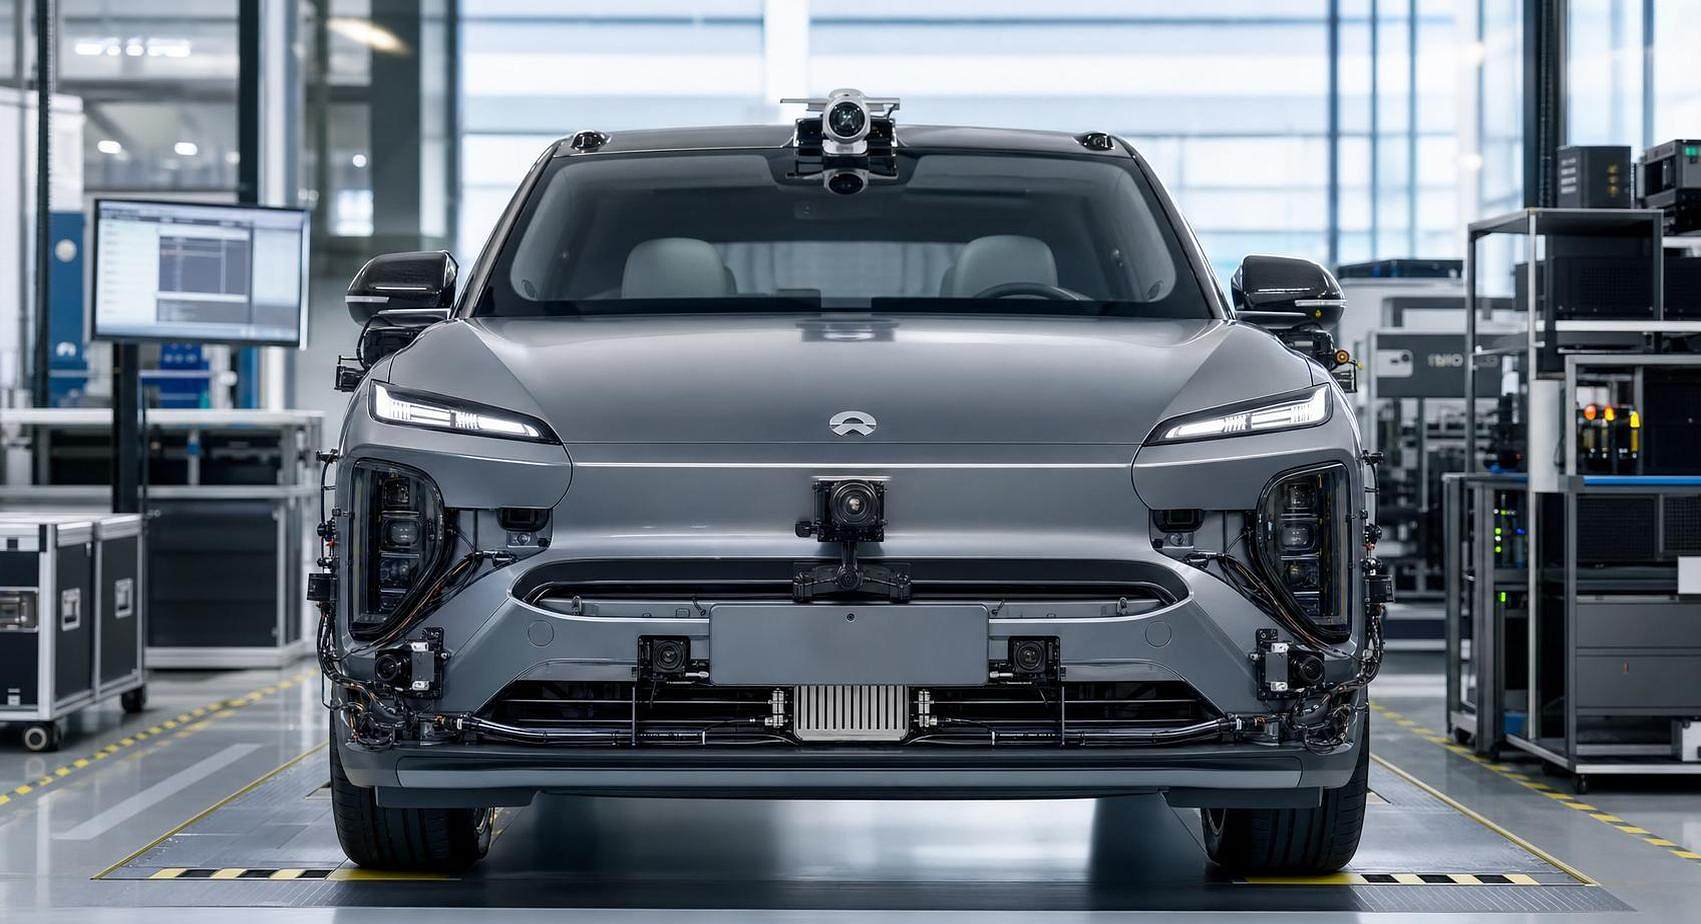
For financial approvers evaluating next-generation vehicle vision systems, smart optical perception cost is driven by more than sensor pricing alone. Camera modules, processing power, software complexity, thermal design, and vehicle-level integration all shape the true investment profile. Understanding how these cost layers interact is essential for balancing safety, performance, compliance, and long-term return in modern automotive programs.
Why smart optical perception cost rises beyond the camera bill of materials
Many finance teams start with a simple question: how much does the sensor cost? In practice, smart optical perception cost in vehicles expands across the full exterior and vision stack, especially in NEV platforms where energy efficiency, styling, safety, and software-defined functions must work together.
A front camera may look affordable on paper, yet the approved budget often grows once image processors, wiring, cleaning systems, heat dissipation, validation, and homologation are included. This is why cost reviews should move from component price to system economics.
AEVS follows this topic from the perspective of vehicle exteriors and dynamic driving perception. That matters because optical sensing does not live in isolation. It is affected by headlight architecture, body packaging, aerodynamic surfaces, wheel spray behavior, sensor switch logic, and global compliance requirements.
- Sensor hardware sets the entry point, but not the final approval number.
- Compute capability determines feature depth, latency, and software maintenance burden.
- Vehicle integration adds hidden expense through brackets, harnesses, thermal paths, sealing, testing, and calibration.
- Compliance and serviceability influence lifetime cost, not just launch cost.
What financial approvers should count as “real cost”
For budgeting purposes, real smart optical perception cost should include direct material, indirect engineering, validation, production tooling, program risk reserve, and post-launch support. If these are separated into different departmental budgets, the total program exposure is often understated during approval.
Which cost blocks matter most in vehicle vision programs?
The table below helps finance teams examine smart optical perception cost in a structured way. It highlights where visible costs end and where cross-functional program costs begin.
This breakdown shows why purchase price alone is a weak decision metric. In many vehicle programs, integration and software choices become the largest drivers of smart optical perception cost once feature ambition increases.
Sensor count is important, but architecture matters more
Two systems with the same number of cameras can have very different cost outcomes. A distributed architecture may lower local hardware cost while increasing network complexity. A centralized architecture may simplify updates but require a more powerful processing domain and stricter thermal control.
How sensors, compute, and integration each change smart optical perception cost
Sensors: price is tied to optical performance and environmental robustness
Camera cost changes with resolution, dynamic range, low-light performance, lens quality, heating needs, contamination resistance, and enclosure durability. In exterior applications, wash performance, vibration resistance, and sealing quality are not optional details. They directly affect warranty and field reliability.
For NEVs, packaging pressure is stronger because aerodynamic surfaces and flush styling can reduce available sensor space. That may push suppliers toward compact modules that are harder to cool or service, increasing overall smart optical perception cost.
Compute: the hidden multiplier in advanced perception programs
Finance teams often underestimate compute. When the feature set expands from basic surround view to lane understanding, object classification, glare control interaction, or sensor fusion, the processing budget rises quickly. More compute also means more power draw, thermal material, software adaptation, and validation hours.
This is especially relevant when smart optical perception interfaces with LED headlight assemblies or auto sensor switches. A richer interaction between vision and vehicle exteriors may improve user value, but it also broadens the system boundary that must be budgeted.
Integration: where many programs lose cost control
Integration cost includes more than fitting a camera into a body panel. Teams must assess field of view, mud and water exposure, wheel spray patterns, wiring route length, cleaning strategy, thermal escape paths, electromagnetic compatibility, assembly tolerances, and plant calibration workflow.
AEVS intelligence is valuable here because exterior systems influence perception stability. For example, wheel airflow, tire spray, and front fascia geometry can change sensor contamination rates. A component may seem low cost in sourcing but expensive in real-world maintenance.
What is the best-fit configuration for different budget and feature targets?
The next comparison table is useful when evaluating smart optical perception cost against functional ambition. It is not a fixed pricing guide. Instead, it supports program-level selection logic for finance, engineering, and sourcing reviews.
For financial approvers, the modular path often deserves attention. It can prevent the common mistake of selecting the cheapest current option, then paying more later for revalidation, repackaging, and software restructuring.
When a lower-cost system becomes more expensive later
A low-entry solution can lose its appeal if it lacks thermal margin, software scalability, or compliance flexibility for export markets. Redesign after SOP pressure begins is usually far more expensive than building controlled upgrade paths into the original business case.
How should finance teams evaluate suppliers and proposals?
A disciplined procurement review can reduce smart optical perception cost volatility before contracts are signed. Finance should not review proposals only by unit quote and tooling charge. The better method is to test assumptions that influence launch timing, compliance, and field performance.
- Ask for architecture boundaries. Confirm which functions are inside the sensor, inside the ECU, and inside central compute.
- Check environmental design assumptions. Exterior optics face water, dust, thermal cycling, and spray contamination that can reshape service costs.
- Review software obligations. Clarify licensing terms, update responsibilities, cybersecurity maintenance, and feature localization by market.
- Map compliance exposure. Determine whether ECE, DOT, EMC, and related test burdens are already reflected in the quotation.
- Evaluate serviceability. Lens contamination, camera replacement, calibration time, and spare-part planning influence total operating cost.
A practical approval checklist
Before budget release, finance can require a cross-functional signoff covering optical performance targets, compute load margin, thermal concept, packaging feasibility, certification scope, and launch-risk contingency. This reduces the chance that smart optical perception cost is approved on incomplete assumptions.
Which compliance and lifecycle issues are commonly overlooked?
Vehicle vision systems are exposed to a wider approval burden than many non-safety exterior components. The system may interact with driver assistance, lighting logic, body electronics, and global traffic compliance expectations. That means delayed test findings can be expensive.
- Environmental durability testing can uncover sealing, fogging, or thermal drift issues that require design revision.
- EMC and network stability can affect camera signal integrity and ECU behavior, especially in feature-dense NEV platforms.
- Regional regulations may alter lighting and perception interaction requirements, affecting export readiness.
- Service procedures such as recalibration after replacement can add hidden downstream expense for fleets and dealerships.
AEVS tracks these issues as part of a broader exterior and vision intelligence framework. That perspective helps decision-makers connect optics, lighting, aerodynamic design, and raw material shifts instead of evaluating them as isolated purchasing lines.
FAQ: smart optical perception cost questions financial approvers often ask
Is smart optical perception cost mainly determined by camera resolution?
No. Resolution matters, but total cost depends equally on compute, software stack, thermal management, integration labor, validation, and lifecycle support. A higher-resolution camera with efficient architecture can sometimes be more economical than a lower-cost camera deployed in a fragmented system.
Which scenario creates the biggest budget overrun risk?
Late discovery of integration or compliance issues is one of the biggest risks. Common examples include contamination vulnerability, insufficient thermal margin, export-market regulation gaps, and under-scoped software responsibilities. These issues usually surface after sourcing assumptions have already been locked.
How can finance compare two proposals with different architectures?
Use a whole-program lens. Compare not only piece price, but also compute strategy, harness impact, calibration workflow, software ownership, future trim scalability, and service cost. The lower quote is not automatically the lower smart optical perception cost over the vehicle lifecycle.
Are optical systems more cost sensitive in NEVs than in conventional vehicles?
In many cases, yes. NEVs place stronger pressure on aerodynamic efficiency, thermal packaging, energy consumption, and intelligent feature integration. That means exterior optics can influence not only safety functions but also styling, range perception, and software-defined brand positioning.
Why AEVS is a useful partner for cost-aware exterior and vision decisions
AEVS focuses on the connected reality of vehicle exteriors, from LED headlight assemblies and auto sensor switches to wheels, tires, and aerodynamic packaging. For finance teams, that cross-domain view is valuable because smart optical perception cost is rarely controlled by optics alone.
Our Strategic Intelligence Center follows compliance shifts, raw material movements, thermal management trends, airflow behavior, and commercial signals across the global NEV landscape. This helps buyers and approvers judge whether a proposed vision system is cost-efficient only at sourcing stage or sustainable across launch and lifecycle.
Contact us for decision support that goes beyond unit price
If you are reviewing a vehicle vision budget, AEVS can support parameter confirmation, architecture comparison, product selection logic, delivery timeline assessment, certification scope review, sample evaluation priorities, and quotation discussions tied to real program risk. This is especially useful when smart optical perception cost must be balanced against styling targets, energy efficiency, lighting interaction, and market compliance.
Bring your target feature set, sourcing assumptions, and market plan. We can help structure the questions that matter before approval, so your team can make a faster, clearer, and more defensible investment decision.