
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
Photoelectric Sensing Selection Guide: How to Compare Range, Response Time, and Accuracy
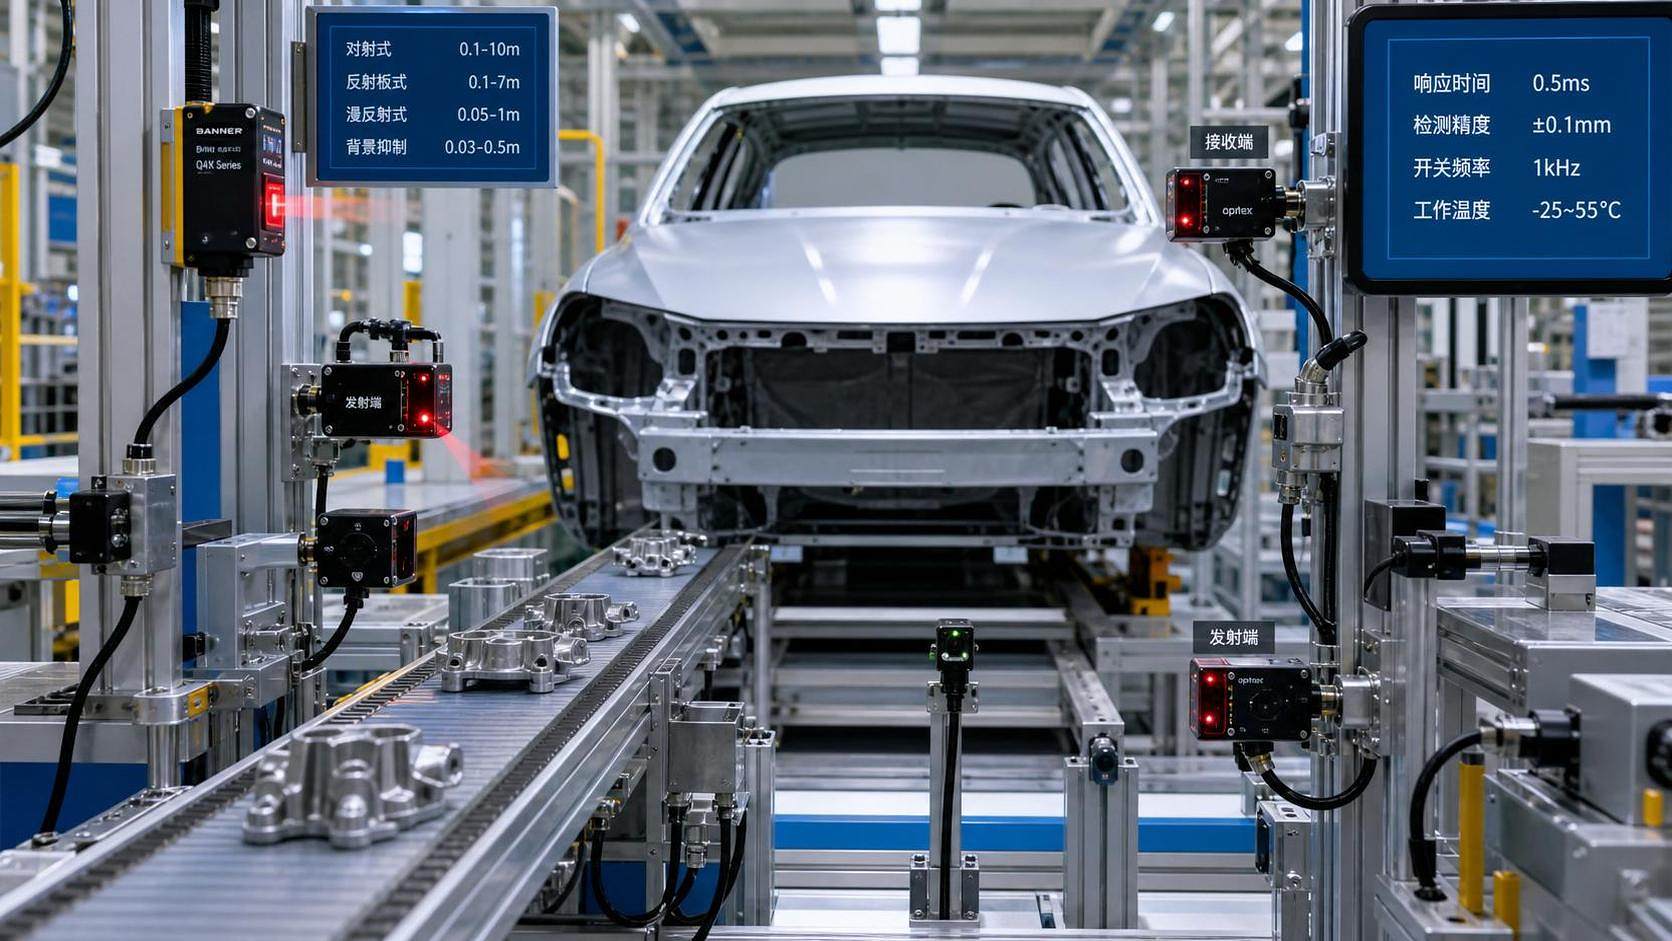
Photoelectric Sensing Selection Guide: How to Compare Range, Response Time, and Accuracy
Choosing the right photoelectric sensing solution requires more than comparing datasheet numbers.
In automotive and industrial systems, sensor choices shape reliability, safety, and total integration cost.
That is especially true when functions depend on rapid and stable object detection.
A good photoelectric sensing strategy must work in the lab and also in dust, glare, vibration, and temperature drift.
This matters across smart headlight activation, body control logic, auto wipers, assembly automation, and safety interlocks.
The practical question is simple: which sensor architecture gives dependable performance without unnecessary design cost?
Why photoelectric sensing selection often goes wrong
Many teams start with nominal range, then move straight to price.
That shortcut looks efficient, but it usually hides performance tradeoffs.
For example, a long-range sensor may react too slowly for fast-moving targets.
A highly accurate unit may lose stability on dark, reflective, or irregular surfaces.
In automotive exterior applications, these gaps can trigger false switching or missed detection.
So, effective photoelectric sensing selection starts with operating reality, not headline specifications.
Start with sensing mode before comparing numbers
Before reviewing range, response time, and accuracy, confirm the sensing principle.
Different photoelectric sensing modes behave very differently in real installations.
Common modes
- Through-beam: strongest range and contamination tolerance, but needs emitter and receiver alignment.
- Retro-reflective: easier installation, but sensitivity to shiny objects can complicate detection.
- Diffuse reflective: compact and convenient, yet strongly influenced by target color and surface texture.
- Background suppression: better positional discrimination where nearby structures create interference.
In practice, the wrong sensing mode cannot be rescued by better nominal specifications.
That is why photoelectric sensing evaluation should begin with target behavior and installation geometry.
How to compare sensing range correctly
Range is the most visible parameter, but also the most misunderstood.
Datasheet range usually assumes ideal target size, perfect alignment, and controlled ambient light.
Real systems rarely provide those conditions.
Key range questions
- What is the minimum target size at the required distance?
- How dark, transparent, or reflective is the target surface?
- What contamination level is expected from dust, oil, rain, or road debris?
- Will nearby metal, gloss paint, or glass create optical noise?
A useful rule is to avoid selecting sensors right at the published maximum range.
Healthy design margin is essential for stable photoelectric sensing performance over product life.
From recent application trends, engineers increasingly target a practical operating distance well below the limit.
That approach improves uptime and reduces field tuning after deployment.
Why response time can outweigh range
A sensor that sees far but reacts late can still fail the application.
Response time defines how quickly photoelectric sensing converts optical change into usable output.
This becomes critical when parts move quickly or control logic needs immediate switching.
Where response time matters most
- High-speed conveyors and indexing lines.
- Smart vehicle body functions with strict switching windows.
- Safety zones where missed edges create hazard exposure.
- Compact assemblies where targets remain detectable for milliseconds only.
The real metric is not just sensor speed.
It is total system delay, including controller scan time, filtering, and actuator latency.
That also means ultra-fast photoelectric sensing may offer limited value inside a slow control loop.
Selection works better when response time is mapped to actual motion speed and decision timing.
How to judge accuracy without overbuying
Accuracy is often treated as a premium feature.
However, the best photoelectric sensing solution is not always the most precise one.
It is the one that meets the decision threshold with repeatability and low false triggers.
Accuracy should include
- Repeatability across multiple detection cycles.
- Stability under temperature and vibration changes.
- Consistency across target color and finish variation.
- Resistance to ambient light and electromagnetic interference.
In automotive optical and body-control scenarios, accuracy also affects calibration effort.
A sensor that drifts less usually reduces maintenance, warranty risk, and software compensation.
So, evaluate accuracy as a lifecycle cost factor, not only as a performance badge.
Environmental factors that change the decision
This is where many photoelectric sensing projects are won or lost.
Laboratory validation can look excellent, while field performance collapses under environmental stress.
Check these conditions early
- Sunlight exposure and strong LED background illumination.
- Rain, fog, condensation, dust, and oily film.
- Mechanical shock, wheel-generated vibration, and thermal cycling.
- Mounting tolerance drift over service life.
For exterior vehicle systems, contamination is especially important.
Road splash, fine dust, and cleaning chemicals can all alter optical behavior.
That is why robust photoelectric sensing selection should include derating under worst-case exposure.
A practical comparison matrix for selection
A structured matrix keeps evaluation objective and easier to defend internally.
This type of comparison makes photoelectric sensing decisions more transparent across engineering, sourcing, and quality teams.
Questions to ask suppliers before final selection
Supplier dialogue often reveals more than catalog pages do.
- What target material and reflectivity were used for the stated sensing range?
- How does response time change with filtering or noise suppression enabled?
- What field data exists for dust, moisture, and vibration exposure?
- What alignment tolerance is acceptable during assembly and service?
- Are diagnostic outputs available for contamination or signal degradation?
These questions support smarter photoelectric sensing procurement and reduce late redesign risk.
More importantly, they shift discussion from price alone to usable system value.
Final decision: balance performance, robustness, and cost
The best photoelectric sensing choice is rarely the sensor with the highest single specification.
It is the option that holds stable range, suitable response time, and reliable accuracy in the real environment.
For intelligent exterior and vision-related systems, that balance directly supports safety, user experience, and cost control.
A disciplined evaluation process also creates stronger technical justification for sourcing decisions.
If the next selection cycle starts with real targets, real motion, and real contamination conditions, better results usually follow.
That is the most reliable way to turn photoelectric sensing from a component choice into a durable system advantage.