
Industry Portal
Related News
- 00
0000-00
Which ISO Standards Govern Vehicle Lightweighting Materials and Validation Testing? - 00
0000-00
Wheel Lightweighting in Europe: How EV Regulations Are Reshaping Wheel Sourcing - 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials
How photoelectric sensing reduces false triggers in rain detection
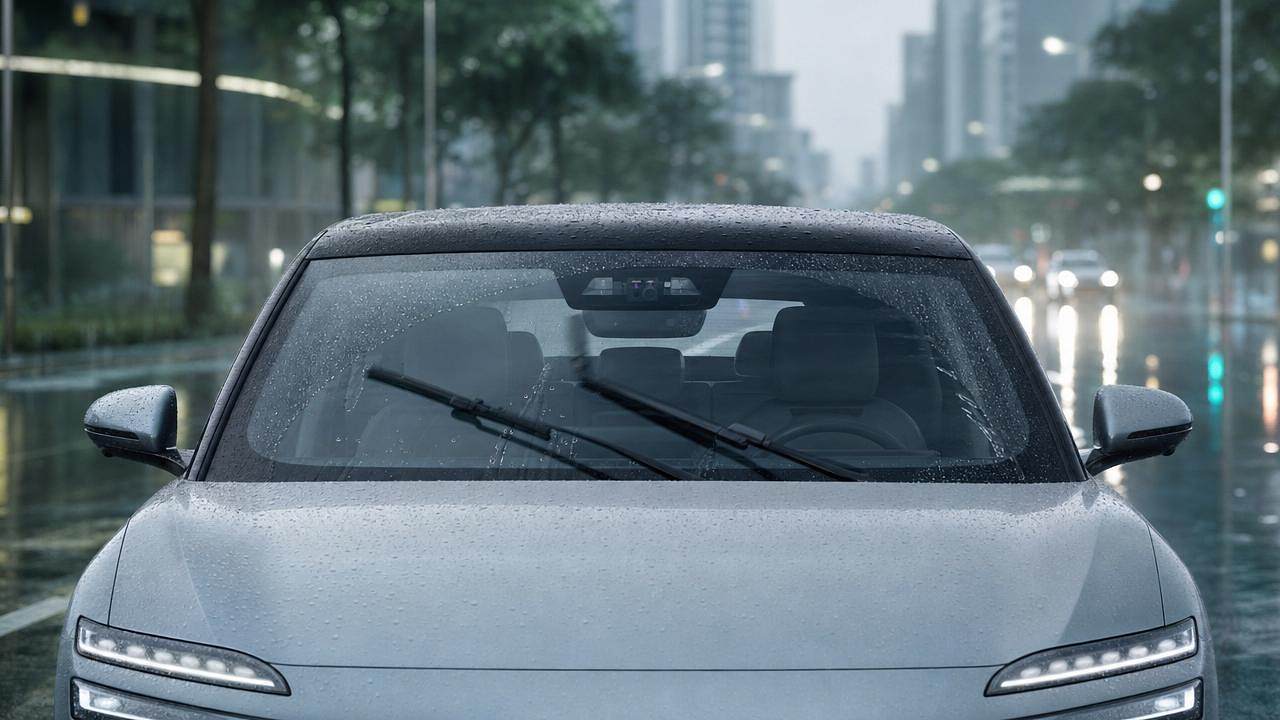
In automotive rain detection, false triggers can compromise both driver comfort and system credibility. Photoelectric sensing offers a more precise way to distinguish real raindrop patterns from glare, dust, condensation, and changing ambient light. For technical evaluators, understanding how this sensing method improves signal reliability, response accuracy, and integration with smart wiper systems is essential when assessing next-generation exterior and vision technologies.
Why false triggers remain a critical issue in vehicle rain sensing
For technical assessment teams, the problem is rarely whether automatic wipers can detect water at all. The real issue is whether the system can avoid acting when rain is not actually present. A false wipe during tunnel exit, strong headlamp reflection, washer residue, or morning condensation quickly reduces driver trust.
In modern NEV and premium exterior systems, trust matters because rain sensing is no longer an isolated comfort feature. It interacts with driver assistance logic, windshield optical packaging, body controllers, and smart headlight activation. A weak sensing decision can ripple through the entire exterior and vision stack.
This is where photoelectric sensing has become increasingly valuable. Instead of relying on crude environmental assumptions, it evaluates optical behavior at the glass interface. That makes it better suited for distinguishing genuine droplet disruption from noise generated by light, contamination, or surface haze.
- False wipes increase perceived system instability, especially in premium vehicles where driver expectations are high.
- Incorrect trigger events can accelerate wiper wear, increase motor duty cycles, and amplify NVH concerns.
- For OEM and Tier 1 evaluators, poor discrimination logic raises validation cost because more edge cases require calibration and field rework.
How photoelectric sensing works in rain detection systems
The optical principle behind the decision
A typical photoelectric sensing rain module uses an emitter and a receiver placed against the inner side of the windshield. The emitter projects infrared or near-infrared light into the glass at a defined angle. Under dry conditions, most of that light is internally reflected and returns to the receiver in a predictable pattern.
When raindrops appear on the outer surface, the refractive condition changes. Water alters reflection and transmission behavior, reducing or redistributing the returned optical signal. The electronics interpret this change as the presence of rain, then send a request to the body control or wiper control unit.
Why this method reduces false triggers
The strength of photoelectric sensing is that it measures a surface-specific optical event rather than broad environmental brightness. That gives evaluators a more direct physical link between signal change and actual moisture on glass. In practice, this helps filter out non-rain disturbances that do not reproduce the same optical signature.
Advanced designs further improve discrimination by combining multiple emit-receive paths, modulated light sources, temperature compensation, and digital filtering. These additions are especially useful for vehicles with steep windshield angles, acoustic laminated glass, or integrated camera housings where optical cross-effects may occur.
- Modulated emission helps reject interference from sunlight and external lamps.
- Multi-zone sensing improves pattern recognition when droplets are unevenly distributed.
- Algorithmic thresholds can be tuned for drizzle, spray, splash, or persistent rainfall.
What causes false triggers, and where does photoelectric sensing perform better?
Technical evaluators usually compare sensing methods by asking a practical question: what kinds of noise events can the sensor survive without an unnecessary wipe command? The table below maps common disturbance sources against the behavior of a photoelectric sensing rain detection approach.
The key point is not that photoelectric sensing eliminates every false event. Rather, it gives engineers a more controllable signal domain. That control supports better calibration, more stable performance across climates, and lower nuisance activation in mixed lighting conditions.
Photoelectric sensing versus other rain detection approaches
When procurement and validation teams compare technologies, they should look beyond brochure claims. The most useful comparison considers signal path, calibration burden, packaging limits, and how the sensor behaves in real road noise conditions.
For vehicles positioned around premium comfort, ADAS sensor cleanliness, or enhanced exterior intelligence, photoelectric sensing often provides a better balance between accuracy and user acceptance. That is particularly true when auto wipers are expected to react smoothly rather than simply turn on and off.
Which technical performance indicators matter most during evaluation?
Core metrics to request from suppliers
Technical evaluators should not accept generic statements such as sensitive detection or improved stability. Ask for measurable performance definitions, validation conditions, and boundary assumptions. A rain sensor can appear accurate in a lab yet behave poorly on a sloped windshield under mixed urban lighting.
- Signal-to-noise behavior under direct sunlight, dusk glare, and nighttime headlamp exposure.
- Response latency from first droplet detection to wiper command generation.
- Baseline drift performance after dust accumulation, temperature cycling, and adhesive aging.
- Compatibility with laminated glass, heated windshield zones, and integrated camera brackets.
- Algorithm adjustability for market-specific wipe preferences and vehicle classes.
Parameter review table for sourcing discussions
The following parameter-oriented checklist helps teams compare photoelectric sensing modules during RFQ, prototype review, or design freeze discussions.
For AEVS-style technical intelligence work, this parameter view is especially useful because rain detection should be assessed alongside broader optical and exterior integration factors, not as a standalone switch component.
Where is photoelectric sensing most valuable in real vehicle applications?
Premium passenger vehicles and smart exterior systems
In premium passenger cars, false triggers are more visible because cabin quietness and refined HMI behavior make every unnecessary wipe noticeable. Photoelectric sensing supports a smoother experience, especially when the wiper system uses variable-speed logic and interacts with auto lighting or windshield camera modules.
NEVs with dense optical packaging
NEVs increasingly combine aerodynamic windshield geometry, roofline optimization, and advanced vision hardware near the top center glass zone. These packaging constraints increase the importance of optical precision. Photoelectric sensing is well suited when evaluators need predictable behavior despite tight integration near cameras, mirrors, and sensor shrouds.
Regional markets with variable weather and compliance pressure
Vehicles sold across humid, dusty, sunny, and cold regions require rain sensing that can tolerate different forms of optical disturbance. Technical teams working across ECE- or DOT-oriented product planning often prefer technologies that allow more repeatable tuning across these conditions, reducing downstream validation cycles.
- Urban traffic with heavy night reflections demands strong ambient rejection.
- Highway spray events require fast recognition without overreacting to isolated splash noise.
- Cold start conditions call for discrimination between condensation, frost residue, and true rainfall.
How should technical evaluators choose a suitable photoelectric sensing solution?
Selection should begin with system architecture, not component price alone. A low-cost sensor that requires repeated software correction, bracket redesign, or field recalibration may cost more over the program lifecycle than a better integrated optical solution.
- Define the windshield stack-up early, including laminate structure, coatings, heated zones, and available mounting area.
- Map target operating scenarios such as tunnel transitions, coastal humidity, winter fogging, and urban night driving.
- Request validation evidence that separates light disturbance immunity from pure water sensitivity.
- Check ECU communication strategy, including how rain intensity translates into intermittent, low-speed, or high-speed wipe commands.
- Review serviceability, replacement alignment tolerance, and production calibration burden.
AEVS emphasizes this cross-domain evaluation mindset because exterior intelligence is no longer compartmentalized. Rain sensing quality affects vision perception, driver confidence, and even the perceived sophistication of adjacent systems such as matrix lighting and auto sensor switches.
Common misconceptions about photoelectric sensing in rain detection
Does higher sensitivity always mean better performance?
No. Excessive sensitivity without noise control can increase false triggers. A well-designed photoelectric sensing system balances sensitivity with hysteresis, temporal filtering, and pattern recognition so that it responds to actual rain events rather than every transient optical disturbance.
Can software alone solve false triggering?
Software helps, but it cannot fully compensate for poor optical coupling, unstable mounting, or unsuitable emitter-receiver design. Evaluators should treat hardware optics, glass interface, and algorithms as one system. Overreliance on calibration often leads to fragile field performance.
Is photoelectric sensing only for high-end vehicles?
Not necessarily. While premium vehicles benefit strongly from refined wipe behavior, mid-range platforms also gain value when nuisance wiping harms perceived quality. The right choice depends on target market expectations, validation budget, and how much system credibility matters in the overall exterior electronics package.
FAQ for sourcing and validation teams
How do we judge whether a photoelectric sensing module is robust enough for production?
Ask for test evidence across real disturbance conditions, not only water response curves. Useful reviews include glare exposure, tunnel exit behavior, contamination drift, temperature cycling, and glass variation tolerance. Production robustness depends on repeatability across these combined inputs.
What procurement risk is most often overlooked?
Many teams underestimate windshield integration risk. A sensor that works on one glass construction may behave differently with another interlayer, coating, or curvature. Confirm optical compatibility before finalizing cost targets or delivery plans.
How important is coordination with smart wiper control logic?
It is essential. Rain detection quality is experienced through wiper behavior, not raw sensor data alone. Even strong photoelectric sensing can feel poor if the control strategy applies aggressive wipe steps, weak hysteresis, or delayed mode changes.
Should we evaluate rain sensing together with other exterior and vision systems?
Yes. On modern vehicles, rain sensing shares space and decision relevance with lighting, camera perception, windshield packaging, and body electronics. AEVS-driven assessment frameworks are useful because they connect optical behavior with broader exterior architecture and vehicle perception goals.
Why choose us for technical intelligence and evaluation support
AEVS focuses on the intersection of smart optical perception, exterior integration, and performance-oriented component intelligence. For teams assessing photoelectric sensing in rain detection, that means support goes beyond basic component description. We help frame the decision within windshield optics, auto sensor switches, smart lighting interaction, and NEV packaging priorities.
You can contact us for practical evaluation support on parameter confirmation, solution comparison, sample review priorities, supplier communication points, likely validation risks, delivery-cycle considerations, and compliance-oriented planning around international vehicle markets. This is especially useful when your team must make a sourcing or architecture decision under tight timing and limited testing bandwidth.
- Parameter confirmation for optical sensing architecture and integration constraints.
- Product selection guidance for different vehicle classes, rain profiles, and driver experience targets.
- Discussion support around sample planning, validation focus, and software calibration checkpoints.
- Consultation on delivery timing, customization scope, and cross-system fit with lighting and vision modules.
If your current challenge is reducing false triggers without sacrificing response speed, a structured photoelectric sensing review is the right starting point. Clear technical criteria early in the program can prevent later redesign, unstable user experience, and unnecessary validation cost.