
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
How photoelectric sensing Works in Automotive Rain and Light Sensors
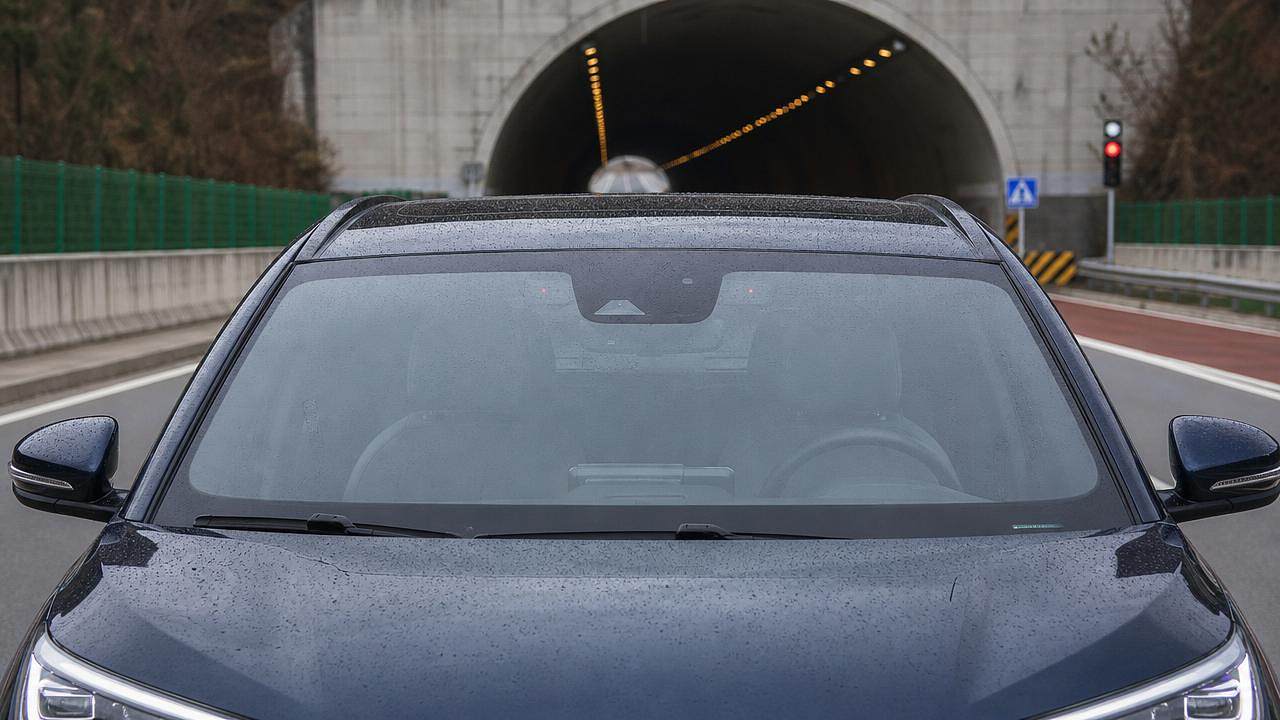
How photoelectric sensing Works in Automotive Rain and Light Sensors
As vehicles become more automated and responsive, photoelectric sensing has become essential to rain and light sensor systems that improve visibility, comfort, and safety.
By detecting changes in reflected light caused by raindrops, ambient brightness, or tunnel entry, these sensors trigger automatic wipers and adaptive lighting.
For automotive exterior and vision technologies, photoelectric sensing explains why smart optical perception is now a key building block in NEV safety.
Why a Checklist Matters for photoelectric sensing Decisions
Rain and light sensors seem simple to users, yet their performance depends on optics, algorithms, glass quality, and vehicle network integration.
A checklist reduces blind spots when evaluating photoelectric sensing modules for auto wipers, smart headlights, and exterior perception systems.
It also helps compare sensor packages across different windshield angles, cabin layouts, climate zones, and electrical architectures.
In NEV platforms, photoelectric sensing must support low power consumption, fast response, high reliability, and clean integration with body controllers.
Core Checklist for Understanding photoelectric sensing
Use the following checklist to judge whether an automotive rain and light sensor design is technically sound and application-ready.
- Verify the optical path by confirming how infrared light enters the windshield, reflects internally, and returns to the receiver.
- Check the rain detection principle by observing how water changes total internal reflection and reduces received light intensity.
- Confirm ambient light sensing by measuring lux variation during dawn, dusk, tunnel entry, shadows, and direct sunlight exposure.
- Assess the emitter and photodiode pairing to ensure stable photoelectric sensing under temperature drift and aging conditions.
- Review the optical coupling pad because air gaps, bubbles, or poor adhesion can distort photoelectric sensing accuracy.
- Validate windshield compatibility by checking glass thickness, tint, curvature, coating, acoustic layers, and heating elements.
- Test software filtering so the sensor ignores dust, vibration, washer spray, insects, and short-lived optical interference.
- Check body control communication through LIN, CAN, or local interfaces to ensure wiper and headlight commands respond correctly.
- Measure reaction time because delayed photoelectric sensing can reduce driver confidence during sudden rain or tunnel transitions.
- Document calibration logic so service teams can replace windshields without degrading rain sensing or automatic light activation.
How the Rain Sensor Uses photoelectric sensing
A rain sensor usually contains infrared LEDs, photodiodes, a lens structure, and signal processing electronics mounted near the rearview mirror.
When the windshield is dry, infrared light reflects strongly inside the glass and returns to the receiver.
When raindrops touch the outer surface, part of that light escapes through the water, reducing the returned signal.
The controller interprets this change as rainfall intensity, then adjusts intermittent, low-speed, or high-speed wiper operation.
This is the practical value of photoelectric sensing: it converts a small optical change into a usable vehicle control command.
Rain Intensity and Algorithm Judgment
Modern systems do not react only to one signal drop. They analyze patterns, frequency, and surface coverage.
This prevents false wiping when a single droplet, smear, or road splash crosses the optical zone.
High-quality photoelectric sensing combines hardware stability with algorithms that classify drizzle, steady rain, and sudden heavy rainfall.
How the Light Sensor Uses photoelectric sensing
A light sensor measures ambient illumination around the vehicle and inside the forward viewing direction.
The signal helps activate headlights, adjust daytime running light behavior, and support adaptive lighting strategies.
In a tunnel, photoelectric sensing detects the rapid drop in brightness and requests low-beam activation before visibility becomes uncomfortable.
At dusk, it recognizes gradual light reduction and avoids unnecessary switching caused by short shadows or passing roadside objects.
For LED headlight assemblies, this sensing data supports better timing, safety, and user experience.
Light Direction and Spectral Response
Good light detection depends on field of view, spectral matching, and resistance to glare.
If the sensor overreacts to dashboard reflections, street lamps, or sunlight angles, automatic lighting becomes inconsistent.
Robust photoelectric sensing requires careful optical shielding and calibration against real driving illumination patterns.
Application Scenarios to Check Before Validation
Urban Commuting
Urban roads create frequent lighting changes from buildings, bridges, tunnels, and traffic reflections.
Photoelectric sensing must distinguish real environmental darkness from temporary shadows and reflected headlamp beams.
Highway Rain Driving
At highway speed, water patterns change quickly across the windshield because airflow reshapes droplets and spray.
The sensor must react quickly without overshooting wiper speed, especially during truck spray and sudden heavy rain.
Cold Climate Operation
Ice, fog, and condensation can confuse optical measurement if the sensor lacks compensation logic.
Photoelectric sensing should be validated with defrost cycles, heated glass, low sun angles, and frozen washer residue.
New Energy Vehicle Platforms
NEV platforms prioritize energy efficiency, quiet comfort, and integrated electronic control.
Reliable photoelectric sensing supports these goals by reducing manual operation and improving exterior vision system coordination.
Commonly Ignored Risks in photoelectric sensing
Ignoring windshield replacement effects. Aftermarket glass may differ in thickness, tint, infrared transmission, or mounting position, causing sensor drift.
Underestimating contamination. Dust, wax, oily film, and washer additives can change optical reflection and reduce photoelectric sensing consistency.
Overlooking optical pad aging. Coupling materials may yellow, harden, or detach after heat cycling, lowering the signal-to-noise ratio.
Testing only in laboratory light. Real roads include glare, wet asphalt reflections, LED street lighting, and fast weather transitions.
Separating hardware from software. A strong photodiode cannot compensate for poor filtering, weak thresholds, or delayed body controller communication.
Execution Guide for Better Sensor Evaluation
- Start with optical simulation to define emitter angle, receiver position, glass interface, and expected reflection loss.
- Build bench tests that compare dry glass, mist, droplets, flowing water, and contaminated surfaces.
- Add vehicle-level tests across tunnel entry, sunset, rain spray, snow, fog, and low sun glare.
- Record raw sensor signals, wiper commands, headlight switching points, and driver-visible response timing.
- Tune thresholds with real road data instead of relying only on ideal optical measurements.
- Confirm service procedures for windshield replacement, sensor reattachment, diagnostics, and calibration verification.
This execution process makes photoelectric sensing measurable, repeatable, and easier to compare across vehicle programs.
Technical Markers Worth Comparing
Summary and Action Direction
Photoelectric sensing works by translating changes in reflected or received light into decisions for wipers and headlights.
Its value depends on optical design, windshield compatibility, algorithm filtering, calibration, and integration with vehicle body electronics.
For exterior and vision systems, the next step is to evaluate photoelectric sensing with scenario-based tests, not isolated specifications.
Create a validation checklist, collect real road data, compare sensor behavior, and link findings to wiper and lighting performance.
That approach turns photoelectric sensing from a hidden module into a reliable part of smart automotive perception.