
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
How Smart Headlight Activation Sensors Improve Visibility and Reduce False Triggering
Start with the failure mode, not the feature list
For a technical evaluator, a smart headlight activation sensor sits in an awkward place: everyone notices it when it behaves badly, and almost nobody talks about it when it works. That is exactly why it deserves a disciplined review. The real job is not simply turning lamps on when ambient light drops. A good system has to interpret messy real-world light conditions, resist short disturbances, and hand over a stable decision to the body control logic without making the vehicle feel hesitant or erratic.
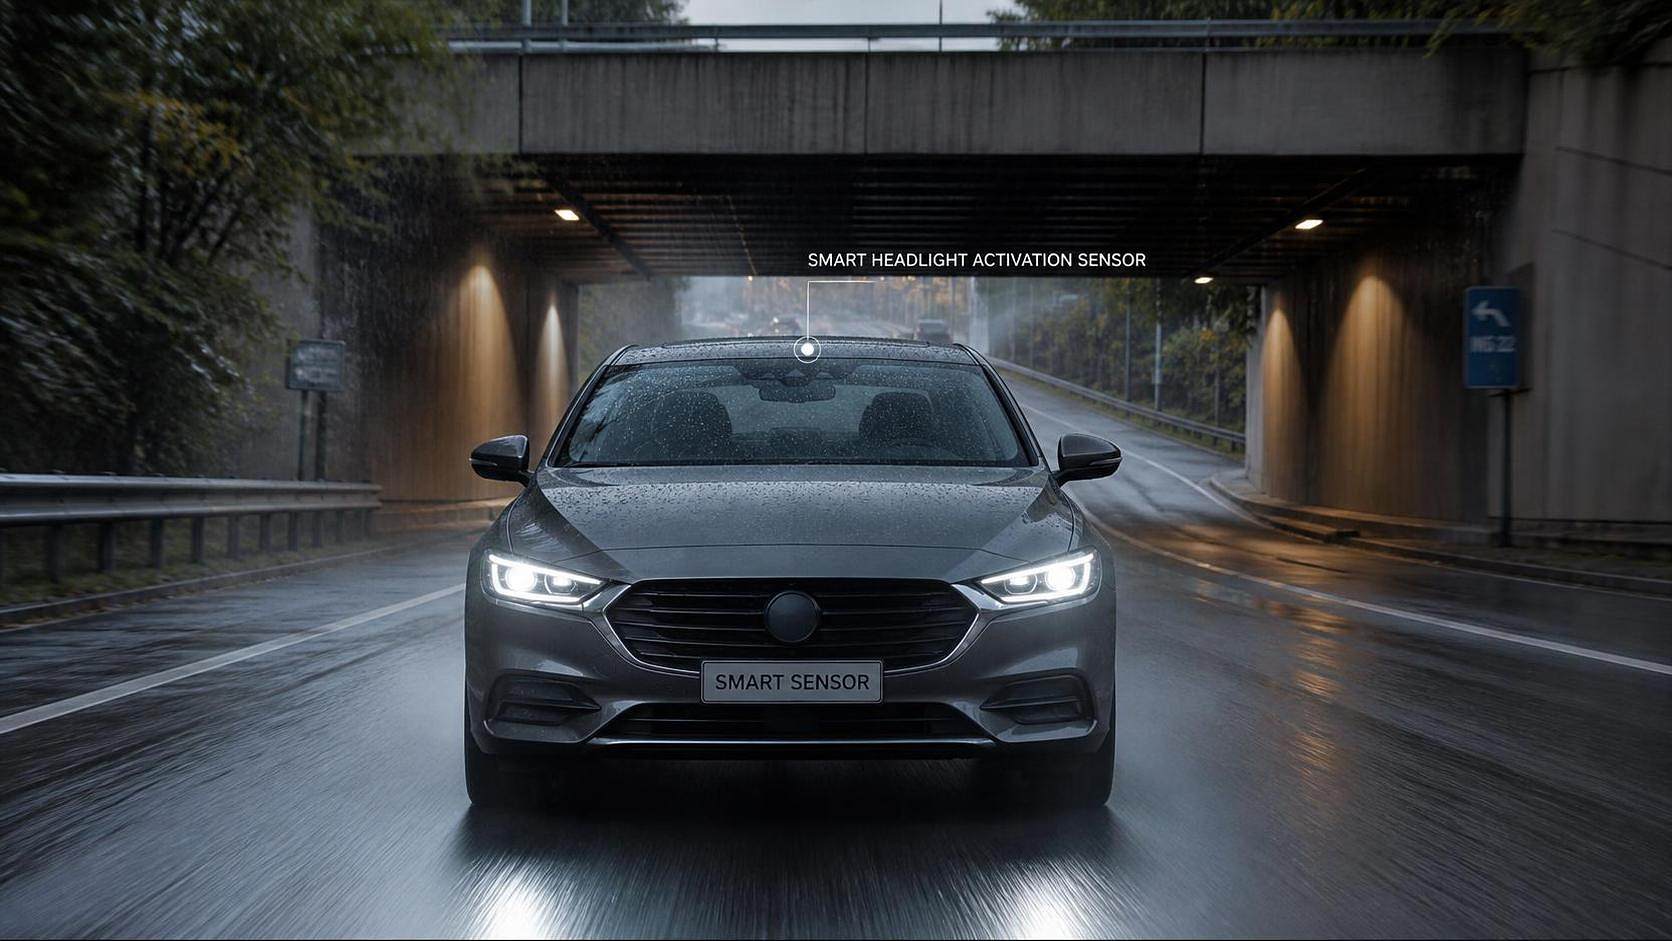
If you are assessing a smart headlight activation sensor for a vehicle program, bench validation alone is not enough. You need to check how the sensor, signal processing, mounting position, and control strategy behave together. Visibility improves when the system reacts early enough in rain, dusk, fog, parking structures, and tree-shadow transitions. False triggering drops only when the algorithm understands context instead of chasing every brief change in lux level.
Check what the sensor is actually measuring
The first mistake is treating every light sensor as interchangeable. Some designs are optimized for ambient brightness only. Others are tuned to approximate human visual perception more closely, which matters because a vehicle moving through sodium street lighting, LED billboard spill, tunnel entrances, or heavily tinted glass does not see the world the way a raw photodiode does.
Review the sensor’s spectral response and the filtering approach around it. You are looking for a system that can distinguish a true low-visibility condition from a short local light event. A sensor that is overly sensitive to narrow-band artificial light may keep headlights off longer than expected under visually poor conditions, or switch them on unnecessarily in bright urban corridors at night. Neither outcome is acceptable, because both undermine driver trust.
A practical question to ask during evaluation: does the design aim to estimate usable driving visibility, or does it merely report incident light at the sensor surface? That difference usually tells you how much software compensation will be needed later.
Do not evaluate switching thresholds without timing behavior
Threshold numbers alone are a trap. What matters in practice is threshold plus dwell time, plus hysteresis, plus release logic. Without those pieces, even a well-chosen activation level can produce headlight chatter.
This is where many false triggering complaints come from. A vehicle passes beneath an overpass, through patchy roadside trees, or next to a reflective glass facade. The ambient light dips for a second or two, then recovers. If the control strategy reacts immediately on the way down and releases just as quickly on the way up, the driver sees pointless lamp cycling. The sensor is not always the culprit; often the signal conditioning is too aggressive.
During review, ask for drive logs rather than a single calibration value. If the supplier cannot show how the system behaves during short transitions, the evaluation is incomplete.
Look hard at mounting position and optical contamination
A smart headlight activation sensor may be sound in principle and still perform poorly because of where it is installed. Windshield angle, dashboard reflections, frit patterns, visor shadows, and the proximity of rain sensors or camera modules can all distort the signal. On some vehicles, the sensor sees more of the cabin environment than intended. On others, it loses fidelity because the exterior optical path is compromised by coating, dirt, or water film.
Check these points in physical build reviews:
- Whether the sensor has a clear forward-facing field through the glazing it is supposed to use.
- Whether laminated glass tint, infrared-reflective layers, or ceramic frit areas change the usable signal.
- Whether water beading, dust loading, or washer residue alters the response under low sun or night street lighting.
- Whether neighboring optical systems create stray reflections into the sensing path.
This is one of those areas where prototype vehicles can mislead teams. A temporary installation may look acceptable until production glass, final trim color, or a different sensor bracket changes the angle by a few degrees. Then the calibration suddenly “moves.”
Verify context inputs that reduce false activation
The better systems do not rely on ambient light alone. They use vehicle context to decide whether a dark reading is meaningful. Wiper status, vehicle speed, time-based filtering, and sometimes camera-based environmental cues can all help. The point is not to make the logic complicated for its own sake. The point is to stop the sensor from overreacting to brief or irrelevant optical events.
Rain is a good example. A scene can remain above the nominal light threshold and still present degraded visibility because the windshield, road spray, and sky condition combine to reduce contrast. If automatic wipers are already active, many evaluators expect the headlight logic to become more conservative about staying off. The exact strategy depends on the architecture, but the principle is consistent: context should tighten the decision when visibility quality deteriorates before absolute brightness does.
What you want to avoid is the opposite problem: adding so many dependent inputs that the activation path becomes opaque and hard to validate. Every extra signal must have a traceable role in the decision chain.
Separate daytime nuisance events from genuine low-visibility events
This is where field assessment pays off. A vehicle that behaves well at sunset can still be annoying in daytime edge cases. Common nuisance events include tunnel approach shadows, dense roadside vegetation, mountain roads with alternating sun and shade, covered toll areas, and urban canyons with strong contrast between sky patches and building shade.
A useful checklist during road evaluation looks like this:
- Drive repeated tunnel entry and exit cycles at different approach speeds. Watch both activation timing and release stability.
- Run tree-shadow and overpass routes in clear weather. Count every unnecessary lamp transition.
- Test in rain, especially under bright daytime cloud cover, where visibility is reduced but ambient light may still appear adequate to a basic sensor.
- Repeat the same route at dusk and early night to see whether the system calibration remains coherent across changing spectra.
A common error is validating each scenario once and calling it good. False triggering often appears only after repeated transitions because some algorithms include memory effects, rolling averages, or state-dependent release behavior.
Check interaction with LED headlamp control strategy
Headlight activation is no longer isolated from the rest of the exterior vision stack. On vehicles with advanced LED headlight assemblies, activation state may influence running light behavior, signature lamp switching, leveling routines, or matrix functions. That means poor activation logic can create downstream issues that are not obvious if you only watch the low-beam command.
During system review, confirm which functions are gated by the automatic headlight state and whether any of them introduce delay, thermal transitions, or visible optical artifacts. An evaluator should not sign off the sensor decision path without checking the lamp-side consequence. A short, unnecessary activation event is much more noticeable when it triggers a full lighting state change rather than a hidden control flag.
Review diagnostics, degradation behavior, and service visibility
A sensor that performs well when healthy but fails ambiguously in service creates a different kind of risk. Technical evaluation should include what happens when the signal is implausible, blocked, drifting, or lost. Does the system move to a conservative fallback? Can the fault be distinguished from a network issue or a body controller issue? Can service teams identify contamination versus sensor malfunction without replacing parts unnecessarily?
This part is easy to skip because it does not change the normal driving impression. Still, it matters. If the failure mode is silent, complaints will come back as “auto lights are inconsistent,” which is expensive to diagnose and hard to reproduce. Review the diagnostic concept, fault storage path, and the conditions under which the system declares a degraded mode.
Map the evaluation to target-market compliance conditions
For technical and standards-driven programs, automatic headlight behavior cannot be reviewed in a vacuum. Target markets may differ in how lighting functions are expected to operate, how daytime running lamps interact with headlamps, and what the vehicle architecture must support to satisfy type approval or market-entry requirements. The point here is not to guess at a universal rule. It is to tie the evaluation to the actual market configuration.
That means checking the vehicle lighting specification, the market-specific variant definition, and the applicable compliance documentation used by the program team. If the same hardware ships across ECE-oriented and DOT-oriented variants, confirm whether the activation logic is common or parameterized. A calibration that feels acceptable in one market package may create an integration issue in another if lamp behavior, telltales, or running light interactions differ.
Use a short decision filter before approval
Before sign-off, reduce the whole evaluation to four questions:
- Does the system switch on early enough when actual driving visibility falls, not just when raw ambient light drops?
- Does it resist brief disturbances such as shadows, overpasses, reflective architecture, and partial tunnel exposure?
- Does installation reality match calibration assumptions, including glass, trim, contamination, and neighboring sensors?
- Can faults and degraded states be identified clearly in validation and in service?
If one of those answers is weak, the program usually does not need a broader marketing claim or a more polished software description. It needs another loop of route-based testing, sensor-path review, and calibration refinement.
The cleanest evaluation sequence is simple: confirm sensing physics, validate timing logic, inspect installation, test nuisance scenarios, then verify market-specific integration and diagnostics. That order catches most of the expensive mistakes before they become field complaints. For a smart headlight activation sensor, that is the difference between a feature that quietly improves visibility and one that teaches drivers to stop trusting automation.