
Industry Portal
Related News
- 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems
How Auto Sensor Switches Work in Vehicles: Types, Trigger Logic, and Common Failures
Why do auto sensor switches matter more than most drivers realize?
Auto sensor switches sit quietly behind everyday vehicle functions.
They decide when headlights turn on, when wipers react, and when warning systems should wake up.
In older vehicles, many of these actions depended on manual input.
In newer models, especially NEVs, they rely on tighter sensor logic and faster body network responses.
That shift matters because exterior intelligence is no longer separate from comfort, safety, and energy efficiency.
A rain sensor that reacts too slowly affects visibility.
A light sensor that misreads twilight can reduce confidence and compliance.
A blind-spot trigger that behaves inconsistently can erode trust in the whole assistance system.
Within the broader AEVS view of vehicle aesthetics and dynamic driving perception, auto sensor switches act like nerve endings.
They connect optical sensing, body electronics, and user-facing behavior into one practical loop.
Understanding how they work helps when symptoms appear subtle, intermittent, or easy to blame on something else.
So what exactly are auto sensor switches in a vehicle?
The term covers more than a simple on-off device.
In practical use, auto sensor switches combine a sensing element, trigger logic, and a switching command.
Some are compact standalone units.
Others work as part of a body control module, lighting controller, or ADAS-related subsystem.
The most common types include photoelectric, capacitive, ultrasonic, radar-based, and optical rain sensing designs.
Each type watches a different signal and converts that signal into a decision.
That decision may activate a relay, send a CAN or LIN message, or request action from a smart controller.
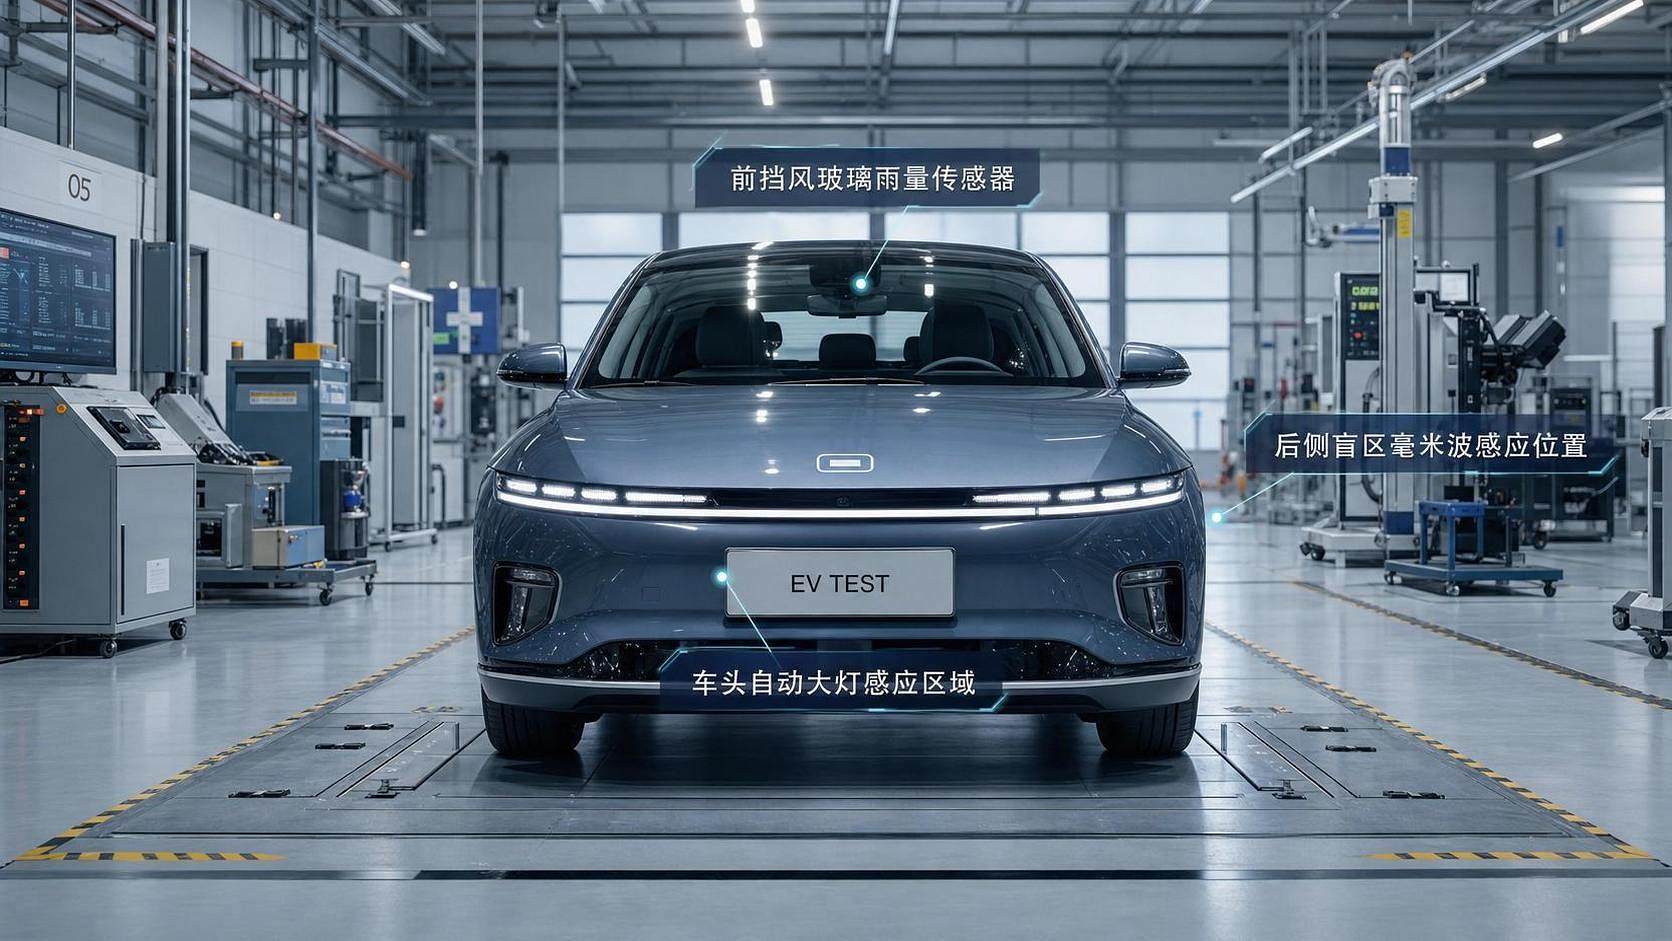
In a modern exterior and vision system, common examples include:
- Automatic headlight switches using ambient light detection
- Rain-sensing wiper switches using windshield optical reflection
- Blind-spot or proximity triggers using mm-wave sensing
- Auto-dimming mirror activation using front and rear light comparison
- Approach or door-related exterior lighting triggers
The key point is simple.
An auto sensor switch is not judged only by sensitivity.
It is judged by whether it turns raw environmental data into a stable, useful action.
How does the trigger logic actually decide when to switch?
This is where many misunderstandings begin.
Most auto sensor switches do not respond to one signal one time.
They follow a logic chain designed to avoid false activation.
A headlight sensor, for example, may not switch on the moment light drops.
It often waits for a threshold, a delay period, and confirmation that the change is not temporary.
The same principle applies to rain sensing.
One droplet pattern may not trigger full wiping.
The system may evaluate spread, repeat frequency, and signal strength before changing wiper speed.
In actual vehicle design, the trigger logic often includes:
- Threshold values for light, moisture, distance, or motion
- Time delays to prevent flicker or oscillation
- Hysteresis, so turn-on and turn-off points are different
- Signal filtering to remove noise and vibration effects
- Cross-checking with speed, gear status, or other modules
This is especially relevant in smart headlight systems.
The switch event may be only one layer inside a larger optical control strategy.
AEVS often frames this as a stitching task.
Exterior sensors, optical algorithms, and road-use requirements have to align.
That is why a switch that seems simple from outside may involve complex calibration inside.
A quick comparison helps
The table shows why diagnosis must follow the sensing path, not just the visible symptom.
Which types of auto sensor switches are most common today?
Not every vehicle uses the same architecture.
Still, a few categories dominate current platforms.
Photoelectric switches
These are common in automatic lighting.
They monitor ambient brightness and feed that value into a controller.
They are relatively mature, but placement and lens contamination still matter.
Optical rain-sensing switches
These usually sit near the windshield and read reflection changes caused by water.
They are effective, but very sensitive to glass replacement quality and gel coupling condition.
mm-wave sensor-triggered switches
These support blind-spot monitoring and rear cross-traffic alerts.
They are increasingly important in NEVs with more integrated perception systems.
Their challenge is not only detection accuracy, but stable filtering in dense traffic environments.
Capacitive or proximity-triggered switches
These appear in handles, liftgates, or approach lighting functions.
They improve convenience, though moisture and grounding quality can affect behavior.
Choosing between these types depends on function, environment, packaging space, and system integration level.
In the AEVS ecosystem, that decision also connects with headlight performance, exterior aerodynamics, and power management.
Why do auto sensor switches fail, even when the hardware seems fine?
The obvious answer is sensor damage, but that is not the whole story.
Many auto sensor switches fail because the input is distorted, the logic is miscalibrated, or communication is interrupted.
That is why replacement alone does not always solve the issue.
More common causes include:
- Dirty optical surfaces, especially around light and rain sensors
- Poor windshield replacement alignment or incorrect adhesive interface
- Voltage instability, weak grounds, or connector corrosion
- Software mismatch after module replacement or battery events
- Radar obstruction from body repair materials or bumper changes
- Unrealistic user expectations about trigger delay
That last point is worth noting.
Sometimes a system is working as designed, but its response feels wrong because the trigger logic is conservative.
For example, headlights may wait to avoid flickering under bridges.
Wipers may hold back after a few scattered drops.
Blind-spot systems may suppress alerts at low relevance angles.
So the right question is not only, “Did the switch fail?”
A better question is, “Is the sensing, logic, or communication layer behaving outside specification?”
How can you judge a problem before replacing parts?
A structured check saves time and prevents unnecessary swaps.
In practice, start with the condition around the sensor, then move inward toward data and control.
This approach is especially useful where auto sensor switches interact with larger exterior systems.
For example, a lighting complaint may involve the sensor, the body module, or the LED headlight controller.
A perception warning may trace back to mounting geometry rather than failed electronics.
Short version: diagnose the chain, not only the endpoint.
What should you keep in mind as vehicles become more intelligent?
Auto sensor switches are becoming less isolated and more networked.
That means future reliability depends on both component quality and system coordination.
In smart mobility platforms, the switch function may influence headlights, mirrors, wipers, warning lights, and ADAS prompts at once.
This is one reason AEVS pays close attention to exterior perception, optical algorithms, and compliance signals such as ECE and DOT expectations.
The operating question is no longer just whether a switch turns on.
It is whether the vehicle interprets real-world conditions consistently, efficiently, and safely.
If you are reviewing auto sensor switches in service or maintenance, focus on a few basics:
- Match symptoms to the exact function and trigger condition
- Check contamination, mounting, wiring, and calibration before replacement
- Consider software and network communication, not just hardware failure
- Compare behavior against design logic, especially delay and hysteresis
- Track changes after repairs involving glass, bumpers, or lighting modules
Auto sensor switches may be small components, but they shape how intelligent vehicles feel in daily use.
When the logic is right, the vehicle feels smooth and predictable.
When the logic is off, even advanced systems can feel unreliable.
The best next step is to build a simple evaluation routine for sensing condition, trigger behavior, and system response.
That makes comparison easier, reduces false replacement, and improves long-term confidence in increasingly connected exterior systems.