
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
Driver Monitoring in Smart Optical Systems: Key Functions, Sensors, and Use Cases
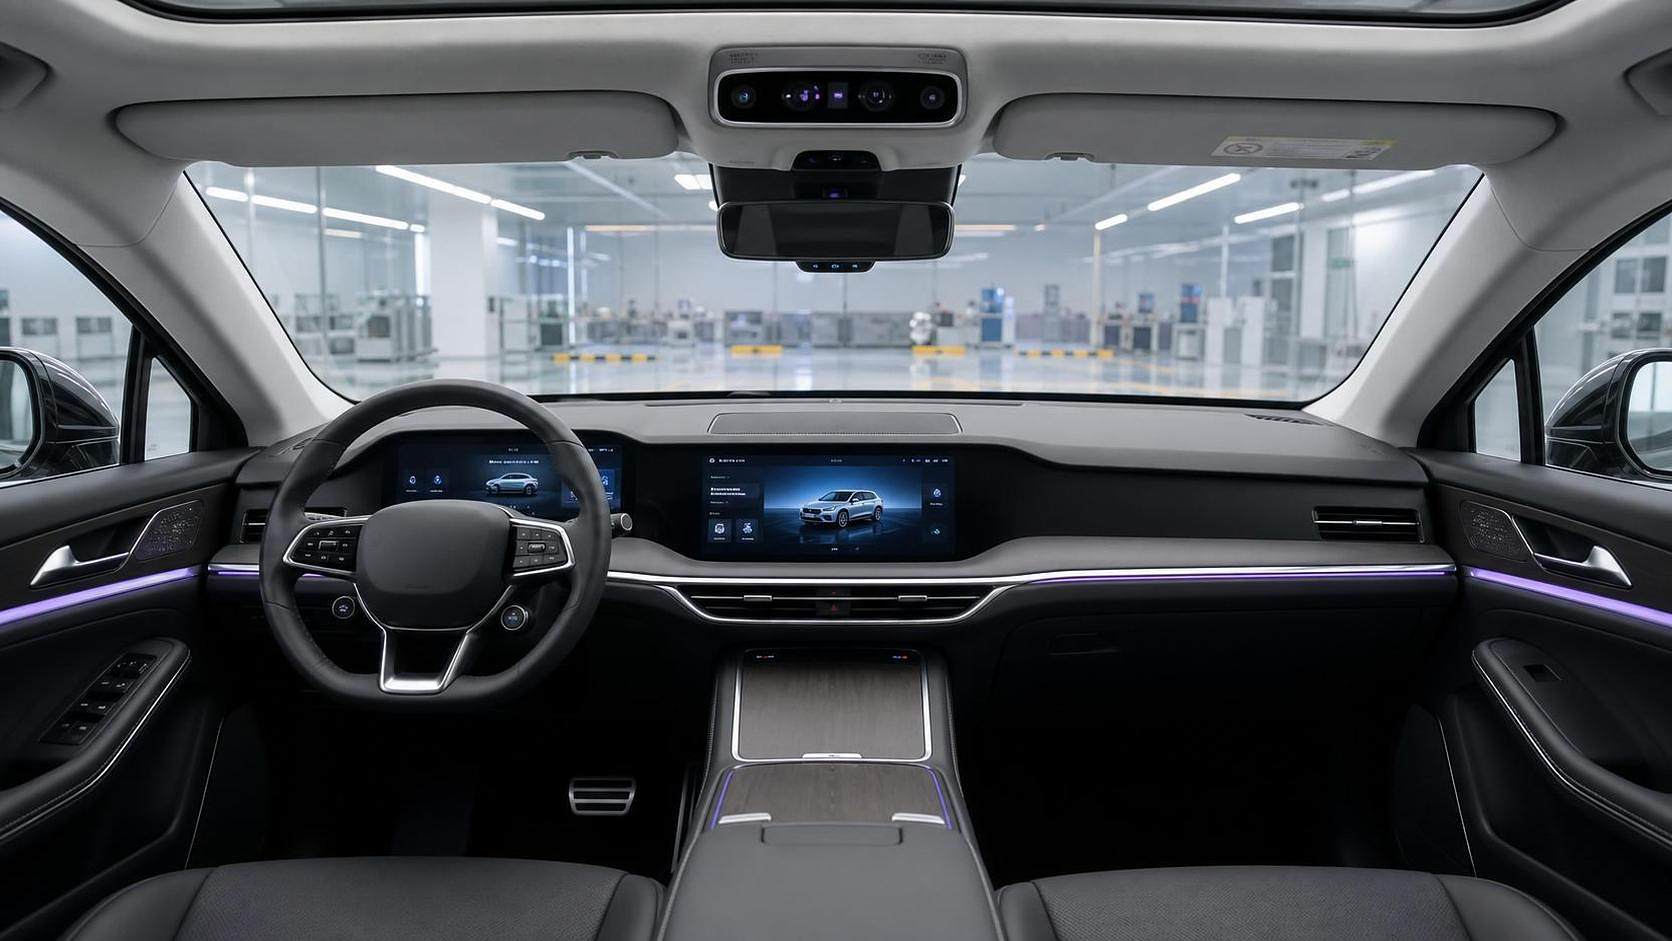
Driver monitoring is becoming a defining layer in intelligent mobility, especially where in-cabin vision must work alongside exterior sensing, lighting logic, and safety software. In that context, smart optical systems driver monitoring is no longer a niche feature. It is part of a broader perception stack that helps vehicles understand not only the road, but also the condition, attention, and readiness of the person behind the wheel.
That shift matters because advanced driver assistance systems are asking for more reliable human supervision. It also matters because electric and software-defined vehicles are turning the cabin into an active sensing environment. For platforms shaped by optical intelligence, lightweight design, and user experience, driver monitoring now sits close to the center of product planning.
Why driver monitoring now sits inside the optical conversation
In earlier vehicle generations, cameras and sensors mainly looked outward. They supported parking, lane keeping, blind-spot coverage, and lighting response. Today, the same logic is moving inward.
Smart optical systems driver monitoring extends perception into the cabin. It uses cameras, infrared emitters, image processing, and behavioral models to interpret eye gaze, eyelid closure, head pose, and occupancy patterns.
This is especially relevant to the AEVS view of the industry. Exterior intelligence and cabin intelligence are increasingly linked. A vehicle that can adapt headlights, auto wipers, and blind-spot logic also benefits from understanding whether the driver is alert enough to respond.
In practical terms, the optical system is no longer only about seeing farther. It is also about judging when the human operator is not seeing well enough, not paying attention, or not in control.
What smart optical systems driver monitoring actually does
At its core, driver monitoring checks driver state in real time. It does not replace driving. It evaluates whether the driver is ready, distracted, fatigued, or temporarily unable to supervise automation.
Core functions commonly deployed
- Distraction detection through eye gaze tracking and head direction analysis.
- Fatigue detection through blink rate, blink duration, and micro-sleep indicators.
- Hands-off and supervision support for Level 2 and Level 2+ driving features.
- Occupant presence and seating posture recognition for safety logic.
- Takeover readiness assessment when automated functions request human intervention.
- Personalization triggers for mirrors, displays, climate, and lighting zones.
These functions share one business goal: reduce the gap between system capability and human behavior. That gap is where many safety failures happen.
Sensors behind the system
Not every driver monitoring setup uses the same hardware. Sensor selection depends on cabin architecture, cost targets, performance requirements, and regulation.
In many modern architectures, the best results come from fusion rather than a single sensor. Camera-based interpretation may handle gaze well, while radar or depth sensing improves occupancy and motion confidence.
That aligns with the wider AEVS perspective. Smart headlights, sensor switches, and body perception systems already rely on combined data paths. Driver monitoring follows the same direction.
Where the strongest industry attention is going
Current attention is not only about adding another cabin camera. The real focus is on trust, compliance, and system robustness.
Regulation and liability
As assisted driving functions spread, regulators are asking whether a vehicle can verify driver engagement. Standards and regional expectations are pushing monitoring from premium option to strategic requirement.
Night performance and optical reliability
Cabin sensing must work under sunglasses, shadows, backlight, tunnels, and nighttime conditions. That makes optical quality, IR design, and algorithm tuning as important as the camera itself.
Integration with broader vehicle experience
Driver state data is starting to influence other systems. Warning timing, seat vibration, display dimming, mirror behavior, and even adaptive lighting logic can all change based on driver readiness.
For an intelligence platform such as AEVS, this matters because perception is becoming cross-domain. Exterior optics, interior sensing, and vehicle dynamics are no longer separate engineering stories.
Use cases across modern mobility platforms
The value of smart optical systems driver monitoring becomes clearer when seen in specific operating contexts.
Passenger vehicles with advanced assistance
This is the most visible use case. Highway assist and urban pilot features need proof that the driver is watching the road and can retake control quickly.
Electric vehicles with software-defined cabins
EVs often combine large displays, quiet cabins, and feature-rich interfaces. That can improve comfort, but it also raises distraction risk. Monitoring helps balance immersive UX with safe attention management.
Commercial and fleet applications
Long driving hours and repetitive routes make fatigue detection especially relevant. In these cases, smart optical systems driver monitoring may support incident reduction, training feedback, and insurance discussions.
Premium platforms focused on perception branding
Vehicles positioned around intelligent lighting, visual identity, and high-end HMI increasingly treat driver monitoring as part of their perception brand. It reinforces the idea that the vehicle understands both surroundings and occupants.
What determines whether the system is genuinely useful
A driver monitoring feature can look impressive in a demo and still fail in daily use. The difference usually comes down to several operational factors.
- Camera placement must suit actual seating positions, not only ideal lab geometry.
- Algorithms should handle glasses, masks, facial variation, and partial occlusion.
- Alerts need calibrated timing, or users will ignore them quickly.
- Privacy policy and data handling must be clear, especially for image-derived data.
- The system should integrate with vehicle safety logic, not operate as an isolated widget.
Another point deserves attention. Smart optical systems driver monitoring should be judged by failure behavior as much as normal behavior. A system that degrades predictably is more valuable than one that performs well only in controlled conditions.
How to evaluate opportunities and next steps
When reviewing this field, it helps to frame decisions around three questions. What problem is being solved, what sensing stack is required, and how will the output affect vehicle behavior?
For some programs, the priority is regulatory readiness. For others, it is premium cabin experience or safer supervision of assisted driving. The answer changes sensor choice, software complexity, and integration cost.
It also helps to compare driver monitoring with adjacent optical investments. Headlamp intelligence, auto sensor switches, cabin comfort features, and aerodynamic packaging all compete for space, power, and design attention.
That is why the subject fits naturally within AEVS coverage. Smart optical systems driver monitoring is not an isolated electronics topic. It sits at the intersection of optics, human factors, safety regulation, and the design language of intelligent vehicles.
A useful next step is to build a simple evaluation framework: target use case, required sensing accuracy, cabin lighting conditions, regulatory exposure, and response strategy after detection. That usually reveals whether a basic camera setup is enough or whether deeper sensor fusion is justified.
As smart mobility platforms mature, the vehicles that perform best will not only see the road more clearly. They will also interpret driver state with more precision, and use that insight in ways that improve safety without damaging the driving experience.