
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
Auto Sensor Switches Explained: Types, Trigger Methods, and Common Integration Issues
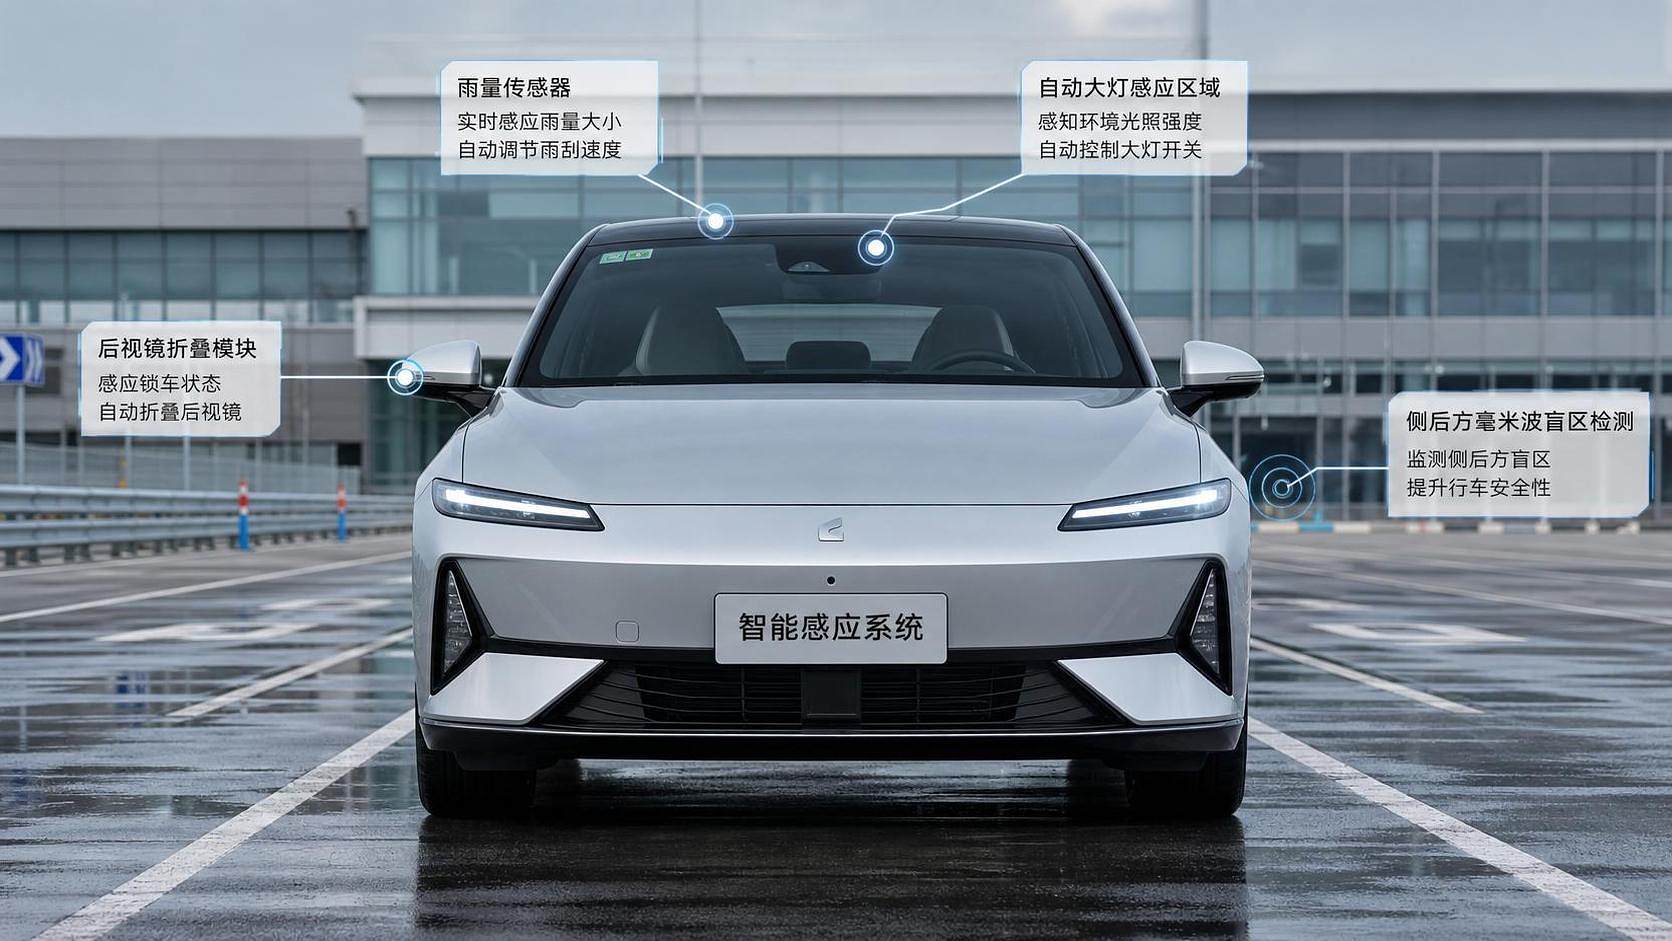
Auto sensor switches sit quietly behind many visible vehicle features, yet they shape how a car reacts to weather, light, traffic, and surrounding motion. In today’s exterior and vision architecture, they connect sensing logic with actions such as automatic headlights, rain-sensing wipers, mirror functions, and blind-spot response. That makes them more than convenience devices. They are control points where safety, perception accuracy, electrical integration, and user trust meet.
Their relevance has grown with the rise of NEVs, denser body electronics, and smarter exterior systems. Platforms now combine lightweight structures, advanced lighting, aerodynamic elements, and optical perception into a tighter network. In the AEVS view of vehicle aesthetics and dynamic driving perception, auto sensor switches act like the nerve endings of that network, translating environmental signals into fast and consistent body responses.
Why auto sensor switches matter now
A few years ago, many switching functions were treated as isolated features. Today, they are judged as part of a larger system. A headlight sensor affects visibility, energy use, and compliance. A rain sensor affects driver workload and windshield camera clarity. A proximity-triggered switch can influence blind-spot awareness, door logic, and human-machine interaction.
This shift matters because modern vehicles no longer separate exterior hardware from digital behavior. LED headlight assemblies, body controllers, mirror modules, and radar-based perception increasingly share data paths. If auto sensor switches trigger too early, too late, or inconsistently, the failure is rarely limited to one feature. It can disturb the entire exterior and vision experience.
That is one reason technical evaluations now look beyond nominal switch performance. They examine response thresholds, false activation behavior, network compatibility, environmental robustness, and calibration stability over time.
A practical way to understand the category
The term auto sensor switches covers a broad set of devices. They are not all built the same way, and they do not all solve the same problem. What unifies them is simple: they detect a condition and trigger or modulate a vehicle function without direct manual input.
In practical automotive use, the category usually includes light-responsive switches, moisture-responsive switches, proximity or presence switches, pressure-triggered switches, and radar-assisted detection switches. Some are standalone. Others are embedded inside larger electronic modules.
This diversity explains why evaluation cannot rely on one checklist. Trigger logic that works for a rain sensor may be irrelevant for a light sensor. A mm-wave based switching event also introduces signal filtering and environmental reflections that do not exist in simpler photoelectric designs.
Trigger methods shape real-world behavior
The most important distinction is not always the housing, connector, or supplier label. It is the trigger method. This determines how the switch interprets conditions, when it reacts, and how often it makes mistakes.
Threshold-based triggering
Many auto sensor switches operate by crossing a fixed or adaptive threshold. Ambient light falls below a calibrated point, so headlights turn on. Rain density crosses a sensitivity level, so the wipe cycle begins. This method is efficient, but threshold tuning is everything.
Pattern-based triggering
Some switches do not react to a single value. They look for a pattern, such as repeated droplet impacts, motion direction, or object persistence. This reduces false triggers, but it increases processing demand and validation complexity.
Context-linked triggering
More advanced systems use context from other vehicle domains. A headlight trigger may consider tunnel entry, wiper status, speed, and camera input. A blind-spot warning switch may weigh radar confidence, turn signal activation, and adjacent object speed. Here, the switch behaves less like a simple component and more like a networked decision node.
From an evaluation standpoint, the trigger method often predicts customer complaints more accurately than the data sheet. A technically compliant part can still feel unreliable if activation timing does not match normal driving expectations.
Where integration problems usually appear
Common integration issues with auto sensor switches rarely begin with total failure. They begin with edge cases. A sensor works in bench testing, then misreads low-angle sunset light. A rain switch performs well in drizzle, then struggles with road spray. A radar-triggered response detects vehicles correctly, but cross-talk appears near metal-rich body structures.
- Signal noise from nearby electronics, especially in densely packaged EV platforms.
- Mounting angle errors that shift the sensing field or optical path.
- Lens contamination, windshield coating effects, or aging of transparent materials.
- Software filtering that reduces false triggers but introduces slow response.
- CAN, LIN, or gateway timing mismatches between the switch and body controller.
- Thermal drift caused by compact installation near lighting or power electronics.
These issues are especially relevant in exterior and vision systems because packaging constraints are severe. The same design area may already host lighting modules, radar units, cameras, harnesses, and styling surfaces. Small placement changes can alter performance in ways that are not obvious during early development.
AEVS frequently frames this as an intelligence stitching problem. A switch cannot be judged only by its own trigger curve. It must fit the thermal, optical, aerodynamic, and electrical realities of the full exterior platform.
Why vehicle architecture changes the evaluation standard
Auto sensor switches used in legacy body systems were often evaluated as simple accessories. In current NEV architectures, that assumption is outdated. Battery range targets, lightweight body structures, and high-efficiency lighting systems all raise the cost of poor switching behavior.
For example, unnecessary headlight activation affects energy management, although the impact may seem small. Poor wiper triggering can degrade camera visibility and compromise advanced driver assistance performance. In a blind-spot application, an unstable trigger can reduce confidence in the warning layer even if radar hardware is technically capable.
That is why evaluation should include the surrounding domain. A light sensor belongs partly to lighting, partly to body electronics, and partly to optical perception. A rain sensor belongs not only to wiper control, but also to windshield material strategy and camera cleanliness management.
What to check before selecting or approving a solution
A useful review starts by matching the switch to the exact operating scenario. The wrong assumption at this stage causes most downstream problems. A trigger that looks ideal in a generic spec may behave poorly in a vehicle with unusual rooflines, aggressive glazing angles, or tightly integrated lamp modules.
- Define the actual trigger environment, not only the intended function.
- Review sensitivity ranges against worst-case weather, glare, dirt, and vibration.
- Check communication timing with the body control module and related actuators.
- Confirm calibration stability after thermal cycling and long-term material aging.
- Test for false positives and false negatives in mixed urban and highway conditions.
- Assess compliance implications under ECE, DOT, and regional lighting or visibility rules.
It also helps to compare the switch as part of a chain. Trigger input, controller interpretation, and actuator response should be reviewed together. Many common integration issues are not sensor defects at all. They are timing, logic, or packaging mismatches between connected subsystems.
A useful next step for ongoing assessment
The most effective way to assess auto sensor switches is to treat them as system-level enablers rather than isolated parts. That means building a comparison framework around trigger method, environmental resilience, network behavior, and fit within the broader exterior and vision stack.
In practical terms, the next step is to map each target function to its real operating conditions, then review where sensing, switching, and actuation may drift apart. For teams tracking NEV exterior evolution, this approach aligns well with the wider AEVS perspective: lighting, visibility, body response, and efficiency are now interconnected, and auto sensor switches are one of the places where that interconnection becomes measurable.
A clearer evaluation standard usually starts with a simple question: when the environment changes, does the vehicle respond at the right moment, for the right reason, and with the right level of confidence? That question remains the most practical filter for selecting, integrating, and improving auto sensor switches.