
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
How Auto Sensor Switches Work: Types, Trigger Modes, and Best-Fit Applications
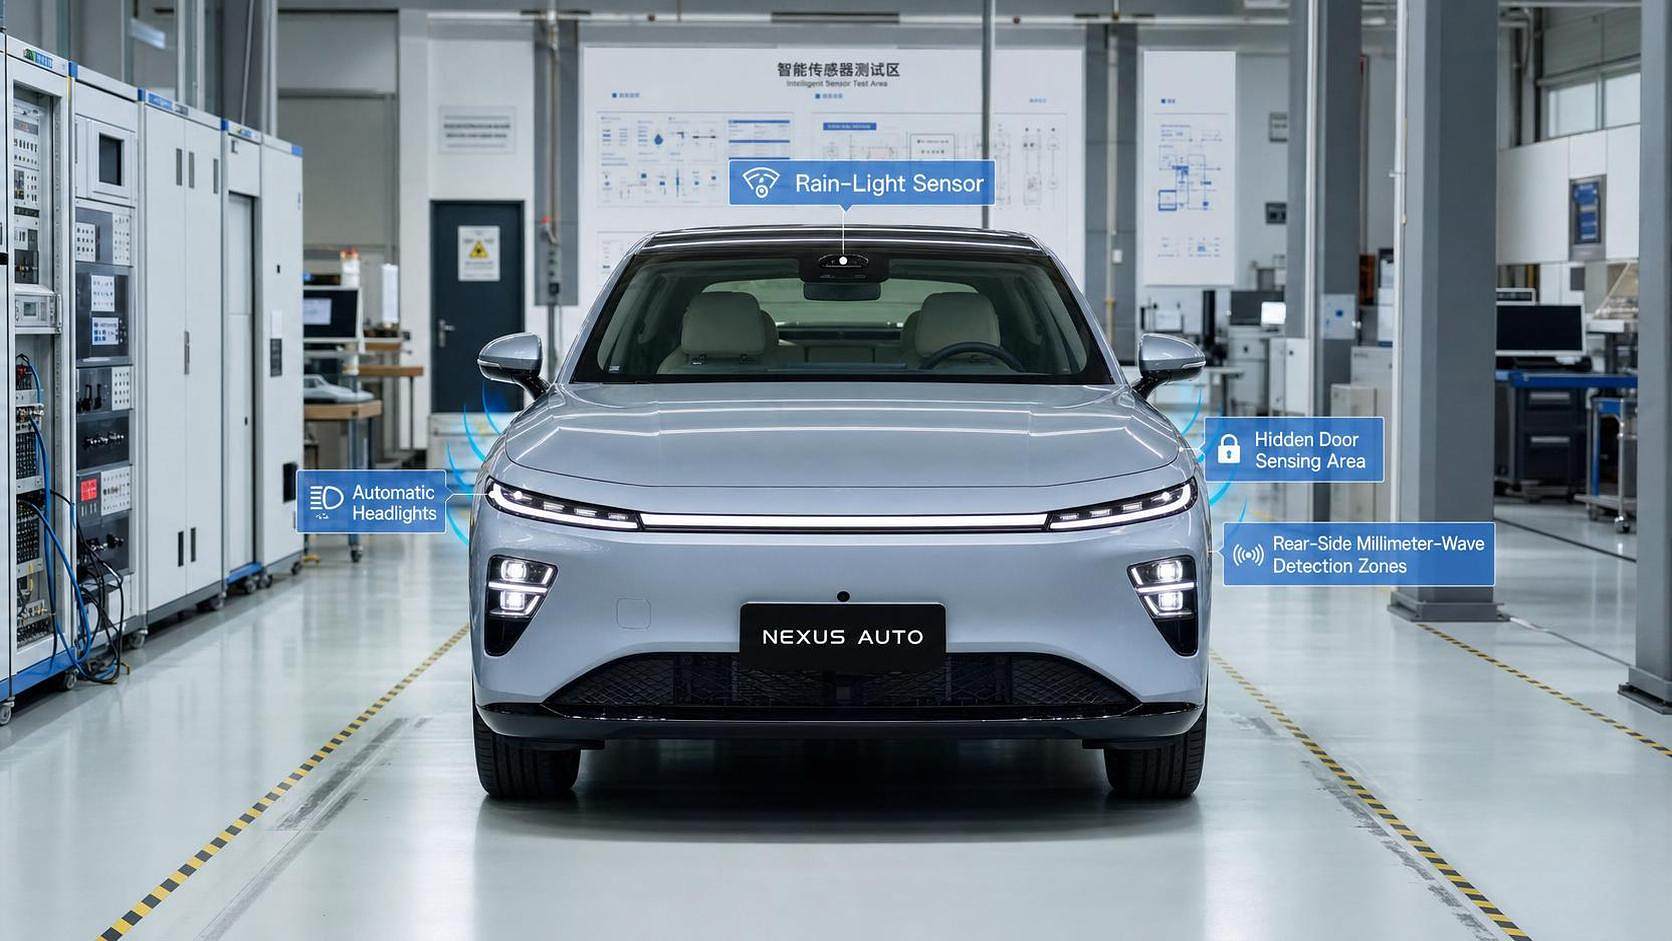
Why are auto sensor switches getting so much attention?
Auto sensor switches now sit behind many functions drivers barely notice until they fail.
They help headlights react to fading daylight, wipers respond to rainfall, and body systems interpret motion, distance, or ambient conditions.
In modern vehicles, especially NEVs, that matters for three reasons: safety, comfort, and efficient energy use.
A well-matched switch does not simply turn something on or off. It supports a larger control loop.
That is why platforms like AEVS treat auto sensor switches as part of exterior and vision intelligence, not as isolated electrical parts.
They connect optical perception, body electronics, and real-world driving inputs in a way that affects both design quality and road behavior.
So what exactly does an auto sensor switch do inside a vehicle?
At the simplest level, an auto sensor switch detects a condition and triggers a response.
That condition may be light intensity, moisture, proximity, motion, pressure, or reflected signal change.
The response may be direct, such as turning on lamps, or indirect, such as sending a signal to a control unit.
In practice, most automotive systems no longer rely on a purely mechanical switching action.
Instead, auto sensor switches combine sensing elements, signal conditioning, threshold logic, and communication with the body control module.
This is why response speed, false-trigger resistance, and calibration stability matter as much as the switching function itself.
For example, a rain sensor near the windshield reads changes in reflected light.
A light sensor measures ambient brightness and may also factor tunnel entry or sudden weather shifts.
A mm-wave sensing node can support blind-spot or approach detection, then trigger warnings or linked body responses.
The working chain usually follows a clear path
- A sensor captures an environmental change.
- The signal is filtered and compared with preset thresholds.
- The switch logic decides whether the event is valid.
- The system triggers an actuator, warning, or controller instruction.
Understanding that chain makes later selection decisions much easier.
Which types of auto sensor switches are most common today?
The answer depends on the sensing principle, not only the application label.
In actual vehicle programs, engineers usually evaluate auto sensor switches by what they detect and how reliably they detect it.
This mix reflects where the market is moving.
Exterior systems now demand lighter structures, cleaner surfaces, and smarter perception, so switch design increasingly overlaps with optics and software.
That crossover is especially visible in lighting, body access, and visibility-related functions.
Trigger modes sound simple, but what do they really change?
A trigger mode defines when the auto sensor switch decides an event is real enough to act on.
This choice affects user feel, system reliability, and even warranty performance.
The most common modes are threshold, timed, continuous, and multi-condition triggering.
Threshold trigger
The switch reacts when a value crosses a preset level.
Automatic headlights often use this logic, but better systems add hysteresis to prevent flickering.
Timed trigger
The input must remain valid for a set period before activation.
This helps avoid false reactions caused by splashes, shadows, or short interference bursts.
Continuous trigger
The system keeps adjusting while the signal changes.
Rain-sensing wipers are a familiar example because wiper speed can scale with rainfall intensity.
Multi-condition trigger
The response occurs only when two or more conditions align.
That can combine speed, darkness, and steering state, or proximity plus vehicle lock status.
In real applications, this is often the best route for reducing nuisance activation.
Where does each auto sensor switch fit best?
There is no universal best type.
The right match depends on exposure conditions, response expectations, integration complexity, and failure tolerance.
A useful way to judge fit is to start from the vehicle function rather than the component catalog.
- For auto lighting, photoelectric auto sensor switches work well when ambient light changes are frequent and fast.
- For rain management, optical sensing is preferred when windshield integration and response modulation are important.
- For blind-spot and side perception, mm-wave-linked switching logic fits better than simple proximity sensing.
- For hidden door access or flush handles, capacitive sensing supports cleaner exterior styling.
- For latch, hood, or closure confirmation, magnetic or inductive designs usually offer stronger robustness.
This matters even more for AEVS-related exterior systems, where visual cleanliness, aerodynamic discipline, and sensing accuracy must coexist.
A switch that performs well in a sheltered interior zone may behave very differently on an exposed exterior panel.
What usually goes wrong when people compare options?
One common mistake is focusing on sensitivity alone.
Higher sensitivity can improve responsiveness, but it may also increase false triggers.
Another mistake is ignoring the installation environment.
Heat, vibration, road contamination, icing, and electromagnetic noise all affect auto sensor switches differently.
There is also a tendency to treat switching hardware and control software as separate decisions.
For current automotive systems, that separation rarely holds.
The best results usually come from matching sensor physics, trigger logic, and body network behavior together.
A quick judgment table helps narrow options
How should implementation, cost, and validation be judged?
Cost is rarely just the unit price of the auto sensor switch.
A cheaper part may require more shielding, more software compensation, or more field recalibration.
That changes the real project cost quickly.
Validation should also cover more than bench performance.
It needs exposure to glare, dust, water film, vibration, thermal cycling, and regional compliance expectations such as ECE or DOT-linked lighting behavior.
For that reason, many teams review auto sensor switches alongside adjacent systems like LED headlight assemblies, wiper modules, closure hardware, and body software.
That broader view aligns with how AEVS interprets exterior intelligence: each sensing node affects perception quality, energy use, and user trust.
- Confirm the sensing principle matches the environment.
- Check whether trigger logic can be tuned after integration.
- Review contamination, temperature, and vibration tolerance early.
- Estimate software and calibration effort, not only hardware cost.
- Validate with real driving scenarios, not only lab thresholds.
What is the practical takeaway before choosing auto sensor switches?
The main question is not which auto sensor switches are most advanced on paper.
It is which ones fit the sensing task, trigger behavior, exterior exposure, and control architecture with the least compromise.
For lighting, rain response, blind-spot perception, and smart body functions, the strongest choice usually comes from system matching rather than component comparison alone.
A sensible next step is to map the application by environment, required reaction speed, false-trigger tolerance, and integration effort.
Then compare candidate auto sensor switches against those criteria before moving into validation.
That approach keeps the decision grounded, and it leads to smarter exterior and vision performance over the full vehicle lifecycle.