
Industry Portal
Related News
- 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems
mm Wave Sensors vs Ultrasonic Sensors for Blind Spot Detection: Key Trade-offs
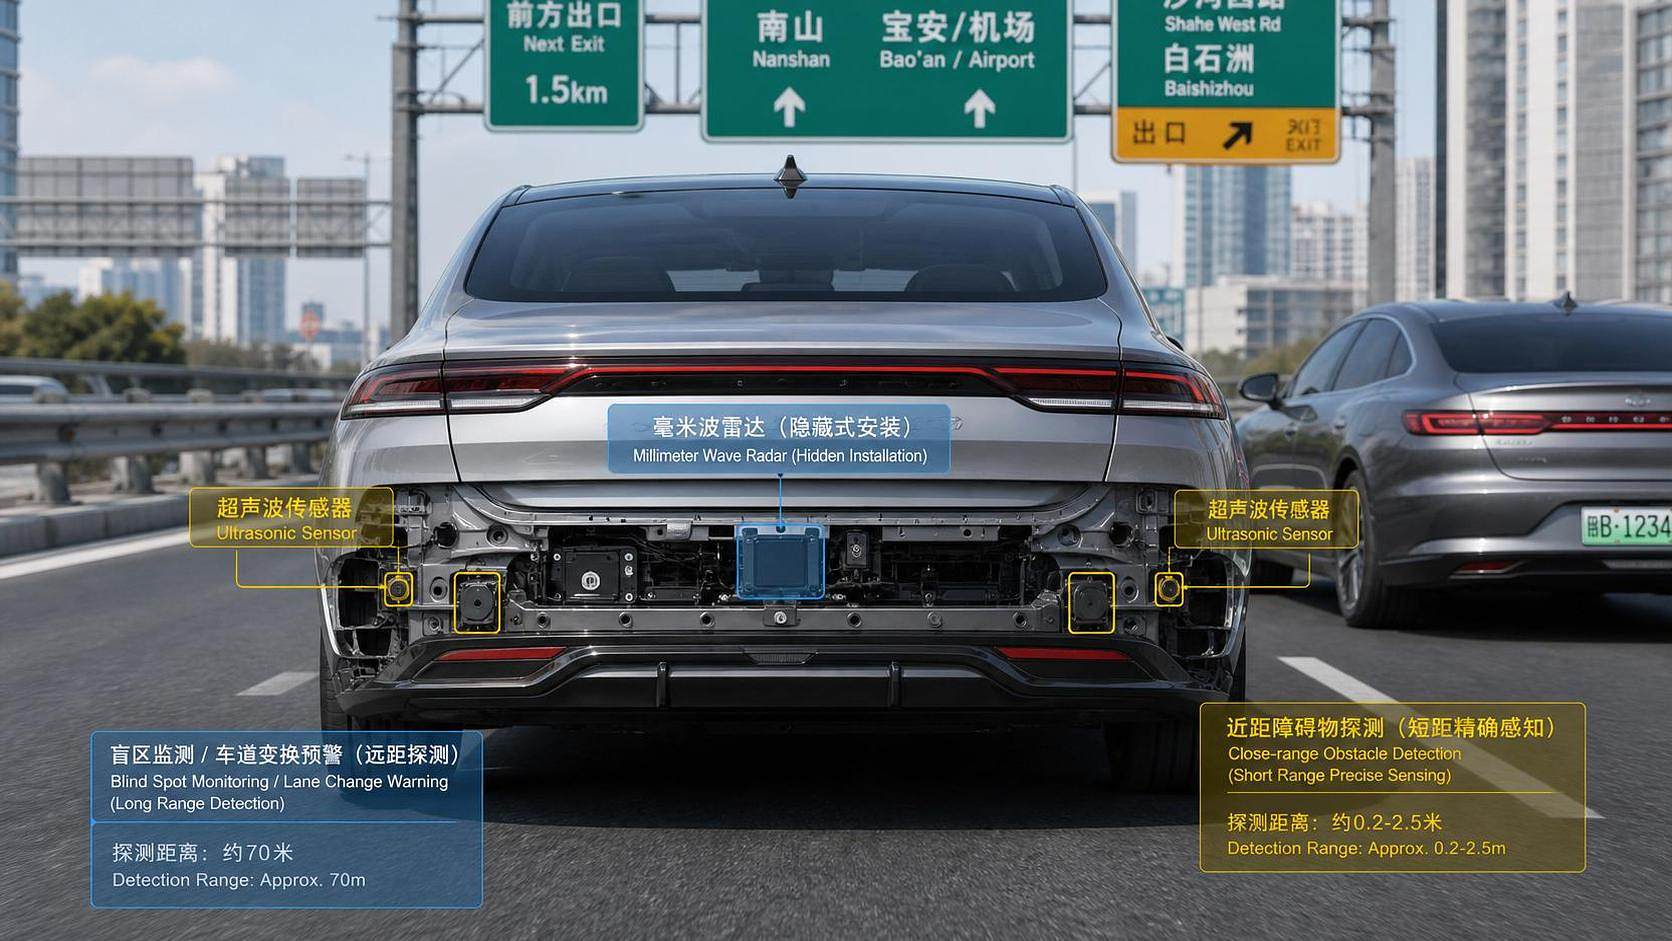
Blind spot detection has moved from a premium feature to a core safety expectation, especially in EV programs where higher curb weight and quieter cabins raise the value of reliable situational awareness.
For teams comparing sensing architectures, the real question is not whether mm wave sensors or ultrasonic sensors can detect nearby objects, but where each technology performs well, where it struggles, and how those limits affect system design.
That decision now matters beyond electronics alone. It touches bumper packaging, exterior styling, aerodynamic surfaces, compliance targets, cost control, and the broader smart perception stack discussed across AEVS in exterior and vision systems.
Why this comparison matters now
Blind spot monitoring used to be judged mainly by feature availability. Today, it is judged by consistency across weather, traffic density, vehicle speed, and body design constraints.
The shift is especially visible in new energy vehicles. Larger wheel designs, tighter rear-quarter packaging, and stronger emphasis on low-drag exteriors can all influence sensor placement and signal performance.
At the same time, buyers and regulators expect fewer nuisance alerts. A system that detects too little creates risk, but a system that warns too often also loses trust in daily use.
This is where mm wave sensors gain attention. They support longer detection ranges and better closing-speed awareness, which are increasingly important in lane-change scenarios at urban and highway speeds.
Two sensing approaches, two different strengths
Ultrasonic sensors work by emitting sound waves and measuring reflections. They are familiar, relatively affordable, and widely used for parking assistance and very short-range object detection.
mm wave sensors use radio frequency signals, typically in automotive radar bands, to estimate object distance, relative speed, and direction with much stronger performance over longer ranges.
For blind spot detection, that difference is not academic. The system must identify vehicles approaching from adjacent lanes, often before they enter the driver’s peripheral view.
Ultrasonic sensing can recognize nearby obstacles well, but it is not naturally optimized for tracking fast-moving targets from farther rear-side positions. mm wave sensors are.
Core comparison at a glance
Detection performance is the real dividing line
In blind spot monitoring, timing matters as much as object presence. A useful alert must arrive early enough for a lane-change decision, not after the adjacent vehicle is already beside the rear door.
mm wave sensors are better aligned with that requirement because they detect farther back and interpret relative motion more effectively. That means stronger performance for vehicles approaching quickly from behind.
Ultrasonic sensors can detect objects in close proximity, but their short range compresses decision time. In many blind spot scenarios, that creates a gap between sensing and usable warning value.
This becomes more critical on highways, where a few additional meters of reliable detection can make the difference between a calm assist function and a late, distracting intervention.
False alerts and missed targets
No sensor is perfect. mm wave sensors may require careful tuning to separate relevant targets from roadside structures, metallic clutter, or dense multi-lane traffic reflections.
Ultrasonic sensors face a different problem set. Their shorter range and environmental sensitivity can increase missed detections in dynamic lane-change conditions, particularly when target approach speed is high.
In practical terms, mm wave sensors usually offer a more defensible base for blind spot functions, while ultrasonic sensing remains stronger as a companion technology for near-field awareness.
Weather, contamination, and real-road stability
Test-bench performance rarely tells the full story. Rear bumper zones face spray, road salt, dust, ice, and car-wash impact, all of which influence long-term sensing quality.
mm wave sensors generally maintain better functional stability in rain, fog, and low-visibility conditions. That resilience is one reason radar-based sensing continues to expand in safety applications.
Ultrasonic sensors are more vulnerable to contamination and acoustic interference. Heavy rain, slush, or irregular surface buildup can degrade echo quality and reduce confidence in detection outputs.
For exterior system programs, this matters because sensor uptime affects perceived product quality. A premium vision and safety experience depends on stable behavior, not just headline specifications.
Packaging and vehicle integration are not secondary issues
Sensor selection also shapes the vehicle exterior. Blind spot hardware sits inside a crowded zone shared by bumper beams, harnesses, trim, wheel arch geometry, and styling constraints.
Ultrasonic sensors are compact and familiar to manufacturing teams, but they often require visible bumper apertures or surface treatments that affect appearance and finishing quality.
mm wave sensors can be hidden behind fascia materials, which supports cleaner exterior integration. That said, radar-transparent material selection and bracket positioning become more sensitive engineering tasks.
For AEVS-related programs, this links sensing directly to vehicle aesthetics, aerodynamic detailing, and cross-functional coordination with lighting, wheel airflow management, and other exterior systems.
Integration questions worth checking early
- Can the bumper material support stable mm wave sensors performance across paint stacks and temperature cycles?
- Will wheel spray, tire debris, or rear-quarter airflow contaminate the sensing zone?
- Does the architecture need one sensor type, or a layered strategy for both blind spot and parking functions?
- How much calibration effort is acceptable during assembly and service replacement?
Cost should be judged at system level
Ultrasonic sensors usually look attractive on unit price. That is a valid advantage in entry-level programs or features limited to low-speed parking support.
But blind spot detection should not be evaluated on component price alone. Missed performance targets can force additional software filtering, more validation cycles, or parallel sensor additions later.
mm wave sensors cost more upfront, yet they can reduce architectural compromise when the target includes highway-capable blind spot alerts, lane-change support, and stronger all-weather behavior.
The better comparison is total delivered function per vehicle platform, not isolated sensor cost. That includes warranty exposure, customer complaints, integration rework, and upgrade flexibility.
Where each technology fits best
The market does not treat these technologies as pure substitutes in every case. Their strongest applications overlap only partly.
Simple parking-oriented vehicles may still justify heavy ultrasonic use. Smart exterior platforms aimed at higher-speed assistance usually lean toward mm wave sensors for blind spot coverage.
A practical evaluation framework
A sound comparison starts with scenario definition. Blind spot detection in urban delivery traffic is not the same task as blind spot detection in fast multi-lane commuter driving.
Then check the sensing envelope against the vehicle program. Rear-quarter sheet metal, bumper shape, wheel design, and contamination paths can change actual performance more than expected.
Finally, match the sensor choice to the broader roadmap. If the platform will later add rear cross-traffic alert or richer ADAS features, mm wave sensors often create a better upgrade path.
- Define target speeds and warning timing before comparing suppliers.
- Test contamination, rain, and splash conditions early.
- Review fascia materials and mounting angles with exterior teams.
- Evaluate false-alert behavior in dense traffic, not only clean tracks.
- Consider future feature expansion when judging current cost.
What the trade-off looks like in business terms
The main trade-off is straightforward. Ultrasonic sensors offer low-cost, near-field awareness. mm wave sensors deliver stronger blind spot performance where range, speed discrimination, and weather tolerance matter most.
For programs tied to premium perception, smarter exterior integration, and higher customer expectations, mm wave sensors usually provide the more credible technical foundation.
The next step is to turn that conclusion into a platform-specific scorecard. Compare range needs, exterior packaging, environmental exposure, feature roadmap, and total system cost on the same sheet.
That approach creates a clearer decision than price comparison alone, and it aligns blind spot architecture with the broader vehicle exterior and vision strategy shaping current mobility programs.