
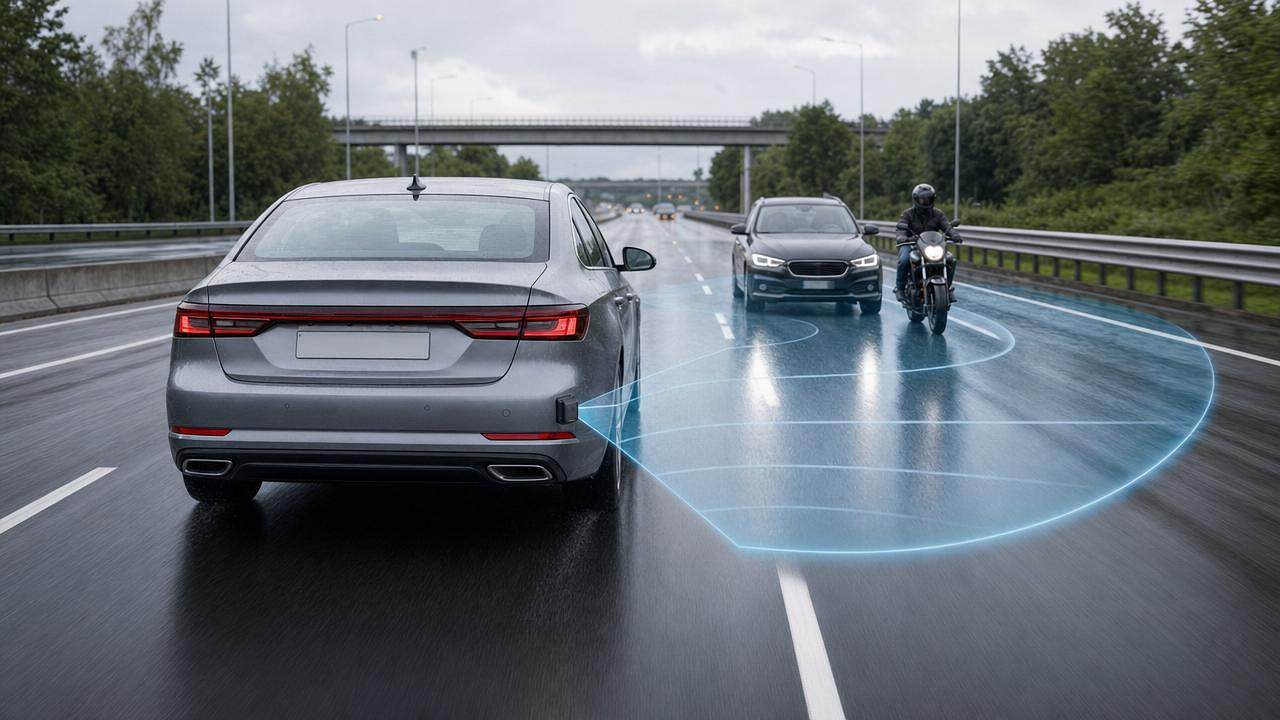
mm-Wave Sensing in Blind Spot Radars: Range, Resolution, and Limits
For quality control and safety managers, blind spot radar performance is no longer a checklist item—it is a measurable safety boundary.
This article examines how mm-wave sensing defines detection range, angular resolution, and real-world limits in automotive blind spot monitoring.
It focuses on rain, vibration, lane clutter, and complex traffic scenarios where validation gaps can become operational safety risks.
By understanding what radar can reliably detect, teams can strengthen compliance testing, reduce false alarms, and support safer exterior perception systems.
Why Blind Spot Radar Performance Must Be Treated as a Safety Boundary
For quality control teams, blind spot radar should not be judged only by whether it activates during a demonstration.
The real question is whether the system detects relevant targets consistently, at the required distance, angle, and closing speed.
For safety managers, this distinction matters because a missed motorcycle or repeated false warning can both increase operational risk.
Modern blind spot monitoring depends heavily on mm-wave sensing because radar remains robust under darkness, glare, dust, and moderate weather.
However, robustness does not mean unlimited performance, and every radar has measurable boundaries shaped by physics, packaging, and software.
The most useful validation approach is therefore not asking whether radar works, but defining where it works reliably.
What Searchers Usually Want to Know About mm-Wave Sensing
Users searching this topic usually need practical answers, not a general explanation of electromagnetic waves or automotive electronics.
They want to know how far a blind spot radar can detect, how precisely it separates objects, and when it fails.
Quality teams also want to understand which test conditions reveal weak designs before they reach production or fleet operation.
Safety managers often focus on risk scenarios: lane changes, motorcycles, adjacent-lane traffic, wet roads, trailers, and bumper damage.
The most valuable content therefore connects radar range and resolution with validation methods, acceptance criteria, and failure-mode thinking.
How mm-Wave Sensing Measures Range in Blind Spot Applications
Automotive blind spot radars commonly operate in the 76 to 81 GHz band, using frequency-modulated continuous-wave radar techniques.
The radar transmits chirps, receives reflections, and estimates target distance from the frequency difference between transmitted and returned signals.
In practical terms, range is not just maximum detection distance. It is usable, stable, classified detection under defined conditions.
A passenger vehicle blind spot radar may detect vehicles tens of meters behind and beside the host vehicle.
Yet the effective safety range depends on mounting height, bumper material, antenna design, target reflectivity, and traffic geometry.
Large metallic vehicles usually return stronger reflections than bicycles, motorcycles, or pedestrians wearing low-reflectivity clothing.
For quality validation, range should be assessed by target type, approach speed, lateral offset, and environmental condition.
Why Maximum Range Is Not the Same as Reliable Detection Range
A datasheet may state a maximum range, but quality managers should avoid treating that number as a safety guarantee.
Maximum range is often measured with ideal targets, clean surroundings, favorable alignment, and carefully controlled laboratory conditions.
Reliable detection range is narrower because real traffic includes curved roads, partial occlusion, wet surfaces, and non-ideal target angles.
The difference between these two ranges is where many validation problems begin, especially during design release and supplier approval.
A practical specification should define probability of detection, false alarm rate, and classification stability across realistic use cases.
Teams should also test detection continuity, because intermittent target loss can confuse warning logic during lane-change decisions.
Angular Resolution: The Key to Separating Real Threats from Background Clutter
Angular resolution describes the radar’s ability to distinguish two objects located at similar distances but different directions.
In blind spot monitoring, angular resolution is critical because adjacent lanes, guardrails, parked vehicles, and motorcycles may overlap spatially.
A radar with poor angular separation may merge targets, misclassify lane position, or trigger warnings for roadside structures.
Better angular resolution usually requires advanced antenna arrays, multiple receiving channels, and signal processing such as digital beamforming.
However, resolution is affected by installation constraints because exterior styling, bumper curvature, and bracket tolerance influence beam patterns.
Quality teams should evaluate angular performance after final vehicle integration, not only at the sensor module level.
Range Resolution and Why Small Distance Errors Matter
Range resolution determines how well radar separates targets located at different distances along the same line of sight.
For blind spot systems, this affects whether the radar distinguishes a close motorcycle from a farther vehicle behind it.
It also affects tracking behavior when vehicles approach quickly from the rear or move through the detection zone.
Range resolution depends strongly on chirp bandwidth, signal processing quality, calibration, and the noise environment around the sensor.
Small errors may appear acceptable in static tests but become important when warning timing is evaluated dynamically.
For safety managers, the concern is not centimeter perfection, but whether warning timing remains appropriate under real closing speeds.
Doppler Measurement: Why Speed Estimation Supports Better Warnings
Blind spot radar does more than detect presence; it estimates relative velocity using Doppler information from reflected signals.
This velocity data helps determine whether a target is approaching, traveling alongside, moving away, or likely to become hazardous.
Speed estimation is especially important for fast motorcycles, overtaking vehicles, and highways where closing rates change quickly.
Poor Doppler stability can create delayed warnings, unnecessary warnings, or missed warnings during aggressive lane-change scenarios.
Validation should therefore include dynamic passes at different speeds, not only stationary targets placed near the rear quarter.
Rain, Spray, and Wet Roads: What mm-Wave Radar Handles Well
One reason mm-wave sensing is valuable is its relative resilience compared with cameras under rain, darkness, and glare.
Radar wavelengths can penetrate moderate rain and maintain detection where optical perception may suffer from water, light scatter, or contamination.
That advantage is important for exterior perception systems, especially when blind spot warnings must work during poor visibility.
However, heavy rain, road spray, and water films on bumpers can still reduce signal quality and increase multipath reflections.
Wet road surfaces may reflect radar energy in unexpected directions, creating ghost targets or weakening useful target returns.
Quality teams should test wet-road conditions with moving traffic, not only spray exposure in isolated environmental chambers.
Vibration, Mounting Tolerance, and the Hidden Risk of Misalignment
Radar performance can degrade when the sensor bracket shifts, the bumper deforms, or vibration changes the effective pointing angle.
Even small angular misalignment can move the radar’s detection zone away from the intended blind spot region.
This is especially relevant after minor collisions, bumper replacement, aftermarket modifications, or repeated exposure to rough road vibration.
Quality control should include mechanical tolerance stack-up analysis, production calibration checks, and post-installation verification procedures.
Safety managers should also consider service procedures, because a technically capable radar can fail through poor repair alignment.
A robust program verifies radar performance at component, vehicle, production, and service levels, not just during initial design validation.
Lane Clutter and Urban Complexity: Where False Alarms Begin
Blind spot radar operates in environments filled with reflective objects, including signs, guardrails, bicycles, parked cars, and roadside barriers.
The system must decide which reflections represent meaningful collision risk and which are harmless background clutter.
False alarms reduce driver trust, and repeated nuisance warnings may cause drivers to ignore valid alerts later.
At the same time, aggressive filtering can suppress real targets, especially motorcycles or small vehicles near lane boundaries.
This tradeoff is central to blind spot radar calibration and should be reviewed with clear safety priorities.
Validation should cover highway barriers, multilane traffic, merging zones, tunnels, urban intersections, and vehicles traveling at varied offsets.
Motorcycles, Bicycles, and Low Radar Cross-Section Targets
Not all road users reflect radar energy equally, and this creates an important safety consideration for blind spot monitoring.
Motorcycles can present smaller radar cross-sections than cars, especially at certain angles or when partially masked by traffic.
Bicycles and scooters can be harder still, depending on materials, speed, body posture, and lateral movement pattern.
Safety managers should avoid validating blind spot systems only with passenger cars or standardized large metallic targets.
A strong test program includes vulnerable and small-profile targets across relevant speeds, angles, and environmental conditions.
For NEV platforms, quiet cabins and rapid acceleration make accurate side-rear perception especially valuable during lane changes.
Bumper Materials, Paint, and Exterior Design Influence Radar Performance
Radar is usually hidden behind bumper covers, making exterior design an active part of the sensing system.
Material thickness, paint layers, metallic coatings, repair filler, and curvature can all influence radar transmission and reflection.
Stylish rear bumper designs may create packaging challenges if sensor viewing angles or radome characteristics are not controlled.
For quality teams, this means radar validation must include final production materials, colors, and trim variants.
Aftermarket accessories can create additional risk by blocking or distorting the radar field without obvious visual evidence.
Supplier documentation should identify approved material windows, service restrictions, and inspection criteria for sensor-covered exterior zones.
What Quality Control Teams Should Measure Before Release
A release-ready blind spot radar program should define measurable performance indicators rather than relying on subjective driver impressions.
Core metrics include detection range, angular accuracy, range accuracy, relative velocity accuracy, latency, false alarm rate, and missed detection rate.
These should be evaluated across target categories, lane positions, speeds, weather exposure, and vehicle loading conditions.
Production audits should verify sensor placement, bracket integrity, electrical connection quality, software version, and calibration status.
Quality teams should also analyze failure trends from road tests, warranty returns, service records, and field complaints.
The goal is not only passing compliance tests, but detecting process drift before it becomes a safety issue.
How Safety Managers Can Evaluate Operational Risk
Safety managers should view blind spot radar as one control layer within a broader driver assistance safety strategy.
The system reduces risk when it reliably supports driver awareness, but it cannot replace mirrors, shoulder checks, or responsible driving.
Operational risk increases when drivers overtrust alerts, misunderstand limitations, or operate vehicles with damaged sensor zones.
Fleet safety programs should include driver education explaining when blind spot warnings may be delayed, suppressed, or inaccurate.
Inspection routines should check bumper damage, sensor warnings, software update status, and any modifications near radar locations.
This risk-based approach helps organizations use mm-wave sensing effectively without assuming it is infallible.
Compliance Testing Is Necessary, but Real-World Validation Is Essential
Regulatory and industry standards provide useful baselines for evaluating blind spot monitoring and lane-change assistance functions.
However, compliance scenarios may not cover every environmental, mechanical, and behavioral condition encountered in service.
Quality leaders should treat standards as minimum requirements and add internal validation scenarios based on actual risk exposure.
This is particularly important for global vehicle programs operating across different road markings, weather patterns, speeds, and traffic cultures.
Data from proving grounds, simulation, controlled roads, and fleet monitoring can be combined to improve confidence.
The best programs document both passing results and known limitations so safety decisions remain transparent.
Common Limits of mm-Wave Sensing That Teams Should Not Ignore
mm-wave sensing is powerful, but it is still limited by physics, installation quality, processing assumptions, and environmental complexity.
It may struggle with extremely small targets, unusual reflection angles, heavy contamination, bumper damage, or dense multipath environments.
It may also classify objects incorrectly when several targets overlap within the same range and angle region.
Interference between nearby radars can be managed, but it remains a design and validation consideration as sensor density increases.
Software updates can improve filtering and tracking, yet they may introduce new behavior requiring regression testing.
Recognizing these limits early allows teams to set realistic requirements and reduce surprises after production launch.
Practical Checklist for Supplier and Platform Review
When reviewing a radar supplier or vehicle platform, start by asking how detection performance is defined and verified.
Request evidence for range, angular resolution, velocity estimation, latency, false alarms, and missed detections under realistic conditions.
Confirm whether tests include motorcycles, bicycles, wet roads, curved lanes, guardrails, tunnels, vibration, and production bumper materials.
Review calibration methods, end-of-line procedures, diagnostic capability, service repair instructions, and software change control practices.
Ask how the system behaves when sensor alignment is degraded, the bumper is damaged, or radar transparency changes after repair.
A mature supplier should explain not only peak performance, but also known limits and mitigation strategies.
Where Exterior Perception Is Heading
Blind spot radars are evolving from simple warning sensors into integrated exterior perception nodes within broader vehicle intelligence systems.
Higher channel counts, better antennas, improved algorithms, and sensor fusion will continue improving detection confidence and object separation.
For electric vehicles, the interaction between aerodynamic exterior design and hidden sensor performance will become more important.
Future validation will likely place greater emphasis on full-vehicle perception quality rather than isolated component specifications.
This means quality, safety, styling, electronics, and service teams must cooperate earlier in the development process.
The competitive advantage will belong to organizations that understand sensing limits before customers or regulators discover them.
Conclusion: Define the Boundary, Then Validate Against It
mm-wave sensing gives blind spot radars a strong foundation for detecting vehicles under difficult visual conditions.
Its value depends on more than maximum range; reliable safety performance requires validated range, resolution, velocity, and classification behavior.
Quality control teams should focus on measurable performance across realistic targets, environments, mounting conditions, and production variations.
Safety managers should translate those measurements into operational rules, inspection routines, driver communication, and risk controls.
The clearest conclusion is practical: blind spot radar is highly valuable, but only when its limits are understood and managed.
By treating radar performance as a defined safety boundary, organizations can reduce false confidence and build stronger exterior perception systems.