
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
Where mm-wave sensing still struggles in dense traffic
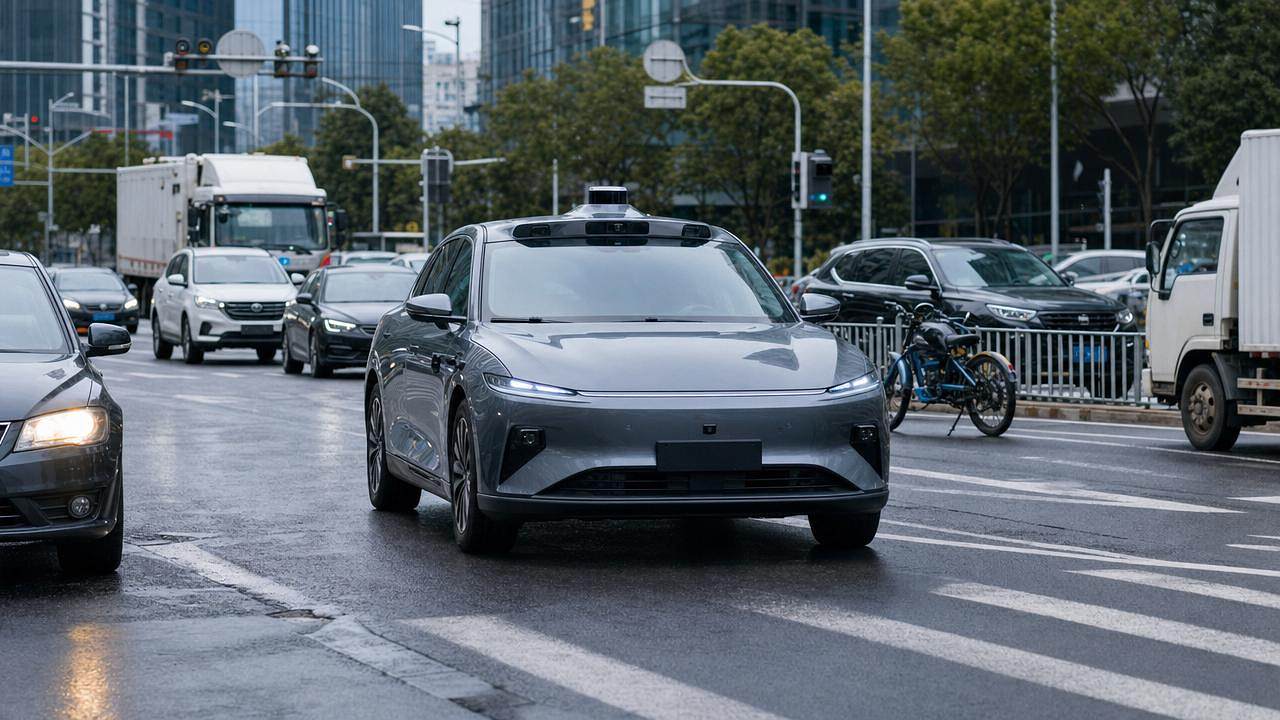
In dense traffic, mm-wave sensing remains essential for modern driver assistance, yet its weakest points appear when the road becomes crowded, layered, and unpredictable.
For automotive exterior and vision systems, that matters far beyond radar performance alone.
Detection confidence affects blind-spot monitoring, cross-traffic alerts, automated braking support, smart lighting logic, and sensor fusion quality across the whole vehicle perception stack.
The central question is not whether mm-wave sensing works.
It is where mm-wave sensing still struggles in dense traffic, and how those gaps should shape system integration, validation, and exterior sensor architecture.
Why dense traffic changes the value judgment of mm-wave sensing
Open-road radar testing often highlights range, velocity estimation, and weather tolerance.
Dense traffic shifts the evaluation standard toward separation accuracy, target stability, and interpretation under clutter.
A vehicle is no longer tracking one lead car on a clean highway.
It must distinguish several cars, motorcycles, guardrails, roadside poles, wet surfaces, and pedestrians within overlapping motion paths.
This is where mm-wave sensing starts facing practical limits in angular resolution, multi-target discrimination, and scene understanding.
For AEVS-related platforms, this issue connects directly to exterior packaging, bumper materials, headlight-integrated perception, and cross-domain fusion with optical systems.
Urban intersections are where mm-wave sensing still struggles first
Intersections compress many risks into a short decision window.
Vehicles approach from multiple angles while bicycles, scooters, and pedestrians enter from edges with irregular speed profiles.
Object separation becomes unstable near crossing paths
At an intersection, mm-wave sensing may detect multiple reflections but still struggle to preserve clean target identity.
When objects move close together, radar returns can merge, split, or jump between tracks.
That can reduce confidence in path prediction and intervention timing.
Stationary clutter complicates threat prioritization
Signposts, barriers, parked cars, and reflective urban furniture create dense background echoes.
The challenge is not raw detection.
The challenge is deciding which reflection matters now.
Without strong fusion logic, mm-wave sensing can overemphasize clutter or underweight a crossing vulnerable road user.
Stop-and-go traffic exposes tracking drift and short-range ambiguity
Congested traffic seems simple because speeds are low.
In reality, low-speed density is one of the most demanding cases for mm-wave sensing.
Close spacing reduces clean target boundaries
When vehicles queue bumper to bumper, radar reflections overlap more easily.
The system may identify a lead vehicle well, yet struggle with adjacent lane intrusions or partially occluded motorcycles.
This matters for lane-change assistance and door opening warnings.
Micro-motions create false confidence
Dense queues involve creeping movement, wheel angle changes, and frequent partial occlusion.
A track may appear stable while the actual scene is changing rapidly at the edges.
That can delay detection of cut-ins, narrow-gap riders, or children emerging beside parked vehicles.
Multi-lane highways bring different mm-wave sensing limits
Highway traffic usually offers cleaner geometry, but dense multi-lane flow introduces its own radar stress points.
High relative speed increases association errors
When several vehicles overtake at different speeds, track association must remain precise frame by frame.
mm-wave sensing can estimate Doppler effectively, but target reassignment still becomes difficult during lane weaving and simultaneous overtakes.
Large vehicles create shadow zones
Trucks and buses block line of sight for cameras, yet they also distort the radar picture.
Reflections from trailers, underbody structures, and roadside barriers can hide smaller vehicles behind them.
That weakens confidence in blind-spot detection and rear cross-traffic coverage.
Parking structures and curbside scenes reveal a different weakness
Low-speed parking assistance relies heavily on reliable short-range perception.
This is another place where mm-wave sensing still struggles in dense traffic-like conditions.
Multipath reflections distort the scene
Concrete walls, metallic columns, ramps, and nearby vehicles create strong multipath returns.
The result can be ghost targets, unstable range estimates, or misplaced obstacle confidence.
Small and soft targets remain difficult
Shopping carts, low curbs, pets, and partially visible legs are not always easy radar targets.
If bumper packaging or fascia materials further attenuate signal quality, short-range reliability can degrade faster than expected.
Where scenario needs differ most for mm-wave sensing
Different traffic scenes do not demand the same radar strengths.
A useful evaluation compares failure modes, not just sensor specifications.
How to adapt exterior and vision systems when mm-wave sensing reaches its limits
The answer is not abandoning radar.
The answer is building around its scenario-specific weaknesses.
- Use camera fusion to improve classification where mm-wave sensing detects motion but cannot label intent well.
- Optimize bumper, grille, and emblem materials to reduce attenuation and thermal drift.
- Validate in dense mixed traffic, not only in clean proving-ground lanes.
- Tune short-range coverage for vulnerable road users near corners and door zones.
- Link smart headlight logic with fused perception confidence, not radar triggers alone.
For AEVS-related architectures, packaging and perception cannot be separated.
Exterior styling decisions directly influence mm-wave sensing performance through radome thickness, curvature, coatings, and contamination exposure.
Common misjudgments when evaluating mm-wave sensing in dense traffic
Several errors appear repeatedly during system reviews.
- Assuming long range automatically means strong urban performance.
- Treating detection count as proof of safe interpretation.
- Ignoring low-speed scenes because collision energy is lower.
- Overlooking bumper integration effects on mm-wave sensing quality.
- Expecting radar alone to resolve complex vulnerable road user behavior.
The strongest systems acknowledge where mm-wave sensing remains reliable and where fusion must take over.
What to do next when assessing mm-wave sensing performance
A practical next step is to map traffic scenarios against perception risks, not against marketing claims.
Review intersection clutter, queue compression, truck shadowing, curbside emergence, and parking multipath as separate validation cases.
Then connect those findings to exterior component choices, sensor placement, optical fusion strategy, and compliance-driven safety targets.
Where mm-wave sensing still struggles in dense traffic is exactly where future automotive exterior and vision systems can gain competitive value.
AEVS continues tracking that intersection of perception physics, vehicle exterior engineering, and real-world driving complexity.