
Industry Portal
Related News
- 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions - 00
0000-00
Private Label Tire Export: Evaluating Suppliers, Compliance, and Landed Cost - 00
0000-00
DOT-Compliant Truck Lighting: A Practical Guide to FMVSS 108 Requirements
Where mm-wave sensing outperforms camera-only detection
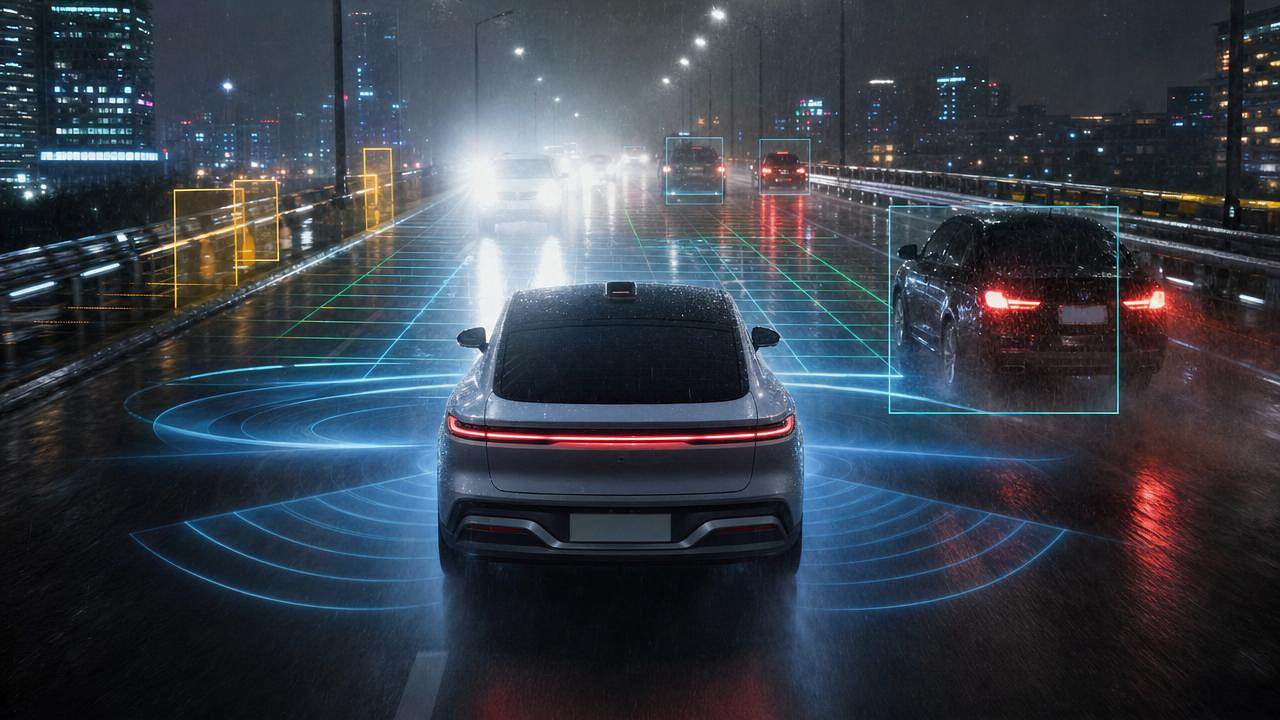
Where mm-wave sensing is becoming the stronger baseline
In advanced vehicle perception, mm-wave sensing is proving its value where camera-only detection reaches practical limits.
For exterior and vision programs, that shift matters because safety, comfort, and compliance now depend on stable sensing in imperfect environments.
Camera systems remain essential for classification, lane interpretation, and visual context.
Yet mm-wave sensing often delivers more dependable detection when visibility degrades, lighting becomes hostile, or motion must be measured instantly.
This matters across the wider automotive exterior ecosystem covered by AEVS.
Sensor performance influences headlight behavior, auto wiper response, blind-spot protection, and the confidence of intelligent body control features.
As electric vehicles become heavier, faster in torque response, and more software-defined, detection reliability has moved from a feature issue to a platform requirement.
The current signal: camera-only detection is hitting operational limits
The trend is not that cameras are obsolete.
The stronger trend is that camera-only detection struggles in edge cases that increasingly define real-world safety performance.
Urban traffic now includes reflective surfaces, LED glare, dense rain spray, mixed-speed micro-mobility, and complex roadside geometry.
Under these conditions, image quality can drop before the vehicle control stack can compensate.
mm-wave sensing is gaining traction because it is less dependent on visible light and less fragile under weather stress.
It can detect range, relative speed, and object movement even when a camera sees low-contrast shapes or partial obstruction.
That has direct value for blind-spot monitoring, rear cross-traffic alert, parking support, smart lighting triggers, and body sensor switching logic.
The practical environments where performance gaps become visible
- Heavy rain, fog, snow, and road spray reduce image contrast and blur object edges.
- Direct sunlight, low-angle dusk light, and headlamp glare can saturate camera sensors.
- Night driving limits passive visual detail for distant or dark-colored targets.
- Fast cut-ins require immediate relative speed estimation, not only object appearance.
- Dirty lenses, condensation, and exterior contamination can sharply reduce camera effectiveness.
Why mm-wave sensing outperforms camera-only detection in key scenarios
The advantage of mm-wave sensing is not aesthetic image understanding.
Its advantage is reliable physical measurement under uncertain viewing conditions.
Four technical reasons behind this shift
- mm-wave sensing measures distance and speed directly, reducing dependence on visual interpretation.
- Its performance remains more consistent across darkness, glare, and poor weather conditions.
- It supports robust motion tracking for adjacent lanes and cross-traffic movement.
- It improves system redundancy, which is increasingly important for safety validation.
Where the impact is spreading across exterior and vision systems
The rise of mm-wave sensing does not affect one subsystem alone.
It changes how multiple exterior functions are designed, integrated, and validated.
For smart headlight assemblies, more reliable environmental detection can improve adaptive beam timing and reduce false switching in difficult lighting.
For auto sensor switches, mm-wave sensing strengthens the logic behind blind-spot alerts, rear approach detection, and support triggers for body automation.
For vehicle exterior architecture, sensor placement now intersects with radome materials, bumper styling, thermal exposure, contamination control, and aerodynamic packaging.
That is especially relevant for NEV platforms, where sleek surfaces and low-drag forms can unintentionally compromise sensor performance.
A poorly integrated camera may lose clarity.
A poorly integrated radar may suffer attenuation, multipath reflection, or blocked field coverage.
The strategic conclusion is clear: sensing performance must be designed with the exterior, not added after styling freezes.
Business and development effects now becoming more visible
- Validation programs are expanding beyond daytime image benchmarks.
- Exterior materials must support radar transparency and stable environmental durability.
- System cost discussions are shifting from component price to failure-risk reduction.
- Compliance pressure is rising as safety expectations move toward all-weather consistency.
What deserves closer attention when evaluating mm-wave sensing
Not every mm-wave sensing implementation creates the same value.
Performance depends on design discipline, calibration, and scenario definition.
- Detection range versus field of view for target use cases
- Relative speed accuracy in dense urban traffic
- False alarm control near guardrails, curbs, and metallic structures
- Radome material compatibility with bumper and fascia design
- Performance stability after dirt exposure, vibration, and thermal cycling
- Fusion logic with cameras, lighting controls, and body electronics
These points matter because mm-wave sensing should not be treated as a simple sensor addition.
It is part of a vehicle perception architecture that must fit exterior packaging, software behavior, and long-term reliability goals.
A practical judgment framework for next-phase programs
A useful decision path is to compare camera-only detection against real operating conditions, not ideal test footage.
The next move: build around dependable detection, not ideal visibility
The strongest market direction is not cameras versus radar.
It is the move toward perception stacks that remain trustworthy when weather, light, and road conditions become messy.
That is exactly where mm-wave sensing outperforms camera-only detection.
For automotive exterior and vision strategies, the practical response is to audit edge-case failures, review sensor placement early, and validate all-weather behavior before styling and electronics are locked.
In that process, mm-wave sensing should be assessed as a performance enabler for safer, more resilient intelligent exteriors.
Programs that act on this now will be better positioned for robust sensing, stronger user trust, and more durable compliance readiness.