
Industry Portal
Related News
- 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions
When mm-Wave Sensing Misses Low-Speed Objects
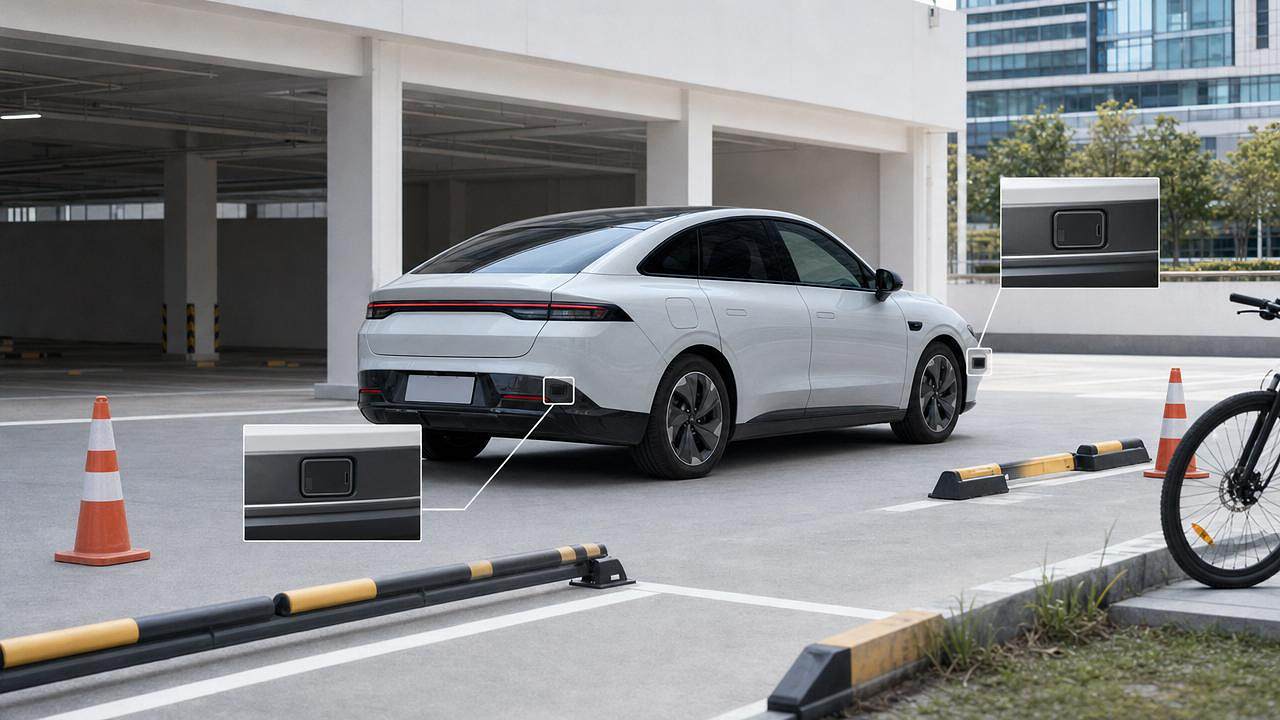
When mm-wave sensing misses low-speed objects, the issue is rarely just a sensor fault—it often reflects deeper trade-offs in signal processing, detection thresholds, environmental filtering, and system integration. For technical evaluators in automotive exterior and vision systems, understanding these blind spots is essential to assessing real-world safety performance, validation robustness, and the limits of perception strategies in increasingly complex NEV scenarios.
In parking lots, urban curbside maneuvers, automatic wiper logic, blind-spot monitoring, and low-speed cross-traffic alerts, missing a pedestrian, cone, bicycle wheel, or low-profile barrier at 0–10 km/h can create a disproportionate safety and liability risk. For AEVS readers and technical assessment teams, the real question is not whether mm-wave sensing is valuable, but where its low-speed perception envelope narrows and how that narrowing should be measured, compared, and mitigated.
This matters even more in New Energy Vehicle platforms, where exterior design, lightweight body structures, wheel aerodynamics, sensor packaging, and smart lighting functions increasingly interact. A radar unit mounted behind a fascia, beside a headlamp, or near wheel-arch geometry does not operate in isolation. Its performance is shaped by bumper material, installation angle, ride height variation, vibration, thermal load, and the software rules that decide what counts as a meaningful target.
Why Low-Speed Detection Is a Persistent mm-Wave Sensing Challenge
At a high level, mm-wave sensing works by estimating range, velocity, and angle from reflected radio signals, commonly in the 24 GHz or 77–81 GHz bands. In automotive applications, the technology is highly effective for medium- and high-speed targets, but low-speed objects often fall into a difficult zone where motion signatures become weak, clutter suppression becomes aggressive, and classification confidence can drop below system thresholds.
Low Doppler Return Is Not the Same as No Risk
Many radar pipelines prioritize Doppler separation because moving objects are easier to distinguish from static surroundings. When an object moves slowly, such as a pedestrian stepping at 1–2 m/s or a bicycle rolling across a reversing vehicle path, its Doppler shift may be close to that of environmental clutter. If the filtering logic is tuned to suppress false positives from guardrails, drains, parked vehicles, or road furniture, the same logic may also suppress valid low-speed hazards.
Typical Trade-Offs Seen in Evaluation
- Higher clutter rejection reduces nuisance alarms but can reduce sensitivity to objects below 5 km/h relative motion.
- Shorter integration windows improve responsiveness, yet may weaken detection stability for small or partially occluded targets.
- Tighter tracking confirmation rules improve robustness, but may require 2–5 frames before an alert is issued.
- Static-object suppression helps highway use cases, while low-speed urban maneuvers often need stronger static awareness.
Object Geometry and Radar Cross Section Matter
Not all low-speed objects look equally visible to radar. A metal shopping cart, tire stack, or vehicle corner reflector may be easy to detect. A child’s scooter wheel, slim plastic bollard, road cone, or wet bicycle frame may produce a far smaller and more unstable radar cross section. Even at the same 3–8 meter distance, target material, orientation, and shape can shift the probability of detection in a meaningful way.
Technical evaluators should therefore avoid generic pass/fail language. A system that performs well on adult pedestrian dummies at 10 meters may still struggle with low-profile roadside objects or partially hidden obstacles near bumper level. For exterior and vision system integration teams, this becomes a packaging and validation issue as much as a sensing issue.
The table below summarizes the most common reasons mm-wave sensing underperforms in low-speed target scenarios and what evaluators should inspect during bench and vehicle-level reviews.
The key takeaway is that low-speed misses often emerge from layered compromises rather than one defective component. A technically sound evaluation process must examine sensing physics, software thresholds, and vehicle integration together, especially when the radar supports exterior safety functions linked to lighting, blind-spot alerts, or body-domain automation.
How Vehicle Exterior Integration Influences mm-Wave Sensing Performance
For automotive exterior and vision systems, mm-wave sensing quality is closely tied to where and how the radar is installed. In modern NEV platforms, design pressure is intense: slimmer fascias, sculpted wheel arches, larger alloy wheel designs, active grille features, and dense lighting modules all compete for space. A sensor that looks acceptable on a lab fixture can degrade after being packaged behind painted plastic, near metallic brackets, or adjacent to heated optical assemblies.
Bumper Materials, Paint Stacks, and Surface Geometry
A front or rear radar typically sits behind a polymer fascia, but thickness variation, metallic paint content, decorative films, and local curvature can change transmission loss and angular behavior. Even a 1–3 dB insertion loss may reduce margin enough to matter when the target is small, slow, and off-axis. For systems expected to detect low-speed objects in ±60° lateral zones, local bumper shape should be validated across production tolerances, not only nominal CAD intent.
Ride Height, Wheel/Tire Changes, and Splash Contamination
AEVS tracks the interaction between wheels, tires, and perception because these domains increasingly overlap. Different wheel offsets, tire shoulder shapes, and suspension load states can alter splash patterns and local contamination. In winter slush or heavy rain, radar covers may accumulate films that do not fully block the signal but do destabilize weak returns. Low-speed objects at 2–6 meters are particularly vulnerable because the signal-to-noise margin is already limited.
Integration Checks Worth Adding to DV/PV Plans
- Measure radar performance with at least 3 fascia variants: nominal, paint-thick, and thermal-aged.
- Run contamination tests under dry dust, road salt film, and water spray conditions.
- Validate with wheel and tire packages that represent both base and optional trim levels.
- Repeat object detection at curb approach angles of 15°, 30°, and 45°.
- Compare hot-soak and cold-start behavior over a temperature band such as -20°C to 60°C.
The next table provides a practical integration-oriented checklist for technical evaluators reviewing mm-wave sensing in exterior-heavy NEV designs.
For procurement and engineering decision-makers, this means radar sourcing cannot be separated from exterior-system sourcing logic. Sensor choice, fascia specification, lighting layout, and even wheel/tire package planning should be aligned early, ideally before design freeze, because late-stage fixes often increase both validation time and tooling cost.
What Technical Evaluators Should Measure Instead of Relying on Datasheet Claims
Many mm-wave sensing datasheets highlight nominal range, field of view, and object count capacity, but these figures rarely describe low-speed perception quality in cluttered real-world environments. A stated 120 m range or ±75° field of view says little about whether a sensor can reliably detect a low-curb obstacle at 4 meters while the vehicle reverses at 3 km/h in rain.
Build a Use-Case-Based Evaluation Matrix
A more reliable approach is to define 4–6 scenario groups and score them separately. Typical groups include parking assist, rear cross-traffic alert, blind-spot monitoring at low urban speeds, close-range obstacle detection, and body-function triggering such as smart headlamp or sensor switch logic. Each group should include at least 3 target types, 3 environmental conditions, and 2 relative speed bands.
Core Metrics to Include
- Probability of detection at 2 m, 5 m, and 10 m
- False alarm rate per minute in dense urban clutter
- Time-to-alert or tracking confirmation delay in milliseconds
- Performance stability after contamination or thermal soak
- Object persistence under partial occlusion by parked vehicles or body structures
- Mode-switching behavior between static and moving target logic
Separate Algorithm Limits from Hardware Limits
A frequent evaluation mistake is to blame hardware for what is actually software tuning. If low-speed misses disappear after reducing clutter suppression or adjusting confirmation thresholds, the issue may not be antenna sensitivity at all. On the other hand, if weak returns remain unstable across multiple tuning sets, hardware packaging, cover loss, or angle resolution may be the limiting factor.
For technical teams, the best practice is to request three levels of evidence from suppliers: raw or semi-processed target data, perception output before fusion, and final function-level behavior. This layered view makes it easier to pinpoint whether the miss occurs in signal acquisition, point-cloud generation, tracking, classification, or downstream decision logic.
Do Not Ignore Service and Recalibration Burden
Low-speed performance also affects aftermarket cost. If a radar requires frequent recalibration after bumper replacement, wheel alignment work, or minor collision repair, the system may meet launch targets but still create ownership friction. In practical sourcing reviews, evaluators should ask how many service steps are needed after replacement, whether static calibration is sufficient, and how long the typical workshop procedure takes—30 minutes, 90 minutes, or more.
Risk Reduction Strategies for NEV Exterior and Vision Programs
No single sensor solves every low-speed object problem. The most resilient strategy is to reduce exposure through coordinated system design, targeted validation, and realistic functional boundaries. This is especially relevant for NEVs, where silent operation raises pedestrian risk, and premium exterior styling can constrain ideal sensor placement.
Combine Sensor Modalities Where the Use Case Demands It
If the vehicle function must detect low, slow, and partially static objects at very short range, mm-wave sensing may need camera, ultrasonic, or optical support. Radar remains strong in rain, fog, and poor lighting, but low-speed edge cases often improve when another modality contributes shape or texture cues. The right fusion architecture depends on use case priority, BOM limits, packaging constraints, and target market regulations.
Align Exterior Design Reviews with Perception Reviews
A practical governance step is to treat radar-related exterior components as perception-critical parts, not cosmetic-only parts. Fascia design changes, wheel arch revisions, decorative trims, headlamp housing shifts, and sensor switch relocations should trigger a defined review gate. Even a minor surface or bracket change made 8–12 weeks before SOP can introduce enough variation to affect low-speed detection consistency.
A Four-Point Program Checklist
- Freeze low-speed object scenarios before finalizing radar placement.
- Validate with production-intent fascia, paint, brackets, and wheel/tire combinations.
- Score system behavior under contamination, low light, and urban clutter separately.
- Define service recalibration rules before aftermarket rollout.
Use Supplier Reviews to Expose Hidden Assumptions
During sourcing or technical review, ask suppliers what object classes were excluded from their internal validation, what minimum relative speed improves confidence, and how the algorithm distinguishes clutter from genuine low-speed hazards. These questions often reveal whether the quoted performance was optimized for open-road ADAS marketing or for real close-range exterior safety functions.
For AEVS-oriented decision-making, the winning solution is usually not the one with the longest headline range. It is the one with the clearest validated envelope, the most transparent integration requirements, and the most controllable service burden across the vehicle life cycle.
Practical Questions Buyers and Evaluators Should Ask
FAQ for Technical Assessment and Sourcing Teams
Can a stronger radar completely eliminate low-speed misses?
Not necessarily. Better hardware can improve margin, but misses may still come from filtering rules, tracking thresholds, or installation constraints. Evaluators should confirm end-to-end performance, not only sensor sensitivity.
Are low-speed misses mainly a parking-assist problem?
No. They also affect blind-spot transitions, rear cross-traffic alerts, body-domain automation, and smart exterior perception functions. In dense urban use, the operational impact can extend well beyond parking maneuvers.
What is the minimum validation depth a buyer should request?
At minimum, request scenario-based detection results across 3 distances, multiple target types, and at least dry, wet, and cluttered conditions. A single clean-track demo is not enough for reliable technical comparison.
Why should exterior teams care if software can be updated later?
Because packaging losses, fascia attenuation, and contamination patterns cannot be fully corrected by software. Once hardware and exterior geometry are frozen, the room for improvement narrows sharply.
For technical evaluators working across automotive exterior, wheels and tires, lighting, and smart sensing domains, low-speed object misses in mm-wave sensing should be treated as a systems engineering issue with direct implications for safety, validation cost, and customer trust. The most dependable programs test beyond nominal range claims, validate under realistic exterior integration conditions, and define clear limits for the sensor’s low-speed operating envelope.
AEVS supports this kind of decision-making by connecting perception performance with exterior architecture, packaging trade-offs, and market-facing implementation needs. If you are comparing sensor strategies, reviewing NEV exterior integration risks, or refining a validation plan for low-speed detection, contact us to get a tailored technical perspective, explore solution paths, and learn more about practical exterior and vision system intelligence.