
Industry Portal
Related News
- 00
0000-00
Which ISO Standards Govern Vehicle Lightweighting Materials and Validation Testing? - 00
0000-00
Wheel Lightweighting in Europe: How EV Regulations Are Reshaping Wheel Sourcing - 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials
What mm-wave sensing can detect that cameras may miss
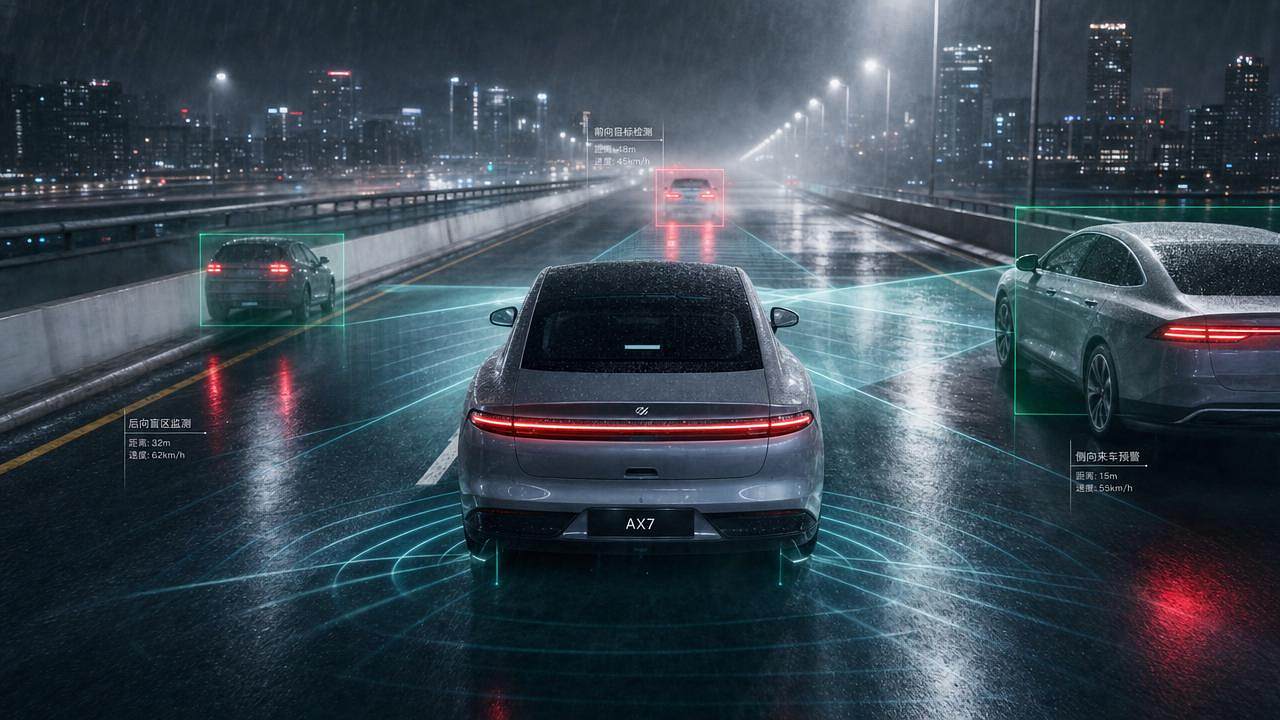
In real-world driving, cameras do not always capture everything that matters. Rain, fog, glare, darkness, and blocked sightlines can all limit visual systems at critical moments. This is where mm-wave sensing stands out, detecting motion, distance, and object presence with strong reliability even when visibility drops. For safer and smarter vehicle perception, knowing what mm-wave sensing can detect that cameras may miss is now essential across modern mobility systems.
What is mm-wave sensing, and why does it matter beyond cameras?
mm-wave sensing uses high-frequency radio waves to measure distance, speed, angle, and motion. It does not depend on visible light in the same way camera systems do.
That difference matters in automotive exterior and vision systems. Cameras provide rich image detail, but mm-wave sensing delivers stable detection when visual contrast is weak.
In practical terms, mm-wave sensing can track an approaching vehicle through spray, identify movement behind a bumper cover, and estimate closing speed during nighttime driving.
For platforms focused on LED headlight intelligence, sensor switches, tires, and dynamic driving perception, this sensing layer strengthens safety decisions when optics alone become uncertain.
It also supports a broader industry shift. New Energy Vehicles need reliable perception for dense traffic, quiet cabins, and aerodynamic designs that can reduce direct lines of sight.
Why cameras still remain important
Cameras recognize lane markings, signs, colors, and surface texture. They are excellent for semantic understanding. mm-wave sensing is different, because it excels at physical detection and motion measurement.
The strongest systems combine both. Cameras explain what an object looks like. mm-wave sensing confirms where it is, how fast it moves, and whether it remains trackable.
What can mm-wave sensing detect that cameras may miss in poor visibility?
This is the core reason mm-wave sensing has become valuable. It can continue detecting objects when visibility conditions weaken image-based perception.
- Vehicles hidden by heavy rain spray
- Objects partially obscured by fog or mist
- Moving targets in darkness beyond headlight image quality
- Approaching traffic affected by sun glare
- Targets behind plastic bumper covers
- Cross-traffic emerging from blocked side views
A camera may see a bright blur in fog. mm-wave sensing can still estimate distance and relative speed. That extra confidence improves braking, warning logic, and adaptive response timing.
Glare is another major example. Low sun, wet roads, and headlight reflections can wash out image detail. mm-wave sensing remains far less affected by those visual disruptions.
On highways, this matters for blind-spot monitoring and rear approach alerts. In urban traffic, it matters for side detection, merging, and stop-and-go movement prediction.
Hidden motion is especially important
mm-wave sensing is strong at detecting motion signatures. A partly blocked object may not look clear on camera, yet its movement can still be measured reliably.
That ability is useful when parked vehicles, exterior pillars, weather, or road curvature reduce visual certainty.
Which automotive scenarios benefit most from mm-wave sensing?
The value of mm-wave sensing becomes clearer when matched to real operating scenarios rather than viewed as a standalone specification.
1. Blind-spot and lane-change monitoring
Vehicles can approach quickly from rear side zones. Cameras may lose performance in rain, darkness, or dirty lens conditions. mm-wave sensing keeps tracking speed and position changes.
2. Rear cross-traffic alerts
When reversing from tight parking spaces, body panels and neighboring vehicles block direct views. mm-wave sensing can detect lateral motion before full visual exposure occurs.
3. Adaptive front sensing
For highway driving, mm-wave sensing supports gap measurement and relative speed tracking. It performs well when LED headlights illuminate the road but image contrast remains poor.
4. Intelligent exterior automation
Auto sensor switches can use mm-wave sensing for presence detection and motion-triggered functions. This can improve activation logic for perimeter awareness and body-network responses.
5. NEV design constraints
Many NEVs emphasize low drag, enclosed forms, and compact sensor integration. mm-wave sensing fits these trends because it can work behind non-metallic exterior surfaces.
How does mm-wave sensing compare with cameras in detection quality?
The comparison should not be framed as winner versus loser. It should focus on detection tasks. Each technology sees different parts of reality.
Where cameras lead
- Reading signs and signals
- Lane marking interpretation
- Color and shape recognition
- Road surface appearance
Where mm-wave sensing leads
- Stable detection in darkness
- Relative speed measurement
- Operation through fog, rain, and spray
- Tracking hidden or partly blocked motion
For exterior perception systems, the most effective architecture often fuses optics and radar-grade sensing. This reduces single-sensor failure modes and improves decision confidence.
That is highly relevant to AEVS themes. Smart headlights, exterior packaging, and sensor switch strategies all benefit when perception layers complement each other instead of competing.
What common mistakes appear when evaluating mm-wave sensing?
One common mistake is expecting mm-wave sensing to replace cameras completely. It does not provide rich visual context, so it cannot substitute for every image-based function.
Another mistake is assuming all mm-wave sensing systems perform equally. Detection range, angular resolution, processing quality, mounting position, and software tuning all change real outcomes.
A third mistake is ignoring exterior material integration. Bumper composition, sensor placement, thermal exposure, and contamination management can all affect signal quality.
There is also a cost misunderstanding. The right question is not only component price. It is total performance value under real traffic, weather, and compliance conditions.
Quick evaluation checklist
- Check performance in rain, fog, and night scenarios
- Review false alert behavior in dense traffic
- Verify integration behind exterior panels
- Assess compatibility with camera fusion logic
- Consider global standards and validation cycles
How should decision-makers judge when mm-wave sensing is worth adopting?
Start with the driving risks that cameras struggle with most. If a system must work through darkness, weather, or blocked views, mm-wave sensing deserves serious consideration.
Next, examine use-case priority. Blind-spot alerts, rear cross-traffic, adaptive sensing, and smart body-network triggers usually gain clear value from mm-wave sensing.
Then evaluate packaging and system goals. Low-drag exteriors, premium safety features, and intelligent lighting ecosystems often benefit from sensor fusion rather than camera-only design.
Finally, test performance by scenario, not brochure claims. Road spray, tunnel exits, reflective surfaces, and mixed traffic reveal the real strength of mm-wave sensing.
What mm-wave sensing can detect that cameras may miss is not a narrow technical question. It is a practical safety and system-design issue for modern mobility.
When visibility falls, cameras may lose certainty. mm-wave sensing can still detect distance, motion, presence, and closing speed with dependable consistency.
That makes it highly relevant for blind-spot functions, rear cross-traffic, adaptive sensing, and intelligent exterior systems shaped by aerodynamic and NEV demands.
The smartest next step is to evaluate mm-wave sensing by scenario, integration quality, and fusion potential. In advanced vehicle perception, resilience matters as much as resolution.