
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
What mm-Wave Sensing Can Detect in Vehicles and Where It Still Falls Short
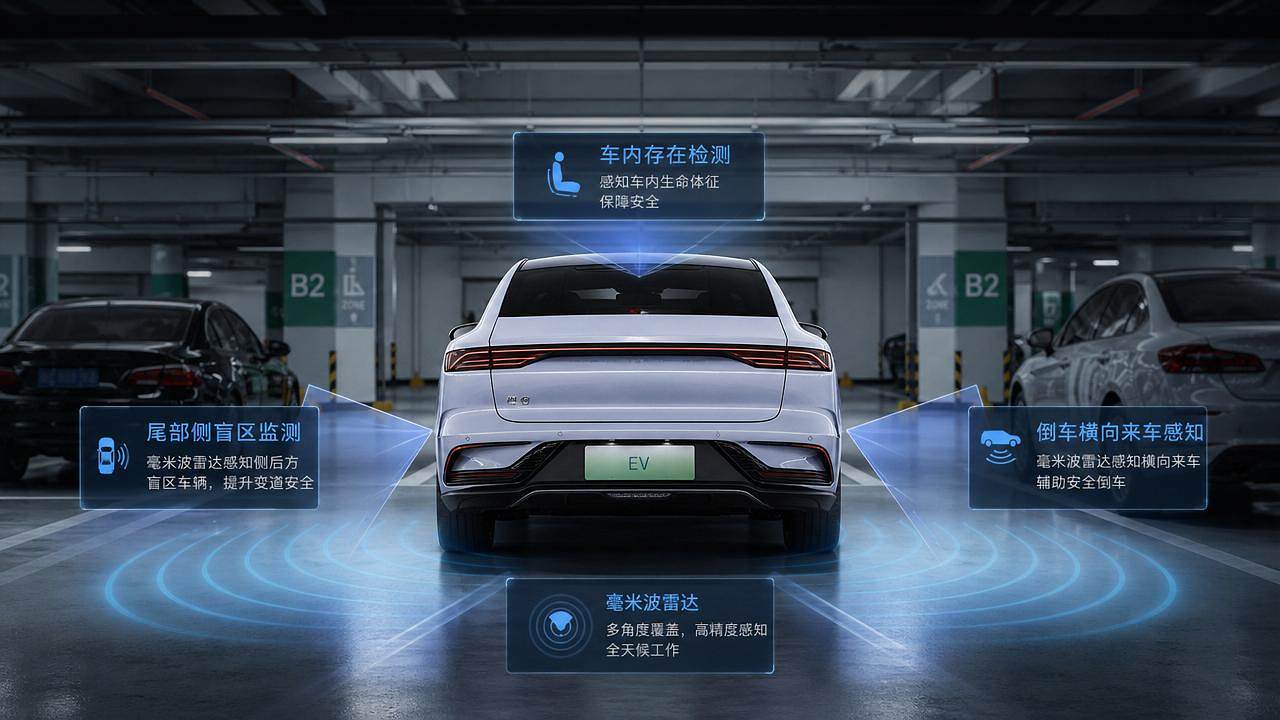
What does mm-wave sensing really do inside a vehicle?
mm-wave sensing uses high-frequency radio waves to detect movement, distance, speed, and presence around or inside a vehicle.
In simple terms, it helps a vehicle notice what cameras may miss and what ultrasonic sensors may detect too late.
That matters more now because modern vehicles carry layered perception systems for safety, automation, comfort, and energy efficiency.
In the AEVS view of exterior intelligence, sensing is not isolated hardware. It affects lighting logic, body control, blind-spot awareness, and driving confidence.
For example, auto sensor switches can use mm-wave sensing with photoelectric inputs to trigger wipers, activate headlight strategies, or support near-body awareness.
The key attraction is reliability in poor visibility. Radar-based sensing can still work when glare, darkness, spray, or light fog disturb optical systems.
Still, the technology is not magic. Detection quality depends on placement, target material, field of view, signal processing, and how well it is fused with other sensors.
So what can mm-wave sensing detect well, and where does it add the most value?
This is where real-world use becomes more specific. mm-wave sensing performs best when the task involves motion, range, relative speed, or hidden approach paths.
In vehicles, the strongest use cases usually include:
- Blind-spot monitoring for vehicles approaching from rear side zones.
- Rear cross-traffic alerts when reversing out of tight parking spaces.
- Occupancy or presence detection inside the cabin.
- Near-field obstacle detection during low-speed maneuvers.
- Motion tracking for door, trunk, or body-zone automation.
It is especially useful for NEVs, where silent operation makes situational awareness even more important in crowded urban environments.
mm-wave sensing also supports design goals beyond safety. Better sensing can reduce unnecessary system activation and improve the coordination of exterior lighting and body functions.
That fits well with AEVS coverage, where vehicle aesthetics, aerodynamic design, and smart perception increasingly influence each other instead of evolving separately.
A quick judgment table for common automotive detection tasks
A practical way to assess mm-wave sensing is to ask what it detects confidently, what it estimates, and what still needs sensor fusion.
Why does mm-wave sensing still miss things people assume it should detect?
This is one of the most common misunderstandings. People often hear “radar” and assume every object becomes easy to detect.
In practice, mm-wave sensing is better at measuring motion and range than describing shape, color, or exact object identity.
A plastic pole, a low curb, wet road spray, and a moving bicycle do not reflect signals in the same way.
Some targets are small, oddly angled, or weakly reflective. Others are partly hidden by body panels, wheel arches, or packed cargo.
Installation also changes outcomes. A sensor behind a bumper cover may work well in one design, then lose accuracy after material or thickness changes.
This matters for exterior systems because lightweight materials, wheel airflow management, and body styling can all influence signal paths.
That is why platforms like AEVS pay attention to exterior architecture, not just sensor specifications in isolation.
Another limit is interpretation. mm-wave sensing can say that something is there and moving, but not always what that thing is or why it matters.
When the task demands finer judgment, camera, ultrasonic, or optical sensing usually fills the gap.
Is mm-wave sensing better than cameras, ultrasonic, or lidar?
Not in every case. The better question is which sensing problem needs to be solved.
If the need is object appearance, lane markings, color contrast, or traffic sign reading, cameras remain essential.
If the need is very close-range parking support, ultrasonic still plays an important role because it is simple and cost-effective.
If the need is accurate depth mapping in advanced automation, lidar may offer better spatial detail, though at different cost and integration demands.
mm-wave sensing stands out in a narrower but very valuable zone:
- It handles darkness and glare better than cameras.
- It tracks relative velocity well.
- It performs reliably in many weather conditions.
- It supports compact integration behind vehicle surfaces.
So the real advantage is not replacement. It is complementarity.
A well-designed sensing stack uses mm-wave sensing where speed and presence matter, then lets optical systems refine interpretation.
What should be checked before relying on mm-wave sensing in a vehicle program?
This is where many good concepts become difficult launches. The technical headline may look strong, but deployment details decide performance.
A practical evaluation usually includes the following checks:
- Sensor location versus bumper, grille, lamp housing, and body curvature.
- Material transparency to radar signals after paint, coatings, and decorative finishes.
- Required field of view for parking, blind-spot, cabin, or side-zone coverage.
- Algorithm tuning for local traffic density, speed profiles, and false alert tolerance.
- Compliance alignment with regional safety expectations and validation processes.
For NEVs, another layer is energy and thermal management. Added sensing should support safety without creating unnecessary power draw or packaging conflicts.
This is one reason integrated intelligence matters. Exterior lighting, wheel aerodynamics, body electronics, and sensing often share space, heat, and design priorities.
The most useful early question is not “Does the sensor work?”
It is “Does it still work after styling, materials, weather exposure, and production variation are included?”
A short checklist for realistic evaluation
Where is mm-wave sensing heading next, and what is still worth watching?
The next phase is less about adding sensors everywhere and more about making each sensing layer more context-aware.
That means better cabin monitoring, smarter side detection, cleaner fusion with matrix lighting, and tighter coordination with body-domain control.
For AEVS-related vehicle systems, this trend is important because exterior intelligence is becoming a linked design problem.
A headlamp assembly, a bumper skin, an auto sensor switch, and a wheel-side airflow solution can all influence how perception performs in daily use.
The technical limit that still matters most is not raw detection distance. It is dependable interpretation under imperfect conditions.
So if the goal is to understand mm-wave sensing clearly, the balanced answer is this:
It is excellent for detecting motion, presence, and relative position in many automotive scenarios.
It still falls short when precise classification, tiny static object confidence, or poorly integrated installation conditions enter the picture.
A sensible next step is to map the sensing task first, then compare placement, material effects, fusion needs, and validation standards before drawing conclusions.
That approach gives a more realistic view of what mm-wave sensing can detect in vehicles, and where caution is still justified.