
Industry Portal
Related News
- 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions - 00
0000-00
Private Label Tire Export: Evaluating Suppliers, Compliance, and Landed Cost - 00
0000-00
DOT-Compliant Truck Lighting: A Practical Guide to FMVSS 108 Requirements
Mm-wave sensing or cameras, which fails less in rain?
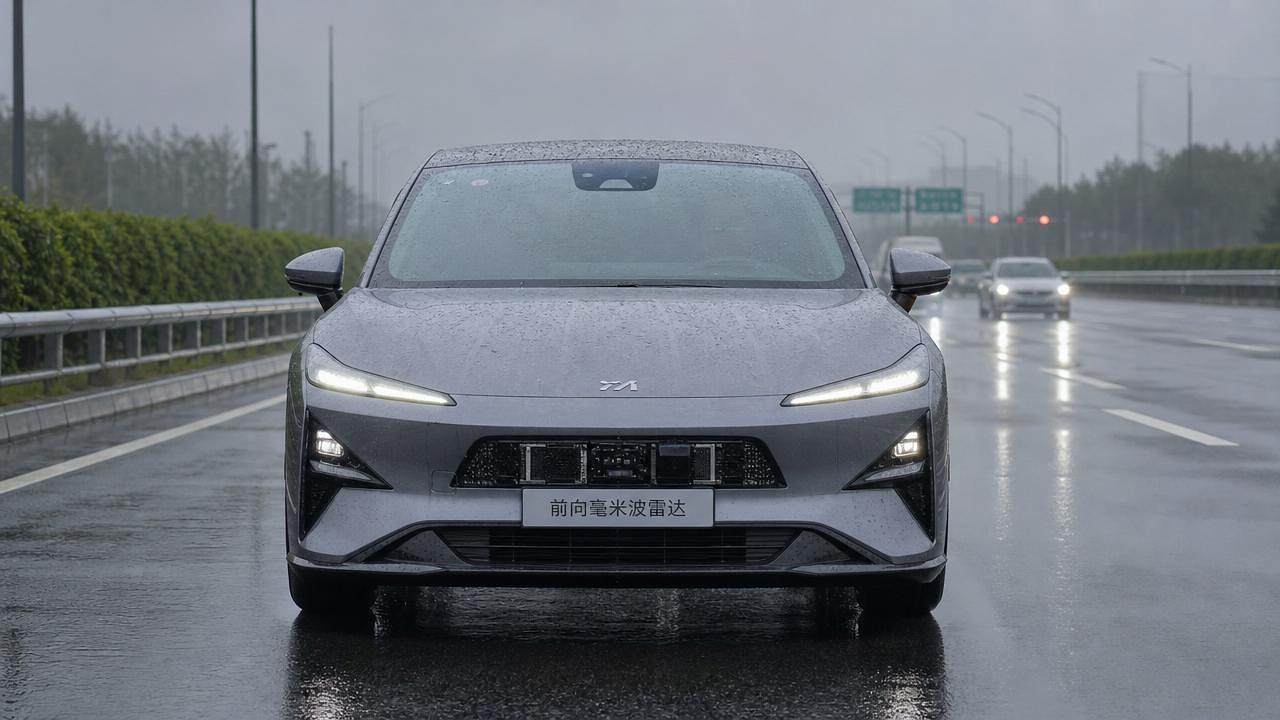
When rain blurs lenses and weakens visibility, the comparison between cameras and mm-wave sensing becomes practical, not theoretical. In wet conditions, detection stability affects braking confidence, driver assistance quality, and overall exterior intelligence performance.
This guide explains which technology fails less in rain, where each sensor struggles, and how to evaluate reliability using a structured checklist. The answer is rarely absolute, but the risk profile is clear.
Why a Checklist Matters for Rain Performance
Rain does not create one single failure mode. It changes visibility, surface reflectivity, spray density, road contrast, and signal noise at the same time.
That is why a checklist-based review works better than simple claims like “radar sees through rain” or “cameras are enough.” For automotive exterior systems, reliability depends on sensor physics, mounting position, software filtering, and cleaning strategy.
In most cases, mm-wave sensing fails less often than cameras in moderate to heavy rain for object presence and distance detection. Cameras, however, still outperform radar for lane interpretation, sign reading, and shape-rich visual context when visibility remains acceptable.
Core Checklist: How to Judge Cameras vs mm-wave sensing in Rain
Use the following points to compare real wet-weather robustness instead of relying on headline specifications.
- Check attenuation tolerance first. Measure how heavy rain reduces detection range, then compare whether camera confidence drops faster than mm-wave sensing target tracking.
- Inspect contamination exposure. Review whether lens surfaces collect droplets, mud, or road film more easily than a protected radar cover integrated into the exterior fascia.
- Verify object priority. Decide whether the system must identify lane edges and traffic signs, or simply maintain reliable ranging and obstacle awareness in spray.
- Test low-contrast scenes. Compare performance when dark vehicles, wet asphalt, tunnel exits, and reflective puddles reduce camera contrast and raise image ambiguity.
- Review false positive filtering. Confirm whether mm-wave sensing software can suppress clutter from guardrails, splash zones, and metallic roadside structures.
- Evaluate mounting geometry. Check whether the camera sits behind glass with wiper coverage, and whether the radar faces minimal blockage from badges or thick coatings.
- Assess cleaning and heating. Confirm lens defogging, washer logic, hydrophobic treatment, and radar cover ice control before judging all-weather reliability claims.
- Measure latency under load. Compare how quickly each sensor recovers after splash events, especially during overtaking, cut-ins, and emergency braking scenarios.
- Check fusion fallback logic. Determine whether the vehicle degrades gracefully when cameras lose confidence but mm-wave sensing still provides stable range data.
- Validate by road class. Repeat tests on highways, urban streets, and rural roads because rain behavior changes with speed, lighting, and roadside clutter.
What Actually Fails in Rain
Camera failure patterns
Cameras depend on clean optical input. Rainfall alone is a problem, but droplets on the lens or windshield are often worse. A single smear can distort lane lines, vehicle edges, and object classification.
Night rain adds another layer of difficulty. Headlight glare, reflections from wet pavement, and reduced contrast can lower confidence sharply. In these moments, visual perception may still function, but with more uncertainty and slower decision quality.
mm-wave sensing failure patterns
Mm-wave sensing is generally more tolerant of rain, fog, and splash because radio waves are less dependent on visible light. It usually keeps tracking distance and relative speed after cameras become unreliable.
Still, radar is not immune. Heavy precipitation can reduce range. Dense spray can introduce noise. Stationary object interpretation may be filtered too aggressively. Radar also lacks the visual richness needed for lane semantics and sign recognition.
Scenario-Based Comparison
Highway in heavy rain
On highways, mm-wave sensing usually fails less for forward object tracking. Relative speed estimation remains useful even when spray from trucks weakens camera clarity.
Cameras remain important for lane centering, but lane markings can disappear under standing water or glare. In this setting, radar gives more dependable core awareness, while cameras become the more fragile layer.
Urban traffic with reflections
Cities create a mixed result. Cameras can still read scene details if lens cleanliness is maintained. They handle pedestrians, markings, and signs better than radar.
However, wet roads, glass façades, parked vehicles, and narrow angles increase complexity. Mm-wave sensing remains stable for motion tracking, but clutter filtering becomes critical to prevent noisy detections.
Low-speed parking and exterior automation
For parking, cameras support precise close-range visualization. Yet rain droplets can make curb edges and obstacles appear distorted. This directly affects user trust in surround-view systems.
Radar-based sensing helps maintain presence detection through spray and darkness, but resolution limits remain. For tight maneuvers, fused systems generally outperform either sensor alone.
Commonly Overlooked Risk Factors
Sensor cover materials: Exterior styling decisions can weaken performance. Thick paint, metallic finishes, or decorative badges may impair radar transmission or create unwanted reflections.
Washer and wiper logic: A high-spec camera still degrades quickly if the cleaning system reacts too slowly. Recovery time after splash exposure matters as much as baseline image quality.
Thermal management: Condensation, icing, and fogging are rain-adjacent risks. Heated lenses and controlled sensor temperatures often decide whether a system stays stable after weather shifts.
Algorithm tuning: Mm-wave sensing hardware may be capable, but poor filtering can create hesitation around bridges, barriers, or roadside metal objects in wet conditions.
Overreliance on single-sensor claims: Any system marketed as all-weather should be reviewed for degraded-mode behavior, not just peak-condition demos.
Practical Execution Recommendations
- Prioritize mm-wave sensing for distance-critical functions such as adaptive cruise, forward collision support, and blind-spot awareness in frequent rain regions.
- Retain cameras for classification-heavy tasks including lane interpretation, traffic sign reading, and close-range visual confirmation during parking and urban assistance.
- Specify fusion logic that shifts weighting dynamically when rain lowers camera confidence but radar data remains stable and trackable.
- Demand validation with real spray, dirty water, tunnel transitions, nighttime glare, and repeated splash recovery instead of light-rain laboratory claims.
- Review exterior integration early, because sensor reliability depends on fascia materials, cleaning paths, heating design, and aerodynamic contamination control.
Conclusion and Next-Step Guidance
If the question is simply which fails less in rain, mm-wave sensing is usually the safer answer for maintaining core object detection and ranging. Cameras are more vulnerable to blur, glare, blockage, and contrast loss.
But the best decision is not radar instead of vision. It is understanding where each sensor breaks first, then building an exterior perception stack that degrades predictably and safely.
Use the checklist above to compare wet-weather performance by function, environment, and integration quality. In smart mobility systems, resilient perception comes from disciplined validation, not from choosing a single technology label.