
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
MM-Wave Sensing vs Camera Sensors: Which Is Better for Blind Spot Detection?
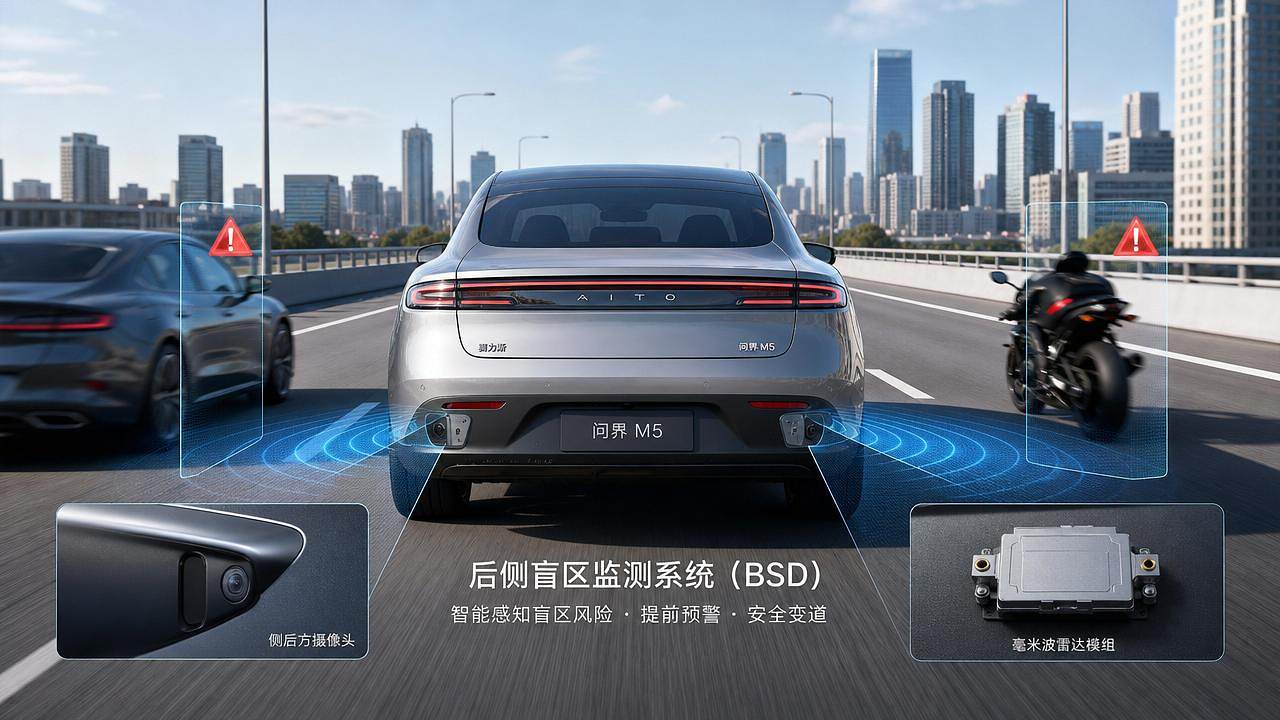
Blind spot detection has moved from a premium feature to a core safety layer, especially in NEV platforms where higher body sides, thicker pillars, and quieter cabins change how risk is perceived. In that context, the comparison between mm-wave sensing and camera sensors is not only technical. It also shapes warning consistency, system cost, packaging freedom, and the broader exterior perception strategy surrounding mirrors, lighting, and body-mounted sensor switches.
Why this comparison matters now
Blind spot monitoring used to be evaluated as a single function. Now it is part of a larger perception stack tied to lane change assist, rear cross traffic alert, auto lighting logic, and exterior electronics integration.
That shift matters because the sensor decision made for blind spot detection can influence harness design, bumper architecture, thermal exposure, and even styling constraints around the rear quarter area.
For platforms balancing aerodynamic surfaces, optical perception, and safety compliance, the question is practical: which sensing route delivers dependable coverage without creating new weaknesses?
AEVS has tracked this issue closely because blind spot monitoring sits at the intersection of smart optical perception and auto sensor switches, two areas increasingly linked in exterior system design.
What mm-wave sensing and cameras actually detect
At a basic level, mm-wave sensing measures reflected radio waves. It estimates distance, relative speed, and object movement even when the target is partly obscured.
Camera sensors work differently. They capture visual data and depend on image processing to classify vehicles, bikes, lane edges, and sometimes pedestrians.
That means mm-wave sensing is naturally strong at motion awareness. Cameras are naturally strong at scene interpretation.
For blind spot detection, both can identify adjacent traffic, but they reach that result through different data paths. One emphasizes kinematics. The other emphasizes visual context.
The core trade-off
If the main priority is knowing that something fast is entering the danger zone, mm-wave sensing usually has the edge.
If the main priority is understanding what the object is and where it sits in a broader scene, a camera can add value.
The problem is that blind spot warnings must work before the driver cares about classification detail. They must be early, stable, and trustworthy.
Where mm-wave sensing usually performs better
In real driving, blind spot zones are dynamic. Vehicles approach from diagonals, motorcycles appear suddenly, and closing speeds vary widely.
This is where mm-wave sensing often proves more robust. It does not rely on ambient light, and it can continue tracking in rain, fog, road spray, and glare-heavy sunsets.
For highway lane changes, mm-wave sensing also tends to support lower latency in detecting relative motion. That matters when warning timing is measured in fractions of a second.
Another advantage is hidden-target behavior. When part of a vehicle is masked by dirt, reflections, or body geometry, radar-based systems can still maintain useful detection confidence.
- Stable detection in low light and at night
- Better resistance to fog, mist, and spray
- Direct measurement of relative speed
- Reliable support for rear cross traffic functions
- Strong fit for all-weather safety positioning
These strengths explain why mm-wave sensing remains common in production blind spot architectures, including many systems that later add camera support rather than replace radar entirely.
Where camera sensors still have an advantage
A camera can see lane markings, curb shapes, vehicle outlines, and vulnerable road users in richer detail. That helps when blind spot logic is linked to surround view or driver assistance visualization.
In design terms, camera-based solutions may also support digital mirror strategies, parking fusion, and wider perception reuse across multiple software features.
When image pipelines are already present, adding blind spot functions through software can appear efficient. But that benefit depends on processing capacity, lens cleanliness, and validation quality.
Camera systems also face well-known limits. Performance can degrade under headlight glare, heavy rain, snow buildup, mud, or strong contrast changes at tunnel exits.
The interpretation burden
A camera does not simply detect. It interprets. That creates computational overhead and raises the cost of edge-case validation.
For blind spot detection alone, that extra context is useful, but not always decisive. In many safety programs, dependable triggering matters more than rich scene rendering.
A practical comparison for blind spot detection
A direct feature-by-feature review makes the choice clearer.
For a standalone blind spot warning function, mm-wave sensing usually offers the more dependable baseline. For a broader perception suite, cameras can become more attractive, especially when paired with other visual features.
Integration issues that influence the final choice
The better sensor is not decided by lab performance alone. Exterior integration often changes the answer.
Rear bumper materials, wheel arch turbulence, lighting module heat, and contamination from road debris all affect sensor consistency.
On NEV platforms, these details matter even more. Lightweight exterior structures and aggressive aerodynamic shaping can limit mounting options and alter signal behavior.
This is why AEVS often frames blind spot sensing as an exterior systems question, not only an electronics question. Sensor choice must coexist with wheel airflow, lamp architecture, surface styling, and compliance requirements.
Key evaluation points during selection
- Detection zone shape at highway and urban speeds
- False alert rate near barriers, guardrails, and parked vehicles
- Performance after dirt, salt, and water exposure
- Software calibration burden across vehicle variants
- Compatibility with ECE, DOT, and regional safety expectations
When a hybrid architecture makes more sense
The market is not moving toward a simple winner-takes-all result. In many advanced programs, mm-wave sensing and cameras are complementary.
Radar handles reliable motion detection. Cameras add visual confirmation, object type clues, and smoother integration with surround perception.
This hybrid route is especially relevant when blind spot monitoring feeds lane change assist, mirror displays, or broader ADAS decision layers.
Still, the combination only creates value if the fusion logic is mature. Poor fusion can add complexity without improving trust.
A grounded way to decide
If the requirement is dependable blind spot detection across weather, light transitions, and mixed-speed traffic, mm-wave sensing is usually the stronger primary choice.
If the requirement extends into digital mirrors, scene visualization, or software-heavy perception reuse, cameras deserve a larger role, but rarely without careful risk control.
A useful next step is to compare architectures against real operating conditions rather than headline specifications. Evaluate warning timing, contamination tolerance, and false positives on the actual vehicle surface package.
That approach turns the mm-wave sensing debate into a more valuable exercise: defining which sensor strategy best fits the vehicle’s exterior design, safety targets, and long-term perception roadmap.