
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
Is mm-wave sensing still the best choice for blind spots
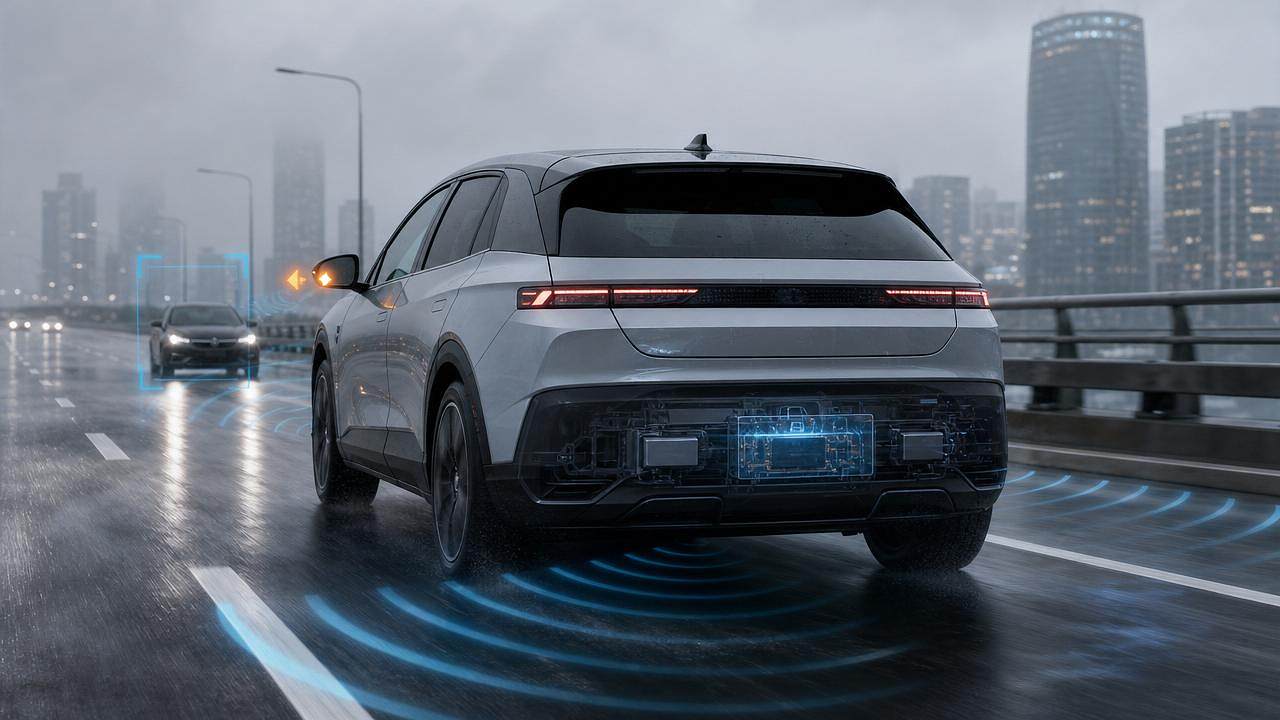
For blind-spot monitoring, mm-wave sensing is still the reference point for range, weather tolerance, and mature vehicle integration. Yet “best choice” now depends on more than detection alone. Sensor cost, styling constraints, software stack complexity, false-alarm control, and fusion readiness all shape the answer. In today’s smart automotive market, the strongest solution is often not a single technology, but the right architecture for the intended safety level and vehicle program.
Why a checklist is necessary before selecting mm-wave sensing
Blind-spot solutions now sit at the intersection of exterior design, optical perception, electronics packaging, and compliance strategy. A simple sensor-to-sensor comparison misses downstream integration risk.
A checklist helps evaluate whether mm-wave sensing remains the best fit, or whether camera-based, ultrasonic, or hybrid sensing offers better lifecycle value.
This matters especially in EV platforms, where aerodynamic surfaces, lightweight body modules, and digital safety features must work together without adding unnecessary cost or complexity.
Core checklist: how to judge whether mm-wave sensing is still the best choice
- Define target detection zones early, including rear lateral range, adjacent-lane speed differentials, and cut-in behavior, before comparing mm-wave sensing with optical alternatives.
- Check weather resilience under rain, fog, road spray, and winter dirt, because blind-spot reliability often drops first at the sensor surface, not in the algorithm.
- Measure false positives in dense traffic, guardrail reflections, and urban multipath conditions, since poor alert logic can reduce trust even when raw detection looks strong.
- Review packaging constraints inside bumper corners, mirror modules, or rear quarter panels, especially where lightweight exterior parts limit sensor angle or material transparency.
- Compare system cost at platform level, including wiring, ECU load, calibration, software maintenance, and replacement expense, not just the sensor bill of materials.
- Validate compatibility with ADAS fusion plans, because mm-wave sensing delivers more long-term value when paired with cameras, headlight logic, or central compute.
- Assess response at highway closing speeds, where radar-based blind-spot monitoring usually outperforms simple vision-only systems in range confidence and relative velocity tracking.
- Inspect aesthetic impact on exterior design, since concealed sensor placement may affect wheel-arch surfaces, bumper geometry, and paint stack choices on premium vehicle programs.
- Confirm regulatory and validation requirements across target markets, including EMC, functional safety, and regional performance expectations linked to driver assistance claims.
- Plan aftermarket serviceability from the start, because misalignment, bumper replacement, or low-quality repairs can degrade mm-wave sensing performance over time.
Where mm-wave sensing still leads clearly
High-speed driving and rear lateral threat detection
On highways, mm-wave sensing remains highly effective because it tracks both object presence and relative speed. That matters when fast-approaching vehicles enter the blind zone quickly.
Cameras can identify object classes well, but speed estimation becomes more demanding in poor visibility or rapid closing scenarios. Radar still provides strong confidence in these conditions.
Rain, fog, and contaminated exterior surfaces
For vehicles operating across mixed climates, mm-wave sensing usually offers better continuity than pure optical systems. Lens contamination can reduce camera quality faster than radar performance degrades.
This advantage supports safety consistency and reduces feature complaints, especially on vehicles exposed to road salt, heavy spray, or frequent long-distance driving.
Where other sensing options are becoming more competitive
Urban maneuvering and close-range visual context
In city traffic, cameras can add valuable context that mm-wave sensing alone does not provide. They help distinguish bicycles, lane markings, curb edges, and complex object shapes.
For low-speed lane changes or parking-adjacent warnings, vision-based systems may improve user understanding, especially when linked to surround-view displays or mirror indicators.
Cost-sensitive vehicle architectures
In entry or mid-range platforms, a dedicated radar module may face pressure from centralized camera architectures. If an existing vision stack can absorb blind-spot functions, total cost may fall.
Still, this only works if the camera system maintains reliable coverage across weather, lighting, and contamination conditions. Low upfront cost can create higher field-performance risk later.
Sensor fusion platforms
The strongest competitor to standalone mm-wave sensing is not another single sensor. It is a hybrid architecture combining radar, camera, and software fusion.
Fusion reduces each sensor’s weakness. Radar handles velocity and poor weather. Cameras provide classification and visual context. Together, they improve blind-spot confidence and driver acceptance.
Commonly overlooked risks when evaluating mm-wave sensing
Material interference from exterior parts
Bumper materials, paint layers, metallic additives, and decorative trims can affect mm-wave sensing transmission. Exterior styling decisions should be validated with sensing performance, not handled separately.
Calibration drift after service events
Blind-spot complaints often appear after minor repairs. A replaced bumper, bracket shift, or wheel-impact event can alter sensor alignment enough to reduce detection quality.
Overestimating raw range and underestimating software quality
A radar with strong specifications can still perform poorly if filtering, target association, or alert timing is weak. Effective mm-wave sensing depends on algorithms as much as hardware.
Ignoring cross-feature integration
Blind-spot monitoring does not live alone anymore. It increasingly interacts with lane change assist, mirror indicators, lighting cues, wiper logic, and central ADAS diagnostics.
Practical execution recommendations
- Start with scenario mapping. Separate highway passing, urban merge, heavy rain, and night driving cases before locking the sensor strategy.
- Benchmark complete system behavior, not sensor datasheets. Compare warning timing, nuisance alerts, and recovery after contamination or temporary blockage.
- Test sensor placement with actual exterior materials. Validate bumper corners, coatings, and mounting tolerances under production-like conditions.
- Request lifecycle data. Include field return rates, calibration stability, replacement complexity, and software update support in the evaluation.
- Prioritize fusion readiness where platform evolution is expected. A scalable architecture protects future blind-spot, lighting, and perception upgrades.
Conclusion: is mm-wave sensing still the best choice for blind spots?
Yes, in many cases mm-wave sensing is still the best choice for blind spots, especially where weather robustness, rear lateral range, and high-speed velocity tracking are critical.
However, it is no longer automatically the best choice in every program. Camera-based systems and fusion architectures are closing the gap, particularly in cost-managed or software-centric platforms.
The most effective next step is to evaluate mm-wave sensing through a structured checklist covering detection performance, exterior integration, software maturity, and service life. That approach reveals whether standalone radar, vision-led sensing, or a hybrid solution will deliver the strongest long-term value.