
Industry Portal
Related News
- 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems
Is mm-wave sensing accurate enough in rain and road spray?
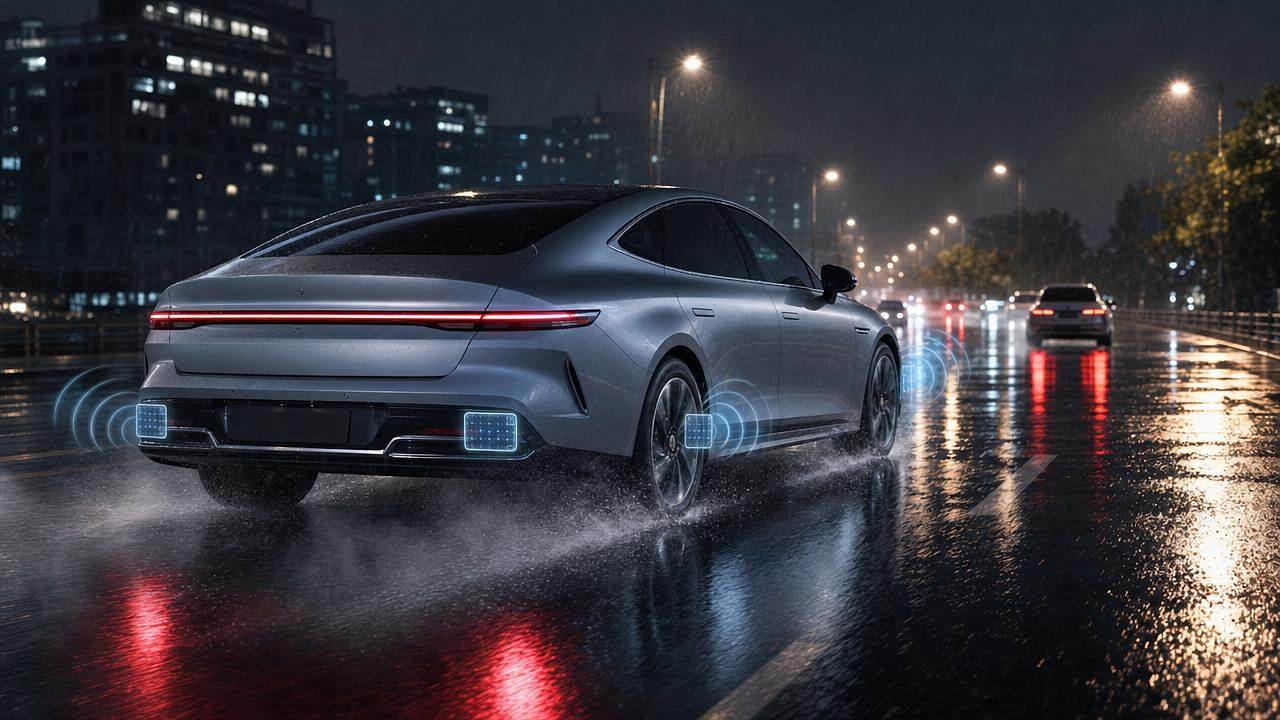
Rain, road spray, and surface contamination can reduce sensor confidence in modern vehicles. That is why mm-wave sensing matters across safety, exterior electronics, and smart vision system design.
In wet driving, the real question is not whether mm-wave sensing works at all. The practical question is how accurate it remains when water droplets, tire spray, mud film, and reflective road surfaces interfere.
For automotive exterior and vision systems, this distinction is critical. Detection stability affects blind-spot monitoring, rear cross-traffic alert, adaptive cruise support, automatic switching logic, and overall validation strategy.
This article explains how mm-wave sensing performs in rain and road spray, where its limits appear, and how integration choices can improve real-world accuracy.
Understanding mm-wave sensing in automotive environments
mm-wave sensing uses radio waves in millimeter-wave frequency bands to detect objects, motion, distance, and relative speed. Automotive radar commonly operates around 24 GHz, 77 GHz, and 79 GHz.
Compared with cameras, mm-wave sensing is less dependent on visible light. Compared with ultrasonic sensors, it usually offers longer range and better speed measurement in dynamic traffic situations.
Its strength comes from Doppler processing, range resolution, and strong penetration through fog, darkness, and moderate precipitation. Yet no sensing technology remains perfect under every contamination condition.
Accuracy in rain depends on several variables:
- Rain intensity and droplet density
- Road spray concentration near the bumper or fascia
- Sensor frequency, antenna design, and power budget
- Radome material, thickness, and water shedding behavior
- Signal processing, filtering, and sensor fusion logic
So, is mm-wave sensing accurate enough? In most production use cases, yes. However, “accurate enough” depends on function safety targets, false alarm tolerance, and environmental validation depth.
Why rain and road spray remain major industry concerns
Wet-weather sensing is now a high-priority issue because vehicles rely on more exterior-mounted electronics. Bumper corners, grilles, mirrors, and rear panels face continuous contamination during daily use.
Electric vehicles amplify this focus. Their quiet cabins raise expectations for seamless driver assistance, while aerodynamic exterior designs can alter water flow and spray accumulation around sensor zones.
Several industry signals explain the increased attention:
Within exterior and vision systems, mm-wave sensing sits at the intersection of optics, aerodynamics, materials, and software. That makes wet-weather performance a cross-disciplinary engineering issue, not only a radar issue.
How accurate mm-wave sensing is under rain and spray
In light to moderate rain, mm-wave sensing generally maintains useful detection performance. It usually outperforms camera-only approaches when visibility drops, especially at night or on poorly marked roads.
The main degradation appears in severe rain, dense truck spray, slush, or standing water splash. In these cases, clutter increases, signal attenuation rises, and near-field contamination can distort target returns.
Typical effects include:
- Reduced detection range for smaller or low-reflectivity objects
- Lower confidence for lateral targets near spray clouds
- Temporary false echoes from water-rich clutter
- Blocked or weakened transmission through contaminated covers
Still, accuracy should be judged by function. For range and relative speed estimation of vehicles, mm-wave sensing remains robust in many wet scenarios. For precise classification, it may require support from camera or fusion systems.
Road spray is often more problematic than rain itself. Spray can form localized, dense water plumes very close to the sensor face, creating unstable returns and persistent contamination on the radome surface.
This is why lab rain testing alone is insufficient. Real accuracy must be validated with wheel spray, dirty water, wake turbulence, and mixed contamination conditions.
Key factors that influence wet-weather accuracy
Sensor placement strongly affects mm-wave sensing performance. Corner radar behind a bumper may face different water loading than front radar placed behind a grille emblem or fascia insert.
Material selection also matters. Exterior panels covering radar must balance styling, paint compatibility, dielectric stability, and low signal loss under temperature and moisture variation.
Software is equally important. Advanced filtering can suppress transient clutter, while confidence models can down-rank uncertain detections during heavy spray events.
Integration value for exterior and vision systems
For automotive exterior systems, mm-wave sensing offers value beyond simple detection. It supports resilient perception architecture when optical channels face rain glare, low contrast, or headlight backscatter.
In practical terms, this brings several business and engineering benefits:
- Improved all-weather continuity for ADAS features
- Better redundancy in sensor fusion stacks
- More stable warning logic in poor visibility
- Stronger safety case for exterior intelligence systems
AEVS-relevant systems benefit directly from this resilience. Auto sensor switches can use mm-wave sensing to improve blind-spot awareness and trigger decisions less vulnerable to darkness or windshield contamination.
LED headlight assemblies also gain indirect value. When radar confidence remains available, intelligent lighting logic can better align beam control, warning cues, and road interaction behavior.
Exterior aerodynamic design has a hidden role here. Wheel arch flow, bumper corner turbulence, and underbody water discharge can all affect how much spray reaches a radar location.
That means mm-wave sensing accuracy is partly shaped by wheel, tire, and body engineering. Cross-functional development improves outcomes more than isolated sensor tuning.
Typical automotive scenarios and performance expectations
Not every use case demands the same wet-weather accuracy. Functions differ in target distance, reaction timing, and acceptable uncertainty.
These scenarios show why mm-wave sensing is usually accurate enough only when matched to the right function envelope, environmental model, and fallback logic.
Practical validation priorities and design precautions
A reliable wet-weather program should test mm-wave sensing as a system, not just as a component. Sensor hardware, cover design, mounting angle, and vehicle airflow must be evaluated together.
Useful validation priorities include:
- Measure performance in light, moderate, and severe rain.
- Add wheel spray, muddy mist, and saltwater contamination tests.
- Check radome transmission after paint, aging, and thermal cycling.
- Map false alarms and missed detections by scenario.
- Verify fusion behavior when camera confidence falls sharply.
- Review cleaning, drainage, and self-shedding exterior geometry.
Several design precautions improve mm-wave sensing reliability:
- Avoid sensor zones with persistent vortex-driven spray buildup
- Use radar-friendly fascia materials with stable dielectric behavior
- Control panel curvature and thickness consistency
- Coordinate tire and wheel spray management with sensor packaging
When these precautions are ignored, software compensation alone rarely fixes the problem. Wet-weather accuracy starts with sound exterior architecture.
Assessment path for next-stage deployment
The evidence shows that mm-wave sensing is accurate enough for many automotive functions in rain and road spray, but not equally enough for every task or every installation condition.
Its real advantage is dependable detection continuity when vision-based systems struggle. Its real limitation appears in severe near-sensor contamination, clutter-rich spray plumes, and poorly engineered exterior placement.
A sensible next step is to evaluate mm-wave sensing through three filters: target function, exterior packaging, and environmental validation depth. That approach gives a clearer view of risk than headline accuracy claims.
For exterior and vision system development, the strongest results come from combining radar expertise with aerodynamic analysis, material control, and fusion strategy. That is where durable all-weather performance is built.
If a program must operate reliably through rain, splash, and roadside contamination, mm-wave sensing deserves attention not as a standalone feature, but as a core part of integrated vehicle perception architecture.