
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
Tags
Is mm-wave sensing accurate enough for blind spot alerts
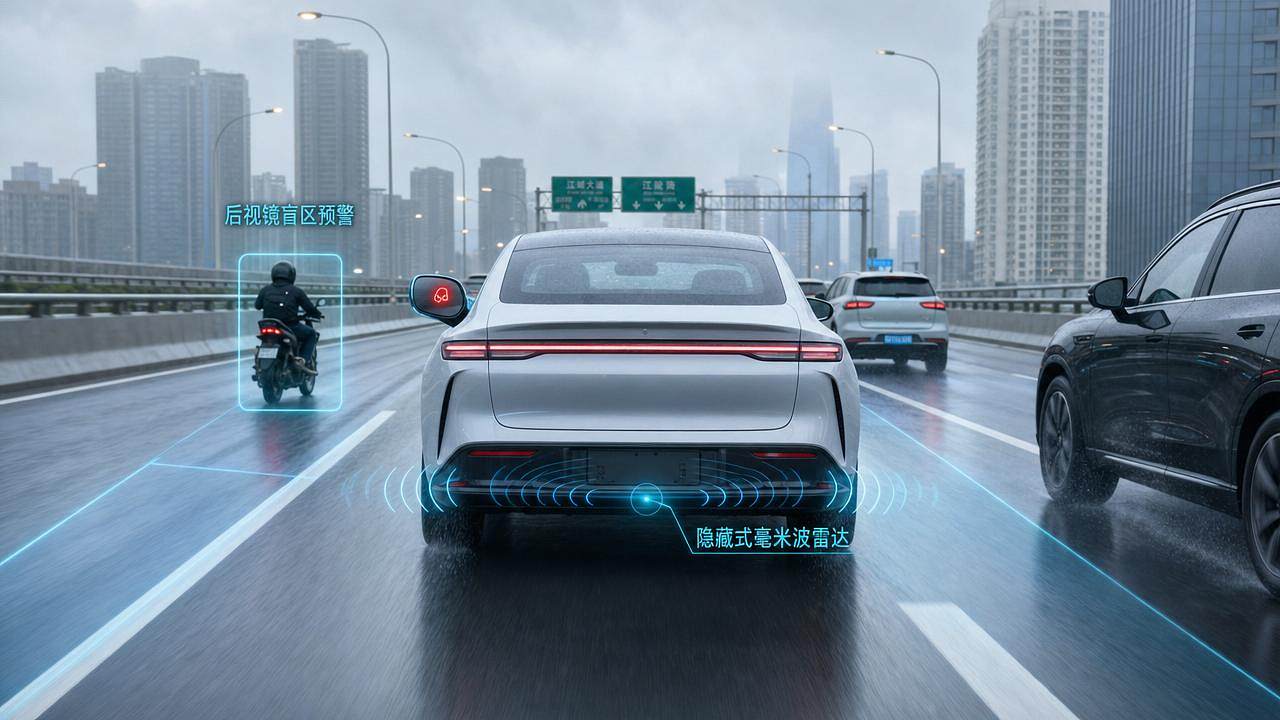
mm-wave sensing is moving from optional feature to safety expectation
For blind spot alerts, innovation alone is not enough.
The key issue is whether mm-wave sensing can stay accurate under rain, road spray, dense traffic, and high-speed lane changes.
That question matters more as NEVs adopt tighter safety integration, cleaner exterior packaging, and more automated driver assistance functions.
In practice, mm-wave sensing is accurate enough for blind spot alerts when system design, placement, filtering, and validation are executed correctly.
However, accuracy is never a single number.
It depends on target reflectivity, sensor position, bumper materials, algorithm tuning, and how the alert logic handles uncertainty.
For automotive exterior and vision systems, this makes mm-wave sensing both a proven technology and a continuing engineering discipline.
The market signal is clear: blind spot performance now depends on robust sensing, not feature claims
Blind spot monitoring used to be judged mainly by availability.
Now it is judged by consistency, especially in crowded urban traffic and fast highway merges.
This shift is changing how mm-wave sensing is specified across the vehicle exterior system.
Several trend signals explain why accuracy expectations are rising:
- NEVs often have quieter cabins, making warning quality more noticeable.
- Vehicle bodies are becoming smoother, forcing smarter sensor integration behind fascia surfaces.
- ADAS stacks increasingly rely on sensor fusion, so weak inputs affect the whole safety chain.
- Regulatory pressure and consumer ratings emphasize real-world performance, not brochure specifications.
- Higher traffic density raises the need to distinguish valid targets from roadside clutter.
As a result, mm-wave sensing accuracy is being evaluated as part of the complete exterior perception architecture.
That includes radar hardware, switch logic, optical support systems, housing materials, and calibration quality.
Why mm-wave sensing performs well in blind spot alerts
The main strength of mm-wave sensing is stable object detection under conditions that challenge cameras or ultrasonic sensors.
Blind spot zones are dynamic, narrow, and often contaminated by spray, dirt, darkness, and multi-path reflections.
Millimeter-wave radar handles many of these conditions better because it measures range, speed, and motion direction directly.
Core technical advantages behind reliable detection
These strengths explain why mm-wave sensing remains a mainstream choice for rear-side monitoring functions.
When paired with good filtering, it can detect motorcycles, cars, and fast-approaching targets with strong repeatability.
Accuracy limits appear when installation and algorithms are not treated as system-level issues
The biggest mistake is to discuss mm-wave sensing accuracy as if radar performance were independent from vehicle design.
In blind spot applications, several factors can reduce detection quality or increase false alerts.
Most common causes of degraded mm-wave sensing performance
- Bumper materials with unstable dielectric behavior.
- Sensor mounting angles that distort rear-side coverage.
- Metal structures nearby creating ghost reflections.
- Poor calibration after assembly or repair.
- Algorithms that overreact to guardrails, poles, or parked vehicles.
- Target classification weakness for bicycles or narrow-profile vehicles.
This is why some vehicles show excellent blind spot alert behavior, while others create warning fatigue.
False positives reduce trust.
False negatives create safety exposure.
Neither outcome is acceptable if mm-wave sensing is expected to support advanced exterior intelligence.
The real trend is sensor fusion, not radar acting alone
In current vehicle architectures, mm-wave sensing rarely delivers its best blind spot performance in isolation.
Its value rises when combined with camera logic, optical indicators, body control units, and smart sensor switches.
This is especially relevant to exterior and vision platforms that already manage headlights, rain sensing, and side-body perception.
How fusion improves blind spot confidence
- Radar confirms motion, distance, and closing speed.
- Camera logic can help classify object type in clear conditions.
- Vehicle state data refines alert timing during turns or lane changes.
- Human-machine interface rules reduce unnecessary warnings.
This layered approach does not replace mm-wave sensing.
It makes mm-wave sensing more dependable, especially in edge cases where one sensor channel becomes uncertain.
What the accuracy question means for exterior systems, validation, and lifecycle quality
For the broader automotive value chain, blind spot accuracy affects more than one module.
It shapes exterior design choices, verification budgets, field service strategy, and safety reputation.
Key impact areas
This is where intelligence platforms such as AEVS add value.
Blind spot performance should be read alongside optics evolution, body architecture, and compliance trends.
What deserves close attention before judging mm-wave sensing as accurate enough
A useful decision framework is not “Does the radar work?”
The better question is “Under which operating envelope does mm-wave sensing stay trustworthy?”
Core checkpoints for dependable blind spot alerts
- Detection range across compact cars, SUVs, motorcycles, and bicycles.
- Performance stability in rain, fog, slush, and road contamination.
- False alert control near barriers, trucks, and curved roads.
- Integration compatibility with bumper materials and styling requirements.
- Calibration retention after maintenance, collision repair, or parts replacement.
- Compliance alignment with regional safety expectations and validation protocols.
These checkpoints turn the mm-wave sensing discussion from marketing language into measurable engineering evidence.
A practical judgment: accurate enough, if validated as part of the full exterior perception stack
So, is mm-wave sensing accurate enough for blind spot alerts?
Yes, in most modern automotive applications, it is accurate enough to serve as a core sensing layer.
But that answer is conditional.
mm-wave sensing reaches dependable blind spot performance only when hardware packaging, algorithm tuning, and validation discipline are mature.
The next step is to evaluate mm-wave sensing through real operating scenarios, not isolated laboratory claims.
Track how bumper design, optical systems, sensor switch logic, and service recalibration interact across the vehicle lifecycle.
That system-level view is the most reliable way to decide whether mm-wave sensing can sustain trustworthy blind spot alerts at scale.
For organizations following exterior intelligence trends, this is also where the strongest long-term advantage will emerge.