Industry Portal
Related News
- 00
0000-00
NEV Industry Standards in China: Which Battery Safety Tests Are Required? - 00
0000-00
Automotive Exterior Lighting Systems: Lamp Types, Functions, and Placement - 00
0000-00
Choosing an Electric SUV Sunroof: Key Fit, Safety, and Weather-Sealing Factors - 00
0000-00
Pop-Up Automotive Sunroof Systems: Key Design Factors for Vehicle Integration - 00
0000-00
Automotive Product Comparison Charts: How Buyers Can Compare Specs, Cost, and Fit
How to Specify EV Sensor Systems for Reliable ADAS and Battery Safety Performance
How to Specify EV Sensor Systems for Reliable ADAS and Battery Safety Performance
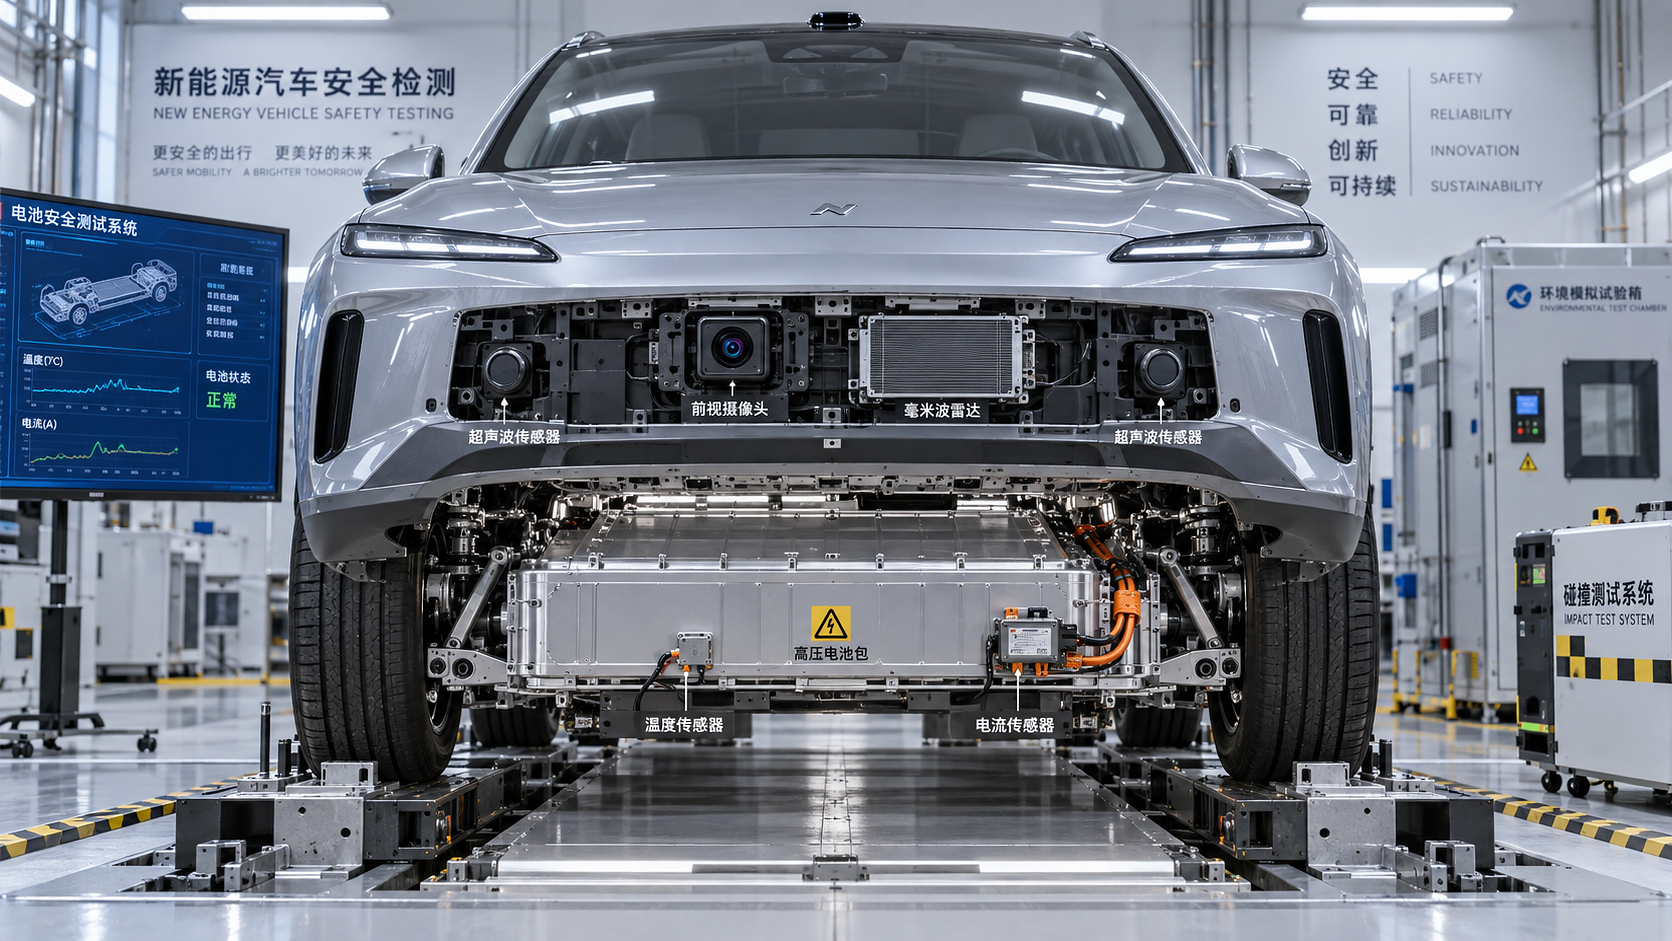
Specifying automotive sensor systems for EVs requires more than comparing detection range, resolution, or unit cost on a datasheet. Technical evaluators must decide whether a sensor remains trustworthy when the vehicle is exposed to rain, road spray, curb strikes, high-voltage switching noise, thermal cycling, low-contrast objects, or partially degraded optics. The decision also reaches beyond perception: the same electrical and software architecture that supports ADAS may influence how reliably a vehicle recognizes abnormal battery conditions and moves into a safe state.
For an EV platform, sensor selection is therefore a system-engineering task. A camera may have excellent nominal image quality but lose effective performance behind a contaminated lens cover. A radar may offer robust detection in fog yet create integration issues when its bumper radome, decorative coating, or mounting bracket changes. A battery temperature sensor may be accurate in a laboratory but provide insufficient insight if its placement does not reflect the cell temperatures that matter for thermal control and fault detection.
The strongest specifications start with the vehicle’s operational risks, then translate those risks into measurable sensor, interface, diagnostics, validation, and service requirements. That approach is more durable than selecting components one by one and hoping that fusion software resolves the remaining gaps.
Start With Safety Functions, Not Sensor Categories
It is tempting to begin with a shopping list: forward camera, corner radar, ultrasonic sensors, cabin camera, battery temperature sensors, current sensors, voltage sensing, and perhaps lidar for higher automation targets. That list says little about whether the architecture can support the intended vehicle behavior.
A more useful first question is: what safety-relevant decision must the vehicle make, under what conditions, and with what acceptable uncertainty? Forward collision warning, automatic emergency braking, blind-spot assistance, parking support, adaptive lighting, automatic wipers, battery charging control, thermal derating, isolation monitoring, and high-voltage contactor management all have different sensing needs. Some require long-range classification; others need reliable near-field presence detection; battery functions often depend on stable, traceable measurements rather than broad environmental perception.
Functional safety work under frameworks such as ISO 26262 should shape the allocation of sensing, diagnostics, redundancy, and safe-state behavior. For ADAS functions whose limitations arise from difficult real-world scenes rather than component faults alone, evaluators should also consider the safety-of-the-intended-functionality questions commonly addressed through ISO 21448. Neither framework can be reduced to a sensor certificate. The key issue is whether the entire function has a credible response when the input is missing, implausible, delayed, or ambiguous.
For example, a lane-related function should not merely define camera resolution. It needs operational design domain boundaries, lane-marking assumptions, glare and low-light behavior, confidence reporting, degradation strategy, and driver notification logic. Likewise, battery safety sensing should define what happens if one temperature channel is implausible, a voltage measurement drifts, a current signal is interrupted, or communication from the battery management system is unavailable.
Build a Complementary Perception Stack
No single external sensor modality is equally strong in every driving condition. Cameras provide rich semantic information for object classification, lane interpretation, traffic-sign recognition, driver-facing visual functions, and smart lighting inputs. Their limitations are familiar: low sun, darkness, glare, rain, fog, lens contamination, and scenes with poor contrast can reduce usable information even when the camera remains electrically healthy.
Radar is generally valued for range and robustness in adverse weather, but its real-world performance depends heavily on installation. Fascia geometry, paint chemistry, metallic pigments, sensor angle, radome thickness, and nearby structural features can influence transmission and unwanted reflections. A radar specification should therefore include vehicle-level verification through the final bumper and not only free-space supplier data.
Ultrasonic sensing remains relevant for close-range parking and low-speed maneuvering, especially where precise near-field awareness matters more than long-range classification. Lidar may provide useful geometric detail for certain automation strategies, but its selection should include questions about optical cleanliness, heating, packaging, field of view, point-cloud performance under adverse conditions, and the maintainability of the chosen mounting location.
The practical decision is not “camera versus radar.” It is whether the sensor suite has sufficiently independent failure characteristics for the claimed function. Fusion can reduce uncertainty, but it cannot recover information that every sensor has lost for the same reason. If a vehicle design places multiple forward-facing sensors behind surfaces prone to the same contamination pattern, that common-cause exposure deserves more attention than nominal sensor diversity.
Specify performance in use, not only peak capability
Sensor requirements should state the test conditions that matter to the vehicle program. These may include target type, relative speed, detection probability criteria defined by the project, field of view, range zones, object classification needs, latency, update rate, false-positive tolerance, and confidence output. “Detect pedestrians at distance” is not an engineering requirement until the target conditions, illumination, occlusion, road geometry, and response chain have been clarified.
Latency deserves particular scrutiny in heavy EVs. Vehicle mass, tire characteristics, brake thermal state, road grip, and control strategy all affect stopping behavior. The sensor’s contribution is only one part of the total response time, which also includes signal processing, fusion, decision logic, network transport, actuator response, and brake-system behavior. A low-latency sensor does not automatically produce a low-latency safety function.
Treat Battery Sensing as a Safety Architecture
Battery safety depends on more than temperature measurement. A battery management system typically requires a coordinated view of cell or module voltage, pack current, temperature, insulation condition, contactor state, cooling-system feedback, and communication integrity. Depending on the pack architecture and hazard analysis, additional sensing may be considered for pressure, gas, coolant conditions, or local thermal events. The required configuration must be determined at pack and vehicle level rather than copied from another program.
Placement is often as consequential as sensor accuracy. A temperature sensor attached to a module surface may not represent the hottest internal location during high-load operation or charging. More channels improve spatial visibility, but they add harness complexity, diagnostic load, cost, and potential failure points. The correct balance depends on cell format, module construction, cooling path, thermal propagation assumptions, and the time available for protective action.
Current sensing requires similar discipline. Resolution, offset stability, bandwidth, measurement range, response under transients, galvanic isolation, and fault detection should be assessed against the BMS control strategy. A solution adequate for energy estimation may not be adequate for fast protection decisions. Voltage sensing also needs attention to channel accuracy, common-mode conditions, isolation design, wiring faults, and the ability to identify implausible readings.
For global programs, battery-related compliance should be checked against the applicable market and vehicle requirements rather than assumed from one region. UNECE Regulation No. 100 is relevant to electric powertrain safety in markets applying the UNECE framework, while other jurisdictions may have different approval, testing, and documentation expectations. Sensor specifications should leave room for evidence gathering, change control, and traceability throughout validation.
Environmental Durability Is an Integration Question
An automotive sensor is exposed through its installation, not in isolation. Exterior cameras and radar modules must tolerate vibration, stone impact risk, water ingress, salt, cleaning chemicals, solar load, and repeated thermal expansion of surrounding components. Sensor-switch functions for automatic lighting or wiper activation can be affected by windshield optical properties, coatings, adhesive regions, sensor coupling, and replacement-glass variation. These details are easy to underestimate until late validation reveals inconsistent field behavior.
The same principle applies to EV exterior design. Low-drag wheels, tire spray patterns, front-end air management, headlamp geometry, and bumper form can alter where dirt accumulates and how water moves across sensing surfaces. A sensor strategy should therefore involve exterior designers, aerodynamics teams, lighting engineers, chassis specialists, and ADAS developers early enough to change the package. Cleaning systems, lens heaters, protective coatings, drainage paths, and diagnostic alerts may be justified where the function cannot tolerate a prolonged loss of perception.
This cross-disciplinary view aligns closely with the work of The Global Automotive Exterior & Vision Systems (AEVS). Its focus on smart optical perception, exterior architecture, high-performance tires, lightweight wheels, lighting systems, and body-network sensor switches reflects a useful reality: perception reliability is influenced by the entire vehicle envelope, not merely by the electronic control unit.
Do Not Leave EMC, Networks, and Cybersecurity Until Late
EVs create a demanding electrical environment. High-voltage inverters, DC-DC converters, charging hardware, traction motors, switching events, and long harness runs can challenge low-level sensor signals and high-speed communication links. Electromagnetic compatibility must be evaluated at component, subsystem, and vehicle levels. A module that passes its own test plan may still be affected by grounding, cable routing, shielding choices, connector design, or interactions with neighboring equipment after installation.
Specify power-supply operating conditions, startup and shutdown behavior, voltage transients, communication recovery, fault reporting, timestamp handling, and data integrity. For Ethernet-based sensors in particular, time synchronization, network loading, diagnostic access, and degraded communication modes should be considered before harness and gateway decisions are frozen.
Connected sensors also create cybersecurity considerations. ISO/SAE 21434 provides a recognized process framework for road-vehicle cybersecurity engineering, but the practical question is simpler: can a compromised, spoofed, stale, or unavailable sensor input be recognized and contained? Secure updates, authenticated communications where appropriate, access control, logging, and anomaly handling should be consistent with the vehicle cyber-risk assessment.
Use Supplier Evidence to Judge Maturity
A credible supplier review goes beyond a presentation of headline specifications. Technical evaluators should request clarity on requirement ownership, hardware and software revisions, calibration needs, manufacturing end-of-line testing, traceability, diagnostic coverage assumptions, environmental validation scope, electromagnetic compatibility evidence, and change-notification processes. Where a sensor depends on a vehicle-specific radome, lens, bracket, or thermal interface, the responsibility split must be explicit.
It is also worth examining how a supplier handles degradation. Can the module identify blocked optics, misalignment, overheating, communication loss, internal self-test failures, or implausible output? Is the diagnostic state available to the relevant domain controller? Can service teams recalibrate or replace the sensor without creating an unverified vehicle condition? These questions frequently expose risks that a range-and-resolution comparison will miss.
- Define vehicle functions and safety goals before fixing the sensor bill of materials.
- Validate sensors behind production-intent materials, surfaces, coatings, and mounting structures.
- Assess common-cause failures such as contamination, shared power loss, thermal exposure, and network disruption.
- Link battery measurements to thermal models, control actions, fault thresholds, and safe-state behavior.
- Plan calibration, replacement, software updates, and diagnostic access as part of lifetime ownership.
A Better Final Decision Gate
Before nomination, the program team should be able to explain why each sensor exists, which failure modes it addresses, what its operational limits are, and how the vehicle behaves when its information cannot be trusted. If the answer relies mainly on supplier claims or bench-test results, the specification is not finished.
The most reliable automotive sensor systems for EVs are specified as part of a connected exterior, electrical, software, and battery-safety architecture. That perspective is especially important as LED headlamps become perception-linked interfaces, body sensor switches feed automated comfort functions, and vehicle shape influences sensor cleanliness and field of view. AEVS’s Strategic Intelligence Center approaches these interdependencies through optics, tire dynamics, exterior architecture, compliance developments, and component-level engineering trends. For evaluators, the useful next step is to convert that broader view into a program-specific verification matrix: functions, hazards, environmental conditions, interfaces, diagnostics, regulations, and lifetime service assumptions should all be visible before the design is locked.