
Industry Portal
Related News
- 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects - 00
0000-00
Automatic Wipers for Buses: 7 Selection Criteria for Fleet Procurement - 00
0000-00
How Smart Optical Perception Prevents Collisions in Low-Light Driving Conditions - 00
0000-00
Private Label Tire Export: Evaluating Suppliers, Compliance, and Landed Cost - 00
0000-00
DOT-Compliant Truck Lighting: A Practical Guide to FMVSS 108 Requirements
How mm-wave sensing is changing blind spot accuracy
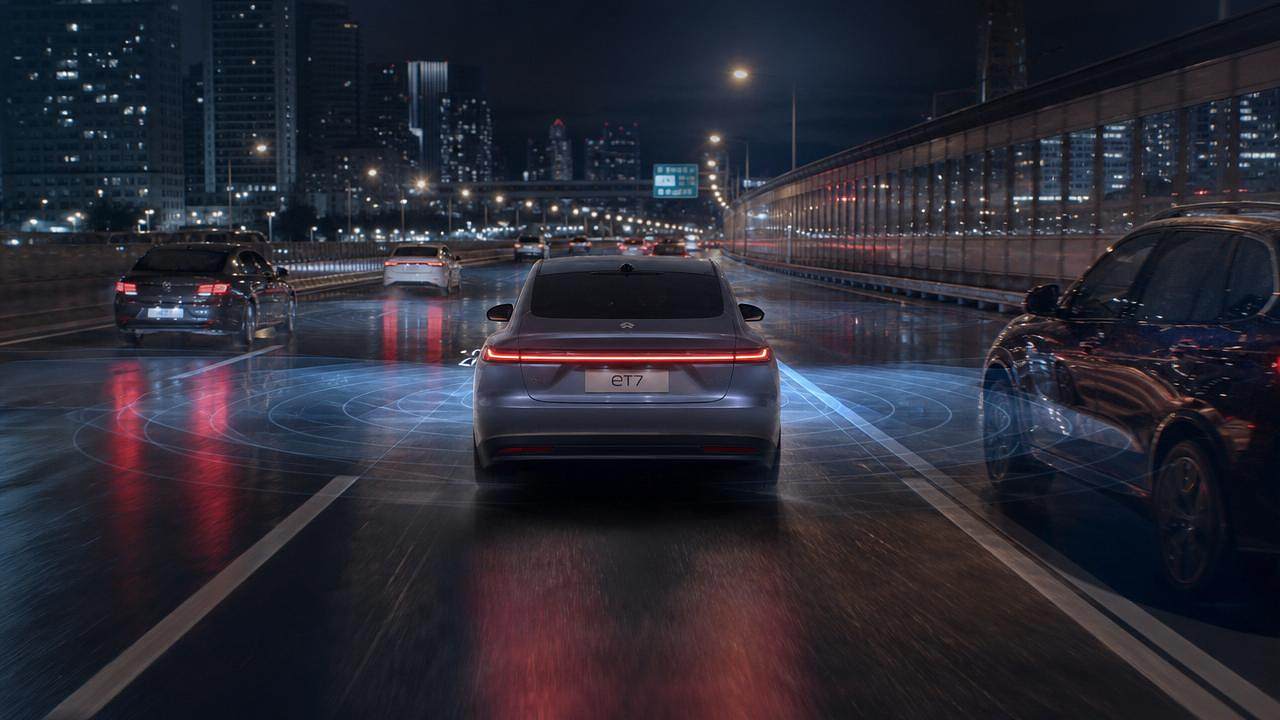
For technical evaluators, mm-wave sensing has moved beyond a supporting ADAS feature. It now plays a direct role in blind spot accuracy, especially in fast, dense, and weather-affected traffic.
As vehicle exteriors become smarter, detection quality is no longer judged only by range. Stability, filtering, reaction timing, and integration with optical perception now define real system value.
This matters across the broader automotive exterior and vision systems sector. Blind spot monitoring influences mirror architecture, sensor switch logic, lighting interaction, and the safety credibility of new energy vehicles.
Blind spot accuracy and the role of mm-wave sensing
mm-wave sensing uses millimeter-wave radar to detect objects through reflected electromagnetic signals. In blind spot applications, it monitors adjacent lanes, rear-side zones, and fast-approaching targets.
Traditional blind spot systems often struggled with rain, spray, glare, and clutter. Camera-only approaches can lose confidence when visibility drops or when object contrast becomes weak.
mm-wave sensing improves resilience because it is less dependent on visible light. It can maintain useful detection performance in fog, darkness, road splash, and low-contrast scenes.
Its real advantage is not merely seeing farther. The bigger change is more reliable classification of relative speed, angle, and motion, which directly affects warning precision and false alert control.
Core technical elements shaping accuracy
- Range resolution, which separates nearby vehicles from roadside structures.
- Velocity estimation, critical for identifying fast overtaking traffic.
- Angular resolution, which improves lane-level target placement.
- Signal processing quality, which reduces ghost targets and clutter.
- Sensor fusion logic, which links radar confidence with vision and body controls.
Because of these factors, mm-wave sensing is increasingly assessed as a system architecture decision, not just a component specification.
Why the industry is paying closer attention
Across smart mobility, blind spot performance now affects more than safety ratings. It also influences exterior packaging, energy efficiency, software complexity, and platform scalability for global vehicle programs.
For portals focused on exterior and vision intelligence, this shift is important. Side sensing now connects with mirror design, bumper materials, wheel airflow, lighting interfaces, and vehicle body communication networks.
The result is clear. mm-wave sensing is being judged by how well it supports a complete exterior perception strategy, not by isolated detection distance claims.
Operational value across exterior and vision systems
In practical programs, mm-wave sensing improves blind spot accuracy by increasing detection confidence in situations where exterior sensors usually face uncertainty.
1. Better stability in adverse weather
Rain, mist, and road spray can weaken camera performance. Radar-based side sensing remains more consistent, helping preserve warning logic during lane changes and merging events.
2. Stronger speed discrimination
Blind spots are dangerous when a fast vehicle approaches from the rear-side area. mm-wave sensing can better estimate relative speed, supporting earlier and more accurate alert timing.
3. Lower false warning rates
Road barriers, parked vehicles, and metallic clutter can confuse weaker systems. Advanced filtering and tracking reduce unnecessary warnings that erode trust in driver assistance functions.
4. Cleaner integration with smart body electronics
Auto sensor switches, mirror indicators, and lighting prompts can all respond to radar confidence levels. This creates a tighter loop between detection, notification, and body control behavior.
5. Support for future perception stacks
As LED headlight assemblies and optical systems become more intelligent, side radar adds a dependable non-visual input. That balance improves overall perception robustness across mixed driving environments.
Typical scenarios where mm-wave sensing changes results
Blind spot accuracy should be judged in real scenarios, not ideal test lanes. The strongest impact of mm-wave sensing appears in transitional, cluttered, and speed-variable conditions.
These scenarios explain why side radar evaluation now matters to both safety engineering and exterior system planning.
Key evaluation factors for accurate deployment
A strong mm-wave sensing solution depends on more than sensor selection. Installation, materials, thermal conditions, and calibration all affect blind spot accuracy in production vehicles.
Packaging and mounting geometry
Bumper curvature, bracket angle, and side body contours can distort the sensing field. Clean packaging is essential for consistent adjacent-lane coverage.
Material interaction
Paint thickness, metallic coatings, and fascia composition can affect signal transmission. Exterior styling decisions should be reviewed alongside radar performance targets.
Fusion strategy
Radar-only detection can be strong, but fusion often improves confidence. Combining mm-wave sensing with cameras and smart sensor switches helps balance context and reliability.
Environmental validation
Testing should include wet roads, reflective barriers, tunnels, heavy traffic, and mixed-speed flows. Accuracy claims from limited conditions can be misleading.
Software tuning and update pathways
Tracking algorithms, threshold settings, and object classification models shape user experience. Calibration should allow updates as fleet data reveals new edge cases.
Practical recommendations for next-step assessment
For a reliable blind spot roadmap, mm-wave sensing should be reviewed as part of the complete exterior intelligence stack. Short-term cost checks alone rarely capture long-term system value.
- Map target scenarios first, including weather, speed bands, and traffic density.
- Verify mounting and material compatibility before freezing exterior surfaces.
- Compare false alert rates, not just maximum range figures.
- Review integration with mirror alerts, lighting cues, and body network logic.
- Plan for software refinement using field feedback and compliance requirements.
In today’s market, blind spot performance reflects the maturity of the whole vehicle perception approach. That is why mm-wave sensing has become a defining metric in exterior and vision system evaluation.
A deeper review of side radar architecture, optical coordination, and exterior integration can reveal where accuracy gains are technically achievable and commercially meaningful.