
Industry Portal
Related News
- 00
0000-00
Which ISO Standards Govern Vehicle Lightweighting Materials and Validation Testing? - 00
0000-00
Wheel Lightweighting in Europe: How EV Regulations Are Reshaping Wheel Sourcing - 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials
How mm-wave sensing changes blind spot safety in traffic
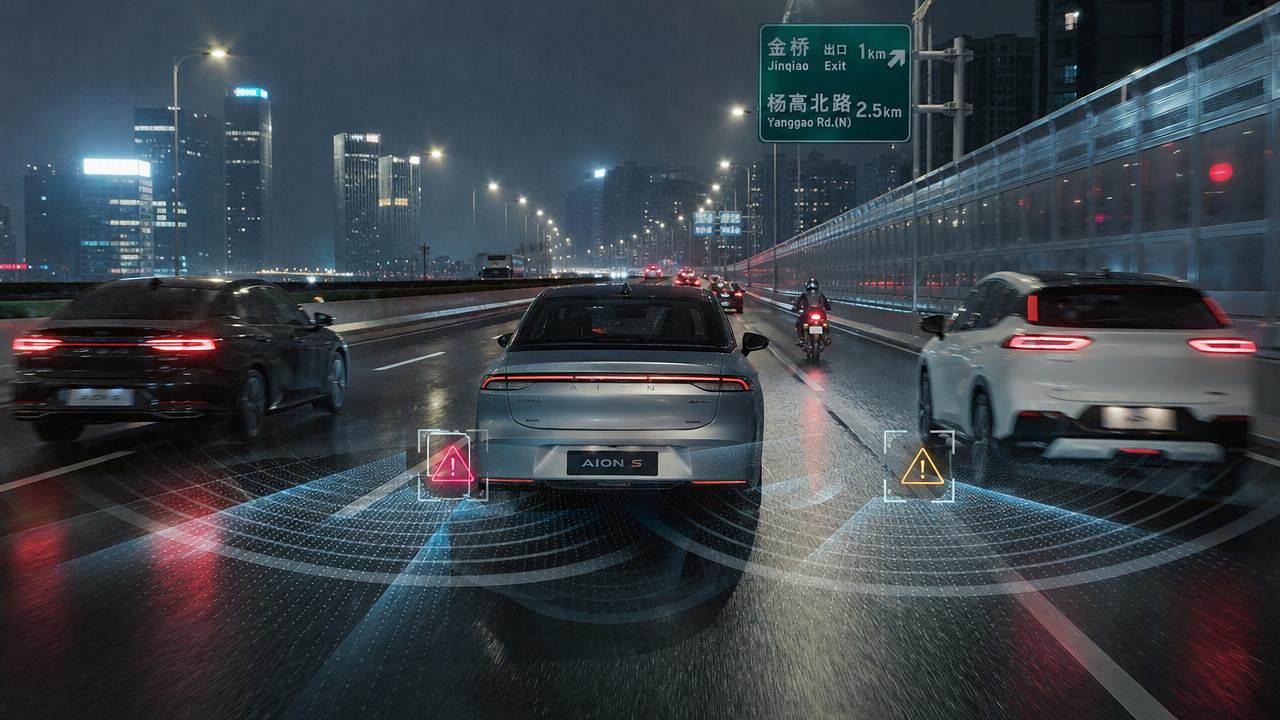
As traffic grows more complex, mm-wave sensing is redefining blind spot safety across modern mobility systems. It delivers faster object recognition, stronger all-weather stability, and tighter integration with mirrors, lighting, and body electronics.
For the automotive exterior and vision ecosystem, this matters far beyond a warning icon. It shapes lane-change confidence, sensor placement strategy, compliance planning, and the evolving safety expectations surrounding global NEV platforms.
Why blind spot safety now depends on scene-based sensing judgment
Blind spot risk is no longer limited to simple highway overtakes. Urban density, mixed traffic, silent EV operation, and higher driver assistance adoption have expanded the number of edge cases.
In these changing environments, mm-wave sensing offers a practical advantage. It detects relative speed, distance, and movement direction with greater consistency than many vision-only approaches.
That consistency is important for exterior system planning. Sensor switches, mirror modules, rear corner architecture, and lighting interactions must now support faster and cleaner decision loops.
The value of mm-wave sensing increases when traffic conditions become uncertain. Rain, fog, glare, road spray, and nighttime driving all reduce the reliability of human judgment.
High-speed lane change scenarios demand earlier blind spot awareness
On expressways, blind spot safety depends on early detection rather than late warning. Vehicles approach quickly from rear-side zones, leaving little time for correction after mirror checks.
Here, mm-wave sensing improves risk timing. It can track fast-closing targets and estimate threat severity before the vehicle fully enters the adjacent lane.
This supports better calibration of alert thresholds. Systems can distinguish a distant vehicle from one accelerating into a critical blind zone.
Key judgment points for highway use
- Relative speed matters more than simple presence detection.
- Rear corner radar coverage must remain stable during body vibration.
- Alert timing should avoid both panic warnings and delayed response.
- Integration with steering intent improves lane-change relevance.
For NEVs, aerodynamic surfaces and lightweight body parts can influence mounting angles. That makes packaging quality as important as sensing performance.
Urban mixed traffic scenarios test detection precision more than range
Cities present a different challenge. Speeds are lower, but traffic objects are more diverse, including scooters, bicycles, delivery vehicles, and pedestrians crossing near side lanes.
In this setting, mm-wave sensing must reduce false alarms while preserving short-range accuracy. Frequent alerts with weak relevance quickly reduce driver trust.
Urban blind spot monitoring works best when radar data is fused with vehicle speed, turn signal status, and surrounding object trajectories. Context is everything.
Typical city-side blind spot cases
- A bicycle approaches the rear quarter during a right turn.
- A scooter filters through adjacent lanes beside stopped traffic.
- A compact EV exits a parking lane into a crowded road.
- Roadside barriers create partial reflections near intersections.
These cases show why mm-wave sensing is not just a hardware upgrade. It is a scene interpretation tool that supports safer exterior intelligence.
Rain, fog, and glare scenarios reveal the all-weather edge of mm-wave sensing
Bad weather remains one of the strongest arguments for mm-wave sensing. Cameras and human eyes both suffer when visibility drops or strong reflections distort scene perception.
Millimeter-wave radar keeps working through many conditions that weaken optical performance. That makes it valuable for blind spot detection linked to mirrors, wipers, and headlight logic.
This advantage aligns with AEVS focus areas. Auto sensor switches, smart headlights, and exterior perception systems increasingly benefit from cross-domain data sharing.
Why weather resilience matters in exterior system design
- Road spray can obscure camera edges and mirror sightlines.
- Low sun angles create glare that disturbs visual judgment.
- Night rain reduces contrast for lane-level visual interpretation.
- Radar-backed sensing improves continuity during degraded visibility.
Different traffic scenes require different mm-wave sensing priorities
Not every vehicle program should evaluate blind spot sensing with the same checklist. Scene priorities change according to speed profile, vehicle size, traffic density, and regional regulations.
This comparison shows that mm-wave sensing should be judged by application fit, not by a single performance number.
How to adapt blind spot systems to different vehicle and market needs
A practical deployment strategy starts with vehicle architecture. Rear fascia materials, wheel arch geometry, and exterior trim can all affect radar transparency and installation quality.
From there, calibration should reflect actual usage patterns. A city-focused compact EV needs different thresholds than a premium crossover built for long-distance travel.
Scene adaptation recommendations
- Map common traffic scenes before defining warning logic.
- Test mm-wave sensing behind real exterior materials, not only lab panels.
- Align blind spot alerts with mirror indicators and driver intent signals.
- Validate performance in rain, road salt, and dirt accumulation conditions.
- Review regional compliance requirements early in platform development.
For cross-functional exterior programs, this reduces redesign risk and helps maintain both safety performance and visual integration.
Common blind spot mistakes when mm-wave sensing is added too late
One common mistake is treating mm-wave sensing as a plug-in feature. In reality, its effectiveness depends on placement, signal filtering, body contours, and software coordination.
Another error is overvaluing range while ignoring scene relevance. Long detection distance means little if the system misjudges harmless objects or misses lateral threats.
There is also a packaging misconception. Decorative trims, metallic coatings, and wheel-generated spray patterns can interfere with sensing quality if not reviewed early.
- Do not calibrate using only dry and clean test conditions.
- Do not separate radar decisions from turn signal logic.
- Do not ignore body material effects on radar transmission.
- Do not assume camera redundancy solves all blind spot cases.
Next-step focus for safer traffic systems using mm-wave sensing
The shift in blind spot safety is clear. mm-wave sensing is moving from a supporting detector to a core judgment layer for exterior intelligence and traffic risk reduction.
The strongest results come from scene-based validation. Highway speed, urban density, weather exposure, and vehicle packaging all shape the right sensing strategy.
A useful next step is to review blind spot performance by scenario, then compare sensor behavior against exterior design constraints and compliance needs. That creates a clearer path toward safer, smarter mobility systems.