
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
How Dynamic Driving Perception Systems Improve Detection in Urban Traffic
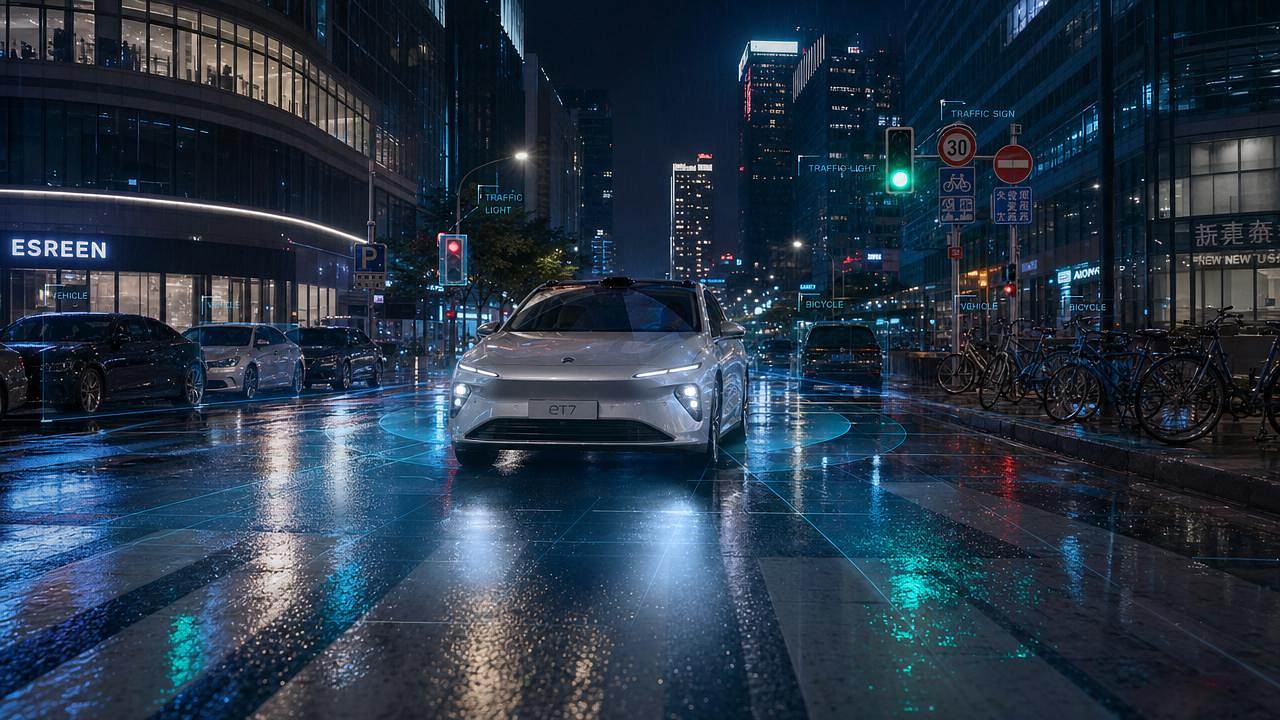
Urban detection improves when perception reacts, not just records
Urban traffic rarely fails in one obvious way. It usually breaks perception through overlap, glare, sudden motion, and crowded visual layers.
That is why dynamic driving perception matters. It does more than capture objects. It interprets changing context and adjusts detection behavior in real time.
In city environments, reliable detection depends on how optical systems, sensor switches, lighting logic, and vehicle response work together under pressure.
This makes the topic highly relevant across the broader mobility supply chain, especially where exterior systems, smart lighting, wheels, tires, and sensing interfaces shape safety and efficiency together.
AEVS follows this intersection closely. Its view of vehicle aesthetics and dynamic driving perception links design quality with optical accuracy, compliance, and practical road performance.
Why the same city road can create different detection demands
Not every urban route challenges perception in the same way. A wide boulevard at dusk behaves differently from a narrow delivery lane in rain.
The useful judgment is not whether a system detects objects in general. It is whether dynamic driving perception maintains confidence when the environment keeps shifting.
In practice, detection quality changes with headlight reflections, stop-and-go density, wheel spray, curbside occlusion, and mixed road users crossing from unpredictable angles.
For NEV platforms, this becomes even more sensitive. Heavier vehicle mass, instant torque, low-noise cabins, and aerodynamic priorities all influence how exterior systems support perception.
A vehicle may carry advanced cameras and sensors, yet still underperform if lens contamination, thermal drift, blind-spot geometry, or lighting mismatch are ignored.
The more useful evaluation starts with conditions
- Traffic density determines whether tracking stability matters more than long-range visibility.
- Weather and road spray affect optical clarity and the response timing of auto sensor switches.
- Lighting contrast decides whether anti-glare masking and matrix LED control improve object separation.
- Wheel, tire, and body design influence splash, vibration, and airflow around perception hardware.
At busy intersections, separation matters more than raw range
Intersections are where dynamic driving perception proves whether it can prioritize. The issue is rarely distance alone. It is object separation under clutter.
Pedestrians, scooters, turning vehicles, signal poles, reflective signs, and storefront lighting all compete for attention within a compressed field.
Here, smart optical perception must reduce false overlap. Detection quality improves when systems distinguish a crossing cyclist from background reflections or parked vehicles.
LED headlight assemblies play a practical role in this scene. Precise beam shaping can support forward recognition without creating unnecessary glare for oncoming traffic.
A common mistake is focusing only on sensor resolution. In real junctions, timing, masking logic, and blind-spot closure are usually the deciding factors.
What to check in this scene
Look at detection persistence during turns, not just straight-line recognition. Watch how quickly the system reclassifies partially hidden movement near curbs and islands.
In narrow streets and curbside lanes, blind spots become a design issue
Dense curbside environments create a different challenge. Delivery vans, temporary parking, open doors, and short stopping distances compress reaction windows.
In these streets, dynamic driving perception depends heavily on side coverage and low-speed prediction rather than high-speed range performance.
This is where auto sensor switches and body-network coordination become useful. Fast transitions between blind-spot monitoring, wiper activation, and headlight adaptation help stabilize awareness.
Exterior architecture also matters. Mirror geometry, wheel arch airflow, and sensor placement can either protect or compromise lateral visibility.
AEVS often frames this as a stitched decision problem. Exterior styling, optical logic, and compliance cannot be assessed as separate modules in crowded city use.
Rain, glare, and road spray expose hidden weaknesses
Bad weather does not simply lower visibility. It changes the quality of every signal entering the perception chain.
In rainy urban traffic, dynamic driving perception must handle windshield noise, water film, road reflections, and contamination around external sensing points.
This is where high-performance tires and wheel design affect more than comfort or efficiency. They influence spray dispersion and the cleanliness of surrounding visual fields.
Low-drag wheels may improve range, yet airflow around brake zones and wheel housings also needs attention because it affects moisture behavior and debris movement.
Headlight thermal management matters here as well. If optical output and beam precision drift under prolonged wet conditions, recognition quality can drop before the driver notices.
A frequent misjudgment is testing dynamic driving perception only in clean daytime conditions. Urban detection rarely stays that stable for long.
A more practical validation approach
- Compare dry and wet detection confidence, not only object count.
- Review spray patterns around wheels, arches, and lower body sensors.
- Confirm the timing link between rain sensing, wipers, and lighting response.
- Check compliance implications under ECE or DOT lighting behavior limits.
Night traffic needs optical intelligence, not just brighter output
Nighttime city roads are full of misleading brightness. Shop signs, wet asphalt, opposing beams, and reflective surfaces can distort object contrast.
Dynamic driving perception improves detection here when lighting systems participate actively in interpretation rather than acting as fixed illumination tools.
Million-pixel matrix LED systems show their value in these conditions. They can mask glare, guide road edges, and preserve target visibility in mixed traffic.
The important point is balance. Overly aggressive illumination can increase reflections, while conservative lighting may hide vulnerable road users near crosswalk entries.
That is why AEVS emphasizes the link between thermal models, optical algorithms, and real road behavior. Urban night detection is an operational calibration issue.
Common errors appear when similar scenes are treated as identical
One recurring problem is assuming all low-speed city traffic needs the same perception setup. It does not.
A school-zone morning, a downtown evening rush, and a wet underground ramp share congestion, but their detection priorities differ sharply.
Another weak point is evaluating parts in isolation. A sensor may look capable on paper, while the surrounding wheel spray, body contour, or headlight behavior reduces actual performance.
Cost is also misread when only purchase price is compared. Maintenance access, cleaning frequency, replacement intervals, and software recalibration affect real deployment value.
In practical reviews, dynamic driving perception should be judged as a coordinated exterior and vision ecosystem rather than a single hardware feature.
How to adapt dynamic driving perception before wider rollout
A useful next step is to map the urban conditions that appear most often, then rank which ones create the highest detection uncertainty.
From there, compare how lighting, sensing, tire behavior, and body design interact in those exact conditions instead of using generic city labels.
- Define scene groups by glare, spray, occlusion, and traffic mixing level.
- Set evaluation criteria for reclassification speed, blind-spot closure, and detection confidence decay.
- Check whether exterior components support perception or introduce noise through vibration, contamination, or airflow.
- Review lifecycle factors, including cleaning, recalibration, software updates, and regulatory fit.
When dynamic driving perception is matched to real urban scenes, detection improves in ways that are measurable, safer, and easier to sustain across evolving NEV platforms.
That is usually the more reliable path: start with scene differences, confirm system interaction, and build adaptation standards before scaling decisions further.