
Industry Portal
Related News
- 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs
How Automotive mm Wave Sensors Work and Which ADAS Functions They Support
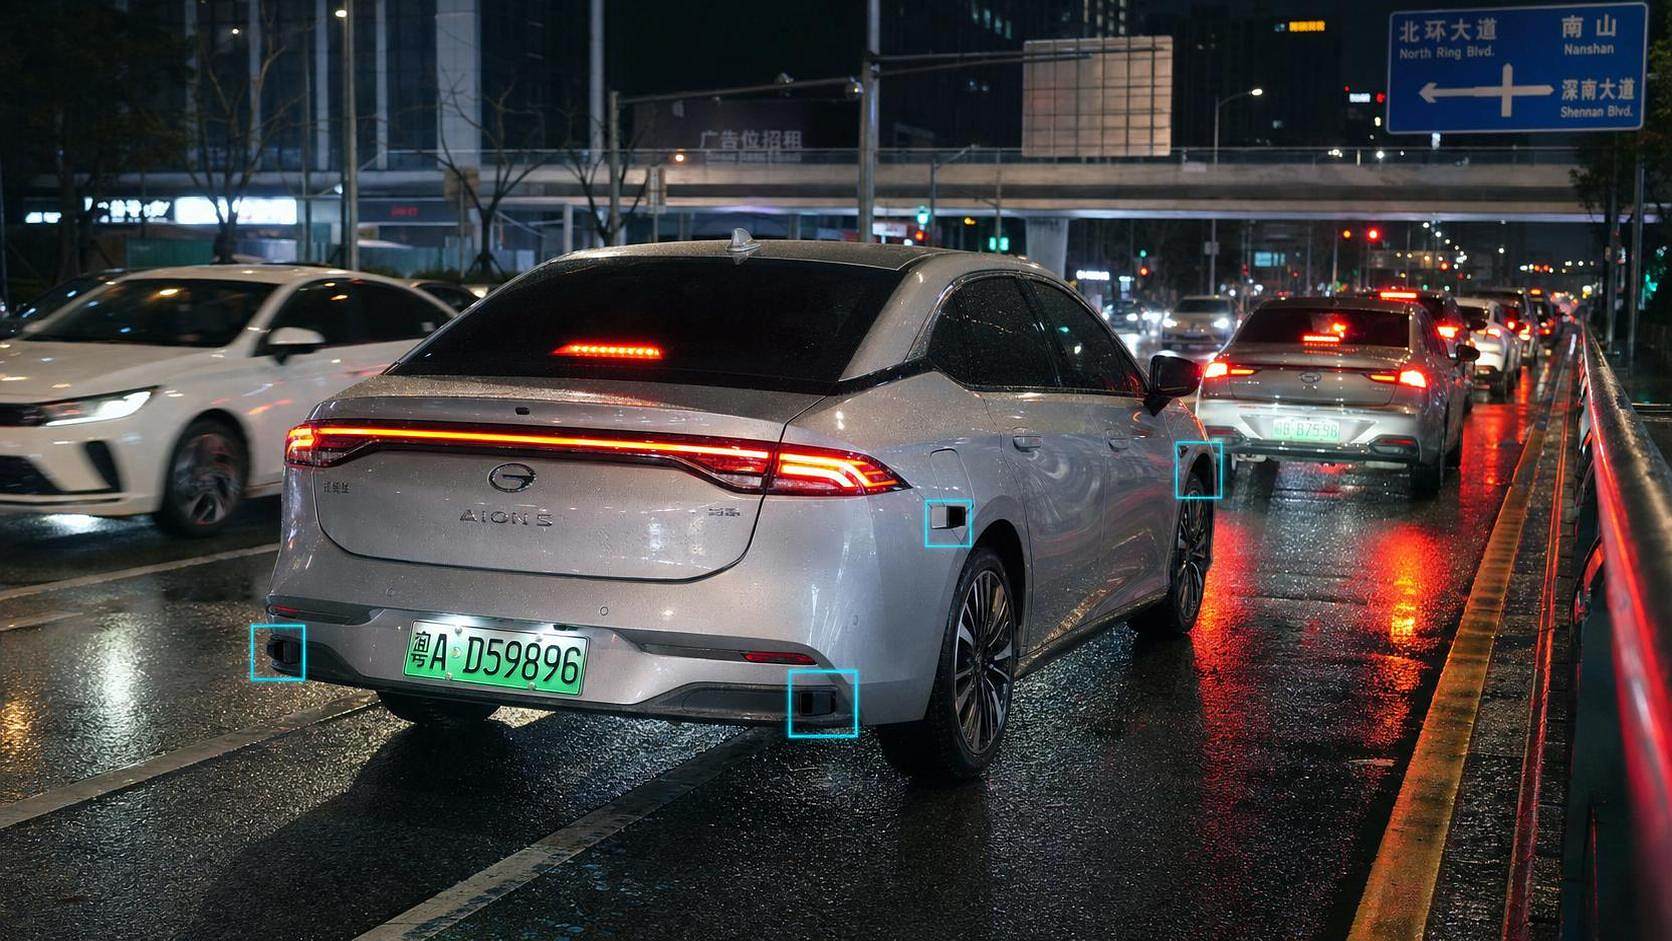
Why are automotive mm wave sensors getting so much attention?
Automotive mm wave sensors have moved from niche hardware to a core layer of vehicle perception. That shift matters because ADAS now depends on stable sensing across weather, lighting, and traffic complexity.
In simple terms, these sensors send high-frequency radio waves, receive reflections, and calculate distance, speed, and direction from returning signals. The result is fast object detection that cameras alone cannot always guarantee.
This is especially relevant in rain, fog, dust, and night driving. A camera may lose contrast. A lidar unit may face cost pressure. Automotive mm wave sensors usually keep working with fewer visibility penalties.
That is one reason they fit naturally into the broader exterior intelligence landscape covered by AEVS. Smart headlights, sensor switches, wheel aerodynamics, and body integration now influence how perception systems perform in real vehicles.
For NEV platforms, the topic goes beyond safety. Sensor packaging, thermal load, fascia materials, and aerodynamic surfaces all affect efficiency, styling, and function. That makes automotive mm wave sensors both an electronics issue and an exterior engineering issue.
How do automotive mm wave sensors actually work on a vehicle?
Most automotive mm wave sensors operate in the 24 GHz or 77 GHz bands, with 77 GHz now dominating advanced applications. The sensor transmits radio waves and listens for echoes from cars, guardrails, cyclists, or road edges.
From that echo, the system estimates three things quickly:
- How far away the object is
- How fast it is moving relative to the vehicle
- Where it sits within the sensor’s field of view
The speed measurement often comes from Doppler shift. The distance result usually comes from time and frequency analysis. More advanced chips also separate multiple targets in crowded traffic.
On the vehicle, placement matters. Front radars often support long-range detection. Corner radars watch adjacent lanes and cross traffic. Rear units support blind-spot and reversing functions.
A common misunderstanding is that radar works alone. In practice, automotive mm wave sensors are usually part of sensor fusion. They complement cameras, ultrasonic sensors, and sometimes lidar rather than replacing them.
That fusion logic is increasingly important for exterior system design. AEVS often tracks this intersection because headlamp architecture, bumper design, switch logic, and optical perception no longer evolve as separate topics.
Which ADAS functions do automotive mm wave sensors support most directly?
The most widely used ADAS features supported by automotive mm wave sensors are those that need reliable motion and range detection. Radar is particularly strong when the vehicle must react to moving targets in uncertain visibility.
The strongest fit usually includes:
- Adaptive cruise control
- Forward collision warning
- Automatic emergency braking support
- Blind-spot detection
- Rear cross-traffic alert
- Lane change assistance
- Exit warning in urban traffic
Some parking and low-speed maneuvering functions also use short-range radar. The value here is not just object presence. It is the ability to detect relative motion around corners or through poor weather.
To make those use cases easier to compare, the table below summarizes where automotive mm wave sensors contribute most clearly.
What stands out is the role of radar in motion-critical functions. Whenever the system must judge closing speed quickly, automotive mm wave sensors tend to be central.
Radar, camera, or lidar: which one answers which problem?
This is where many comparisons become too simple. There is no universal winner. The better question is which sensing method solves a specific driving task with acceptable cost, reliability, and integration effort.
Automotive mm wave sensors are strong at measuring distance and speed under poor visibility. Cameras are better at reading lane markings, traffic signs, and object appearance. Lidar can provide detailed 3D shape, but cost and packaging still matter.
In actual vehicle programs, the more common decision path looks like this:
- Use radar where robust detection is essential
- Use cameras where classification and lane context matter
- Add lidar when higher-resolution depth justifies the system cost
This blended approach aligns with broader exterior and vision engineering. For example, LED headlight systems and optical sensing must coexist physically and electronically, especially as front-end packaging becomes tighter on EV platforms.
AEVS follows these cross-domain tradeoffs closely because perception performance is increasingly linked to material choices, fascia design, aero targets, and compliance requirements such as ECE and DOT expectations.
What should be checked before judging sensor quality or integration value?
Looking only at range claims is not enough. A long quoted range may sound impressive, but integration quality depends on a wider set of technical and vehicle-level checks.
Useful review points include:
- Operating frequency and bandwidth
- Angular resolution in dense traffic
- Detection stability in rain or spray
- Interference resistance from nearby radars
- Fascia material compatibility and mounting angle
- Calibration effort across vehicle trims
- Software maturity for fusion and false alarm control
One frequent mistake is treating automotive mm wave sensors as plug-in modules. In reality, bumper paint thickness, emblem position, wheel spray patterns, and vibration paths can influence results.
That is why the subject belongs in a wider exterior systems discussion. A sensor may test well on a bench but behave differently after styling changes, aero refinements, or wheel and tire package updates on production vehicles.
Where do projects usually run into trouble?
The first issue is overconfidence in radar alone. Automotive mm wave sensors are reliable, but they still need good fusion logic to interpret stationary objects, road geometry, and mixed urban scenes.
The second issue is packaging drift. Styling teams may adjust front grilles, logos, or bumper layers late in development. Small changes can alter transmission loss or reflection behavior.
The third issue is performance expectation. A sensor chosen for highway ADAS may not automatically deliver ideal low-speed corner coverage. Long-range and short-range radar tasks often require different tuning priorities.
The fourth issue is lifecycle planning. Software updates, compliance checks, and replacement part quality all affect long-term function. This matters even more as aftermarket activity grows in premium wheels, lighting, and exterior modules.
A practical way to avoid misjudgment is to separate three questions early: what the sensor must detect, where it will be mounted, and how its data will be fused with other perception channels.
So what is the best next step when researching automotive mm wave sensors?
Start by mapping the target ADAS functions, not by collecting sensor brochures. That keeps the analysis tied to real use cases such as blind-spot monitoring, ACC, or rear cross-traffic alert.
Then compare automotive mm wave sensors through a structured lens: detection range, angular resolution, weather robustness, mounting constraints, fusion requirements, and compliance fit.
It also helps to follow adjacent systems. Headlamp architecture, auto sensor switches, bumper materials, wheel spray behavior, and EV aerodynamic targets can all influence perception reliability more than early desktop reviews suggest.
That broader perspective is where AEVS adds value as an intelligence source. The platform connects radar sensing with exterior lightweighting, optical perception, regulatory signals, and evolving NEV integration priorities.
In short, automotive mm wave sensors work by turning radio reflections into distance and motion data, and they support many of today’s most important ADAS functions. The smarter next move is to judge them in context: function, vehicle package, software fusion, and long-term system fit.
A solid review checklist, a realistic comparison table, and close attention to exterior integration will usually reveal more than headline specifications alone.