
Industry Portal
Related News
- 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs - 00
0000-00
Rain Sensing Systems Calibration: Methods for Reliable Detection and Testing - 00
0000-00
How to Evaluate a Photoelectric Sensing Supplier for Industrial Automation Projects
How Automotive Vehicle Perception Systems Fuse Cameras, Radar, and LiDAR for ADAS
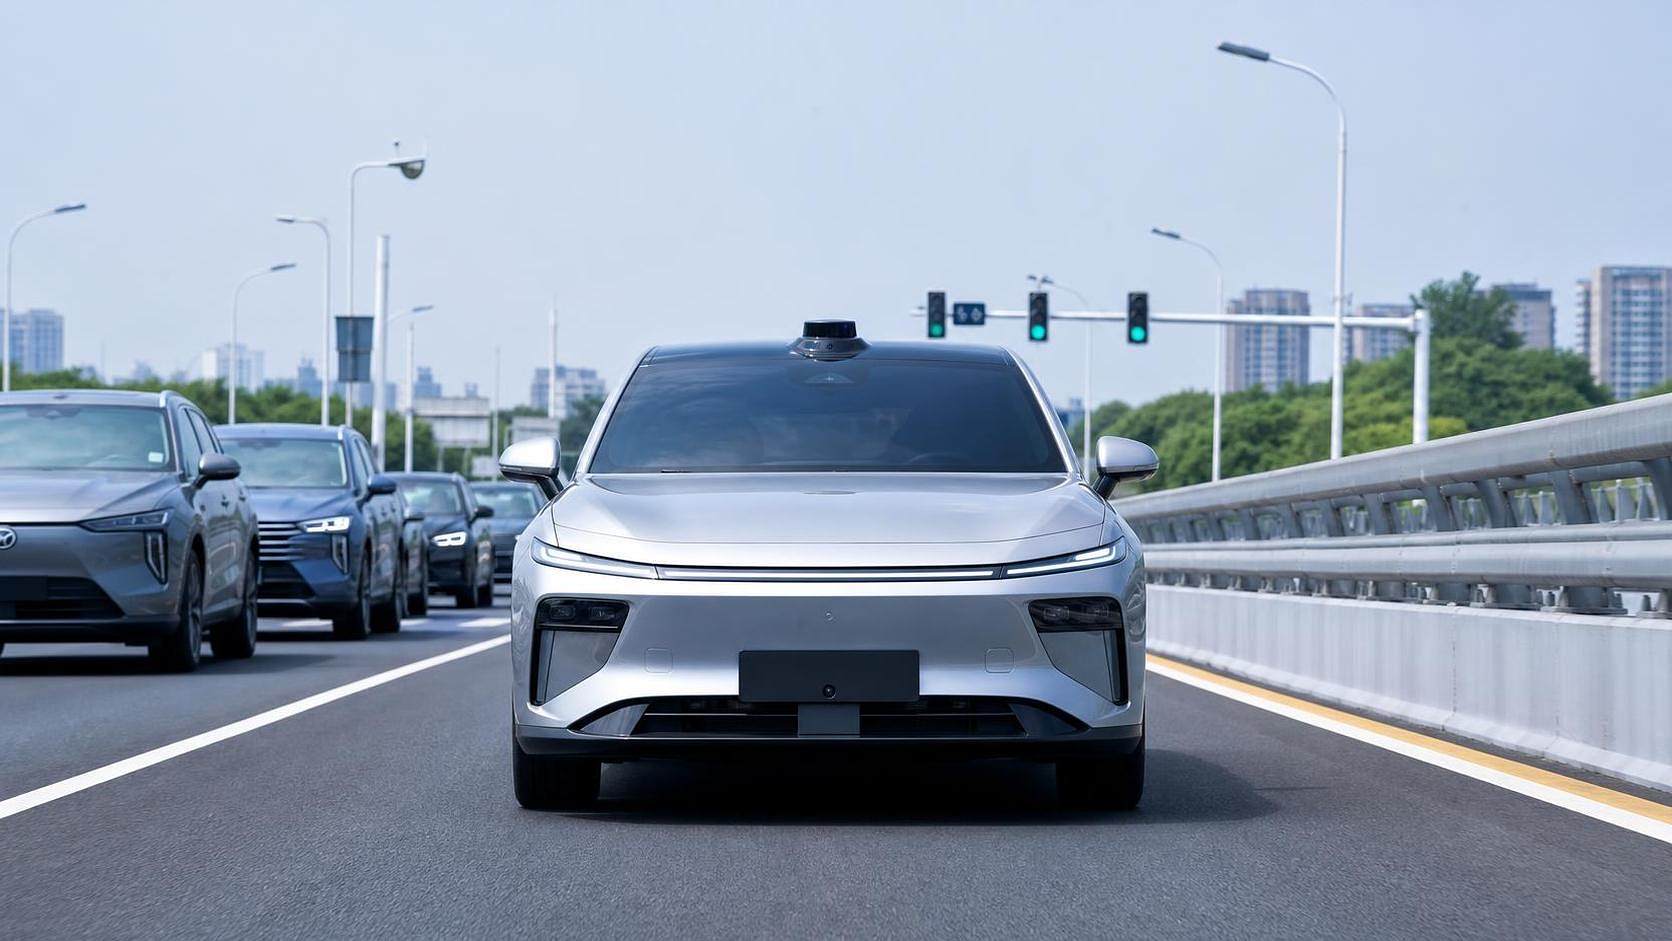
How Automotive Vehicle Perception Systems Fuse Cameras, Radar, and LiDAR for ADAS
Vehicle perception systems automotive platforms increasingly depend on a simple but demanding principle: no single sensor sees the road well enough, often enough, to support advanced driver-assistance systems on its own. A forward camera can recognize lane markings, traffic lights, and vulnerable road users. Radar can estimate relative velocity through rain, darkness, and some visual obscurants. LiDAR can provide highly useful geometric structure where camera depth estimation or radar angular resolution becomes uncertain.
The difficult part is not mounting three sensor types on the vehicle. The difficult part is deciding what the vehicle should believe when those sensors disagree. A wet road may create camera glare, a guardrail may generate persistent radar reflections, and airborne dust can reduce LiDAR returns. In production ADAS, fusion is therefore not just an algorithmic feature. It is an engineering discipline spanning sensor placement, optical and electromagnetic design, time synchronization, diagnostics, functional safety, and validation.
For vehicles moving toward higher levels of assisted driving, perception quality also has direct consequences for exterior-system design. Windshield optics, camera washer coverage, radar radomes, headlamp packaging, bumper materials, wheel-spray behavior, and thermal paths all influence the inputs received by the automated driving stack. The “sensor” is never entirely separate from the vehicle around it.
Why Sensor Fusion Is Necessary in Real Driving Conditions
Cameras remain indispensable because they capture semantic information. They can distinguish a traffic signal from a reflective sign, identify lane boundaries, interpret road text, and classify many object types. Their limitation is equally familiar to anyone who has reviewed difficult road recordings: a camera is sensitive to illumination. Low sun, tunnel transitions, headlamp flare, lens contamination, fog, snow, and low-contrast clothing can all degrade usable image evidence.
Automotive radar addresses a different part of the problem. It is particularly valuable for relative range and radial velocity, which matters when a vehicle is approaching a slower object at highway speed. Radar performance can remain useful in conditions where visible-light cameras struggle. Yet radar does not “see” a scene in the way a human driver does. Multipath reflections around large vehicles, metallic roadside infrastructure, and complex urban geometry can complicate interpretation. A radar return may be physically real but semantically ambiguous.
LiDAR adds distance-resolved three-dimensional information. Depending on the architecture and operating conditions, it can help separate objects that overlap in a two-dimensional image and improve geometric understanding of free space, road edges, or obstacles. It is not immune to environmental limitations, however. Rain, snow, fog, contamination, and certain reflective surfaces can affect returns. Cost, cleaning strategy, field of view, packaging, and long-term optical durability must also be assessed as vehicle-level issues rather than treated as a sensor supplier’s isolated problem.
The practical value of fusion is redundancy with diversity. Three cameras mounted behind the same dirty windshield are redundant in coverage, but not necessarily diverse in failure mode. A camera, radar, and LiDAR combination can fail differently and provide different evidence. That distinction is central to robust ADAS design.
The Three Main Levels of Fusion
Fusion is often described as early, feature-level, or late fusion. In practice, production systems may combine these approaches rather than choosing only one.
Object-level fusion is common because it creates manageable interfaces between sensor domains. A camera pipeline may report a pedestrian candidate, radar may report an approaching target with relative speed, and LiDAR may provide a stable three-dimensional cluster. The fusion module determines whether these observations represent one object, several objects, or an uncertain situation requiring conservative behavior.
The risk is that upstream perception errors can become difficult to recover. If a sensor fails to create an object track at all, later-stage fusion has little to work with. This is why newer architectures increasingly use richer feature representations or occupancy-based perception alongside conventional object lists. Rather than asking only “what object is this?”, the system can estimate where physical space is occupied, uncertain, or traversable.
Time, Position, and Confidence: The Less Visible Requirements
A fusion system can appear accurate in a static laboratory scene and still fail in motion if timestamps are unreliable. At road speed, even a modest timing mismatch shifts the apparent position of moving objects. Camera frames, radar detections, LiDAR scans, vehicle yaw rate, wheel-speed signals, and steering angle data must be referenced to a coherent time base. Motion compensation is then needed because the vehicle and surrounding objects move while each sensor is collecting information.
Spatial calibration is equally unforgiving. The system needs accurate knowledge of each sensor’s orientation and location relative to the vehicle coordinate system. A minor camera bracket shift after a repair, bumper replacement, windshield change, or suspension-related body alignment issue can affect sensor alignment. This is not merely a workshop concern. It should influence the design of mounting features, recalibration procedures, diagnostic records, and service instructions from the beginning.
Good fusion does not blindly average sensor outputs. It weighs them according to uncertainty. A camera may carry less confidence in intense glare; radar confidence may be reduced in a known multipath environment; LiDAR confidence may decline when the optical window is contaminated. The perception stack needs explicit mechanisms for quality estimation, sensor health monitoring, and plausibility checking. Without them, “more sensors” can simply mean more contradictory inputs.
Exterior Integration Can Decide Whether Fusion Works
Sensor fusion is often discussed in software terms, but exterior engineers see the consequences of physical integration early. A radar placed behind a painted fascia depends on material selection, thickness control, geometry, coating formulation, and manufacturing consistency. A camera behind glass depends on local optical quality, defogging performance, contamination management, and the behavior of the windshield under sunlight and temperature cycling. LiDAR windows introduce their own optical, cleaning, heating, and styling constraints.
Headlamp systems deserve particular attention. Matrix LED assemblies are evolving beyond illumination toward adaptive beam control and road-guidance functions. Their thermal design, optical output, and packaging must coexist with forward-looking cameras and other perception hardware. Stray light, reflections from glossy trim, and thermal loading around sensor housings are not always visible in CAD reviews, but they can emerge during night validation. This is one reason vehicle exterior, lighting, and automated-driving teams should not work as separate packaging silos.
Road spray is another underestimated interaction. Tire tread design, wheel architecture, wheelhouse airflow, and body-side aerodynamics affect how water and debris move around the vehicle. In wet conditions, sensor cleaning coverage and recovery time may matter more than nominal detection range. Low-drag wheel designs and underbody airflow work are valuable for electric-vehicle efficiency, but the final assessment should include their influence on camera and sensor contamination patterns.
This broader viewpoint is increasingly relevant to exterior and vision-system intelligence work: perception quality is created by optical algorithms and electronic control units, but also by glass, coatings, thermal paths, wheel spray, fascia materials, and the serviceability of the finished vehicle.
Safety and Standards: What a Technical Review Should Actually Ask
No single standard certifies that a sensor-fusion system is universally “safe.” Safety must be argued through the intended function, operational design domain, system architecture, test evidence, and residual-risk treatment. ISO 26262 is relevant to functional safety for electrical and electronic systems, while ISO 21448, commonly called SOTIF, addresses hazards that can arise even when systems operate as designed but face performance limitations or foreseeable misuse. Cybersecurity engineering, including the principles addressed in ISO/SAE 21434, also matters because a compromised sensor interface or software update process can affect perception integrity.
Regulatory expectations differ by market and by ADAS function. UNECE regulations, including those governing certain automated lane-keeping functions, may apply where the vehicle is type-approved under the relevant framework. Other markets use different regulatory pathways. It is risky to treat a general reference to ECE, DOT, or any regional regime as proof that a perception architecture is acceptable. The applicable vehicle category, feature scope, software version, deployment market, and current legal requirements must be checked individually.
A disciplined review should ask more concrete questions:
- What conditions define the system’s operational design domain, and how does it recognize when it is leaving that domain?
- Which sensor faults are detected, including blockage, misalignment, degraded signal quality, and communication loss?
- How are conflicting observations handled when braking, steering, or warning decisions are time-critical?
- What is the fallback behavior when confidence falls below an acceptable threshold?
- How are sensor replacement, windshield repair, bumper repair, and calibration controlled over the vehicle life cycle?
Validation Must Target the Awkward Cases
Clear-weather testing on well-marked roads is necessary, but it does not expose the hardest fusion problems. The awkward cases are more revealing: a pedestrian partly hidden by a parked vehicle; a motorcycle entering from a shadowed side street; a stationary object near a metal barrier; rainwater on a camera lens; low sun after a tunnel exit; lane markings worn away at a merge; or a trailer whose shape challenges object association.
Simulation, proving-ground testing, public-road data collection, and controlled sensor-fault injection each answer different questions. Simulation can efficiently explore permutations that are difficult to encounter repeatedly. Physical testing reveals real optical contamination, vibration, thermal behavior, radar interference, and installation variation. Neither approach replaces the other. A mature validation plan also traces scenarios back to safety goals and records what evidence supports the claimed behavior.
The right question is not whether camera, radar, and LiDAR fusion is inherently superior. It is whether the selected architecture can maintain a justified level of perception performance across its stated operating conditions, including degradation and maintenance realities. The most convincing systems are usually not the ones with the longest sensor list. They are the ones whose sensor diversity, exterior integration, uncertainty handling, and validation evidence fit together without leaving obvious blind spots.