
Industry Portal
Related News
- 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems - 00
0000-00
Choosing Low Rolling Resistance Tires for Longer Mileage and Lower Fleet Fuel Costs
Can smart optical perception reduce sensor blind spots?
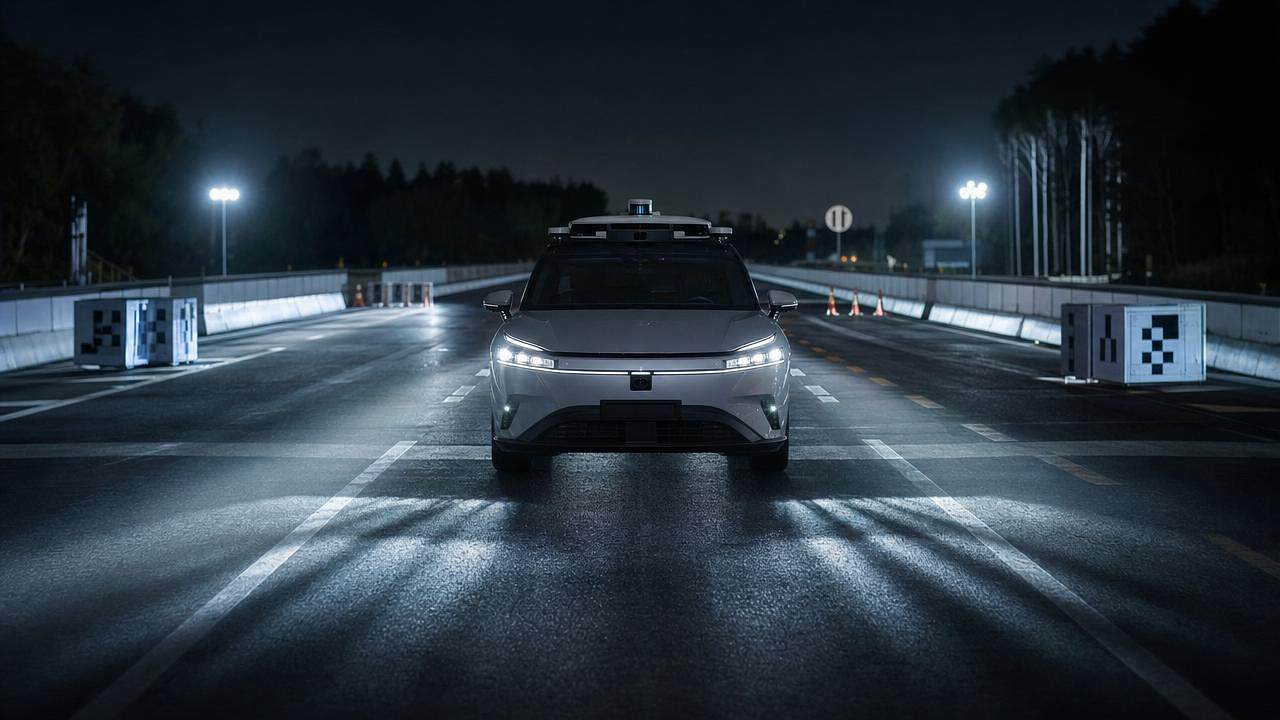
Can Smart Optical Perception Reduce Sensor Blind Spots?
As vehicles rely on more cameras, LiDAR, radar, and photoelectric triggers, blind spots have become a systems-engineering problem.
The answer is yes: smart optical perception can reduce sensor blind spots, but only when optics, algorithms, lighting, and validation work together.
For technical evaluators, the real question is not whether the technology is advanced, but whether its performance is measurable and repeatable.
The practical answer: reduction is possible, elimination is not
Smart optical perception extends vehicle awareness beyond conventional camera sight lines by combining adaptive illumination, sensor fusion, and environmental interpretation.
However, no optical system can fully eliminate occlusion, contamination, extreme glare, or physics-based limitations in every driving scenario.
A credible system should therefore be assessed by how much it reduces blind-spot probability under defined operating conditions.
This distinction matters because marketing language often suggests complete visibility, while engineering reality depends on coverage, latency, redundancy, and confidence scoring.
Technical evaluators should look for quantified improvements in detection distance, object classification accuracy, false positives, and missed detections.
The strongest smart optical perception architectures do not rely on a single sensor, but coordinate cameras, LiDAR, radar, lighting, and body sensors.
Where blind spots actually come from in modern vehicles
Blind spots are not limited to mirror geometry or driver visibility; they now include perception gaps in automated sensing systems.
Camera blind spots can occur near pillars, bumper edges, high-contrast shadows, dirty lenses, or scenes with insufficient illumination.
LiDAR may struggle with dark, absorptive, transparent, or highly reflective surfaces, depending on wavelength, range, and receiver sensitivity.
Radar performs well in poor weather, but it may lack the angular resolution needed for precise object shape recognition.
Photoelectric switches and rain-light sensors offer fast triggering, yet their local field of view limits broader scene understanding.
Smart optical perception reduces these weaknesses by using complementary sensing, adaptive exposure, active lighting, and algorithmic confidence management.
Why optical intelligence matters more as vehicle design changes
New energy vehicles often use smoother bodies, lower hoods, flush surfaces, and reduced aerodynamic drag features that affect sensor placement.
Design choices that improve range or styling can create complex reflections, hidden zones, or packaging constraints around exterior sensors.
Large panoramic roofs, illuminated grilles, slim headlamps, and low-drag wheels all influence available space for perception hardware.
This makes smart optical perception valuable because it treats exterior design and sensing performance as one integrated engineering problem.
The goal is not simply adding more sensors, but positioning and controlling them intelligently within the vehicle exterior architecture.
For evaluators, this means checking whether perception performance survives the real constraints of styling, aerodynamics, manufacturability, and cost.
How adaptive lighting helps reduce optical blind spots
LED headlight assemblies have evolved from illumination devices into active perception partners for cameras and ADAS functions.
Matrix LED and pixel lighting systems can shape light distribution, reduce glare, and improve visibility in selected road zones.
When coordinated with cameras, adaptive lighting can enhance contrast around pedestrians, lane boundaries, curbs, and roadside obstacles.
This is particularly useful at night, where passive camera performance depends heavily on available light and scene contrast.
Anti-glare masking also matters because excessive light can blind other road users and degrade visual perception through reflection.
A strong system should prove that lighting control improves detection without creating regulatory, thermal, or driver-distraction problems.
Sensor fusion is the core, not an optional feature
Smart optical perception becomes most effective when optical data is fused with radar, LiDAR, ultrasonic, and inertial information.
Fusion enables the system to compare signals, compensate for weak channels, and raise confidence when multiple sensors agree.
For example, radar may detect motion in rain while a camera confirms object class when visibility improves.
LiDAR may provide precise depth, while optical cameras add semantic information such as lane markings or pedestrian posture.
Good fusion design also recognizes disagreement, rather than forcing uncertain data into a single overconfident decision.
Technical evaluators should ask whether fusion happens early, late, or through hybrid architectures, because each approach affects latency.
The key performance metrics evaluators should demand
The first metric is detection accuracy across object classes, including vehicles, pedestrians, cyclists, animals, barriers, and road debris.
Accuracy should be segmented by distance, angle, speed, lighting condition, road surface, weather, and object reflectivity.
The second metric is latency, because delayed detection can erase the safety benefit of a wider perception field.
Evaluators should review end-to-end timing from photon capture or radar return to ADAS decision and actuator command.
The third metric is false-positive behavior, especially in dense urban scenes with signs, reflections, wet roads, and complex lighting.
A system that constantly warns or brakes unnecessarily may reduce driver trust and create secondary safety risks.
The fourth metric is missed-detection rate in edge cases, because rare failures often define real-world safety perception.
Useful validation reports should include corner cases, not only clean demonstrations on well-marked roads and controlled tracks.
Adverse-weather reliability separates robust systems from prototypes
Rain, fog, snow, dust, road spray, and lens contamination are among the hardest challenges for optical perception.
Smart optical perception can reduce weather-related blind spots through sensor cleaning, heating, hydrophobic coatings, and adaptive algorithm thresholds.
Lighting systems may also adjust beam patterns to reduce backscatter in fog or heavy rain conditions.
However, optical channels will still degrade, so the system must know when confidence has fallen below safe limits.
This is where radar redundancy, diagnostics, and graceful degradation become essential parts of a credible perception architecture.
Evaluators should request performance curves under controlled contamination levels, not just qualitative claims about all-weather capability.
Anti-glare control is both a safety and compliance issue
Glare affects two sides of perception: it can obscure the vehicle’s own sensors and disturb other road users.
Advanced optical systems must balance illumination strength with precise masking, beam steering, and regulatory compliance requirements.
ECE and DOT expectations may differ in beam patterns, adaptive driving beam approval, and testing procedures.
A technically mature solution should document how its light distribution supports perception while remaining compliant in target markets.
Thermal management is also important because high-output LEDs and projector modules can shift performance under heat stress.
If optical performance changes after prolonged operation, the system may create inconsistent detection reliability during long night drives.
Placement and packaging can decide whether the concept works
Even the best algorithms cannot fully compensate for poor sensor placement or compromised exterior packaging.
Cameras mounted too low may suffer from splash and dirt, while high placements may miss near-field obstacles.
Side sensors need enough angular coverage to detect vehicles, cyclists, and pedestrians approaching from oblique directions.
Headlamp-integrated sensing can be efficient, but it must address vibration, heat, repairability, and optical contamination.
Wheel, bumper, mirror, grille, and roofline designs should be evaluated as part of the perception system boundary.
For NEV platforms, packaging reviews should also consider aerodynamic drag, cooling paths, styling surfaces, and service accessibility.
What a credible validation program should include
A credible evaluation begins with an operational design domain that defines speed, road type, weather, and lighting assumptions.
Without a clear ODD, blind-spot reduction claims become difficult to compare across suppliers or vehicle programs.
Testing should combine simulation, hardware-in-the-loop, proving-ground scenarios, public-road data, and controlled laboratory measurements.
Simulation helps scale rare events, while physical testing reveals contamination, glare, vibration, and thermal effects.
Data should include near-field cut-in cases, junction crossings, reversing scenarios, curved roads, and roadside occlusions.
Evaluators should also examine how software updates are validated, because perception behavior can change after deployment.
Common failure modes that buyers should not ignore
One common failure mode is overdependence on camera confidence in scenes with poor contrast or strong backlighting.
Another is insufficient synchronization between sensors, causing object position errors when targets move quickly across fields of view.
Lens contamination detection may also be weak, allowing the system to continue operating with degraded optical input.
Some systems perform well in forward perception but remain vulnerable in lateral, rear, or close-range blind zones.
There may also be mismatch between supplier benchmark data and the final vehicle installation environment.
Technical buyers should verify performance after integration, not only at component level or on supplier demonstration vehicles.
How smart optical perception connects with ADAS safety logic
Reducing blind spots only matters if perception results are translated into reliable ADAS decisions and driver assistance actions.
The system must feed lane change assist, automatic emergency braking, adaptive lighting, parking assist, and blind-spot monitoring logic.
Decision rules should reflect uncertainty, giving different responses to high-confidence threats and ambiguous observations.
Human-machine interface design also matters, because warnings must be timely, understandable, and not excessive.
If smart optical perception improves detection but creates confusing alerts, the safety benefit may not fully materialize.
Evaluators should therefore review perception output quality, decision thresholds, warning strategy, and fail-safe behavior together.
Cost, complexity, and maintainability need realistic assessment
Adding optical intelligence can increase sensor count, computing load, calibration effort, thermal requirements, and repair complexity.
The business case is strongest when the same hardware supports multiple functions, such as lighting, sensing, and driver assistance.
For example, matrix headlights can improve visibility while supporting road projection, anti-glare behavior, and perception enhancement.
Integrated sensor switches can support rain detection, light activation, body control, and localized blind-spot monitoring.
However, integration can also raise replacement costs after minor collisions or headlamp damage.
Technical evaluators should compare lifecycle value, warranty exposure, calibration requirements, and aftermarket service readiness.
Procurement questions that reveal technical maturity
Ask suppliers to define exactly which blind spots are reduced, under which scenarios, and by what measured percentage.
Request confusion matrices, latency budgets, weather degradation curves, and sensor confidence management documentation.
Ask whether the system has been validated on the target vehicle body, not only on a reference platform.
Review compliance evidence for lighting behavior, electromagnetic compatibility, environmental durability, and functional safety assumptions.
Check whether software updates require recalibration, regulatory retesting, or additional fleet data collection.
Finally, ask how the system detects its own degradation and communicates limitations to ADAS controllers or drivers.
Where the technology delivers the clearest value
Smart optical perception is especially valuable in night driving, urban intersections, lane changes, parking, and low-speed maneuvering.
It also supports premium NEV positioning, where lighting signature, safety perception, and intelligent exterior design influence buyer expectations.
Fleet and commercial vehicles may benefit from reduced collision risk, lower downtime, and improved driver awareness.
Luxury and high-performance vehicles can use advanced optics to combine aesthetics, safety, and differentiated driving experience.
The strongest applications are those where perception improvements are measurable and tied to specific ADAS functions.
Weak applications are those that add sensors without a clear problem definition, validation plan, or safety integration path.
Final judgment: smart optical perception reduces risk when engineered as a system
Smart optical perception can meaningfully reduce sensor blind spots, especially when adaptive lighting, fusion, placement, and diagnostics are aligned.
Its value should be judged through measurable safety performance, not through claims about intelligence or sensor quantity alone.
For technical evaluators, the most important evidence is scenario-based data across weather, lighting, contamination, and integration conditions.
A strong solution will show lower missed detections, controlled false positives, acceptable latency, and predictable degradation behavior.
It will also connect perception outputs to ADAS logic, exterior architecture, regulatory compliance, and maintainable vehicle design.
The conclusion is clear: smart optical perception cannot abolish every blind spot, but it can make them smaller, rarer, and better managed.