
Industry Portal
Related News
- 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems
Blind Spot Monitoring Sensors: Which Detection Range and Mounting Setup Work Best?
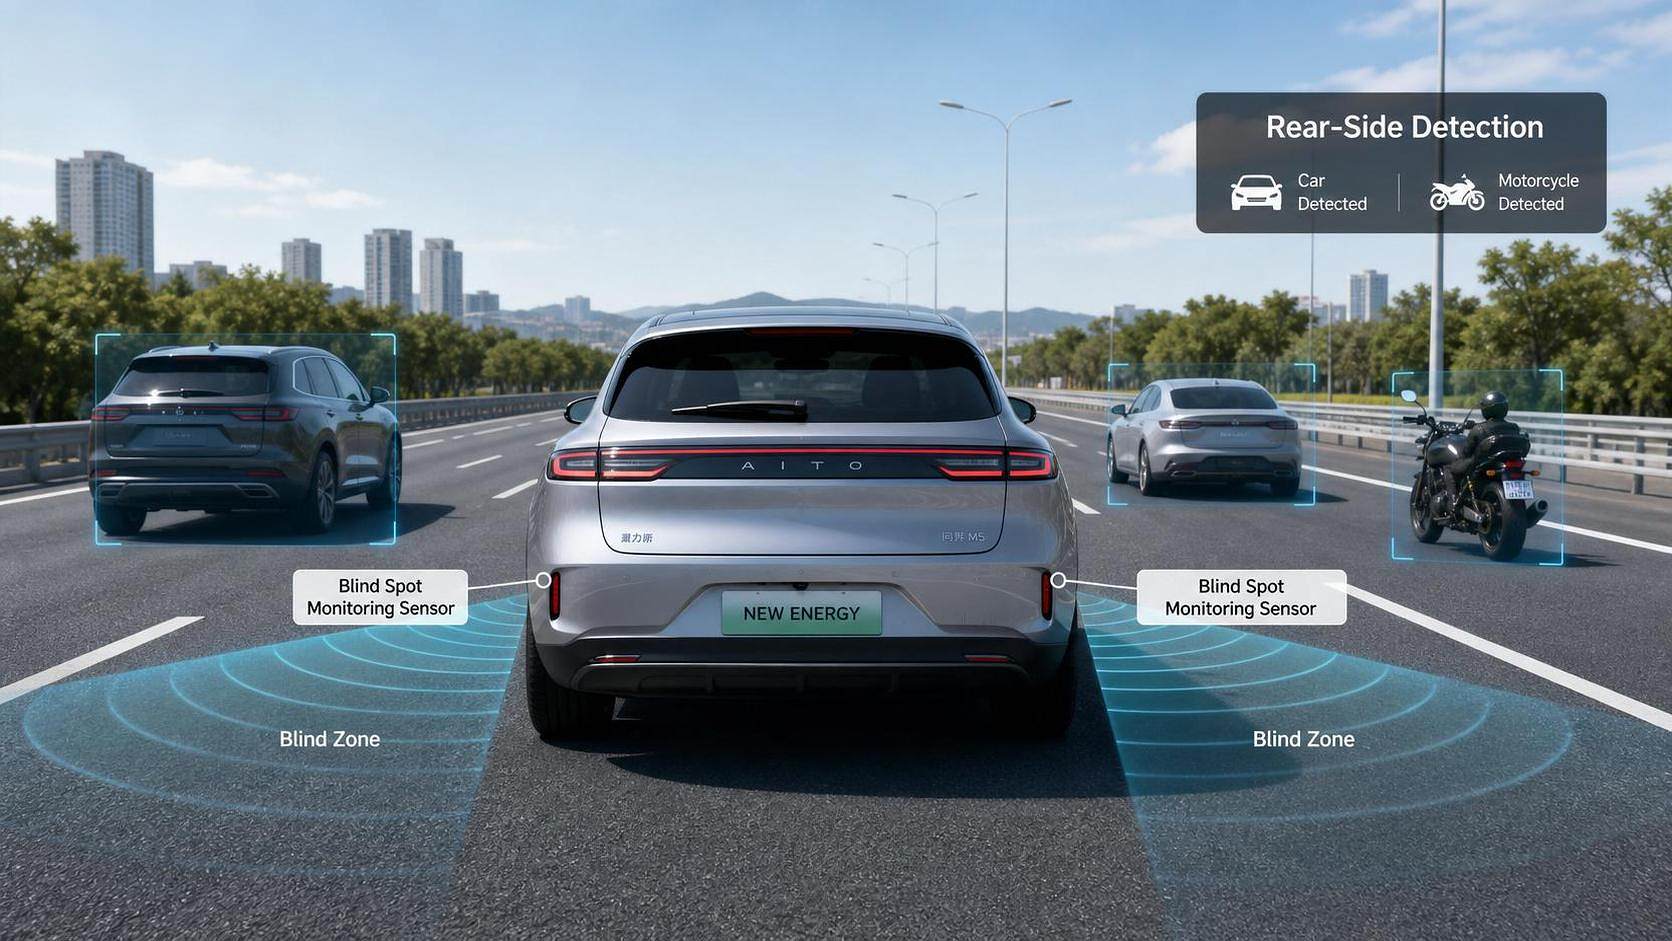
Blind Spot Monitoring Sensors: Which Detection Range and Mounting Setup Work Best?
Selecting the right blind spot monitoring sensors is no longer just a parts decision.
It shapes detection reliability, vehicle packaging, compliance, and safety performance.
For modern passenger cars and NEVs, that tradeoff is getting sharper.
Higher body complexity, tighter rear styling, and more driver assistance features all compete for space.
That is why blind spot monitoring sensors must be evaluated as part of a full sensing system.
The best solution is not always the longest range.
It is the range and mounting setup that match the vehicle geometry, target use case, and program cost.
Why detection range matters more than headline numbers
Many sourcing discussions start with a simple question.
How far should blind spot monitoring sensors detect?
In practice, the answer depends on the scenario, not marketing claims.
A sensor that sees too short may miss fast overtaking motorcycles.
A sensor that sees too wide or too far may generate unnecessary alerts.
That becomes a human factors problem, not just a hardware issue.
For most passenger vehicles, blind spot monitoring sensors typically work within short-to-medium radar zones.
The real goal is stable side-rear coverage during lane changes and merge events.
A practical range framework
A useful way to assess blind spot monitoring sensors is by functional range bands.
- Short range, around 3 to 10 meters, supports close blind zone coverage.
- Mid range, around 10 to 30 meters, improves adjacent-lane tracking.
- Extended rear-side range, up to 50 meters or more, helps with faster approach detection.
For urban vehicles, short and mid range often deliver the best value.
For highway-biased platforms, extended rear-side coverage becomes more important.
This is especially true for NEVs with quiet cabins, where warning quality is highly noticeable.
What detection range works best for common vehicle programs
There is no universal best range for blind spot monitoring sensors.
The best setup is linked to body type, traffic environment, and ADAS strategy.
From recent program changes, a clearer signal is emerging.
Teams increasingly prefer blind spot monitoring sensors with configurable range logic.
That flexibility helps reuse hardware across multiple trims and regional variants.
It also reduces redesign risk when bumper architecture changes late in development.
Which mounting setup works best in real vehicle integration
Mounting setup often decides whether blind spot monitoring sensors perform well in production.
Even a strong sensor can underperform if placement is compromised.
Most systems use rear corner mounting behind the bumper fascia.
That position gives a good angle toward adjacent lanes and rear-side approach paths.
Still, the best mounting setup depends on more than location alone.
Key mounting factors to review
- Bumper material and thickness can affect radar transmission quality.
- Sensor height influences detection of low vehicles, motorcycles, and road splash noise.
- Yaw angle controls adjacent-lane coverage and rear approach overlap.
- Bracket stiffness matters because vibration can disturb calibration stability.
- Nearby metal structures may create reflections or masked zones.
In actual business programs, packaging conflicts are common.
The radar corner shares space with lamps, wiring, trim, crash members, and styling features.
That means blind spot monitoring sensors should be selected with bracket and fascia constraints in mind.
A theoretically perfect sensor is not the right choice if it forces major tooling changes.
Best-practice mounting direction
For many programs, rear bumper corner mounting remains the most efficient option.
It usually offers the best compromise between field of view and manufacturability.
However, symmetry matters.
Left and right blind spot monitoring sensors should see similar environments.
If one side sits near a structural obstruction, false differences can appear in alert behavior.
How NEV architecture changes sensor selection
NEVs bring specific challenges to blind spot monitoring sensors.
They often have heavier bodies, different rear proportions, and stronger user expectations for smart safety.
Battery packaging can also change underbody and rear structural layouts.
As a result, standard mounting recipes do not always transfer cleanly.
This also means validation must be closer to real use conditions.
For example, silent cabins make warning quality more noticeable.
Drivers quickly detect unstable blind spot monitoring sensors through annoying false prompts.
Larger wheel designs and aerodynamic treatments may also influence radar reflections nearby.
That is why integration teams should evaluate the full exterior system, not just the sensor module.
Selection criteria that support better decisions
When comparing blind spot monitoring sensors, it helps to use a structured decision model.
This keeps the team focused on project outcomes, not isolated specifications.
- Define target scenarios first, including city merge, highway overtaking, and motorcycle interaction.
- Check whether blind spot monitoring sensors support adjustable zones and filtering logic.
- Review bumper and bracket constraints before locking a hardware shortlist.
- Validate against regional compliance expectations and platform safety strategy.
- Estimate calibration, tooling, and service impact across the full lifecycle.
A stronger signal in the market is the shift toward scalable sensor platforms.
Suppliers that support multiple detection profiles often reduce sourcing risk.
That matters when one vehicle family spans cost-sensitive and premium variants.
Common risks when blind spot monitoring sensors are misapplied
Several selection mistakes appear repeatedly across programs.
Most are avoidable when engineering and sourcing align early.
- Choosing blind spot monitoring sensors only by maximum range, without filtering quality review.
- Ignoring bumper material changes between trims or regional models.
- Accepting asymmetric mounting because packaging pressure appears manageable.
- Underestimating serviceability after minor rear-end repair events.
- Testing on limited traffic conditions and missing edge-case false alerts.
These risks usually surface late, when correction costs are highest.
That is why early cross-functional review is so valuable.
The most effective blind spot monitoring sensors are the ones that stay stable after design reality hits.
Final recommendation: balance range, placement, and validation
So, which detection range and mounting setup work best?
For most vehicle programs, blind spot monitoring sensors perform best with tuned mid-range coverage and rear corner mounting.
That setup usually balances coverage, packaging, cost, and alert quality.
Highway-focused or larger NEV platforms may need extended rear-side detection.
But even then, mounting quality and signal tuning matter more than raw distance alone.
The smartest decision is to match blind spot monitoring sensors to the real driving mission.
Review body geometry, bumper materials, target markets, and warning behavior together.
That approach leads to better safety performance and fewer late-stage surprises.
If a program team wants a reliable choice, start with real scenario mapping, then validate blind spot monitoring sensors in the intended mounting setup as early as possible.