
Industry Portal
Related News
- 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems
Blind-Spot Monitoring Problems: Common False Alerts, Calibration Issues, and Fixes
Why blind-spot monitoring problems rarely have a single cause
Blind-spot monitoring problems often look simple from the driver’s seat. A warning lamp flashes at the wrong time, stays silent during a lane change, or returns after a recent repair.
In practice, the fault path is usually wider. Radar alignment, bumper material, wheel offset, wiring stability, and software calibration can all shift system behavior.
That matters more in today’s NEV market. Vehicle exteriors now combine lightweight panels, tighter aerodynamic surfaces, and denser optical perception hardware in one package.
Within the AEVS view of exterior and vision systems, blind-spot monitoring sits at the intersection of body design, sensing logic, and real driving safety.
A sensor issue cannot be judged in isolation when tire stance, rear body repairs, and switch-network communication may also influence the result.
The more useful approach is to read blind-spot monitoring problems by scenario. False alerts, missed targets, and post-repair failures rarely share the same trigger conditions.
Actual service conditions change what should be checked first
A commuter crossover with a minor bumper repaint does not present the same diagnosis path as a performance EV with wider aftermarket wheels and low-profile tires.
One vehicle may suffer from radar reflection distortion. Another may show blind-spot monitoring problems because ride height, rear alignment, or wiring repairs changed sensor geometry.
This is where broad exterior intelligence becomes useful. AEVS regularly connects sensor performance with body architecture, lighting evolution, wheel airflow, and ground-contact dynamics.
That wider context helps explain why the same warning symptom can come from very different physical causes.
Looking at blind-spot monitoring problems this way prevents a common mistake: chasing the sensor first while ignoring the repair context around it.
When false alerts appear, the environment is often part of the diagnosis
False warnings are among the most frequent blind-spot monitoring problems. Yet they are not always proof of a failed radar unit.
In urban traffic, roadside barriers, guardrails, metal signs, and sharply curved lanes can create reflection patterns that confuse detection logic.
On some EV platforms, rear bumper packaging is tighter because designers are balancing drag reduction, lighting signatures, and clean exterior surfacing.
That makes sensor placement more sensitive to repaint thickness, filler work, or a bracket that is only slightly out of angle.
A more grounded check sequence usually helps:
- Inspect the bumper cover for metallic repair materials or uneven paint buildup.
- Check whether the radar face is blocked by dirt, ice film, or accessory installation.
- Review wheel and tire changes that may alter road spray or rear stance.
- Confirm that both sides report stable data under the same traffic conditions.
A frequent misread is to treat every rainy-day alert as normal system limitation. Sometimes the real issue is a marginal sensor angle that only shows up in poor conditions.
Missed detection cases need closer attention to geometry and motion
Blind-spot monitoring problems become more serious when the system fails to warn about a vehicle in the adjacent lane.
These cases deserve a different mindset. A clean scan tool result does not guarantee correct target coverage.
Missed detection often appears after body work, bumper replacement, suspension changes, or wheel fitment updates that move the vehicle away from original assumptions.
That is especially relevant on vehicles where lightweight wheel packages and high-load EV tires affect ride height and rear compression under acceleration.
If the detection zone shifts outward or downward, the system may still function but fail in the exact traffic window drivers rely on most.
What deserves extra verification
- Sensor bracket angle after quarter panel or bumper reinforcement repair.
- Rear ride-height consistency after tire size or suspension component replacement.
- Module coding compatibility after software flashing or control unit swap.
- Road-test repeatability with motorcycles, small cars, and fast-closing traffic.
The key judgment is not whether the system works once. It is whether it works across the lane-merge conditions that define real blind-spot monitoring safety.
Post-repair calibration is where many blind-spot monitoring problems are created
A large share of repeat visits comes from vehicles repaired correctly in appearance but not restored correctly in sensor reference.
Calibration errors are rarely dramatic. More often, they hide inside small deviations that pass visual inspection but shift radar performance enough to trigger blind-spot monitoring problems later.
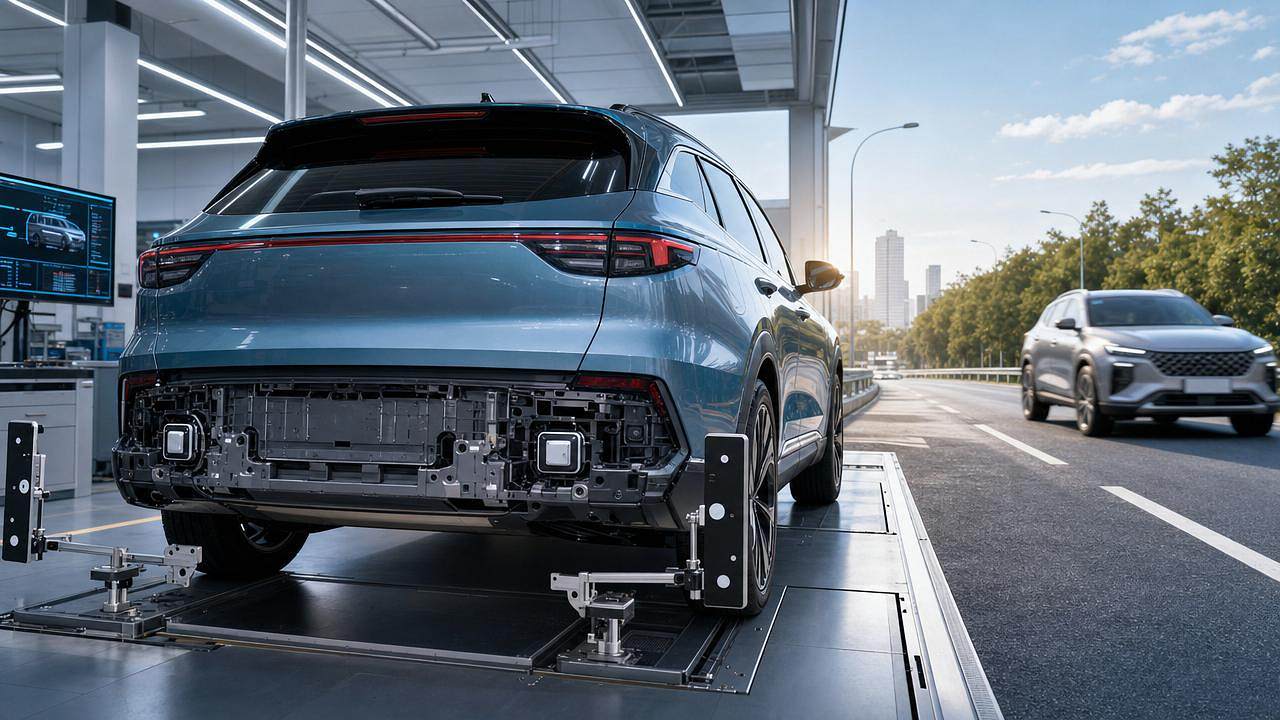
Rear bumper removal, sensor bracket replacement, harness disconnection, battery interruption, and software reset can all create a recalibration need.
What gets overlooked is that calibration quality depends on stable preconditions, not just the final scan tool step.
- Vehicle must sit at specified ride height and tire pressure.
- Target placement must match the OEM procedure exactly.
- Rear body dimensions must be confirmed before electronic calibration starts.
- Battery voltage stability matters during programming and sensor initialization.
In real workshops, the costly mistake is assuming calibration is a software event. For blind-spot monitoring, it is a geometry event first and a software event second.
Different operating scenarios call for different fixes
Not every repair path should end with the same parts replacement strategy. The right fix depends on how the blind-spot monitoring problem shows up over time.
This scenario-based approach reduces unnecessary module replacement and gives more reliable blind-spot monitoring results after service.
What is often overlooked during diagnosis
Several blind-spot monitoring problems stay unresolved because diagnosis is narrowed too early.
One overlooked factor is exterior modification. Decorative films, nonstandard bumper refinishing, and accessory lighting can affect radar transmission or create local interference.
Another is platform interaction. Auto sensor switches, lighting controls, and body network modules increasingly share data paths in smart vehicle architectures.
That means a blind-spot monitoring complaint may involve more than the radar itself. Power supply quality, communication faults, or recent electrical work can matter.
There is also a cost-side blind spot. Choosing the cheapest repair path without confirming calibration conditions often leads to repeat labor and weaker safety confidence.
- Do not judge only by parts specification.
- Do not assume similar body repairs create identical sensor outcomes.
- Do not skip dynamic testing after static calibration.
- Do not separate sensor diagnosis from wheel, tire, and body condition.
A practical path for reducing repeat blind-spot monitoring problems
The most dependable improvement usually starts with better repair sequencing rather than more parts.
Begin by mapping the complaint to its operating context. Was the blind-spot monitoring problem present before repair, after modification, or only in certain weather and traffic patterns?
Then confirm the physical baseline. Rear body dimensions, bracket condition, wheel-tire setup, harness integrity, and bumper material should be verified before recalibration.
Finally, validate the result under realistic motion, not only with fault codes cleared.
For organizations tracking exterior and vision-system quality, this discipline aligns with the broader AEVS logic: sensing performance is shaped by the full vehicle environment.
A useful next step is to document blind-spot monitoring cases by scenario, compare calibration outcomes across repair types, and define a repeatable checklist for body, wheel, and sensor conditions before sign-off.