
Industry Portal
Related News
- 00
0000-00
How to Specify Low-Pressure Casting Parts for Leak-Tight Automotive Housings - 00
0000-00
How to Specify an Electric Sunroof for Passenger Cars: Key Design and Safety Factors - 00
0000-00
North American Vehicle Aesthetics: Trends Shaping Exterior Design and Materials - 00
0000-00
ASPICE for Smart Optical Systems: Evidence Needed for Automotive Development - 00
0000-00
How to Select NVH Control Materials for Automotive Panels and Powertrain Systems
Automotive mm Wave Sensors Selection Guide: Range, FOV, Resolution, and Integration
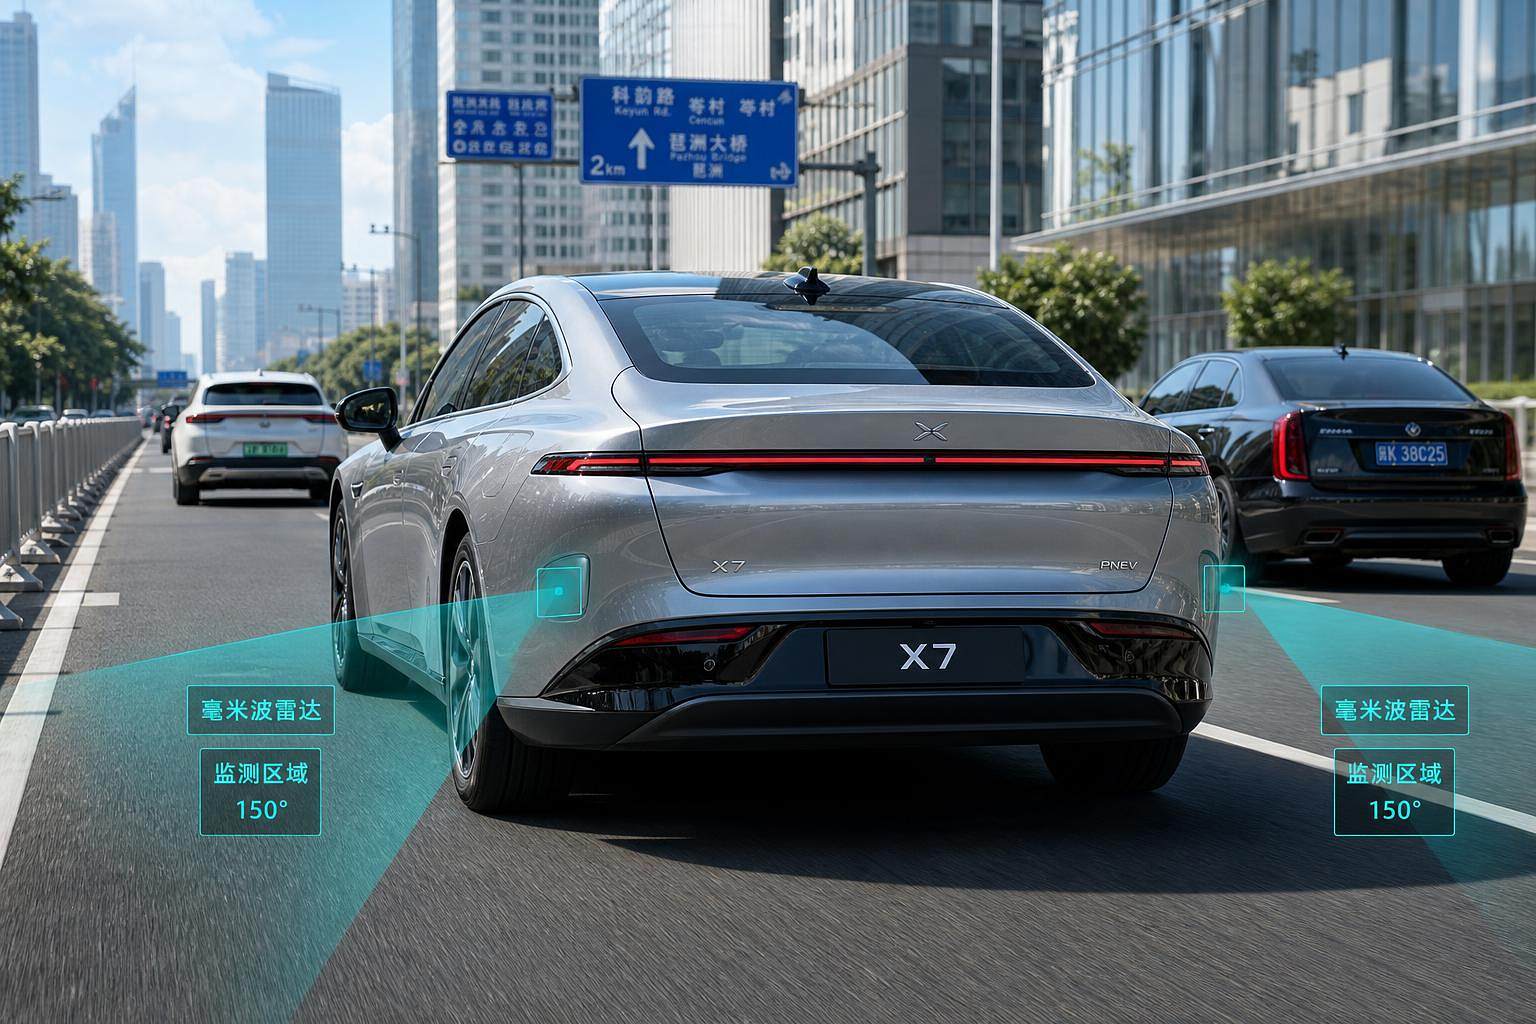
Selecting automotive mm wave sensors is no longer a narrow component decision. It shapes how a vehicle sees side traffic, manages blind zones, and supports ADAS performance within tight exterior packaging limits.
That matters even more in NEV platforms, where aerodynamic surfaces, sensor placement, thermal loads, and styling all compete for space. In the AEVS view of exterior intelligence, radar is part of a larger perception chain.
Range, field of view, angular resolution, and integration must be judged together. A sensor that looks strong on paper can still underperform once bumper materials, wheel turbulence, lighting modules, and body architecture enter the picture.
Why automotive mm wave sensors are under closer review
The market expects more from radar than simple proximity detection. Current systems support blind-spot monitoring, rear cross traffic alert, lane change assist, parking, and in some cases forward perception redundancy.
At the same time, vehicle exteriors are becoming more complex. Flush surfaces, thinner lamp assemblies, lightweight fascias, larger wheel designs, and EV-specific airflow treatments can all affect sensor packaging and signal behavior.
This is where automotive mm wave sensors connect naturally with AEVS priorities. Sensor performance cannot be isolated from headlamp architecture, wheel airflow, tire spray behavior, or the body network that links smart switches and perception inputs.
The real selection question is not only which radar has better specifications. It is which radar preserves reliable detection after the vehicle moves from lab validation to rain, dirt, vibration, glare, curbside metal clutter, and mixed traffic density.
A practical way to read the core parameters
Automotive mm wave sensors are usually compared through four visible metrics. Those metrics are useful, but each one only makes sense when tied to a target use case.
Range
Range defines how far the sensor can detect relevant objects with acceptable confidence. Longer range helps at higher speeds, but it often raises demands on signal processing, mounting stability, and false target control.
For corner radar, extreme range is not always the priority. Coverage consistency in the near and mid field may matter more than maximum distance.
Field of view
Field of view determines how wide the sensor can observe. A wider FOV improves side coverage and parking awareness, but it can reduce effective energy concentration and complicate object separation.
In practice, wide FOV is valuable when bumper corners, rear quarter zones, or low-speed urban maneuvers create large lateral uncertainty.
Angular resolution
Angular resolution describes how well the radar distinguishes objects located close together. Higher resolution supports cleaner target separation in dense traffic, roadside barriers, and multi-vehicle overlap conditions.
This parameter matters when a system must tell a motorcycle from a guardrail edge, or separate two vehicles approaching from similar angles.
Integration
Integration covers more than connector fit. It includes bumper transmissivity, radome geometry, ECU communication, thermal exposure, diagnostic logic, and compliance with the rest of the perception stack.
A well-integrated radar can outperform a higher-spec alternative that suffers from poor placement or unstable calibration in the vehicle body.
The trade-offs that usually decide selection
Most evaluation work comes down to managing trade-offs, not finding a universal best sensor. The table below summarizes where those trade-offs usually appear.
This is why spec-sheet comparison alone is rarely enough. Automotive mm wave sensors should be judged against the intended sensing zone, target classes, traffic speed, and exterior constraints of the platform.
How vehicle architecture changes radar performance
A radar module never works in isolation. Exterior parts can either protect signal integrity or quietly degrade it.
Bumper composition is one obvious example. Paint stack, filler materials, metallic pigments, local thickness variation, and radome curvature can change attenuation and reflection behavior.
Wheel and tire areas also matter. Large alloy wheels, brake airflow channels, and tire-generated spray create dynamic clutter near the vehicle corners, especially in wet conditions.
Lighting integration is another overlooked factor. Advanced LED headlight assemblies and corner lamp packaging may limit mounting freedom or create thermal zones that affect long-term electronics durability.
For AEVS-oriented programs, this wider view is essential. Exterior intelligence depends on how optics, surfaces, airflow, and sensor switches work together, not how each subsystem performs alone.
Typical use cases need different radar priorities
The same family of automotive mm wave sensors may fit several functions, but the parameter balance changes by application.
Blind-spot monitoring and lane change assist
These functions depend on stable lateral coverage, low false alerts, and reliable tracking of fast-approaching vehicles. Mid-range performance and wide rear-side FOV usually carry more value than extreme forward distance.
Rear cross traffic alert
This scenario demands clean detection of objects moving across the vehicle path in cluttered environments. Resolution and motion filtering become more important near parked vehicles, pillars, and roadside structures.
Parking and low-speed maneuvering
Short-range accuracy, broad coverage, and stable performance around curbs or walls matter most. Integration with ultrasonic, camera, and body control logic often shapes the final system result.
Forward radar redundancy or fusion support
Here, longer range and better angular resolution gain weight. The sensor must support robust fusion with vision systems and maintain confidence in rain, glare, or partial camera degradation.
What to verify before approving a sensor
A solid evaluation process usually includes bench data, vehicle-level tests, and cross-functional review. The key is to connect performance claims to the actual architecture.
- Check whether stated range applies to real target classes, not only ideal reflectors.
- Verify FOV performance after final bumper material, paint, and mounting angle are fixed.
- Review angular resolution in dense roadside scenes, not only open-track conditions.
- Confirm thermal and vibration behavior near lamps, wheelhouses, and EV cooling paths.
- Assess diagnostic capability, failure reporting, and network compatibility with body electronics.
- Map the sensor against ECE, DOT, and platform-specific validation requirements.
One more point deserves attention. Cost should be measured at system level. A cheaper module may trigger extra shielding, bracket redesign, software tuning, or validation cycles that erase its initial price advantage.
Where the next decisions should focus
The selection of automotive mm wave sensors is moving toward platform thinking. Radar must fit a broader exterior and perception strategy that includes lightweight structures, optical systems, ground-contact behavior, and intelligent body controls.
For that reason, the next useful step is to define the sensing zone first, then screen sensor options against vehicle placement, environmental exposure, and fusion requirements. After that, compare laboratory specifications with real integration losses.
When the goal is a durable ADAS result, the best choice is usually the sensor that delivers balanced coverage, stable packaging, and predictable validation outcomes across the full exterior system.
A disciplined review of range, FOV, resolution, and integration creates a stronger basis for roadmap decisions, supplier comparison, and future-ready exterior intelligence planning.